Humanoid
Humanoid robots end to end: hardware platforms, whole-body control, and the research and commercial race behind them.
69 articles in this topic
Deploying cuRobo on real robots: checklist and rollback
The final guide in the series: current cuRobo issues, Jetson deployment risks, and safety checklists for robot arms and Unitree G1.

Humanoid Adaptation: Extending VIMA to High-DoF Humanoid Robots
VIMA series capstone: adapt from tabletop 6-DoF to Unitree G1 23-DoF — freeze backbone, swap action head, bridge data gap with teacher-student and LoRA fine-tuning.

PlotJuggler Lua: Computing Power and Tracking Error for G1
PlotJuggler Custom Function Editor writes Lua computing per-joint power (τ × dq) and tracking error — detecting overloaded joints /lowstate doesn't expose.

ZMQ + VideoViewer: Sim-to-Real Debug for G1 with PlotJuggler
A ZMQ bridge from MuJoCo/Python to PlotJuggler to stream G1 sim state live, sync VideoViewer with hardware, and compare sim-to-real gaps per joint/gait phase.
G1 whole-body with cuRobo: floating base and retargeting
A deployment-oriented guide to Unitree G1 whole-body workflows with cuRobo extra_links, tool frames, MotionRetargeter, IK/MPC, and BVH/SOMA data.

PlotJuggler + G1: ROS2 Setup & Live Topic Streaming
Install ros-humble-plotjuggler-ros, configure CycloneDDS for Unitree G1, and stream /lowstate and /sportmodestate live in under 15 minutes.

Visualizing 23 G1 Joints: MCAP Bags & Panel Layouts
Load G1 MCAP recordings with the DataLoadMCAP plugin, drag 23 joint channels into a synced multi-panel grid, save layout as XML, and plot phase portraits.

IMU Debug: Quaternion to Euler + FFT Vibration Analysis
ToolboxQuaternion converts G1 IMU quaternions to roll/pitch/yaw, ToolboxFFT detects gyroscope resonance, and Moving Average smooths foot_force data.

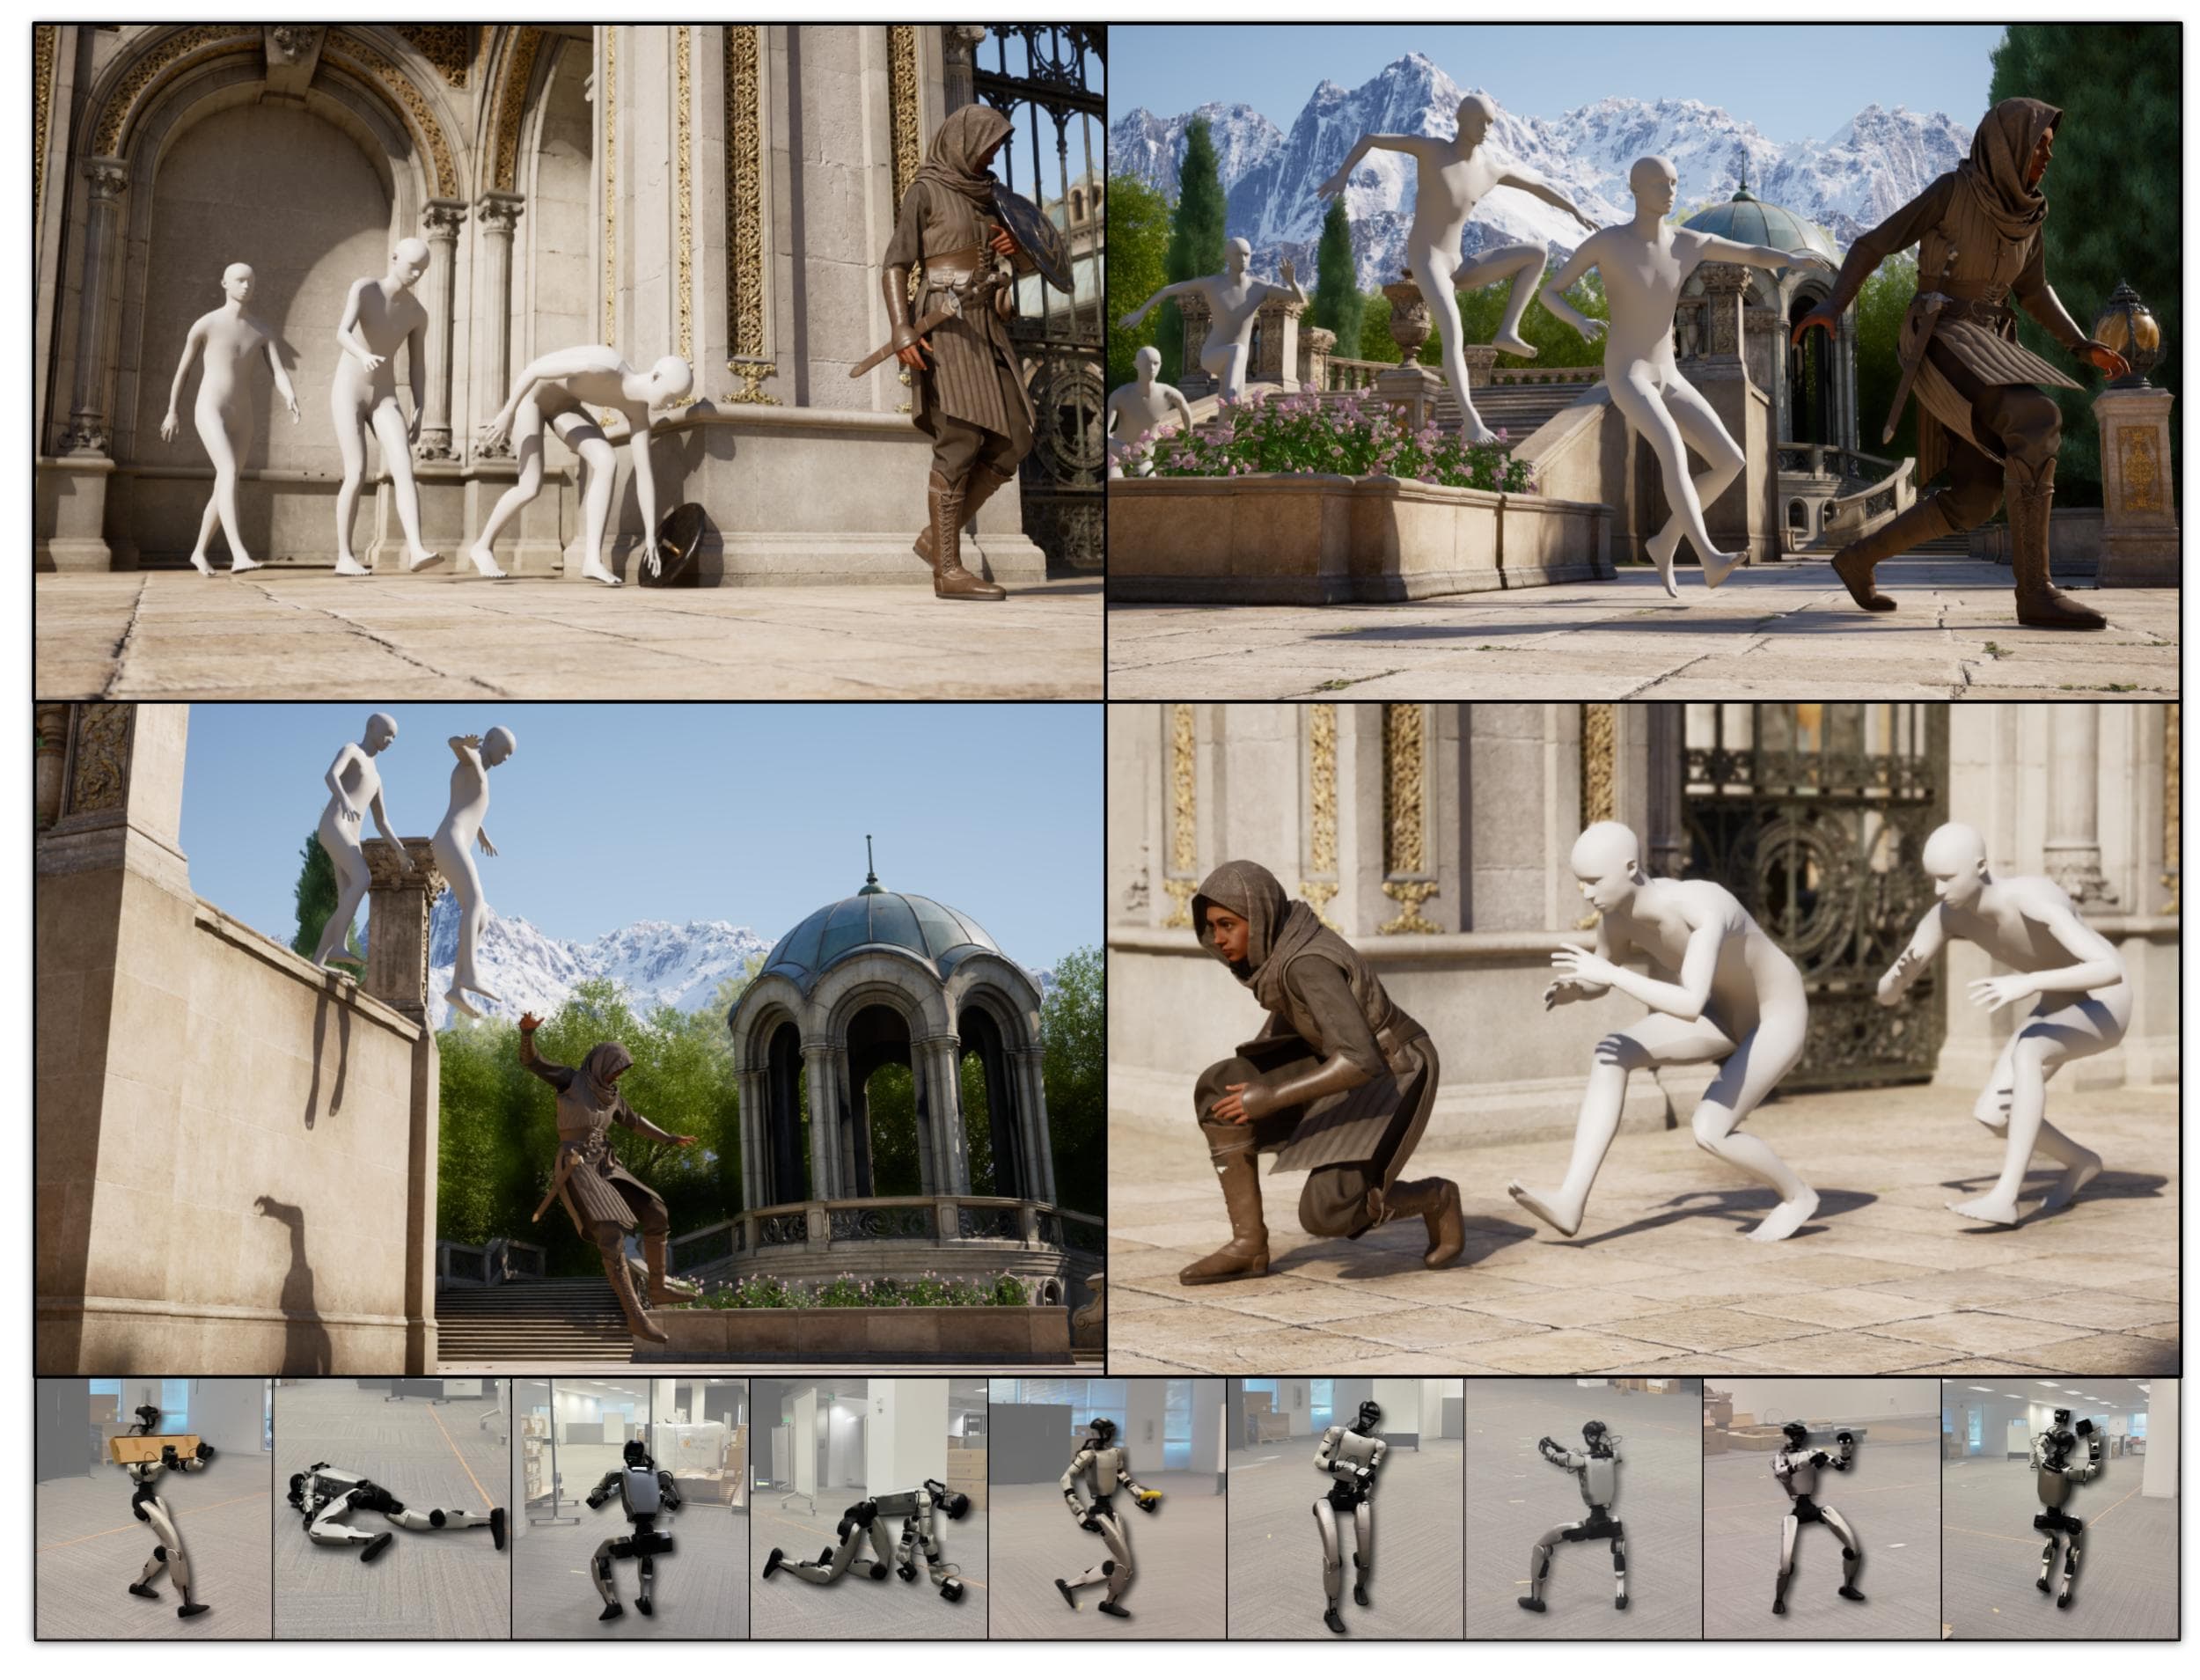
SOMA-X v0.2: One Rig, Every Body
SOMA-X v0.2 unifies body models, pose conversion, LODs and pose inversion for physical AI, humanoid simulation and robotics.

MotionBricks Real-Time Motion Tokens
Connect SONIC to MotionBricks with VQVAE, pose/root models, synthetic training, and ZMQ v4 token_state.
MPC-RL: Training Humanoids with MPC
A beginner-friendly guide to MPC-RL: MPC-shaped PPO rewards, repo setup, training, inference, and results for humanoid locomotion and pushing.

G1 Upper Body: IK, VR and MuJoCo
Follow the OpenWBT pipeline: VR wrist pose, G1_29_ArmIK, action_hl_idx clipping, and G1 upper body control in MuJoCo.

A Sim2Real Checklist for G1 Controllers
A practical G1 sim2real checklist covering DDS, ROS_DOMAIN_ID, OpenWBT, .pkl logs, PlotJuggler, damping and torque guards.
G1 arm-only planning with cuRobo: keeping balance
Using cuRobo for Unitree G1 arm-only workflows with locked legs/waist, joint maps, wrist tool frames, self-collision, and command gates.
Open vs Closed: Licenses, Data Moats, and What's Next
Compare robot dataset licenses, commercial training risk, closed fleet data moats, and the likely open vs closed landscape in 2027.
Data Strategy: What Should Small Teams Collect?
A practical playbook for small robotics teams: SO-101 data, LeRobotDataset v2, pretrained VLA fine-tuning, and HF datasets.
Synthetic Data Pipelines: From Sim to Real
How to turn a few human demos into thousands of robot trajectories with MimicGen, GR00T-Mimic, RoboCasa, and sim-real co-training.

VLA Data Scaling Laws for Robot Learning
Robot data does not scale by raw demo count alone. This guide explains diversity power laws and when more data becomes wasted spend.
Teleoperation: Real-World Robot Data Collection
Compare AgiBot, Unitree XR, ALOHA 2, Mobile ALOHA, and GELLO to choose a real-world teleoperation data stack by budget.
Human Video Mining: Pre-training Robots from Human Video
How Ego4D, EPIC-Kitchens, web video, LAPA, GR00T N1, EgoMimic, and EgoHumanoid turn human video into robot pre-training data.

Human Video: Phantom and pi0.5
Compare Phantom and pi0.5 to decide when human videos become training data, derived robot data, or benchmark evidence.

VLA Stack: Data to Deployment
Close the series with the VLA lifecycle from LeRobot datasets and norm stats to pi0.5 checkpoints, policy serving, and robot actions.
Humanoid Data Map 2026
A beginner-friendly map of humanoid data: raw files, LeRobot, Isaac Lab, Humanoid Everyday, and who controls value at each layer.

VR Teleop: PICO/ZED to HDF5
A practical EgoHumanoid walkthrough: PICO/ZED capture, raw HDF5/SVO2, five processing stages, and consent/licensing audit points.

Aligning Human View to Robot View
How EgoHumanoid uses depth warping and inpainting to turn egocentric human video into robot-compatible observations.

unifolm-vla + Unitree G1 (Post 5): deploy inference server, SSH tunnel, and parallel locomotion
Final series post: start the FastAPI inference server, connect G1 via SSH tunnel, send action commands, run arm VLA and locomotion simultaneously — with safety checklist and debug guide for common real-hardware failures.

Train SONIC, Export, and Evaluate GRAIL
Train SONIC task-general trackers, map paper metrics to code paths, and export successful GRAIL rollouts.

3D Assets and Terrain in GRAIL
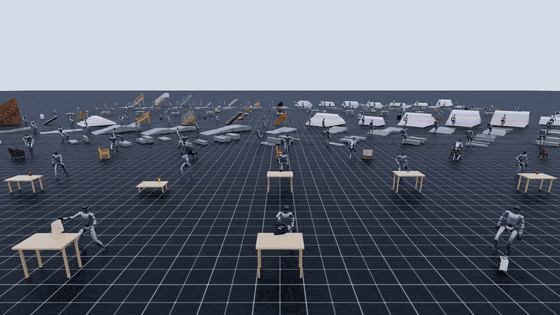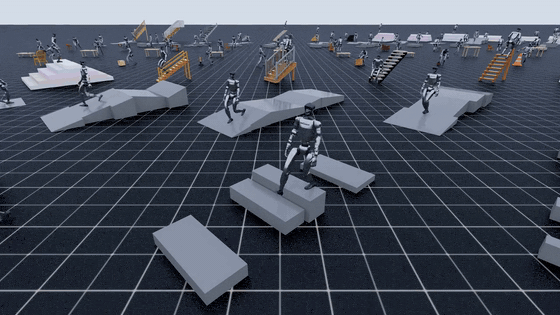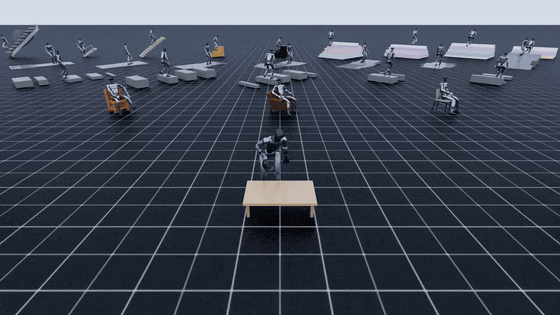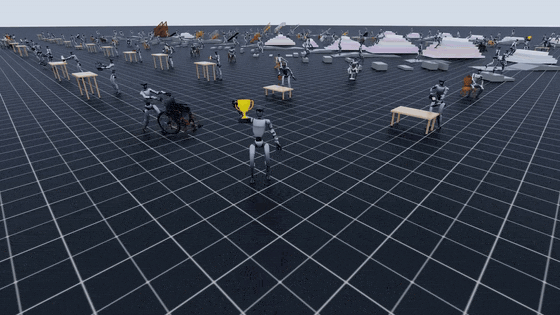
Dissect GRAIL's two asset paths: procedural terrain and Hunyuan3D text-to-mesh for loco-manipulation.

2D HOI Videos with Blender and Kling
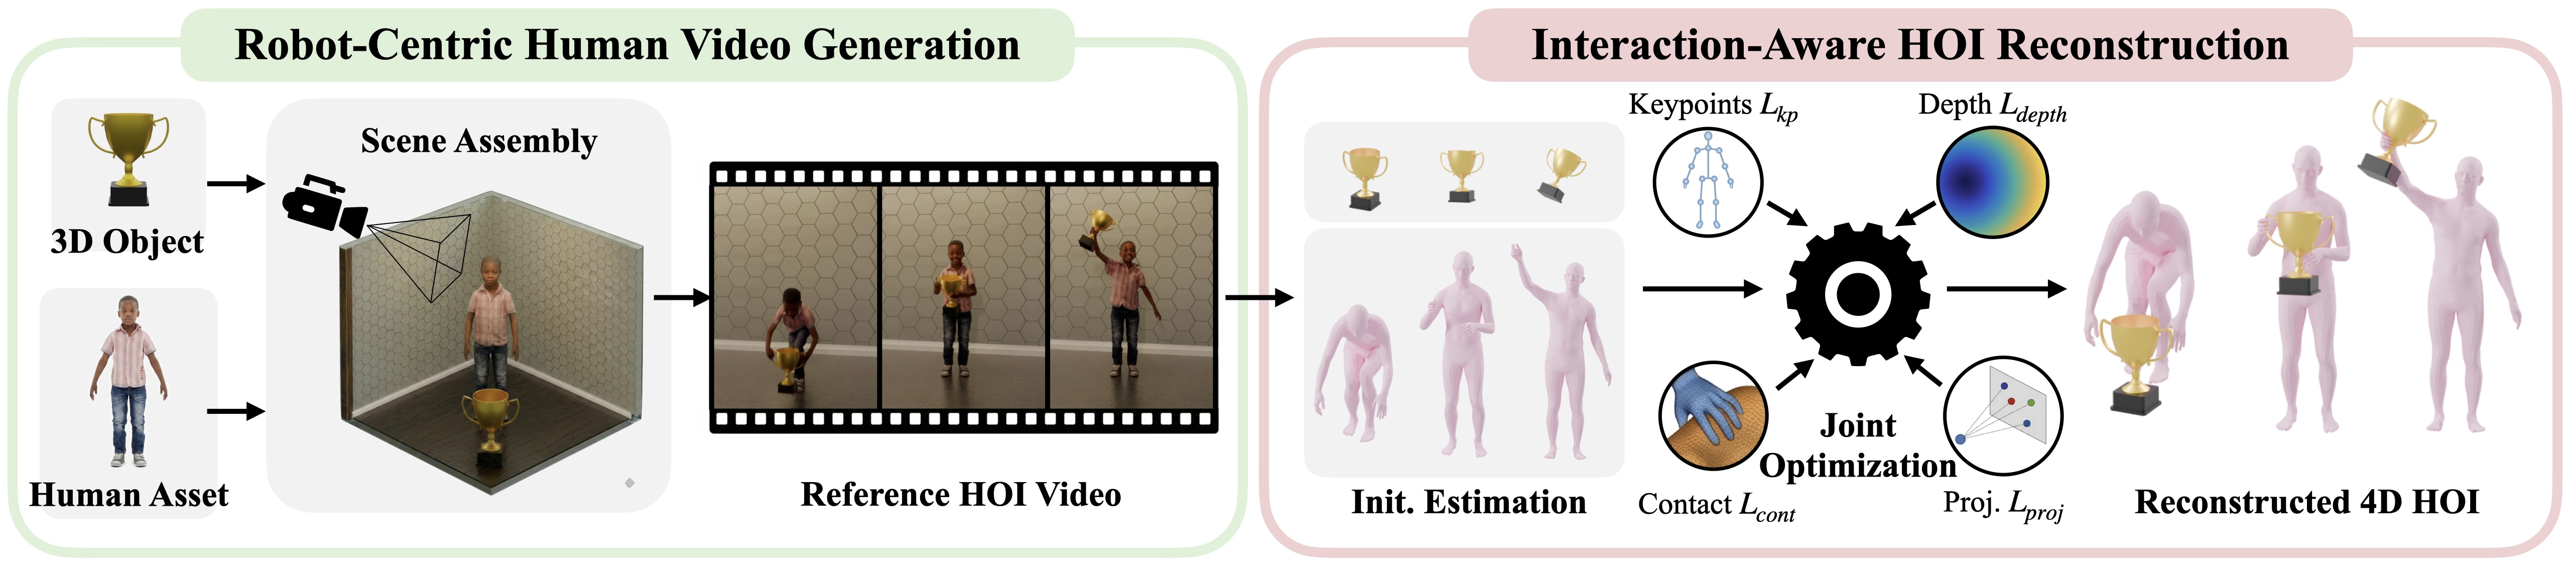
Run gen_2dhoi for cordless_drill: Bullet settling, scale/prompt refinement, scene rendering, and Kling videos.

4D HOI Reconstruction: GEM, SAM2, MoGe
A beginner guide to recon_4dhoi: human pose, masks/depth, FoundationPose, HOIOptimizer, filtering, and visualization.
Retarget SMPL-X Motions to Unitree G1
Trace GRAIL retargeting: SMPL-X to G1, hand actions, table geometry, lift thresholds, and BPS embeddings.

unifolm-vla + Unitree G1 (Post 4): fine-tuning from Qwen2.5-VL-7B — 8-GPU and single-GPU LoRA
Fine-tune unifolm-vla from the public Qwen2.5-VL-7B-Instruct checkpoint (since Unifolm-VLM-0 is not public) — covering the official 8-GPU DeepSpeed approach and a single-GPU QLoRA workaround for beginners.

Whole-body VLA: combining UMI + mocap/VR for full-body humanoid data
Architecture and design principles for extending UMI from upper-body manipulation to whole-body humanoid data collection by combining it with mocap or VR teleop — practical analysis from HumanPlus, OmniH2O, and Open-TeleVision.

GR00T N1 + G1 (Post 5): sim2real transfer and eval
Closing the loop: domain randomization in Isaac Lab, actuator modeling for sim2real gap, deploy to real G1, benchmark with humanoid-bench, plus a debug guide.
VLA + WBC repos from China: Unitree, THU RDT-1B, and the open community
Deep dive into VLA and Whole-Body Control GitHub repos from China and the open community — Unitree (unifolm-vla, xr_teleoperate, unitree_rl_gym), THU RDT-1B, RobotEra humanoid-gym, and benchmark tools.

GR00T N1 + G1 (Post 4): deploying GR00T-WBC — GEAR + SONIC
Deploy the GR00T-WBC stack (GEAR upper body 50Hz + SONIC locomotion 200Hz) on G1 with a fine-tuned GR00T N1 checkpoint — joint mapping, PD tuning, safety.
VLA + WBC repos from the US: NVIDIA GR00T, openpi, HumanPlus, TeleVision
Deep dive into VLA and Whole-Body Control GitHub repos from US companies and labs — NVIDIA Isaac-GR00T, GR00T-WholeBodyControl, Physical Intelligence openpi, Berkeley HumanPlus, Stanford TeleVision, OpenHelix, and EgoHumanoid.
Choosing Cameras for Humanoid Robots: RGB-D, Wrist Cameras, and Calibration
A practical guide to humanoid robot cameras: head RGB-D, wrist cameras, RealSense, OAK-D, latency, ROS 2, calibration, and affiliate placement.

unifolm-vla + Unitree G1 (Post 3): data pipeline — JSON → LeRobot → HDF5 → RLDS
3-step guide to converting teleoperation data: from JSON (xr_teleoperate) to LeRobot V2.1, to HDF5, to RLDS format ready for unifolm-vla training — with dataset verification at each step.
Humanoid Robot Hardware Stack: A Practical Build Roadmap
A practical roadmap for humanoid robot hardware: compute, actuators, cameras, IMU, power, safety, logging, and natural affiliate placements.

GR00T N1 + G1 (Post 3): fine-tuning — GPU, config, script
Fine-tune GR00T N1 (2B params) with a LeRobot dataset from G1 — GPU requirements, training config, avoiding overfitting, evaluating checkpoints before deploy.
VLA + WBC repos landscape 2025-2026: all humanoid GitHub repos mapped
A complete map of active GitHub repositories from humanoid companies and research labs working on VLA (Vision-Language-Action) and WBC (Whole-Body Control) — from NVIDIA to Unitree.
Choosing Jetson for Humanoid Robots: Orin Nano or Orin NX?
A practical comparison of Jetson Orin Nano, Orin NX, and cloud GPUs for humanoid robots across ROS 2, cameras, VLA inference, logging, training, and budget.

GR00T N1 + G1 (Post 2): data collection with xr_teleoperate
Collecting data for GR00T N1 via two tracks: Isaac Lab simulation teleop (no robot needed) and real xr_teleoperate on G1 — both producing LeRobot format.

unifolm-vla + Unitree G1 (Post 2): collecting data with xr_teleoperate + Meta Quest 3
Step-by-step guide to setting up xr_teleoperate with Meta Quest 3, connecting G1, recording teleoperation demos, and collecting high-quality data for VLA training on real hardware.

GR00T N1 + G1: decoupled WBC+VLA architecture, 6Hz-500Hz
How GR00T N1 (VLA at 6Hz) combines with GR00T-WBC (200Hz) to control Unitree G1 — decoupled architecture, why end-to-end fails, how to adapt for other robots.

unifolm-vla + Unitree G1 (Post 1): WBC+VLA system architecture — from data to real hardware
Overview of the 3-repo architecture — unifolm-vla (VLA), xr_teleoperate (data collection), unitree_rl_gym (locomotion) — and how they connect into a whole-body control pipeline for Unitree G1 on real hardware.

SUGAR: Train Humanoid from Human Videos, No Reward
Detailed guide to SUGAR (arXiv 2026.05) — humanoid loco-manipulation framework that learns from real human videos, fully open-source, beginner-friendly end-to-end.

Booster Gym: Train Humanoid T1 Sim-to-Real with Isaac Gym
Detailed guide to Booster Gym — open-source end-to-end RL framework training Booster T1 humanoid walking from teleop to real-world deployment.
LIFT humanoid ICLR 2026: SAC pretrain + world model finetune
Reproduce LIFT (ICLR 2026): pretrain SAC in MuJoCo Playground, then sim2sim fine-tune a physics-informed world model in Brax for Booster T1 and Unitree G1.
SteadyTray: Unitree G1 Tray Carrying with Residual RL
Reproduce SteadyTray on IsaacLab — train a Unitree G1 humanoid to carry a tray without dropping objects using a two-stage Residual RL architecture.
Sim-to-Real for Humanoids: Deployment Best Practices
Complete pipeline for deploying RL locomotion policies to real humanoid robots — domain randomization, system ID, safety, and Unitree SDK.

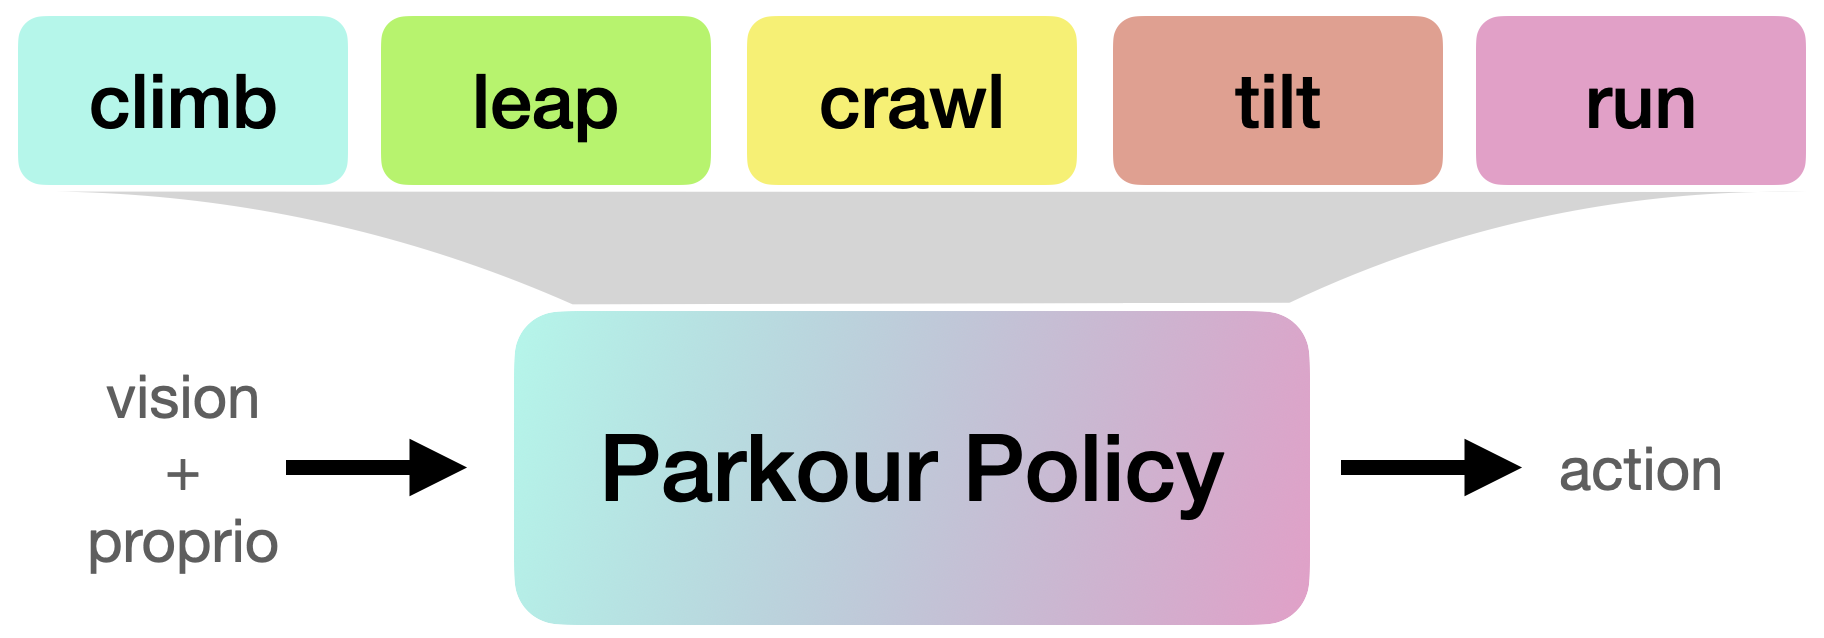
Humanoid Parkour: Jumping, Climbing & Obstacle Courses
Parkour for humanoid robots — jumping obstacles, climbing stairs, navigating rough terrain with RL and terrain perception.

Loco-Manipulation: Walking While Carrying & Manipulating Objects
Combine locomotion and manipulation: carry boxes, push carts, open doors while walking, with multi-objective reward design.

Unitree H1-2: Enhanced Locomotion with New Hardware
Explore H1-2 with dexterous hands and improved actuators, how hardware changes affect locomotion, and loco-manipulation basics.

Unitree H1: Running, Turning & Dynamic Motions
Extend H1 policy to running at 2+ m/s, sharp turning, lateral walking, and a multi-gait command-conditioned policy.
Unitree H1: Full-size Humanoid Locomotion Training
Train locomotion for the full-size Unitree H1, compare with G1, and adjust rewards and PD gains for a 1.8m humanoid.
Unitree G1 vs H1 vs Tesla Optimus: 2026 Humanoid Comparison
Detailed analysis of 3 most popular humanoid robot platforms — specs, pricing, SDK, and practical applications.

Unitree G1: Terrain Adaptation & Robust Walking
Extend G1 walking policy to complex terrain with curriculum learning, domain randomization, and teacher-student training.

Unitree G1: Training a Walking Policy from Scratch in Isaac Lab
Step-by-step tutorial to train a walking policy for Unitree G1 with PPO in Isaac Lab, from config to evaluation.

Reward Engineering for Bipedal Walking: The Art of Reward Design
Detailed analysis of 12+ reward terms for humanoid walking, reward hacking avoidance, and reward curriculum from standing to walking.

RL Locomotion for Humanoids: Fundamentals & Environment Setup
Learn why humanoid locomotion is hard, MDP formulation for bipedal walking, and how to set up Isaac Lab environment for Unitree G1.
The Future of Humanoids: Opportunities for Engineers
Humanoid robot market at $38B by 2035 — hiring trends, essential skills, and learning roadmap for Vietnamese robotics engineers.

Loco-Manipulation: Walking and Manipulating Simultaneously
Techniques for controlling humanoids that both move and manipulate objects — decoupled control, teleoperation, and imitation learning.

RL for Humanoid: From Humanoid-Gym to Sim2Real
Guide to training locomotion policies for humanoid robots with Humanoid-Gym — from reward design to zero-shot sim-to-real transfer.

Whole-Body MPC: Real-Time Full-Body Control
Whole-body Model Predictive Control with MuJoCo and iLQR — from contact dynamics theory to real-time deployment on humanoid robots.
Humanoid Control Basics: IK to Task-Space Control
From Inverse Kinematics to operational space control — theory and Python code for controlling humanoid robot balance and task execution.
Humanoid Robots 2026: Complete Platform Overview
Detailed comparison of Atlas, Optimus Gen 3, Figure 02, Unitree H1/G1/H2, Fourier GR-2, and 1X NEO -- specs, pricing, SDK and ROS 2 support.
Humanoid Robots: From Research to Real-World Applications
Overview of humanoid robots — bipedal walking, whole-body control, and platforms like Tesla Optimus, Figure 02, and Unitree H1.