Physical AI,
from perception to control
Humanoids, robot arms, AMRs and self-driving cars run the same stack: perception → planning → control → sim2real. Read the walkthrough, then run it in a MuJoCo lab in your browser. No $3,000 robot required.
0
Technical articles
0
Learning series
0
Topics
0
Languages
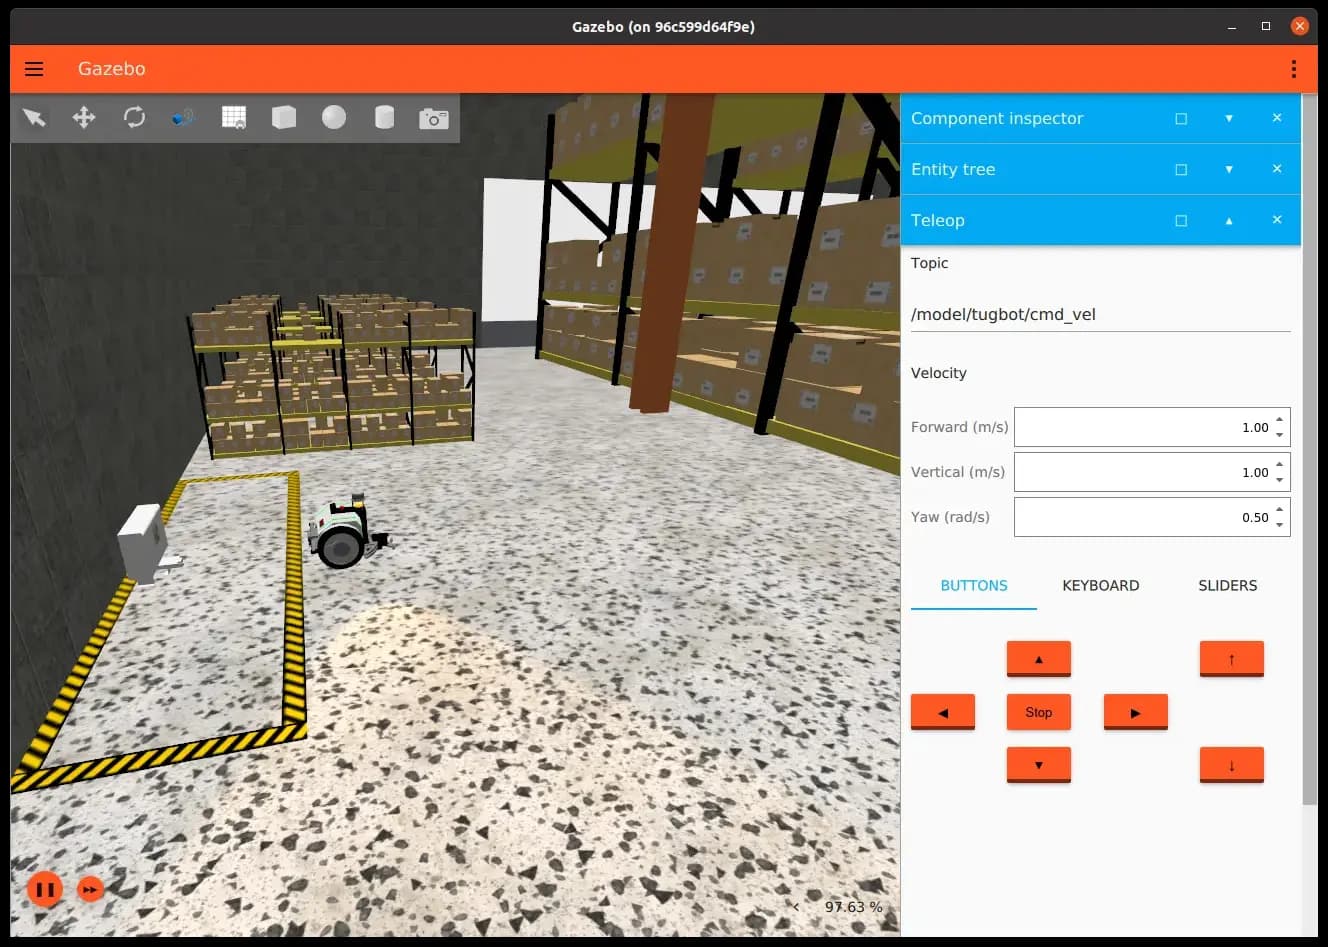 Nav2 · warehouse navigation sim
What we cover
One stack, every machine that acts
Humanoids, arms, mobile robots and vehicles share perception, planning and control. Each pillar below is a hub of in-depth articles.
Humanoid
Humanoid robots end to end: hardware platforms, whole-body control, and the research and commercial race behind them.
Whole-body VLA
Vision-Language-Action models and whole-body control — LeRobot, pi0, GR00T, OpenVLA and the training recipes behind them.
Manipulation
Robot arms and hands — grasping, dexterous and bimanual manipulation, from classical IK to learned policies.
Locomotion
Getting robots to walk, run and recover: quadruped and bipedal gait, terrain adaptation, and the controllers that keep them upright.
Navigation
Autonomous mobility indoors and out: SLAM, Nav2, AMR fleets, mapping and vision-language navigation.
ADAS & Autonomous Driving
Advanced driver assistance and autonomous driving — sensor suites, lane keeping, camera-radar fusion, ODD design and the validation work that makes them shippable. The engineering bridge between automotive perception and robotics.
Simulation
Physics simulation for robots — MuJoCo, Isaac Sim, digital twins and the sim-to-real gap that decides whether a policy survives contact with hardware.
AI & Perception
Perception and learning for embodied systems: computer vision, reinforcement learning, diffusion policies, imitation learning and edge inference.
Research & Trends
Paper walkthroughs and trend analysis from ICRA, CoRL, RSS, IROS and Science Robotics — what actually matters and what is hype.
Platform
From reading to your first experiment
Learn the foundations, change a configuration and observe a simulation in your browser. Connect the fleet dashboard when you have a real robot.
01 / 06
Follow a learning path
Start a lesson, complete its challenge and continue at your own pace. Use your personal account without creating a workspace first.
- Lessons and challenges by track
- Continue a lesson in progress
- Vietnamese and English interfaces
Follow a learning path
Start a lesson, complete its challenge and continue at your own pace. Use your personal account without creating a workspace first.
Control Lab in your browser
Run, pause and adjust a MuJoCo simulation to observe what each change does. 3D support depends on your browser and device.
Save and compare experiments
Choose a workspace when you want to save results. Add a title and notes, then compare saved runs to understand what changed.
Pick up where you left off
Review your progress and the recommended next lesson. Complete a lesson, then open the Lab to try what you learned.
A Physical AI knowledge base
Read technical guides and analysis covering perception, planning, control and sim-to-real, with links to papers and reference code.
Have a robot? Connect your fleet
A separate path for people with hardware: choose a workspace, add a robot and monitor telemetry in the dashboard.
Getting started
Your first lesson, then the Lab
No robot or simulation setup required. Create an account to start learning.
- 01
Choose the learning path
Sign up and choose learning and simulation. You can learn with a personal account.
- 02
Complete your first lesson
Read the lesson, try its challenge and follow the next recommendation.
- 03
Try it in the Lab
Open the Lab, run and pause to observe. Choose a workspace when you want to save results.
No credit card · Learn first, choose a workspace when you need to save
Already have a robot? Read the connection guidePricing
Learn and try the Lab for free
Start with a personal account. Talk to us if you need support for a class or project.
FAQ
Frequently asked questions
What to know before your first lesson and experiment.
Turn what you read into an experiment.
Start with a lesson, try it in the Lab and save what you discover.