Knowledge Base
Blog
Sharing knowledge about Robotics, AI & Industrial Automation
Latest Posts
Browse Series
Adas Fundamentals 2026
· 6 parts
Part 1/6
SAE Level 2 vs 2+ vs 3 vs 4: What Actually Changes
10 min read
Part 2/6
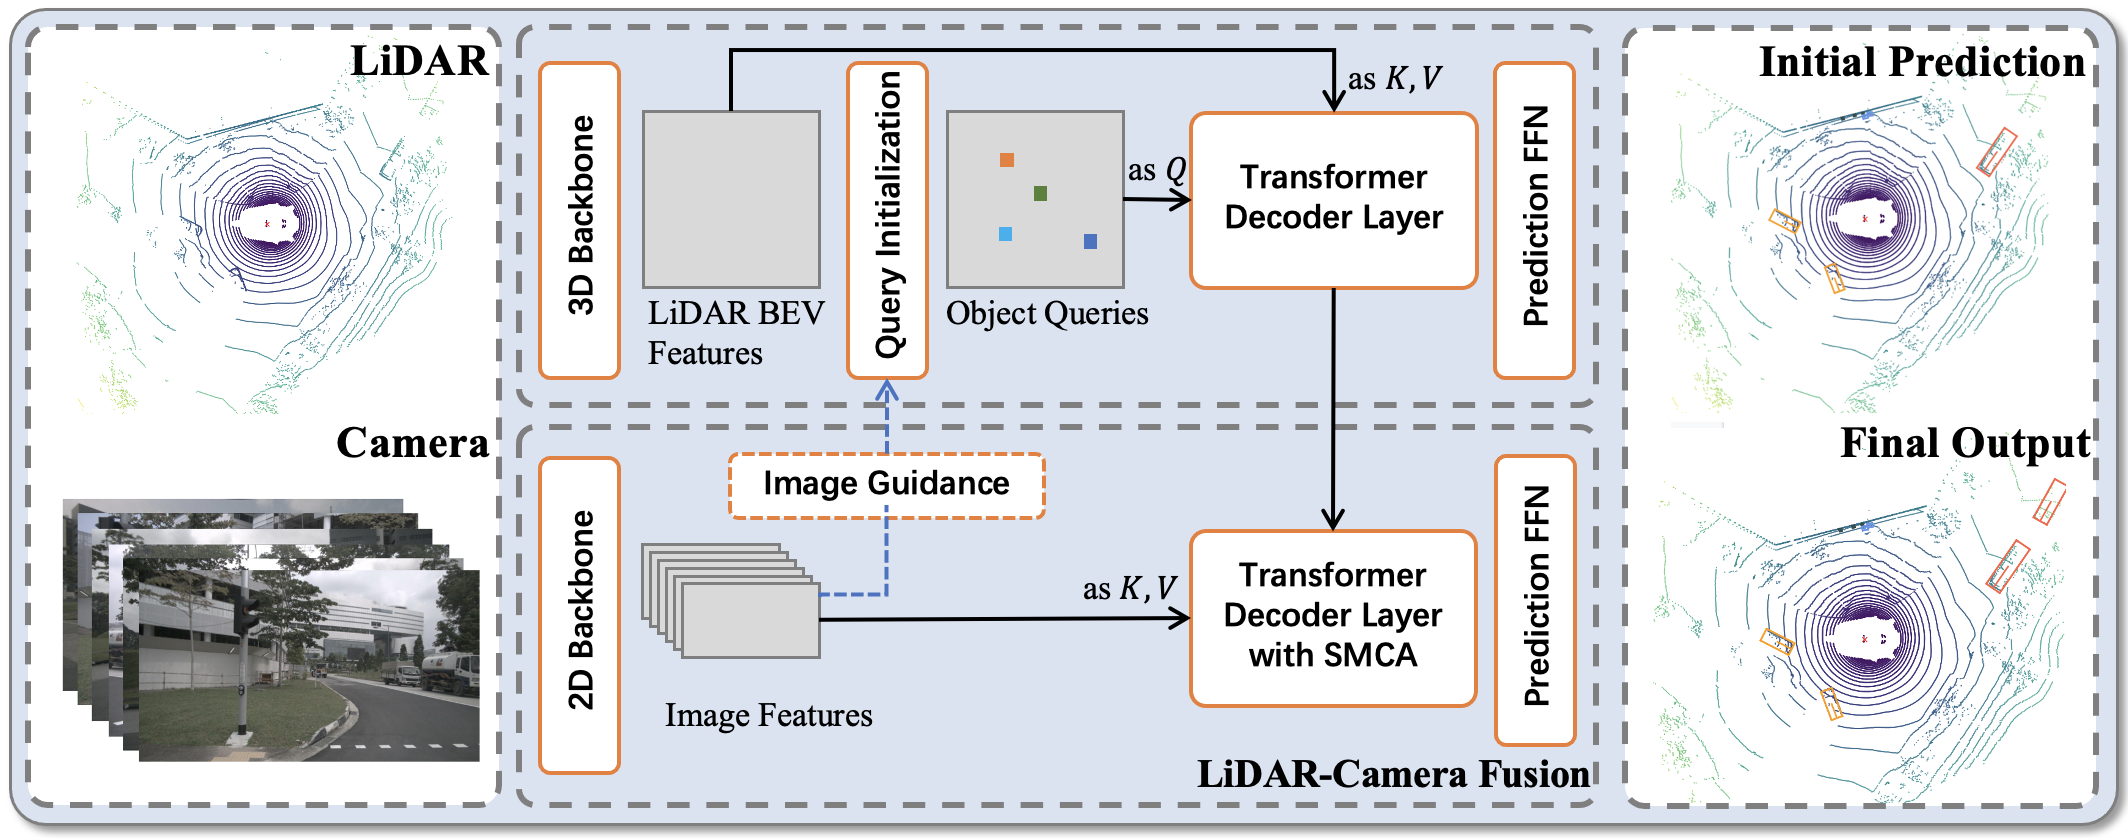
Sensor Fusion for ADAS: Camera, Radar, LiDAR in 2026
11 min read
Part 3/6
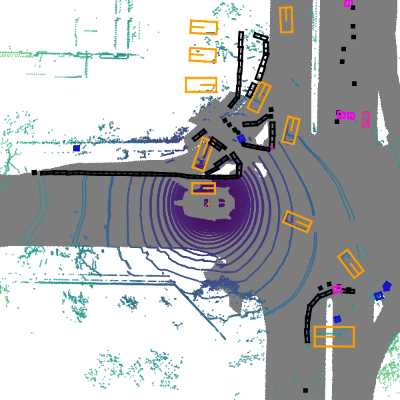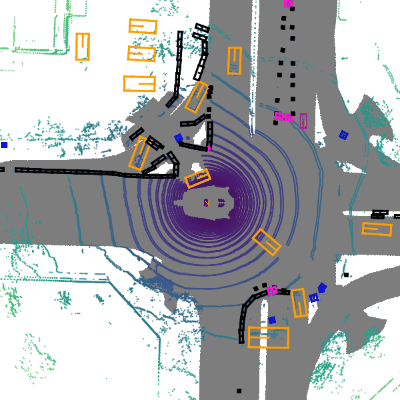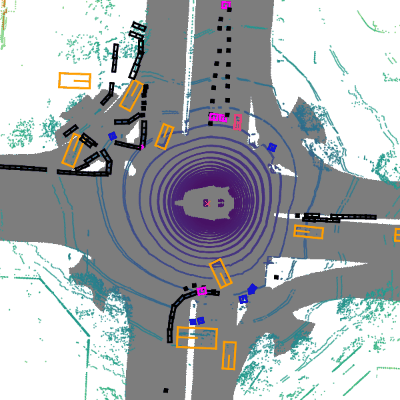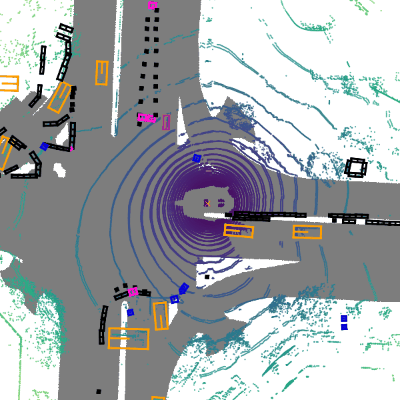
ADAS Perception: 3D Detection and Occupancy Grid 2026
12 min read
Part 4/6
ADAS Localization and HD Maps: NDT, Lanelet2, MapFree
17 min read
Part 5/6
ADAS Planning and Control: From Rule-Based to MPC and PDM
16 min read

Part 6/6
ADAS Validation: ISO 26262, SOTIF, and Euro NCAP 2026
17 min read
Adas E2e 2026
· 6 parts
Part 1/6
From UniAD to VLA: Mapping End-to-End Driving in 2026
11 min read
Part 2/6
Run a Driving VLA Yourself: OpenDriveVLA on nuScenes
9 min read
Part 3/6
Benchmarks Are Arguments: NAVSIM v2, Bench2Drive, WOD-E2E
11 min read

Part 4/6
Alpamayo-R1: Reasoning You Can Actually Inspect
8 min read

Part 5/6
World Models Stopped Being About Pretty Video
11 min read
Robotics
Part 6/6
What Robotaxi Fleets Actually Publish About Safety
13 min read
cuRobo on Jetson AGX Orin and Unitree G1
· 10 parts
Part 1/10
cuRobo on Jetson AGX Orin and Unitree G1: a 10-part roadmap
5 min read

Part 2/10
Installing cuRoboV2 on Jetson AGX Orin: CUDA and smoke tests
4 min read

Part 3/10
Building a cuRobo robot model: URDF and collision spheres
3 min read

Part 4/10
FK and IK in cuRobo: frames, quaternions, and joint order
3 min read

Part 5/10
Motion planning and grasping with cuRobo: obstacles, seeds
3 min read

Part 6/10
A ROS 2 bridge for cuRobo: from goal pose to JointTrajectory
2 min read

Part 7/10
Scene mapping for cuRobo: depth cameras, TSDF/ESDF
3 min read

Part 8/10
G1 arm-only planning with cuRobo: keeping balance
3 min read

Part 9/10
G1 whole-body with cuRobo: floating base and retargeting
4 min read

Part 10/10
Deploying cuRobo on real robots: checklist and rollback
5 min read
Ai Manipulation Agents
· 5 parts
Part 1/5
Multi-Agent Beats Single VLA Models | Manipulation Agents #1
11 min read
Part 2/5
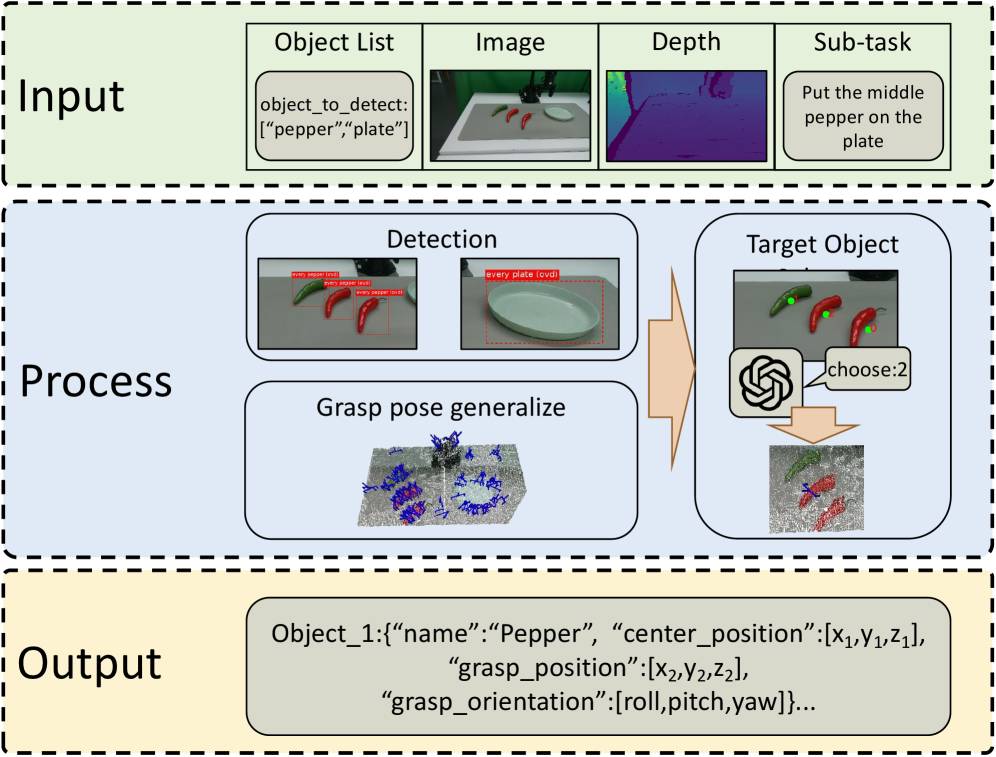
Perception Agent: Florence-v2 + AnyGrasp | Agents #2
14 min read
Part 3/5
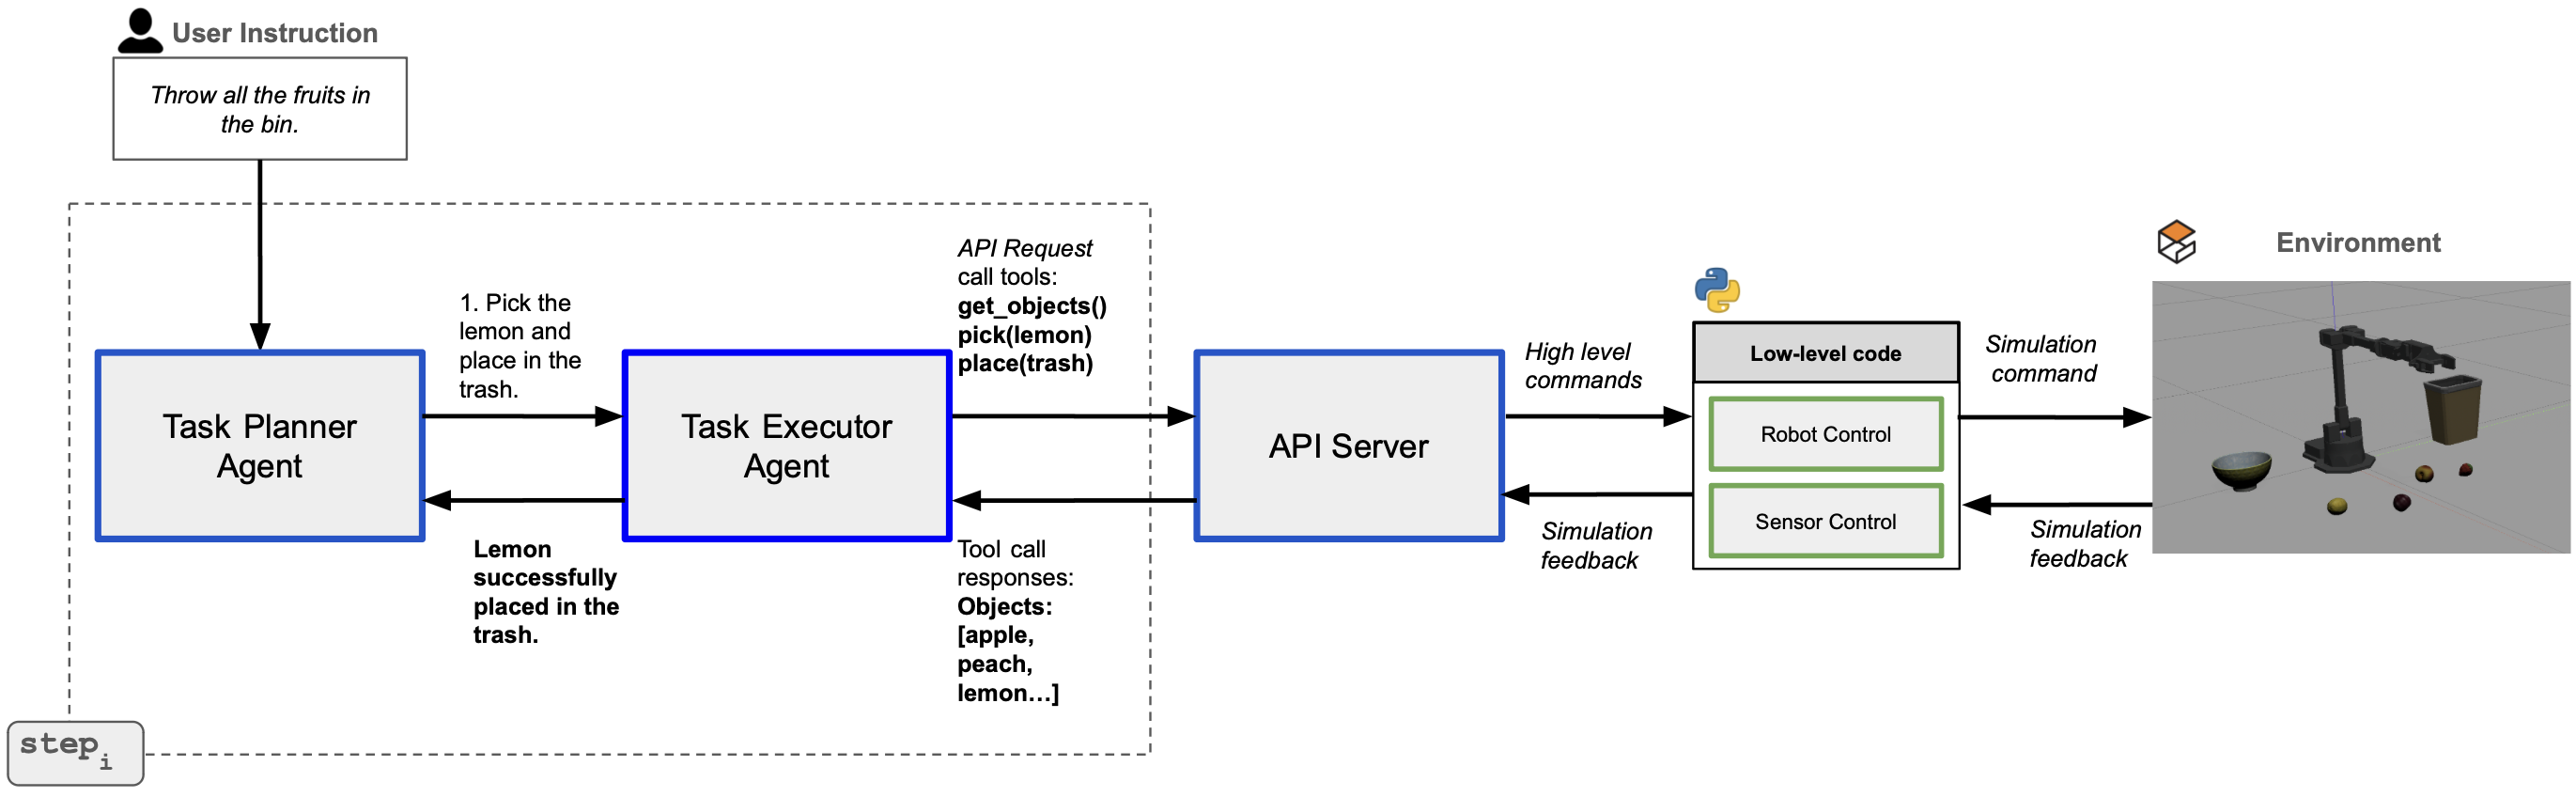
ALRM: Code-as-Policy vs Tool-as-Policy | Agents #3
11 min read
Part 4/5
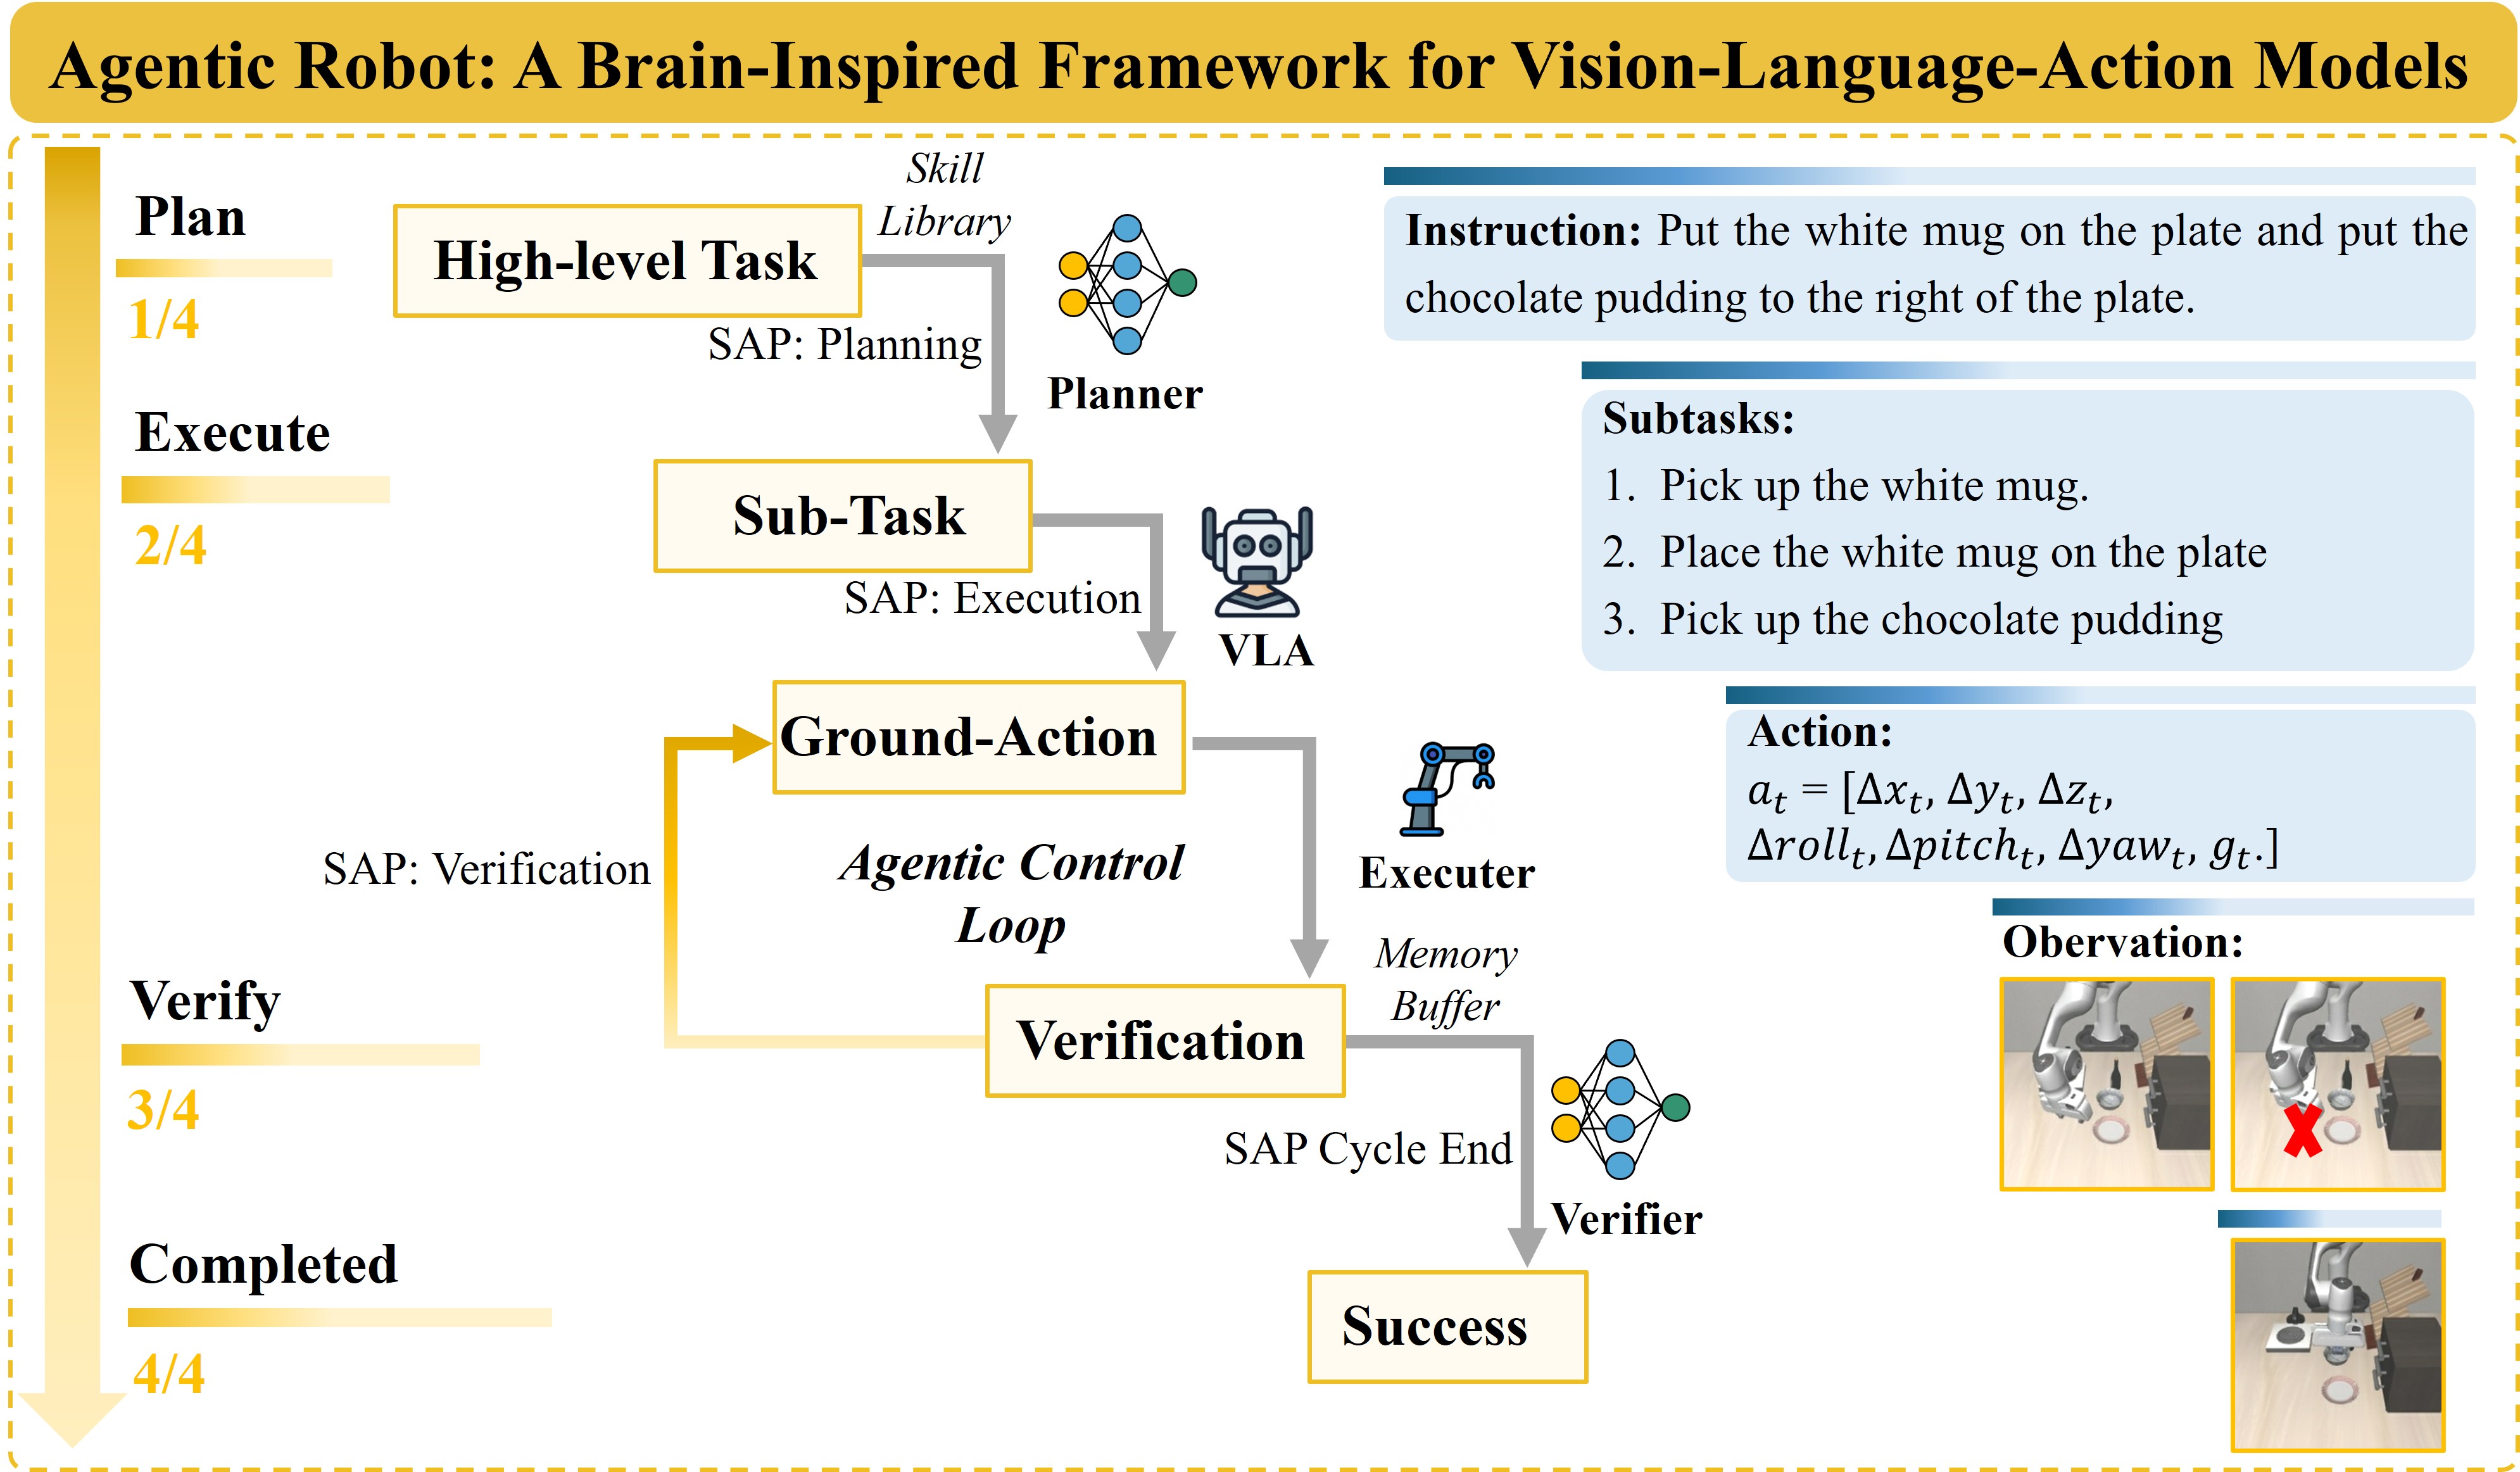
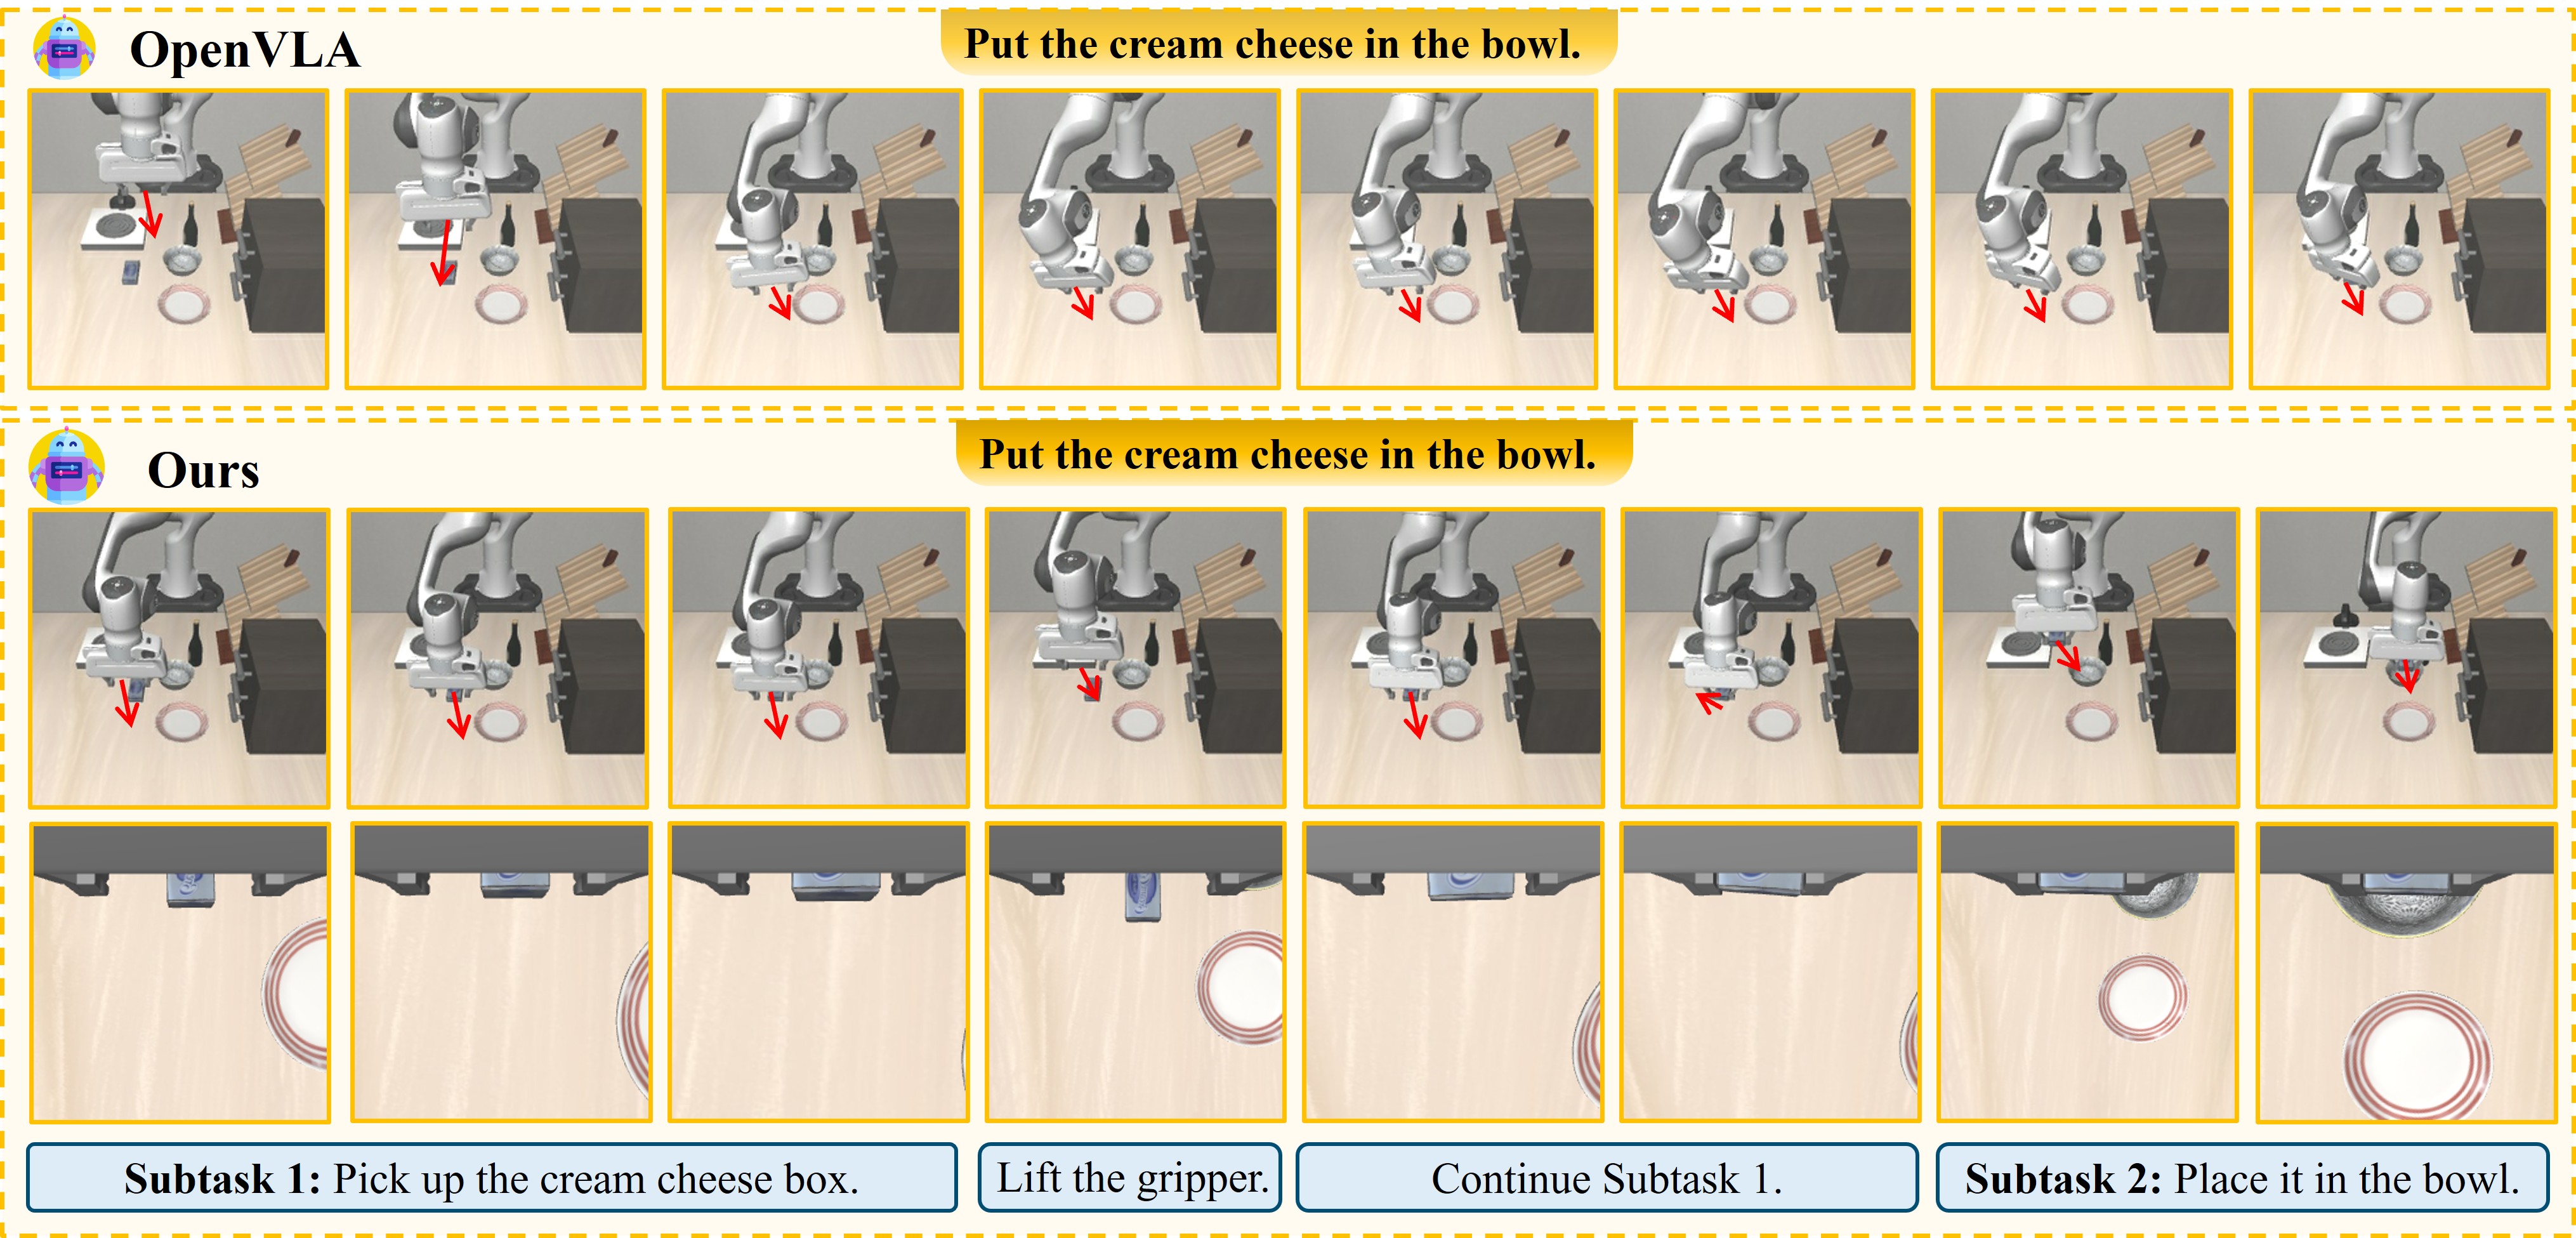
Agentic Robot: SAP Protocol & Temporal Verifier
13 min read
Part 5/5
Sim-to-Real: Moving the SAP Pipeline from LIBERO to Robots
15 min read
Vima Humanoid Manip
· 5 parts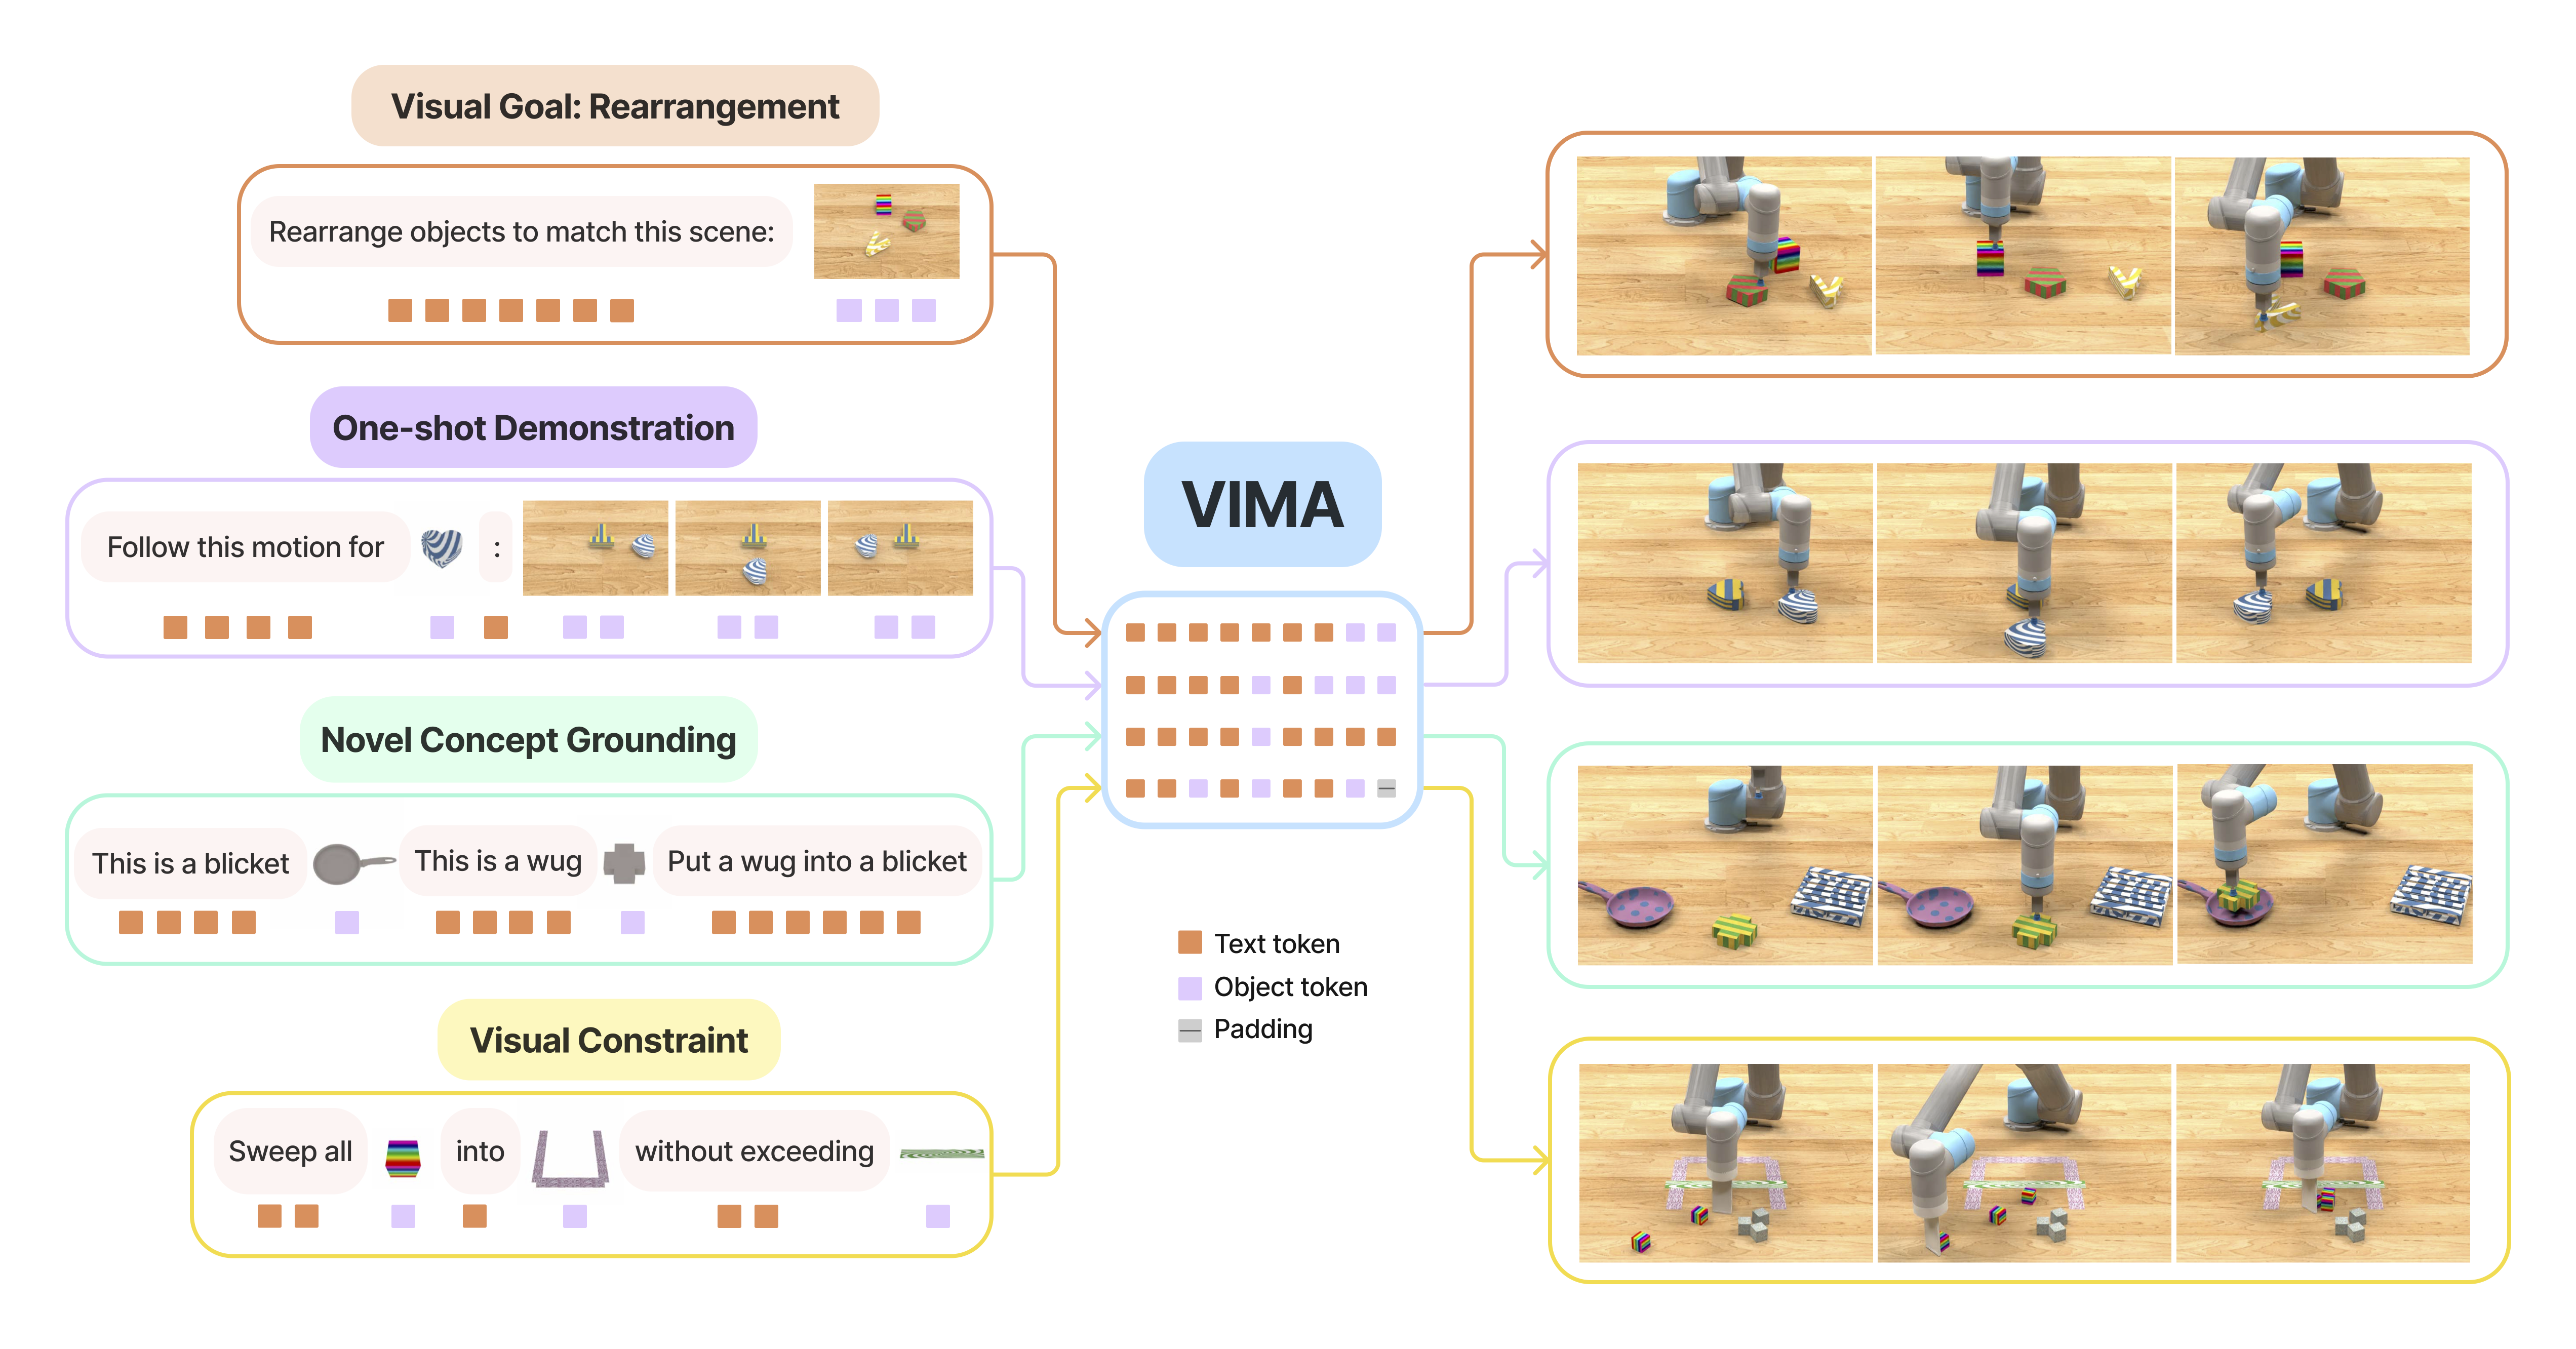
Part 1/5
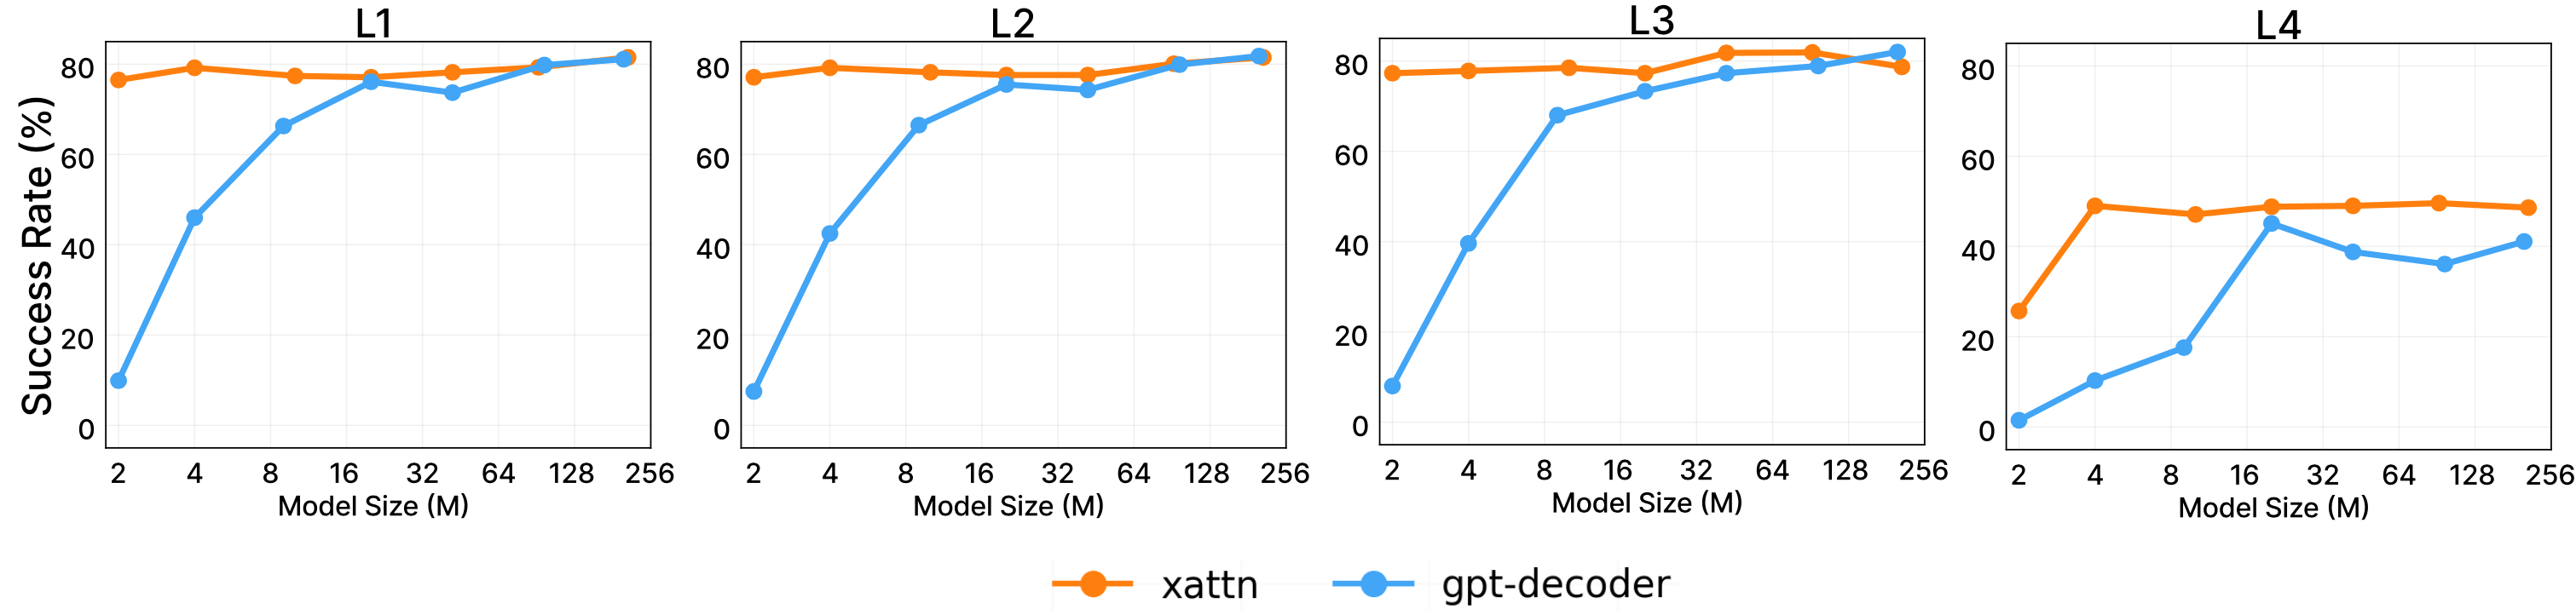
VIMA Architecture: Cross-Attention Transformer Explained
10 min read
Part 2/5
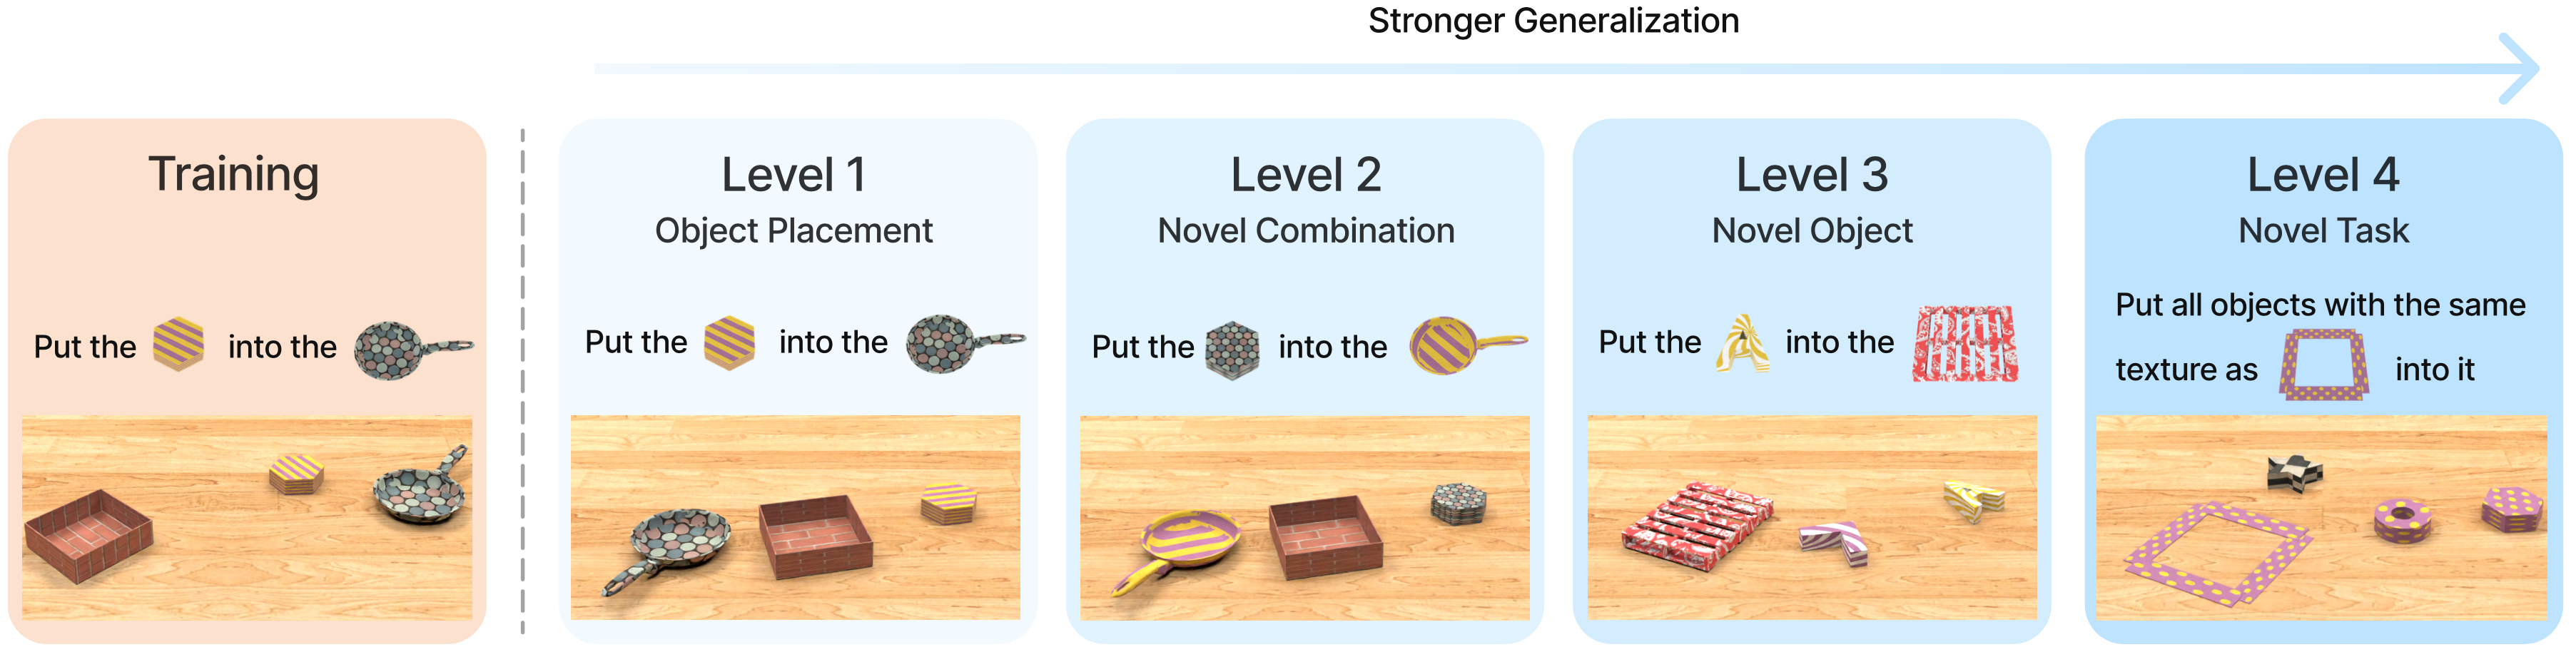
VimaBench: 17 Tasks and 4-Level Generalization Protocol
15 min read
Part 3/5
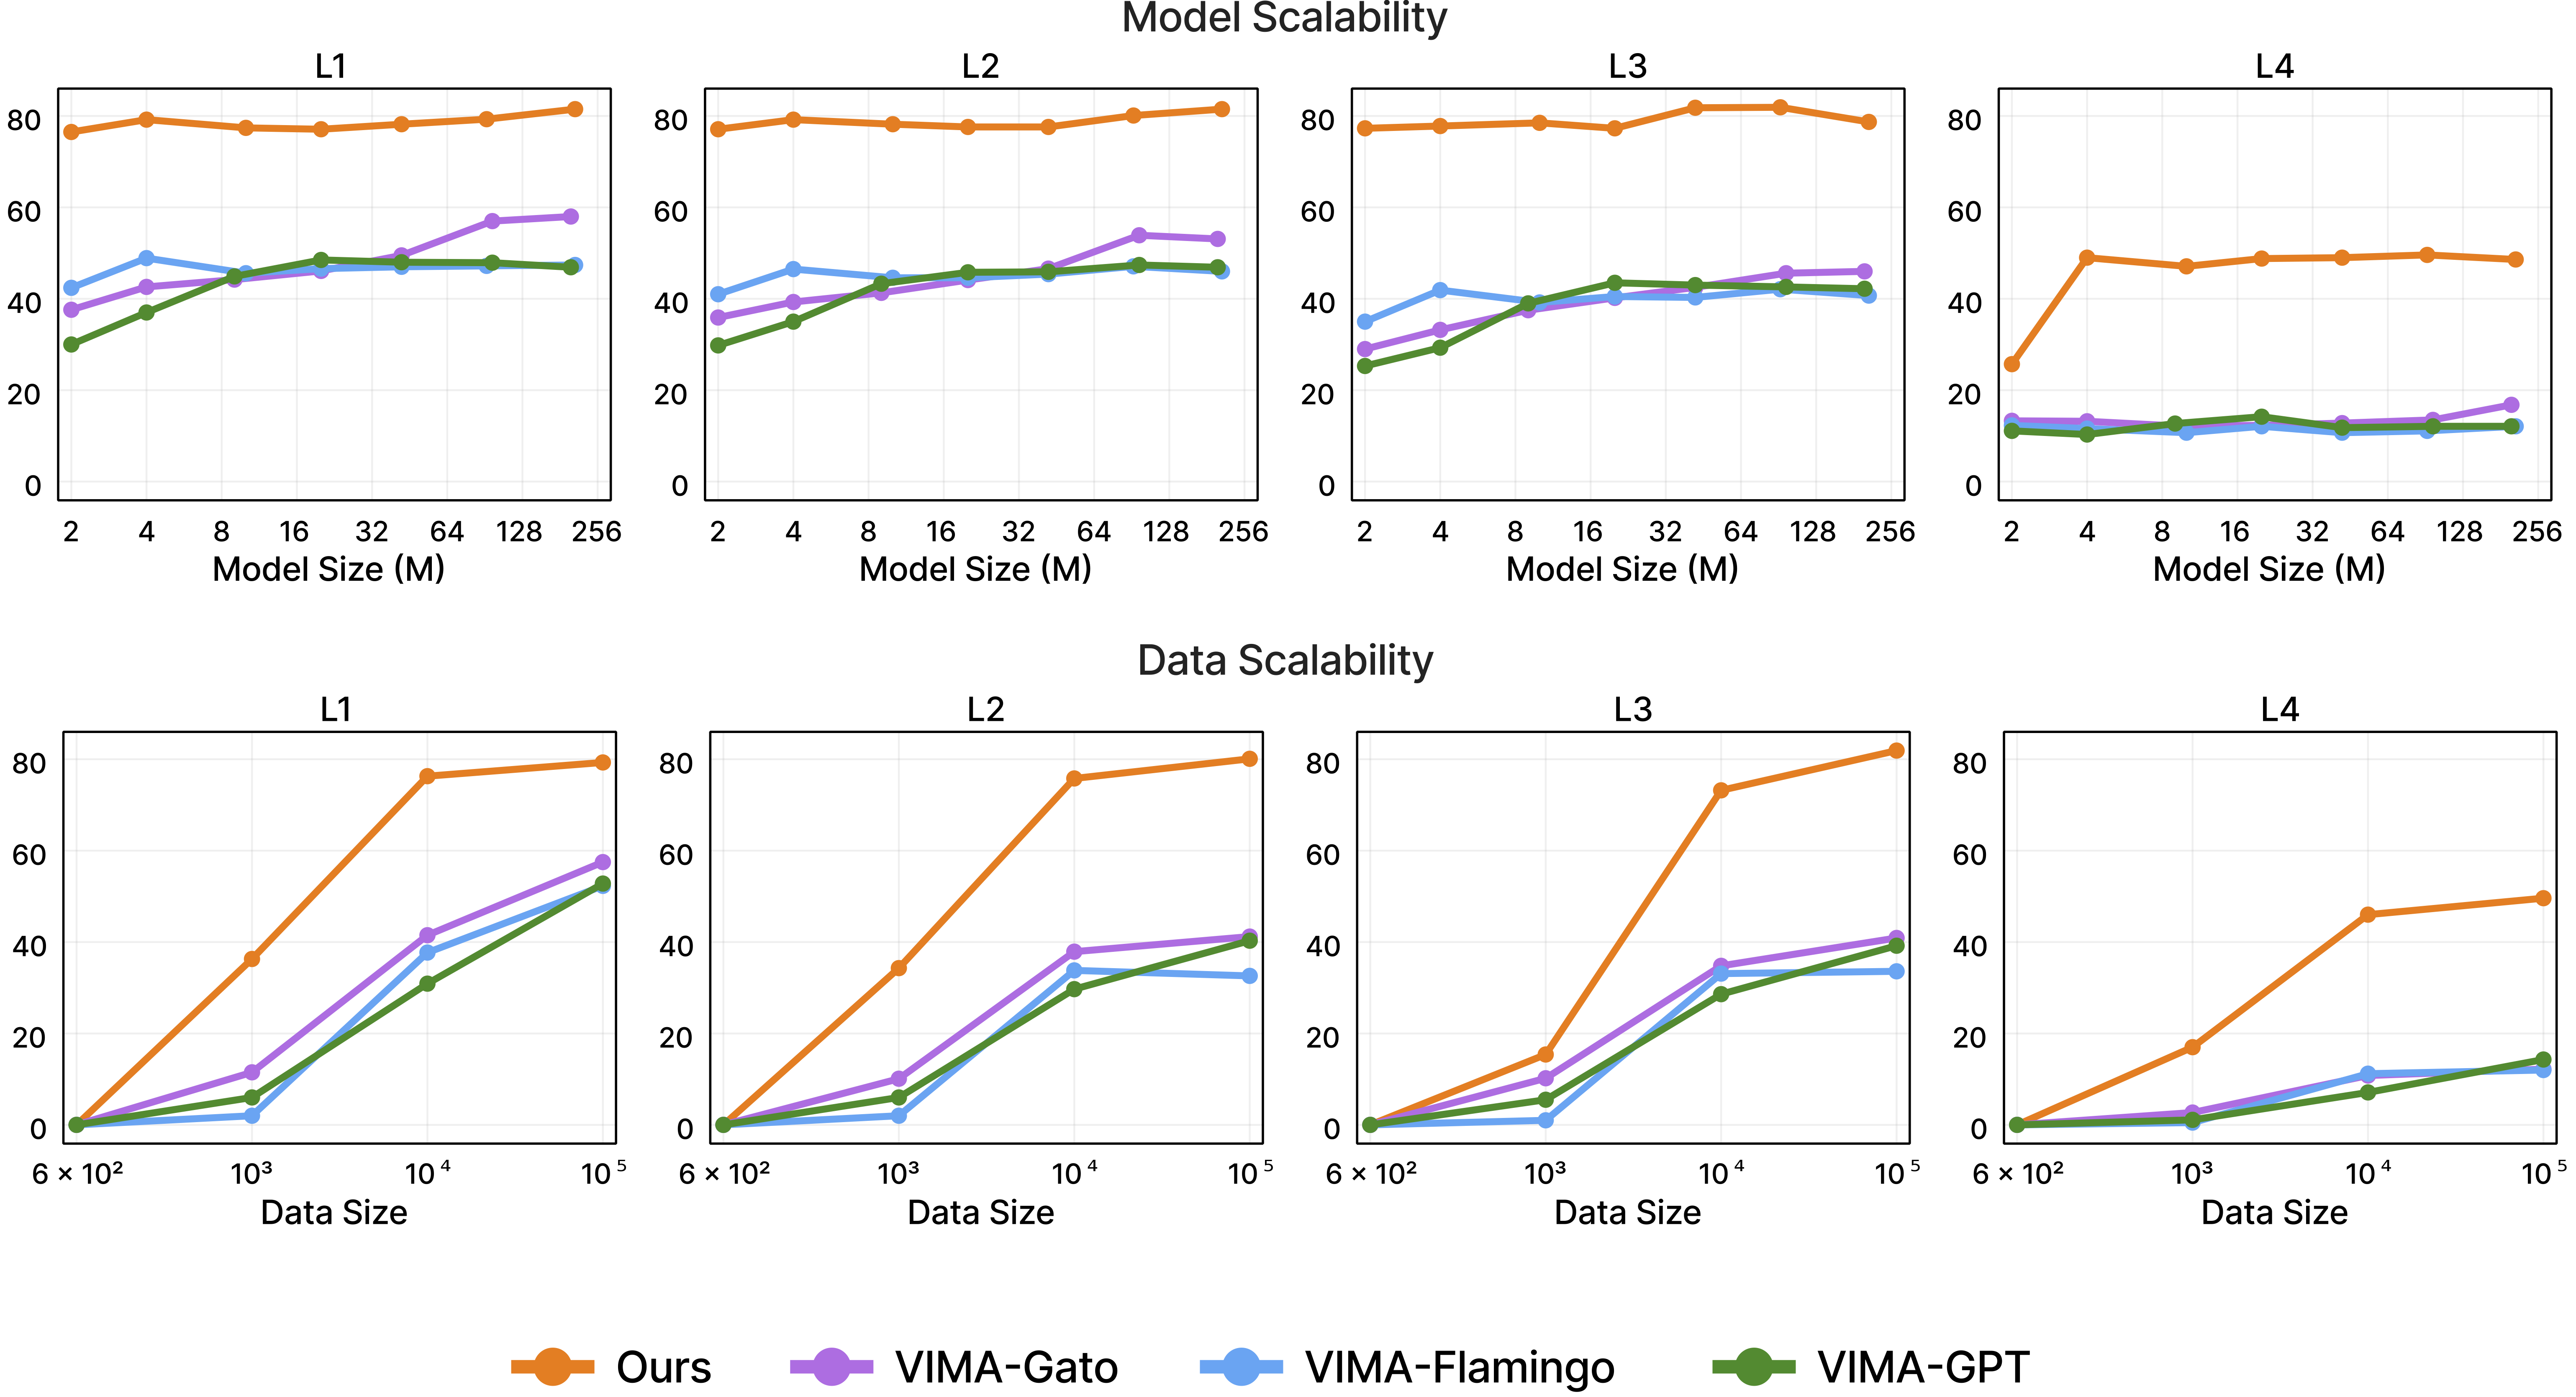
Object Tokenizer: From Raw Pixels to Object Tokens with Mask R-CNN + ViT
15 min read
Part 4/5
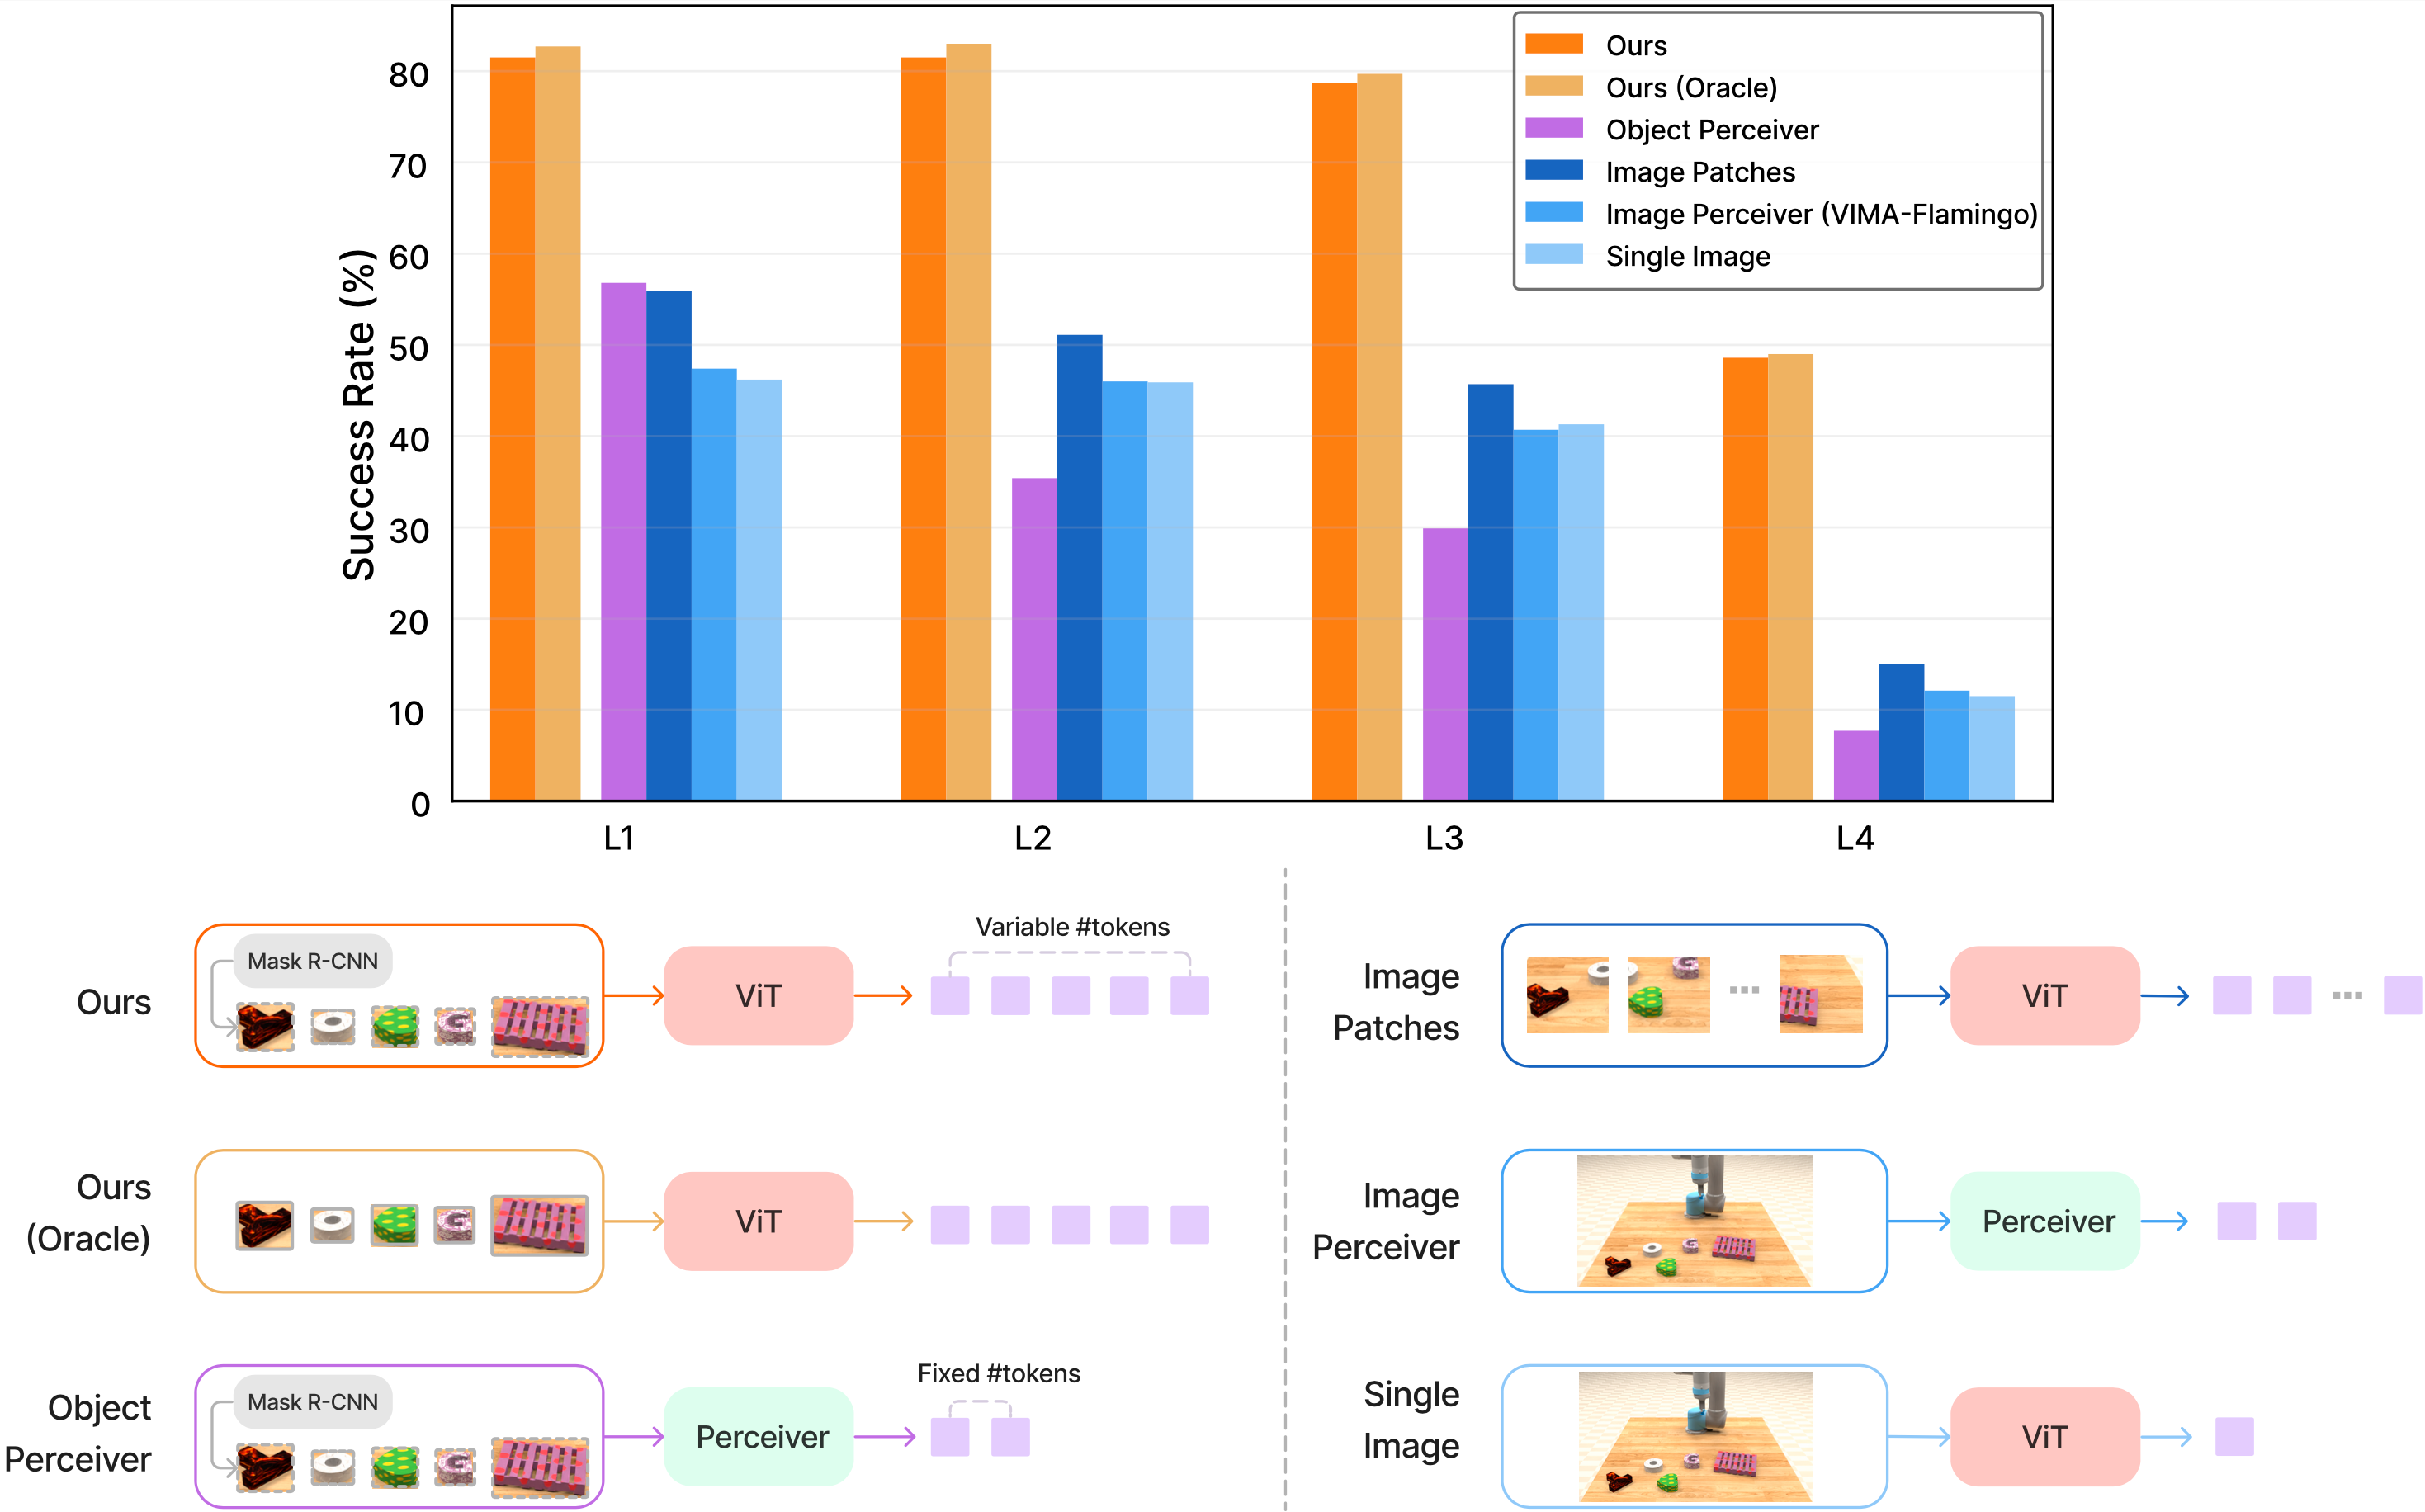
Dataset 650K: Collecting Large-Scale Multi-Task Manipulation Data for VIMA
12 min read
Part 5/5
Humanoid Adaptation: Extending VIMA to High-DoF Humanoid Robots
19 min read
Plotjuggler G1 Debug
· 5 parts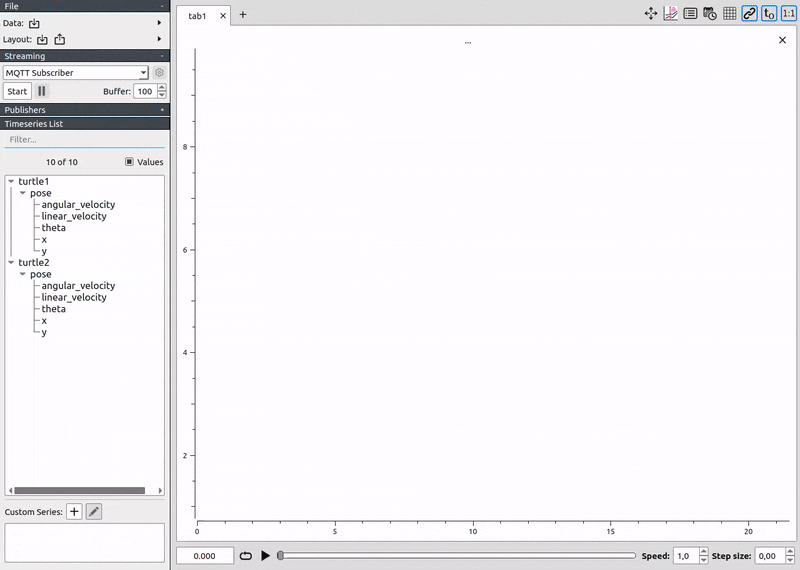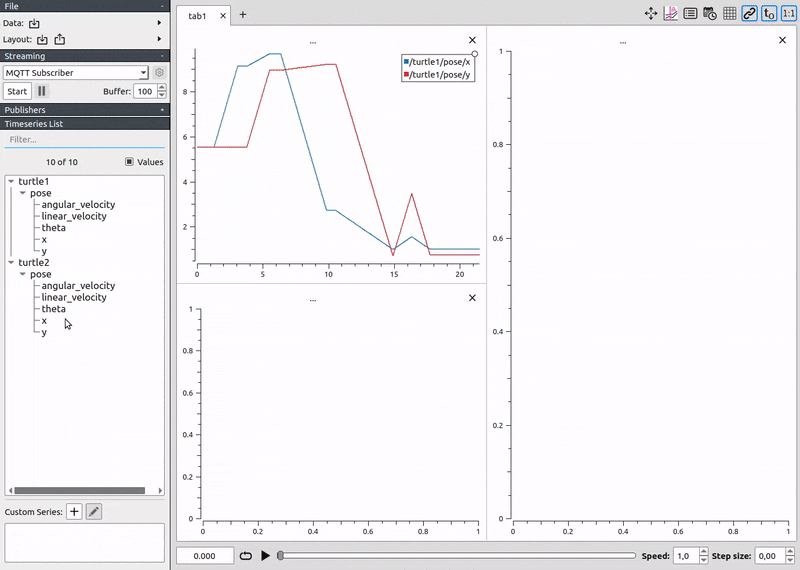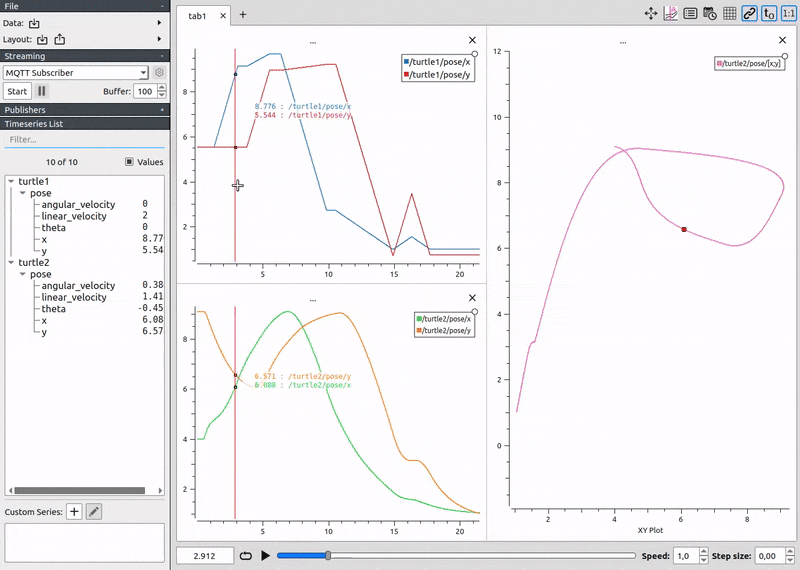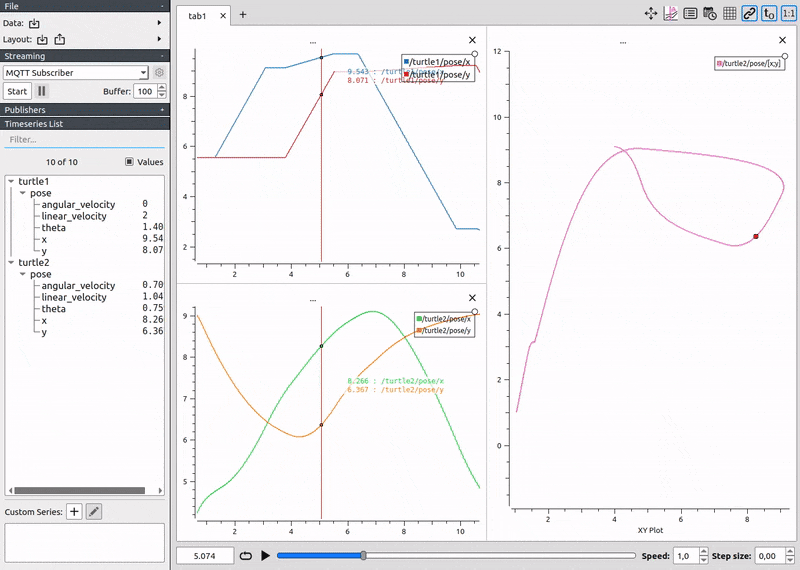
Part 1/5
PlotJuggler + G1: ROS2 Setup & Live Topic Streaming
13 min read
Part 2/5
Visualizing 23 G1 Joints: MCAP Bags & Panel Layouts
12 min read
Part 3/5
IMU Debug: Quaternion to Euler + FFT Vibration Analysis
16 min read
Part 4/5
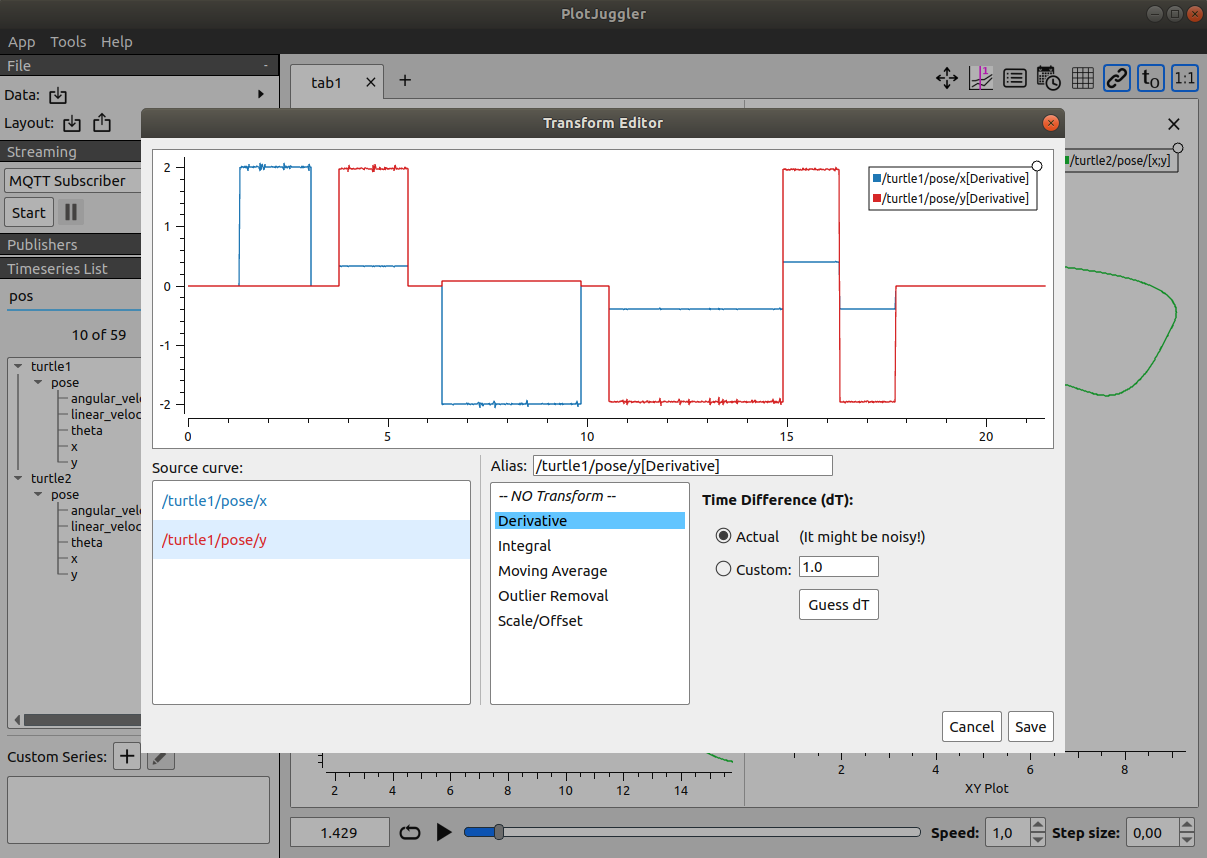
PlotJuggler Lua: Computing Power and Tracking Error for G1
9 min read
Part 5/5
ZMQ + VideoViewer: Sim-to-Real Debug for G1 with PlotJuggler
10 min read
Robot 3d Manipulation Vla
· 7 parts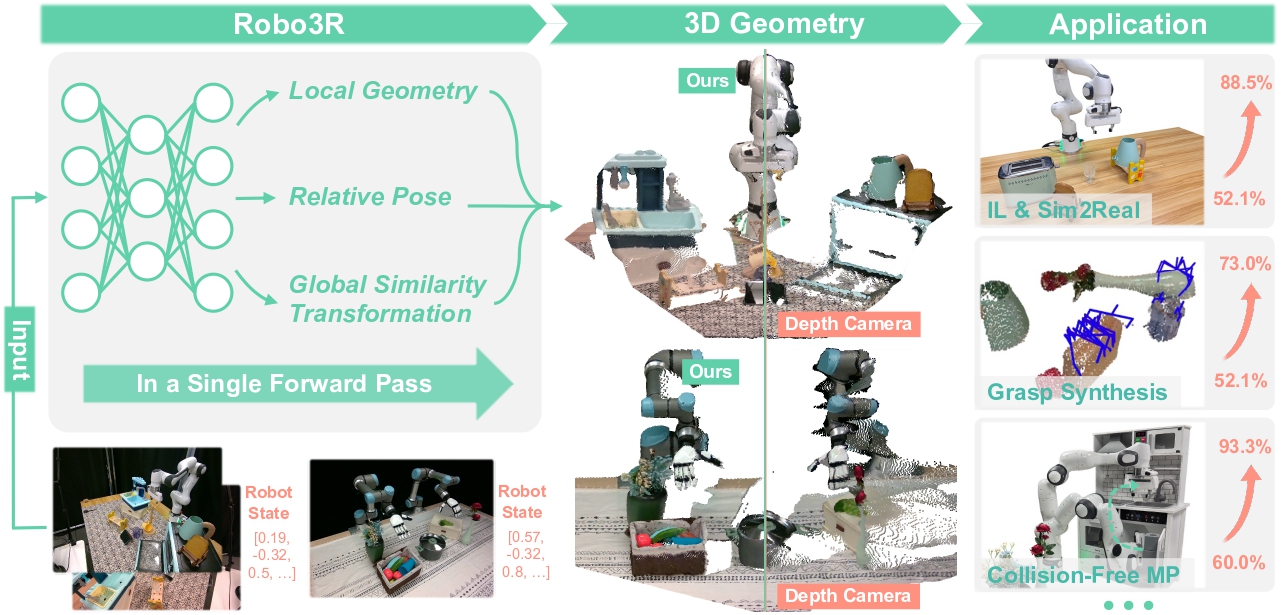
Part 1/7
Why 2D RGB VLA Is Not Enough for Manipulation
12 min read
Part 2/7
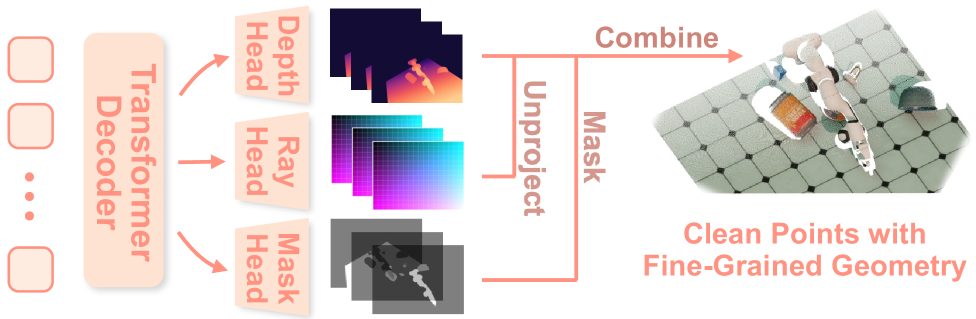
Robo3R: Feed-Forward 3D Reconstruction for Manipulation
11 min read
Part 3/7
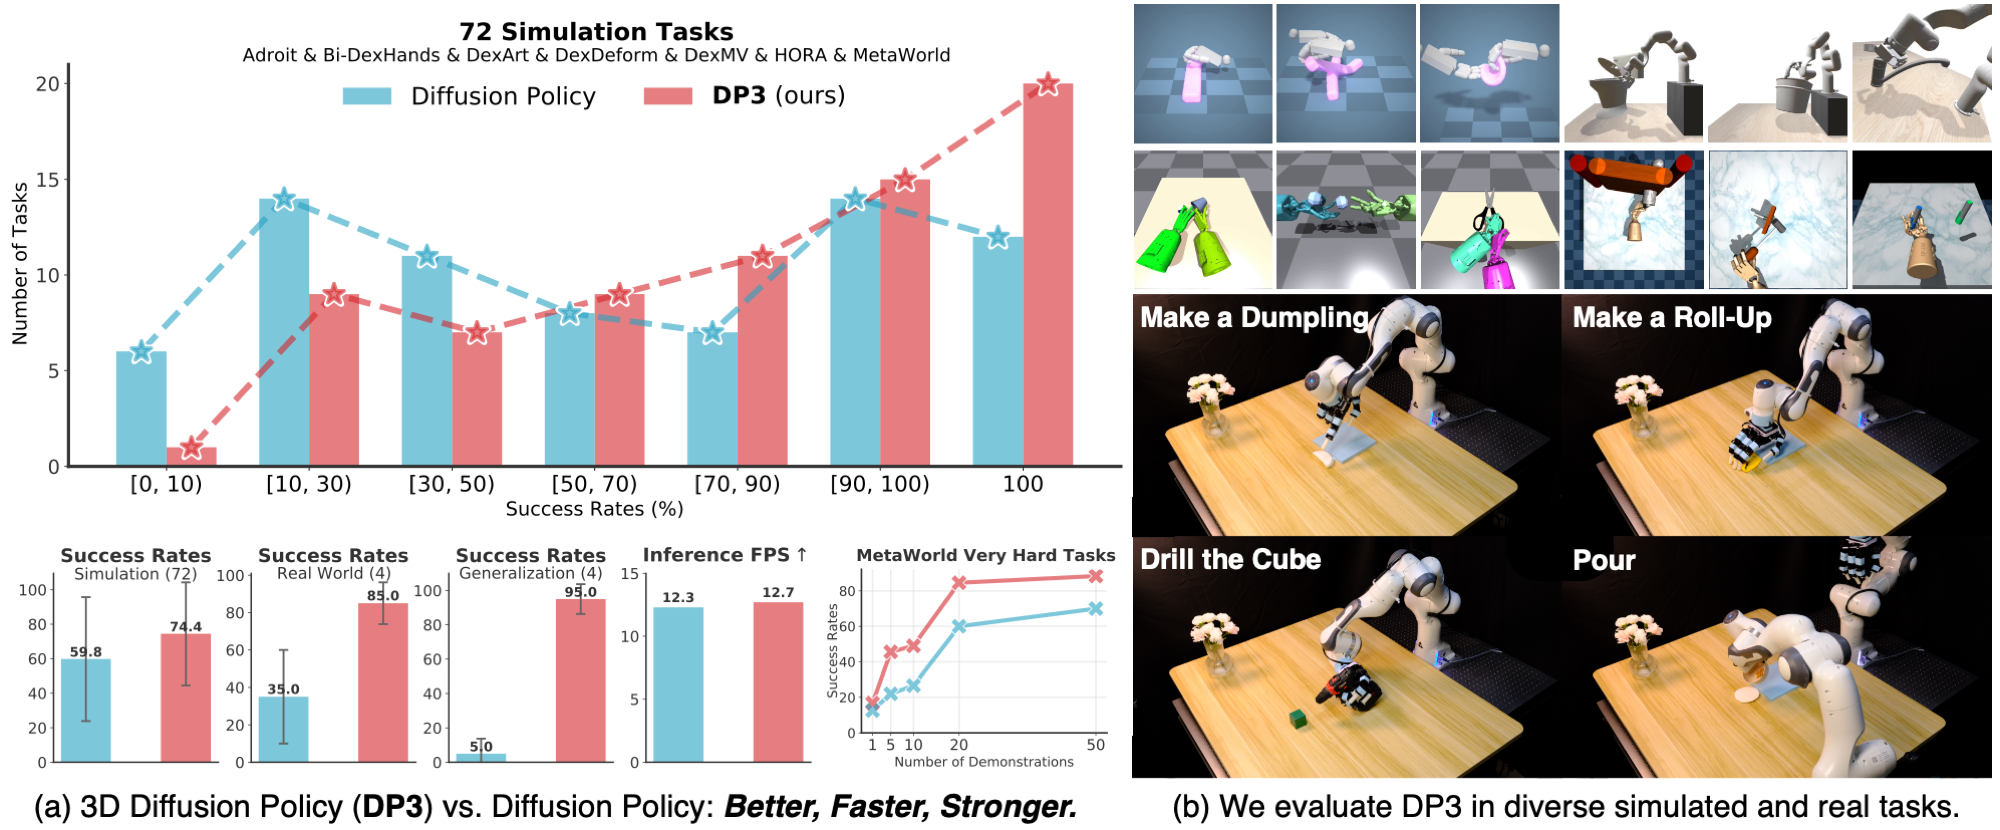
DP3: Point-Cloud 3D Diffusion Policy Hands-On
15 min read

Part 4/7
3D Perception for Whole-Body Humanoids: Beyond-FOV
7 min read

Part 5/7
WholeBodyVLA: Action-Free Video to Loco-Manipulation
6 min read
Part 6/7
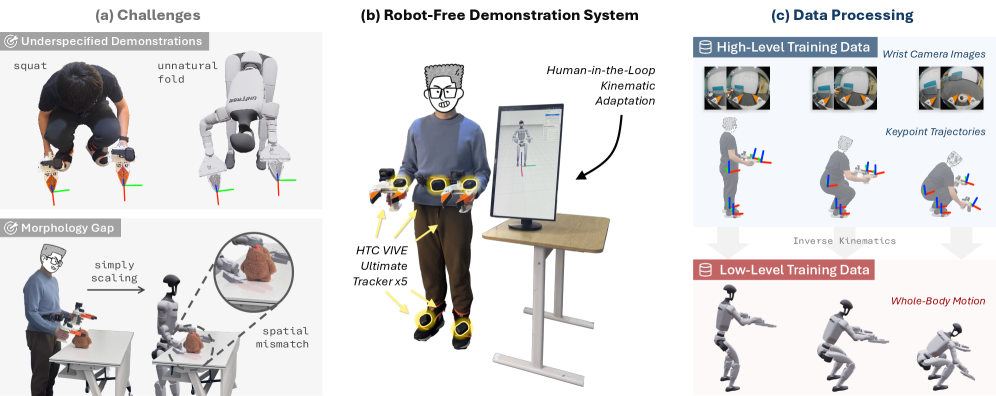
Data Collection: Teleop vs Robot-Free vs Egocentric Video
6 min read
Part 7/7
A 3D Manipulation Roadmap for the Unitree G1 Humanoid
6 min read
Robot Arm Classical Controller
· 15 parts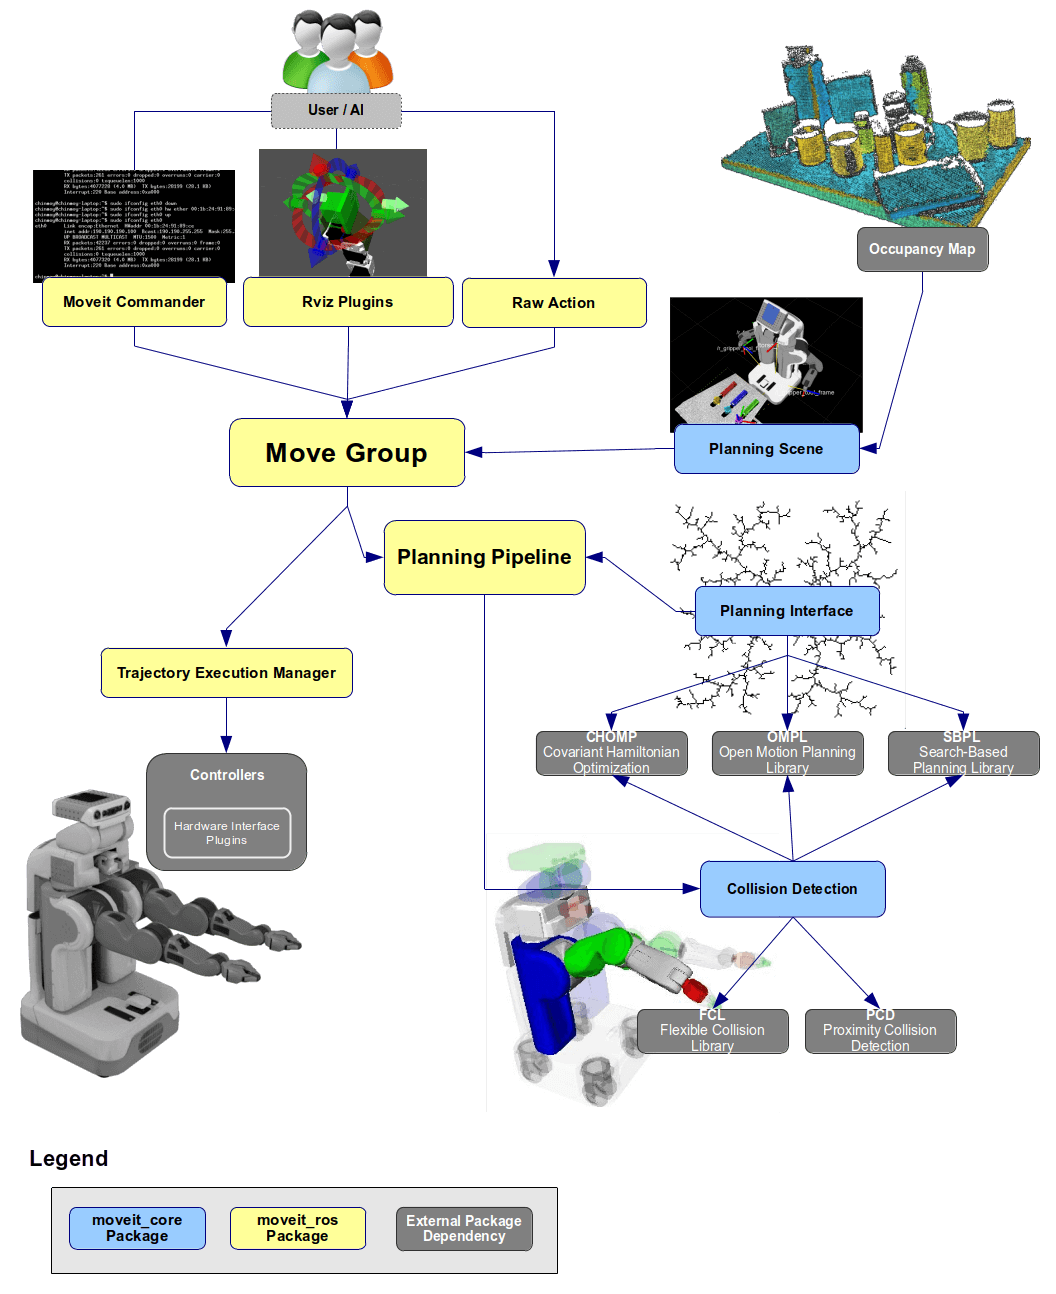
Part 1/15
Classical Robot Arm Control: The Complete Roadmap
16 min read
Manipulation
Part 2/15
Setting Up a C++ Robot Controller Project with CMake
14 min read

Part 3/15
Robot Arm Model: Joints, Links, URDF, DH and SE(3)
16 min read
Part 4/15
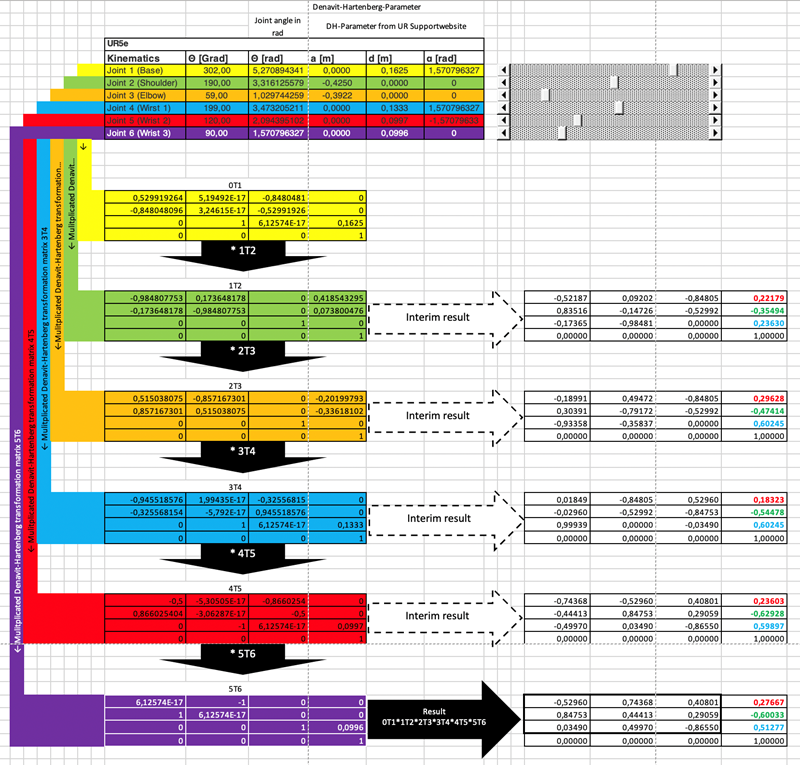
Forward Kinematics from Scratch: DH to SE(3) in C++
14 min read
Part 5/15
Inverse Kinematics for 6-DOF Arms: Analytical vs Numerical
14 min read
Part 6/15
Jacobian-Based Control and Singularity Avoidance
14 min read
Part 7/15
Robot Coordinate Frames: Base, Tool, User and TCP
11 min read
Part 8/15
How to Implement MoveJ for Robot Arms
16 min read
Part 9/15
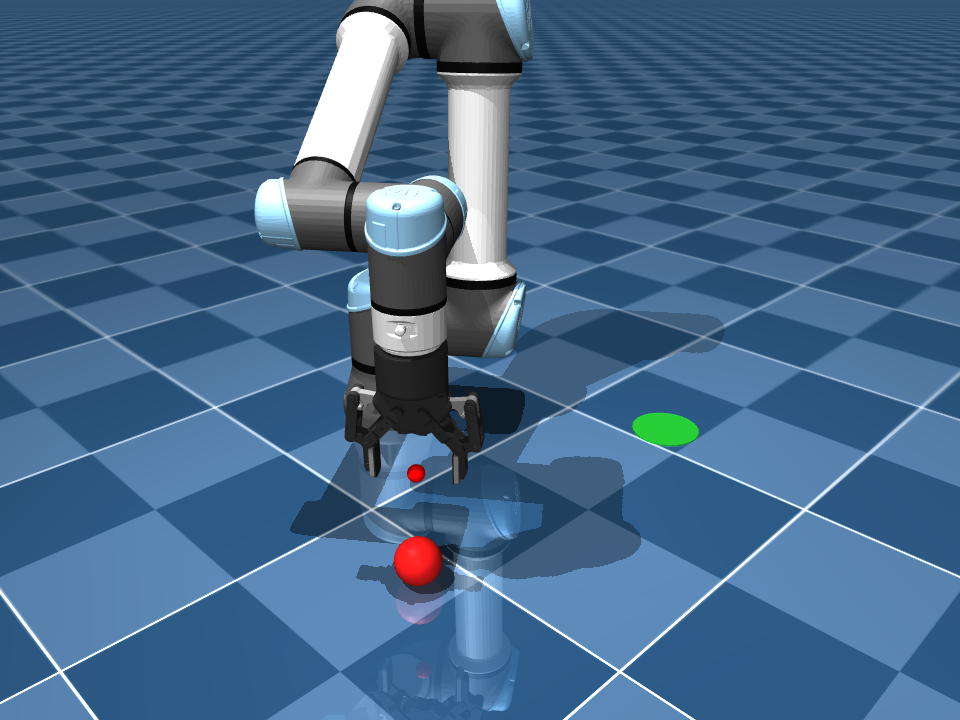
How to Implement MoveL: Cartesian Linear Motion with IK
13 min read
Part 10/15
MoveC and MoveP: Circular and Process Path Motion
16 min read
Part 11/15
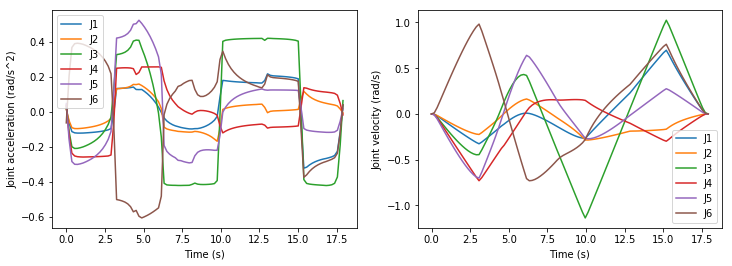
Trapezoidal vs S-Curve Trajectory Profiles
16 min read
Part 12/15
Waypoint Blending and Corner Smoothing for Robot Arms
18 min read
Part 13/15
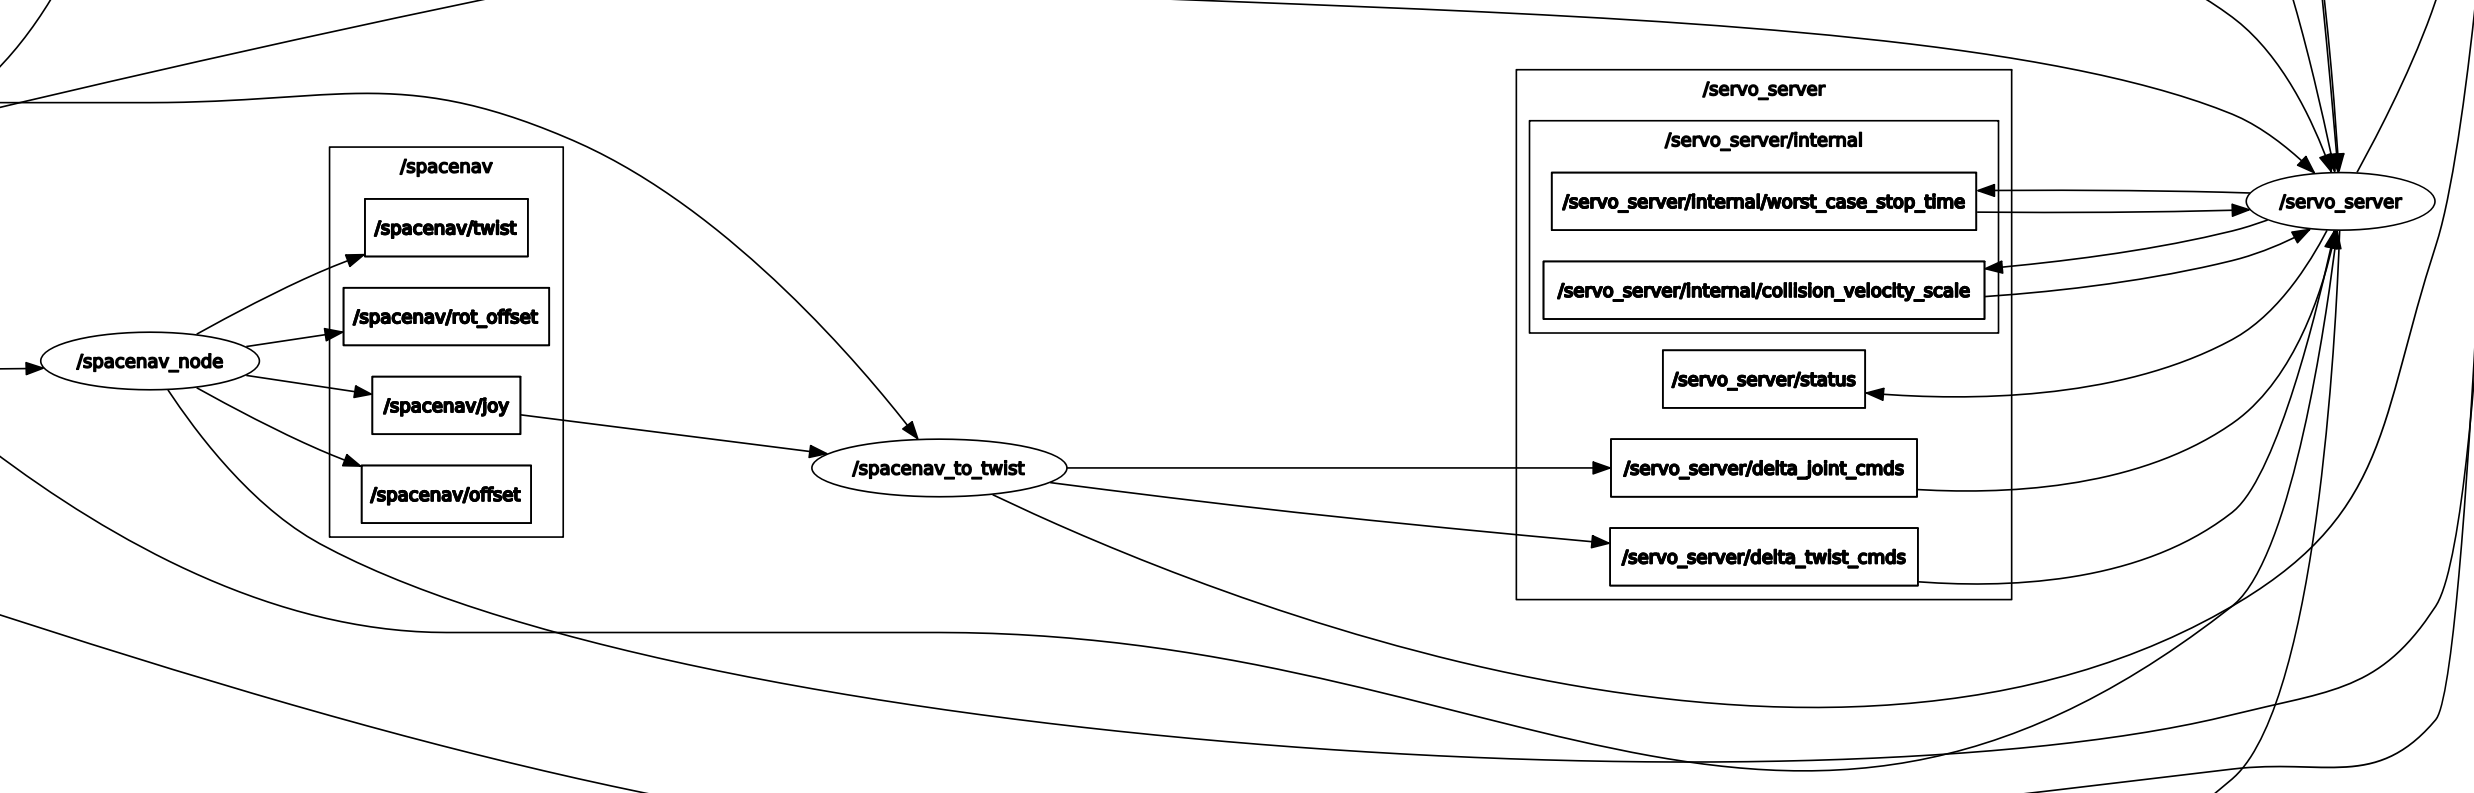
Robot Arm Jogging and Servoing with MoveIt Servo
15 min read
Part 14/15
Motion Planning with Collision Avoidance in MoveIt2
11 min read
Part 15/15
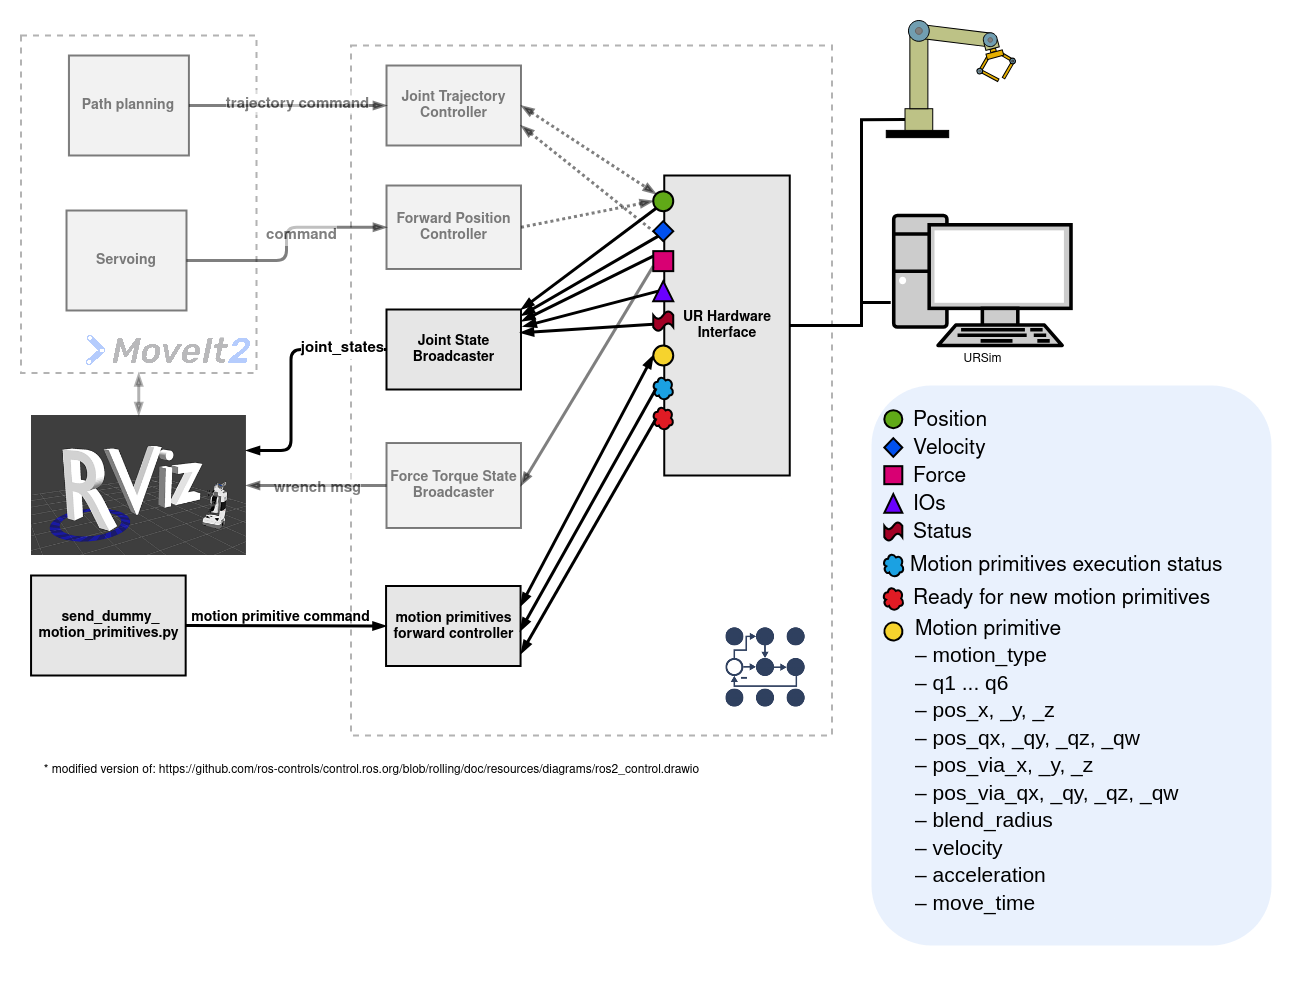
Executing Trajectories with ROS2 Control and UR RTDE
13 min read
Groot Sonic Humanoid Wbc
· 6 parts
Part 1/6
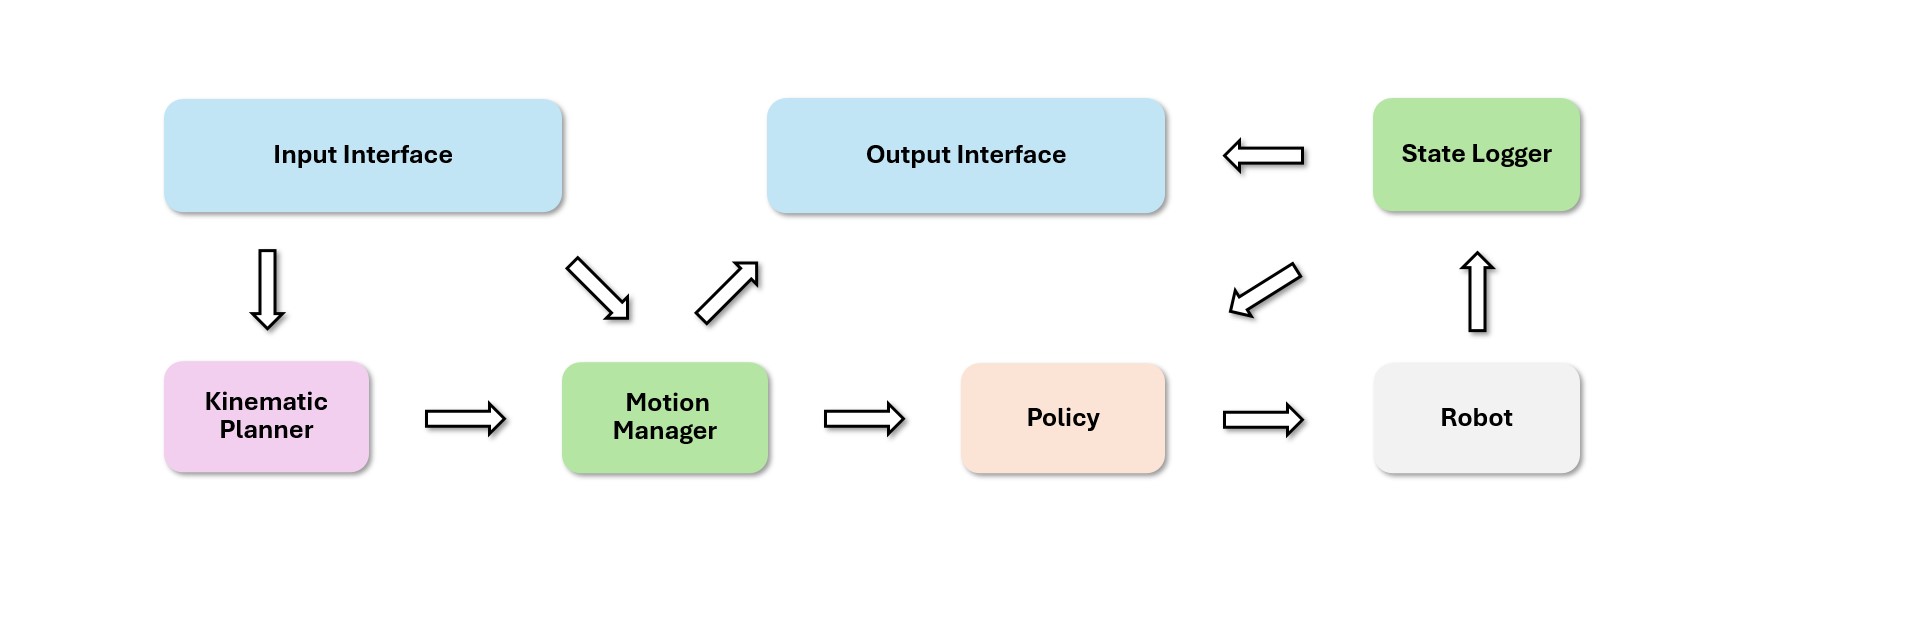
SONIC Architecture for Humanoid WBC
13 min read
Part 2/6
Run Sim and Evaluate SONIC Policies
13 min read
Part 3/6
BONES-SEED Data and SONIC Training
13 min read
Part 4/6
C++ Deployment: TensorRT, ZMQ, ONNX
16 min read
Part 5/6
PICO Teleop and LeRobot Data for VLA
15 min read
Part 6/6
MotionBricks Real-Time Motion Tokens
14 min read
G1 Mujoco Telemetry Control
· 6 parts
Part 1/6
Bring Up G1 MuJoCo with Low-Level DDS
13 min read
Part 2/6
Convert LAFAN1 G1 Motions to Foxglove MCAP
13 min read
Part 3/6
Debug G1 MPC/WBID with PlotJuggler
16 min read
Part 4/6
From Posture PD to Contact-Aware WBID
15 min read
Part 5/6
G1 Upper Body: IK, VR and MuJoCo
14 min read
Part 6/6
A Sim2Real Checklist for G1 Controllers
15 min read
Humanoid Data War 2026
· 7 partsResearch
Part 1/7
The Data War: Who Owns Humanoid Robot Data in 2026?
10 min read
Humanoid
Part 2/7
Teleoperation: Real-World Robot Data Collection
15 min read
Humanoid
Part 3/7
Human Video Mining: Pre-training Robots from Human Video
16 min read
Humanoid
Part 4/7
Synthetic Data Pipelines: From Sim to Real
16 min read
Part 5/7
VLA Data Scaling Laws for Robot Learning
18 min read
Humanoid
Part 6/7
Data Strategy: What Should Small Teams Collect?
18 min read
Humanoid
Part 7/7
Open vs Closed: Licenses, Data Moats, and What's Next
16 min read
VLA & LeRobot Mastery
· 17 parts
Part 1/17
LeRobot Framework Deep Dive: Architecture & API Guide
9 min read
Part 2/17
Data Collection via Teleoperation in Simulation
10 min read

Part 3/17
Training Single-Arm Policies: ACT & Diffusion Policy
9 min read
Part 4/17
Multi-Object Manipulation: Sorting, Stacking & Rearranging
8 min read
Whole-body VLA
Part 5/17
Long-Horizon Tasks: Chaining Actions for Multi-Step Manipulation
8 min read
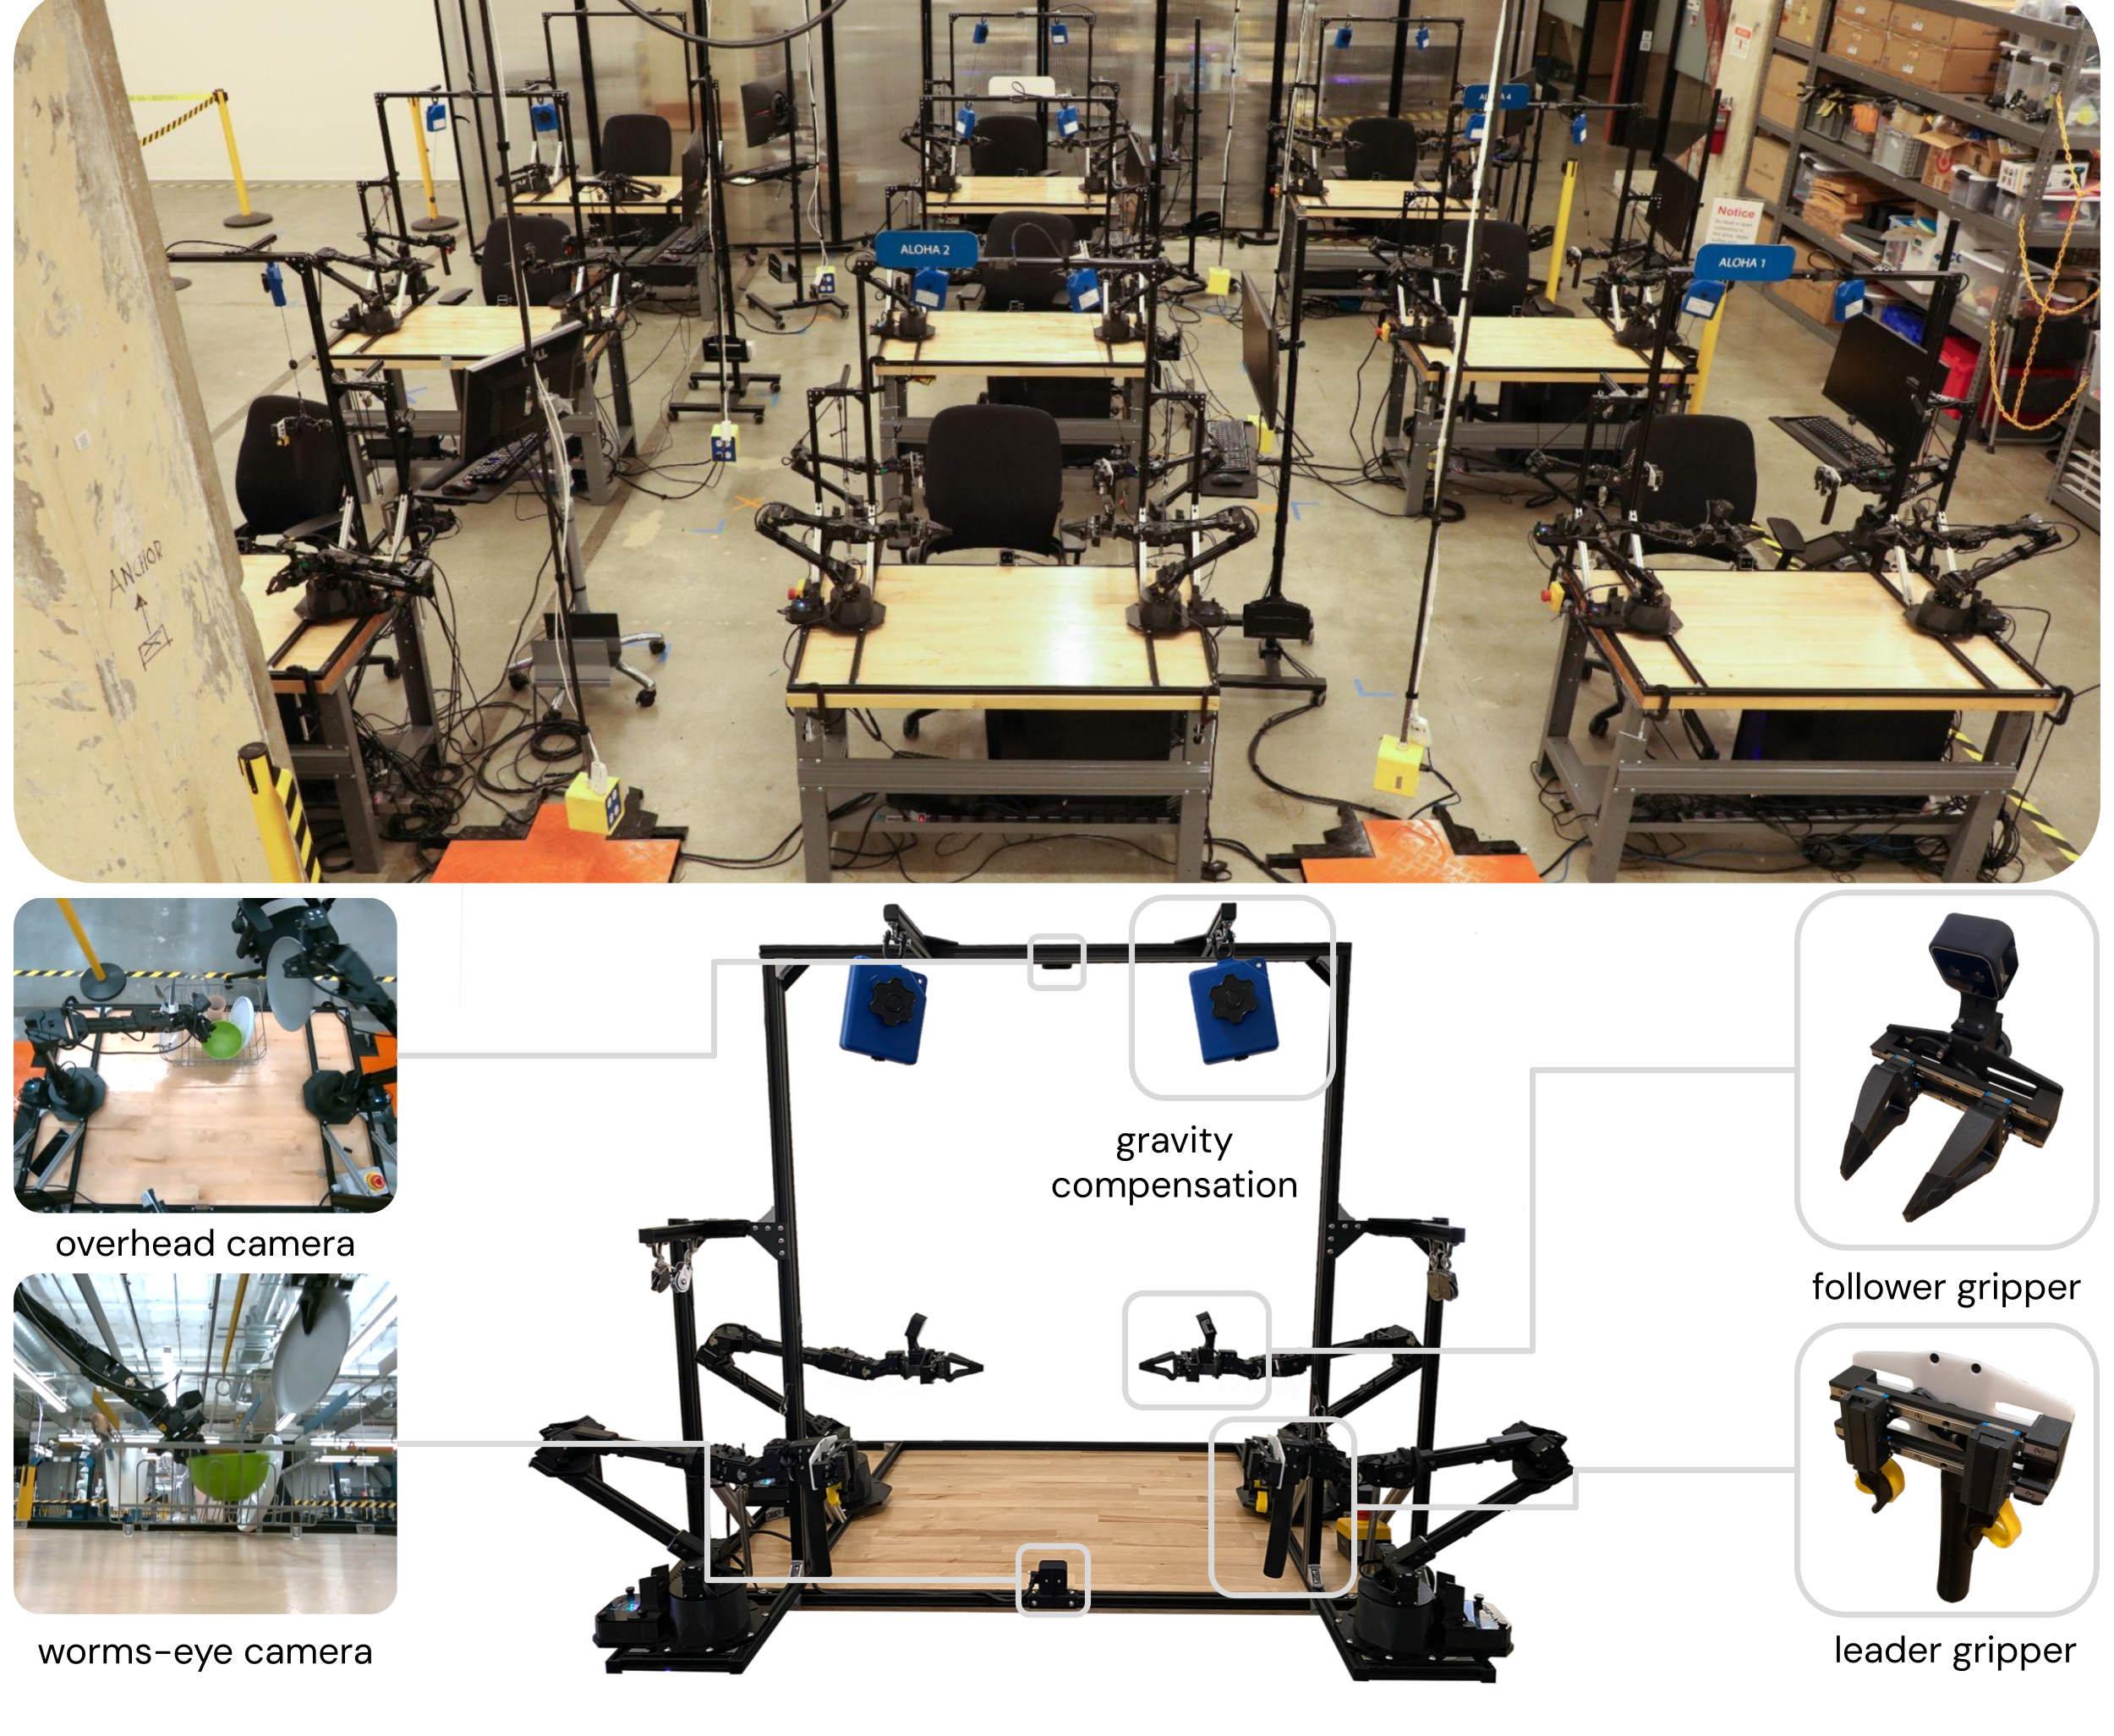
Part 6/17
Dual-Arm Robot: Setup & Calibration with LeRobot
8 min read
Part 7/17
Bimanual Tasks: Folding, Pouring & Assembly with Dual Arms
9 min read
Part 8/17
Mobile Manipulation: Mobile Base + Arms Integration
7 min read
Whole-body VLA
Part 9/17
Humanoid Manipulation: Whole-body Control with LeRobot
7 min read
Part 10/17
Sim-to-Real Transfer: Deploying VLA Policies to Real Robots
9 min read
Part 11/17
LeRobot v0.5: What's New
10 min read
Part 12/17
SmolVLA: Train a 450M VLA on Consumer GPU
10 min read

Part 13/17
Pi0-FAST: 5x Faster Autoregressive VLA
12 min read

Part 14/17
HIL-SERL: Real Robot RL with LeRobot
16 min read
Part 15/17
PEFT/LoRA Fine-tuning & VLA Deployment
11 min read
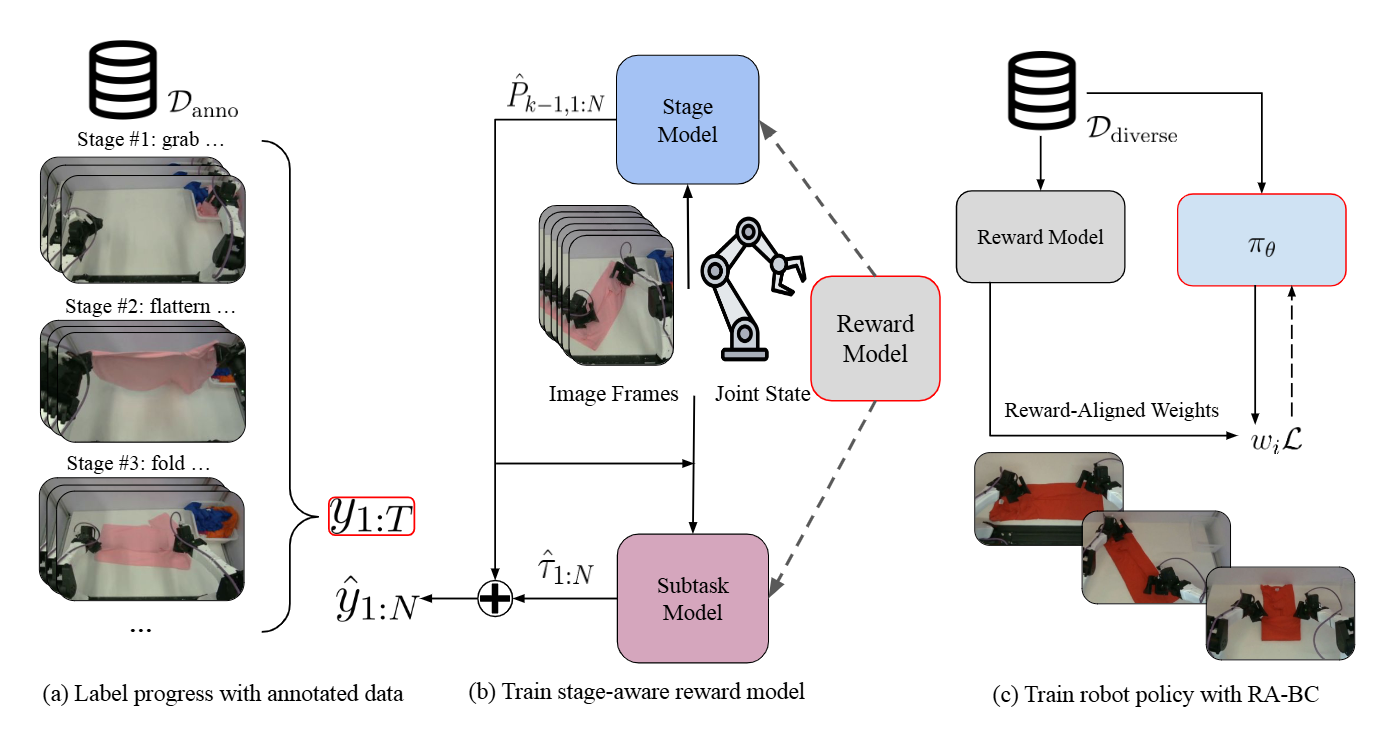
Part 16/17
SARM in LeRobot: Reward Models for VLA
15 min read

Part 16/17
LeRobot v0.5: Pi0-FAST + G1 Whole-Body Control
11 min read
Humanoid Wbvla 2026 Lab
· 6 partsPart 1/6
OpenWBT: G1 Teleop in MuJoCo/Isaac
13 min read
Part 2/6
TWIST2: PICO Teleop and G1 Sim2Real
16 min read
Part 3/6
EgoHumanoid: Human Demos to G1 VLA
16 min read
Part 4/6
VIRAL: RGB Sim2Real for G1 Loco-Manip
16 min read
Part 5/6
FRoM-W1: Text to Motion to G1 Policy
16 min read
Part 6/6
CLONE: MoE Teleop and Stack Choice
18 min read
Wholebodyvla Data Wbc
· 7 parts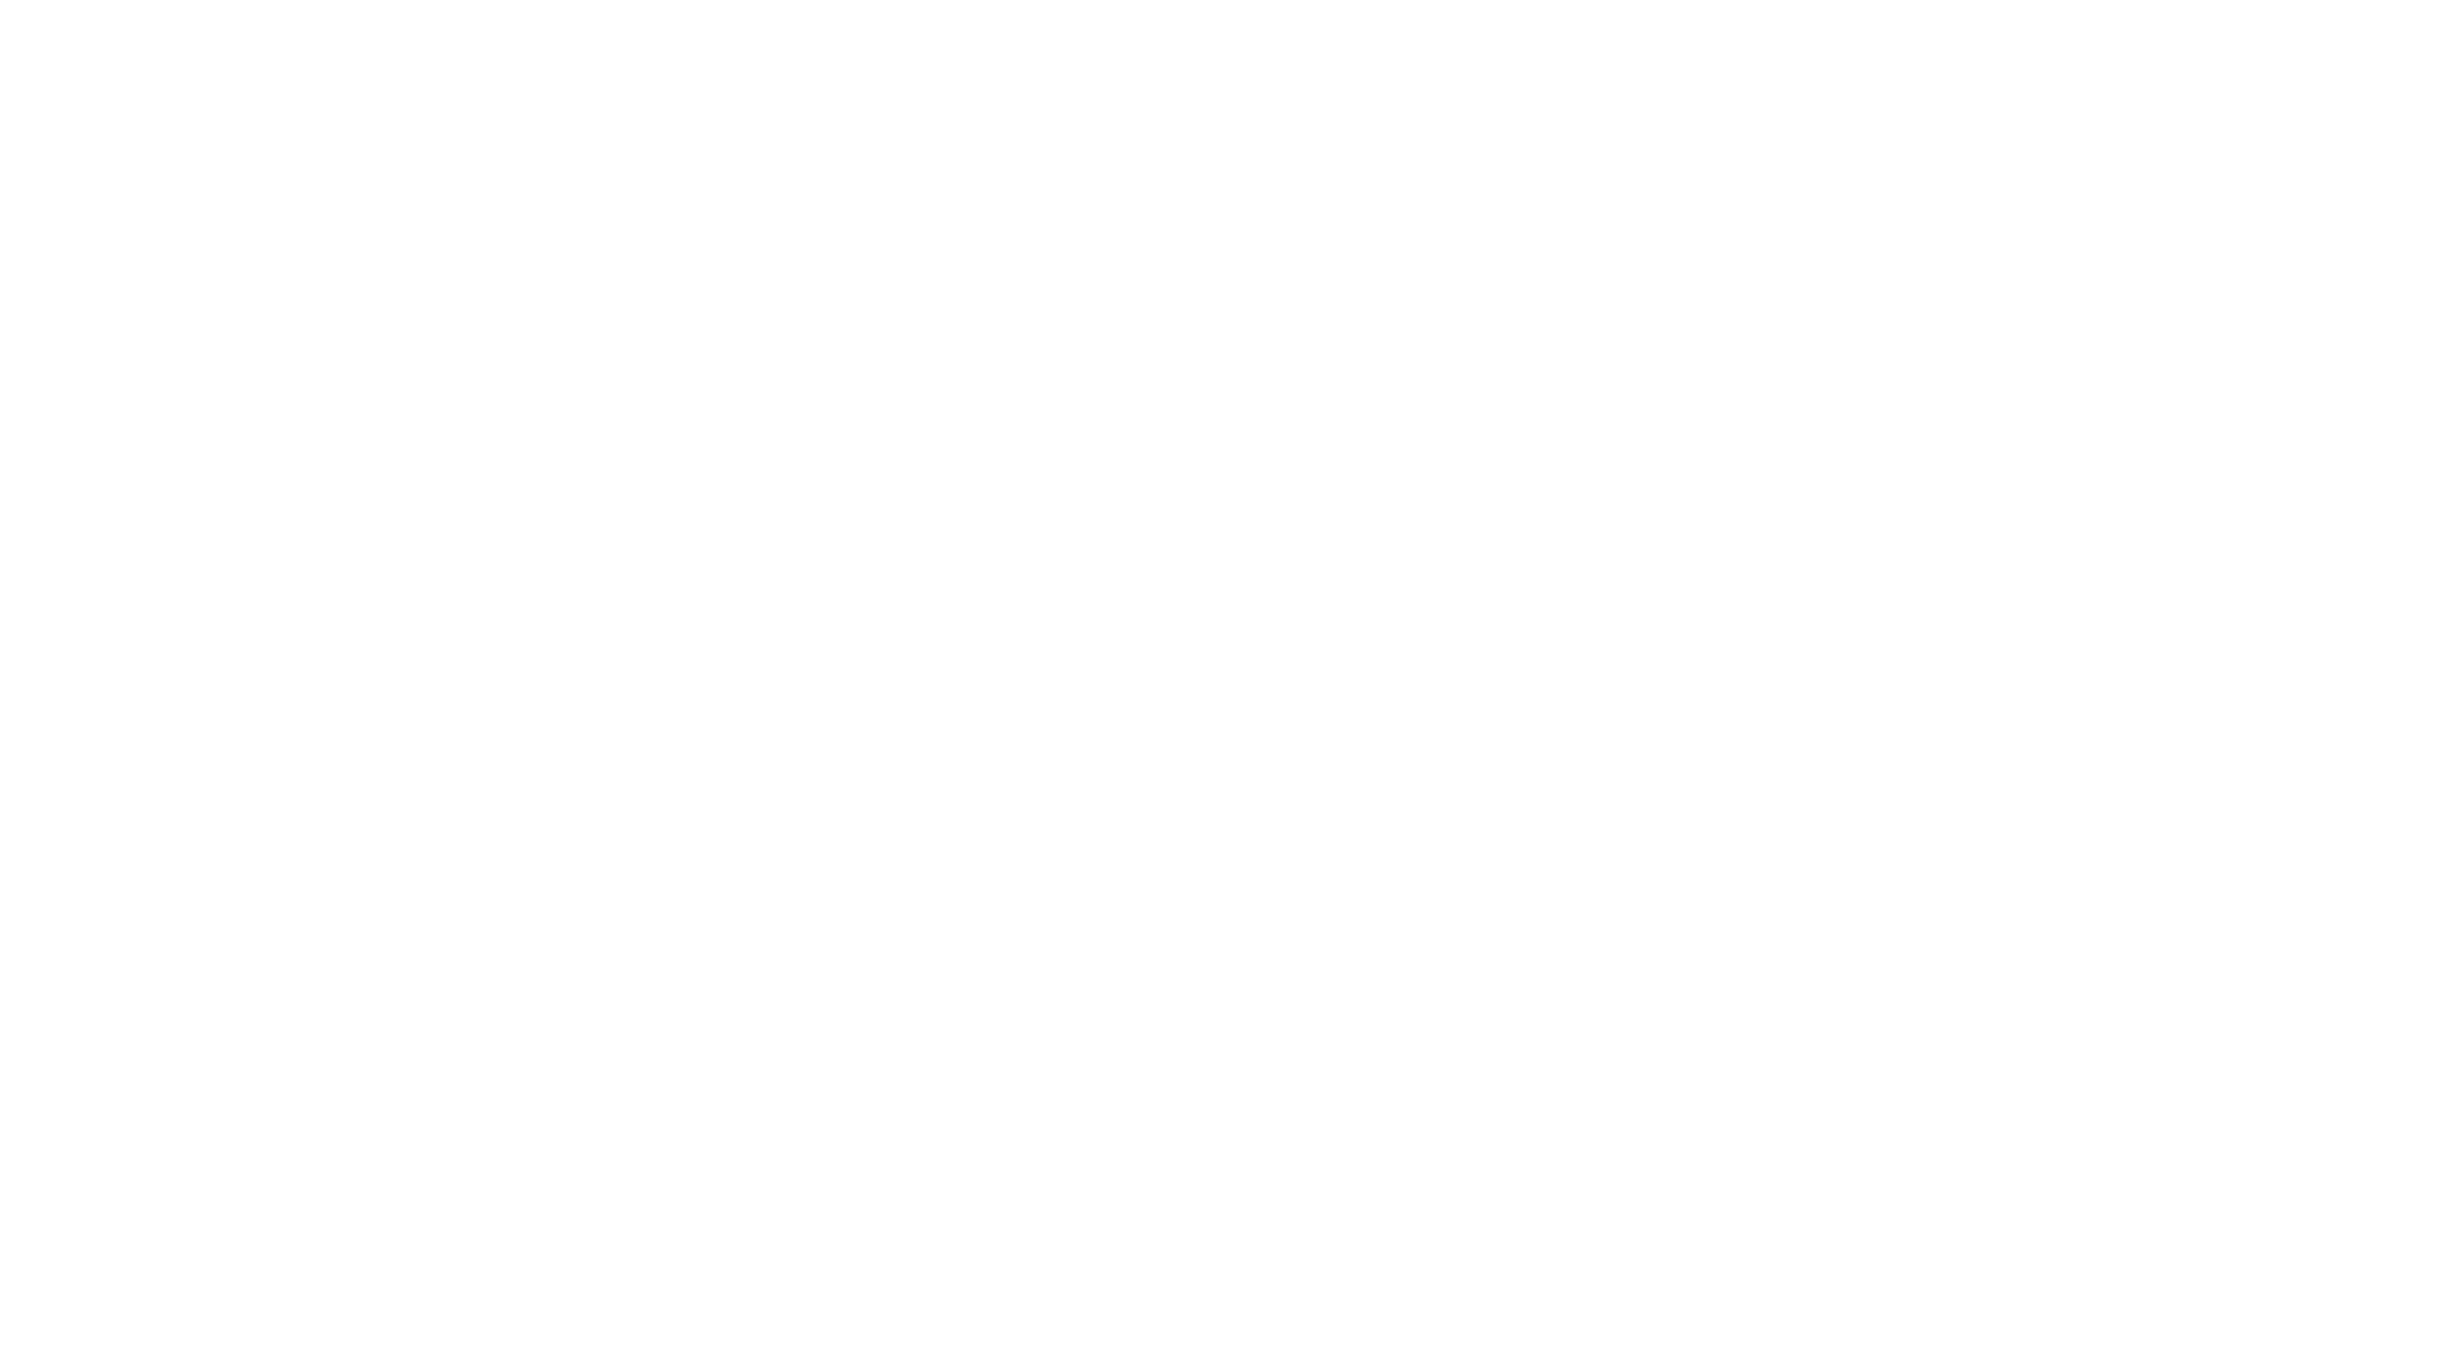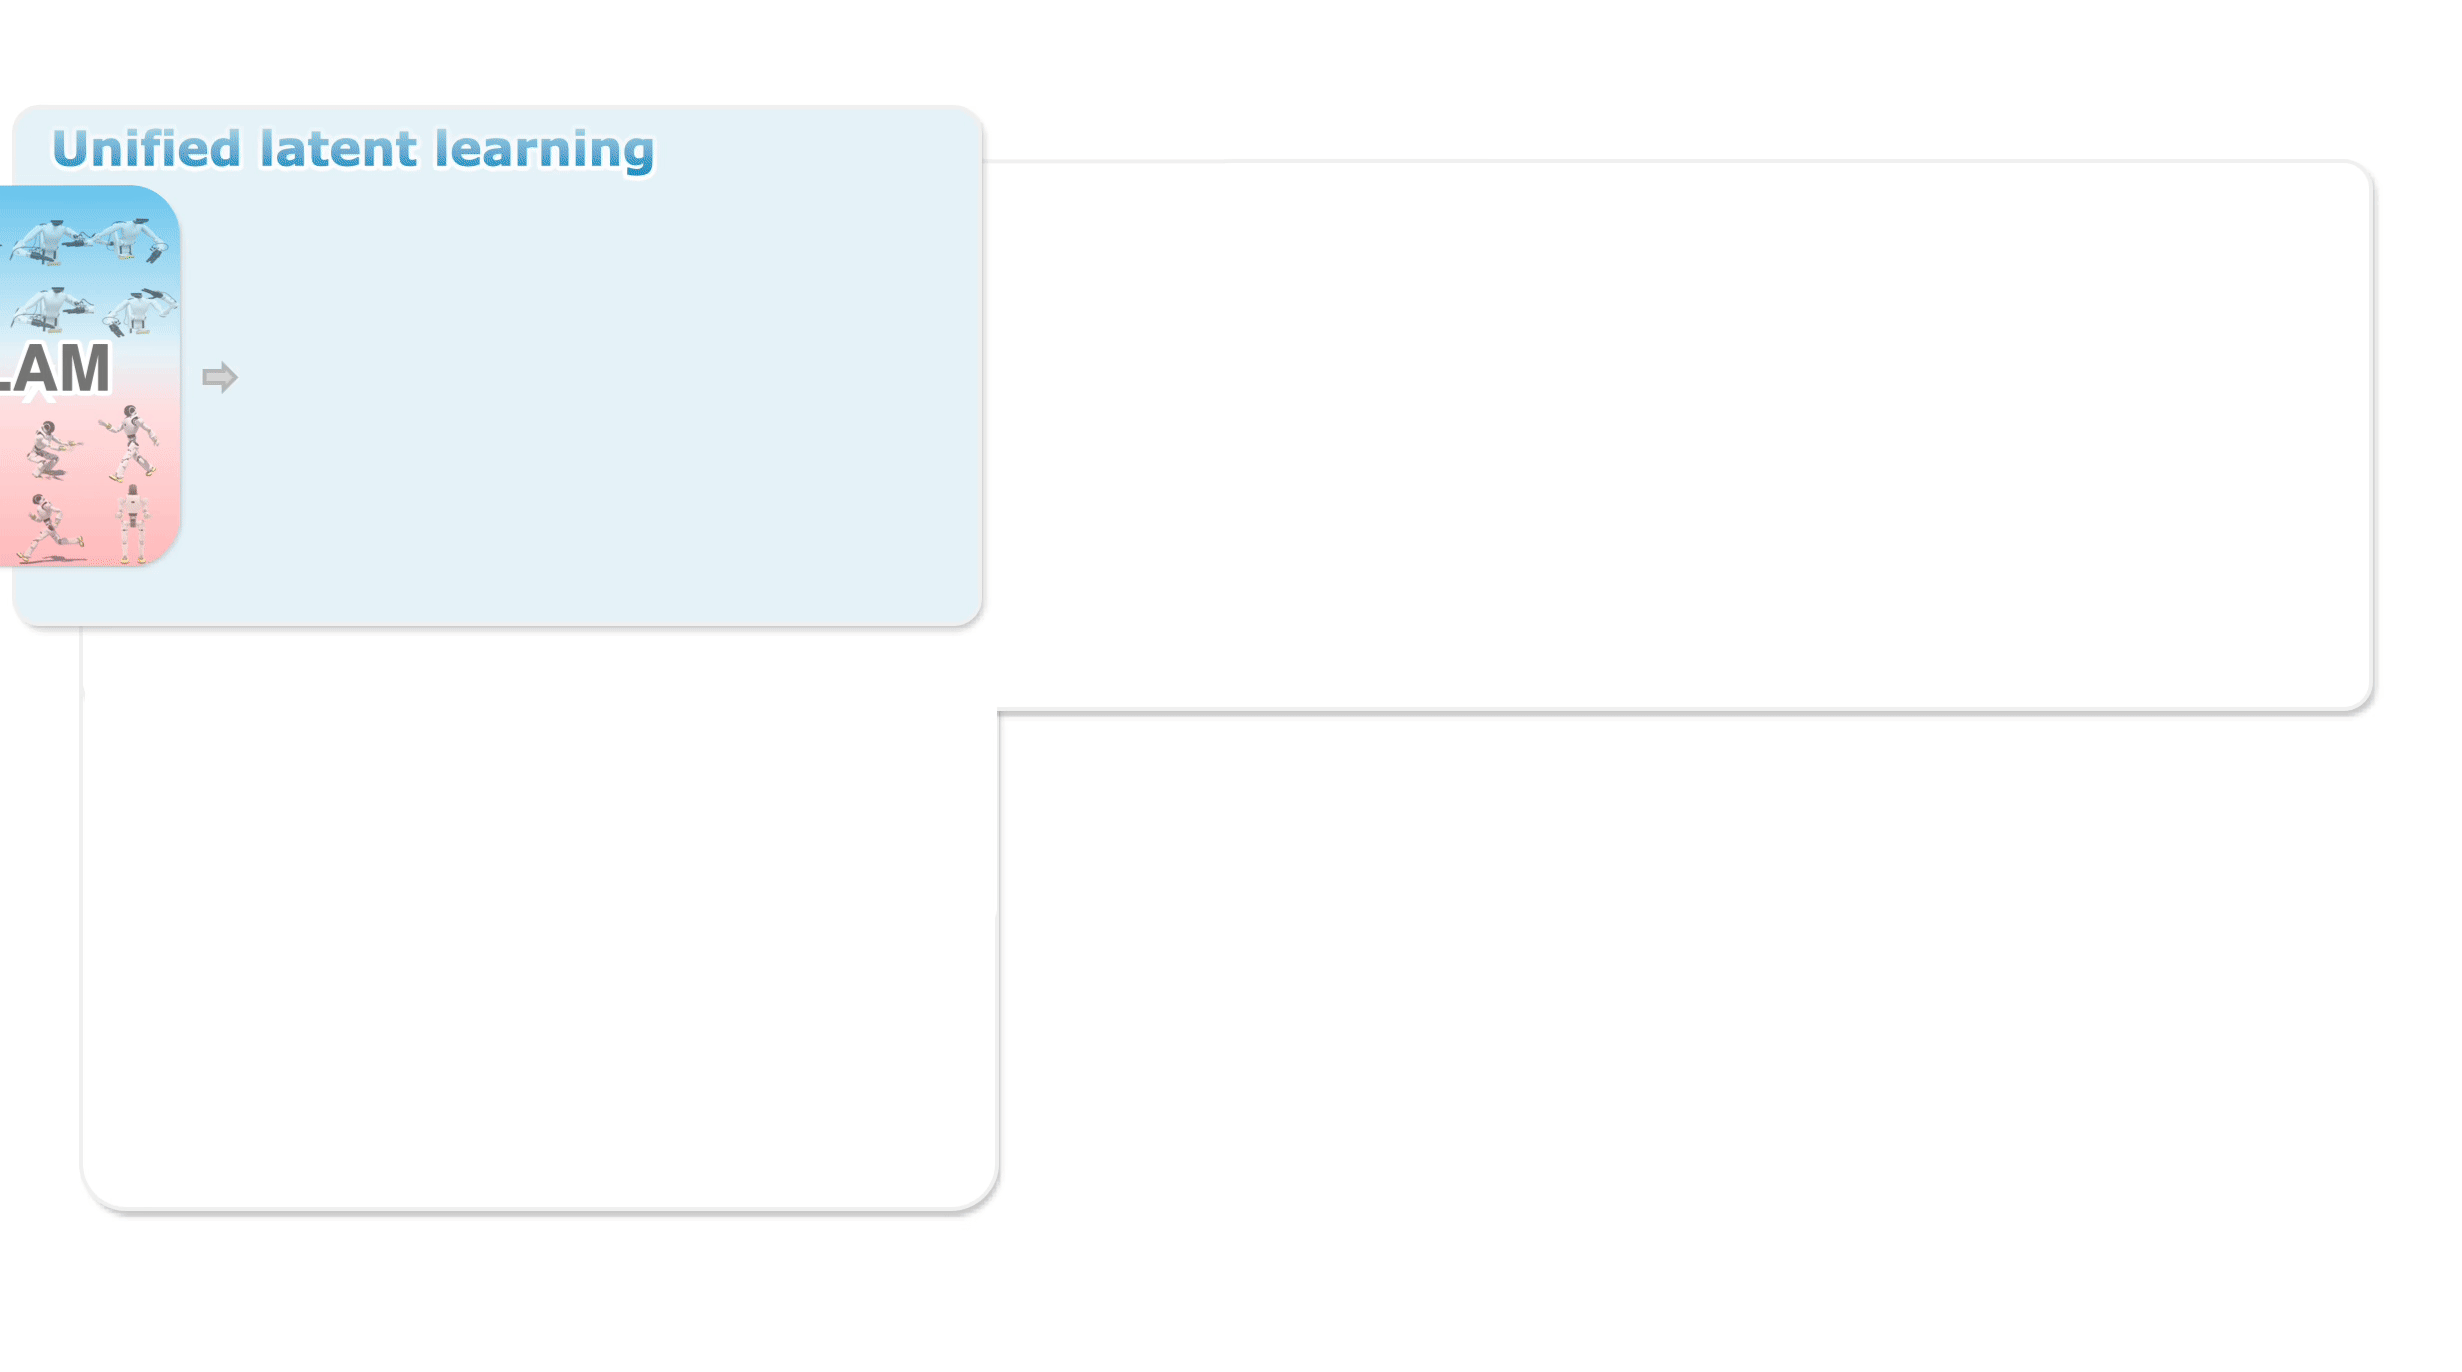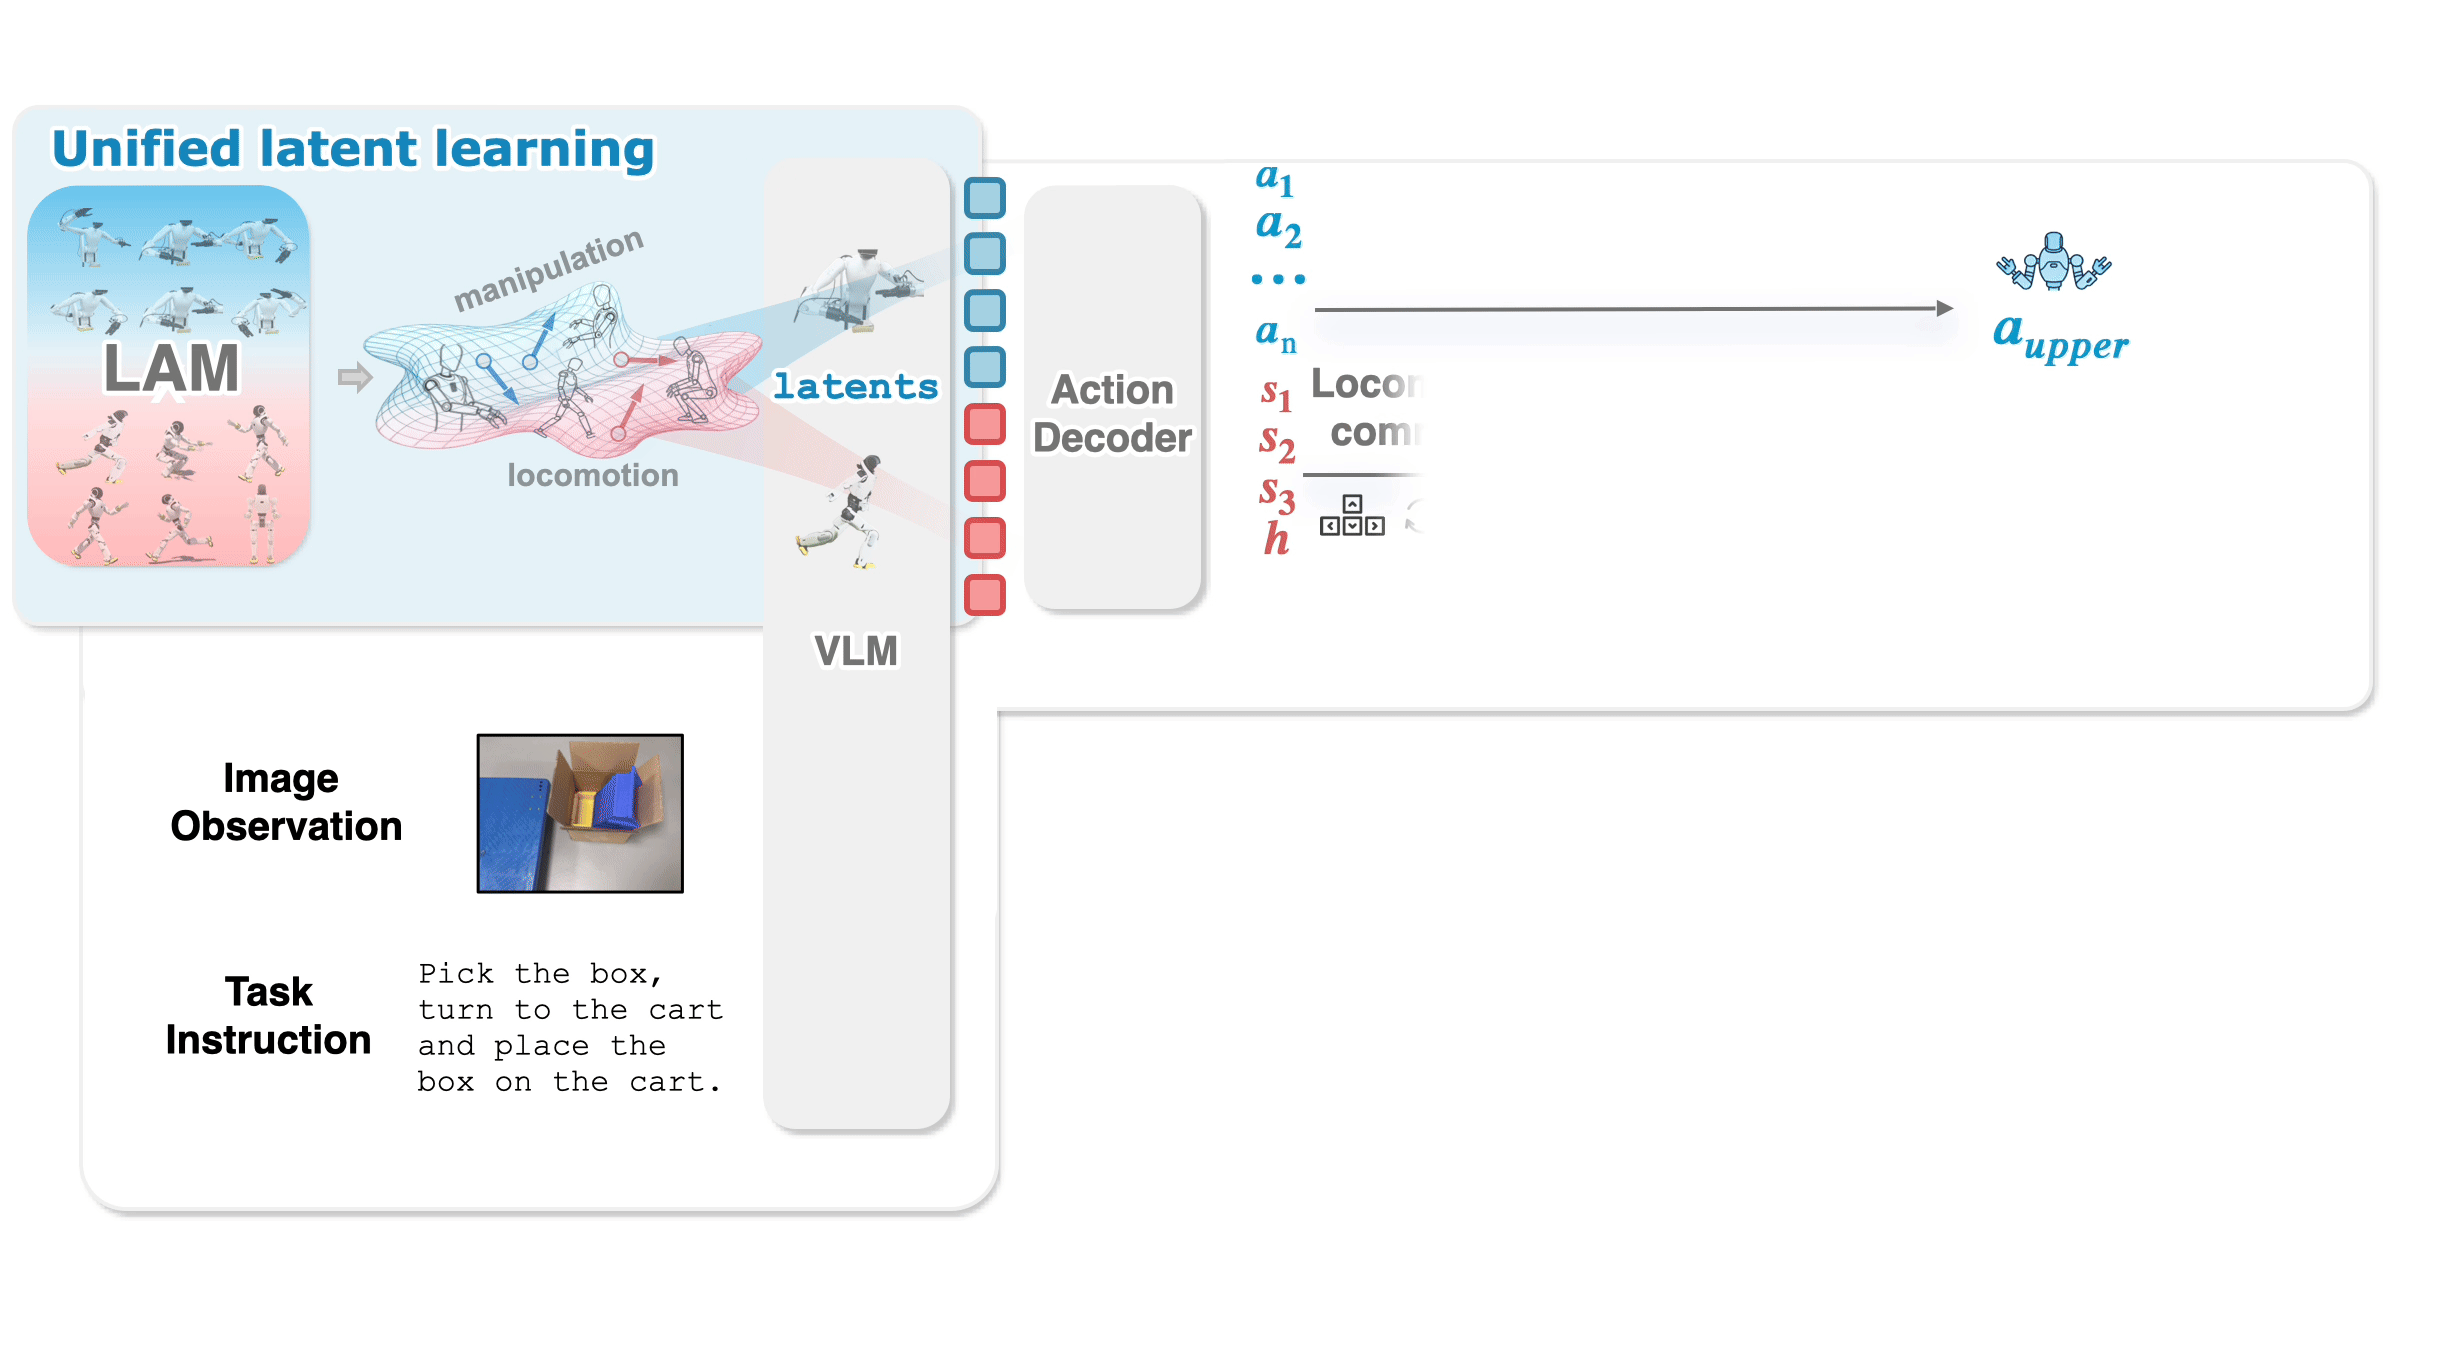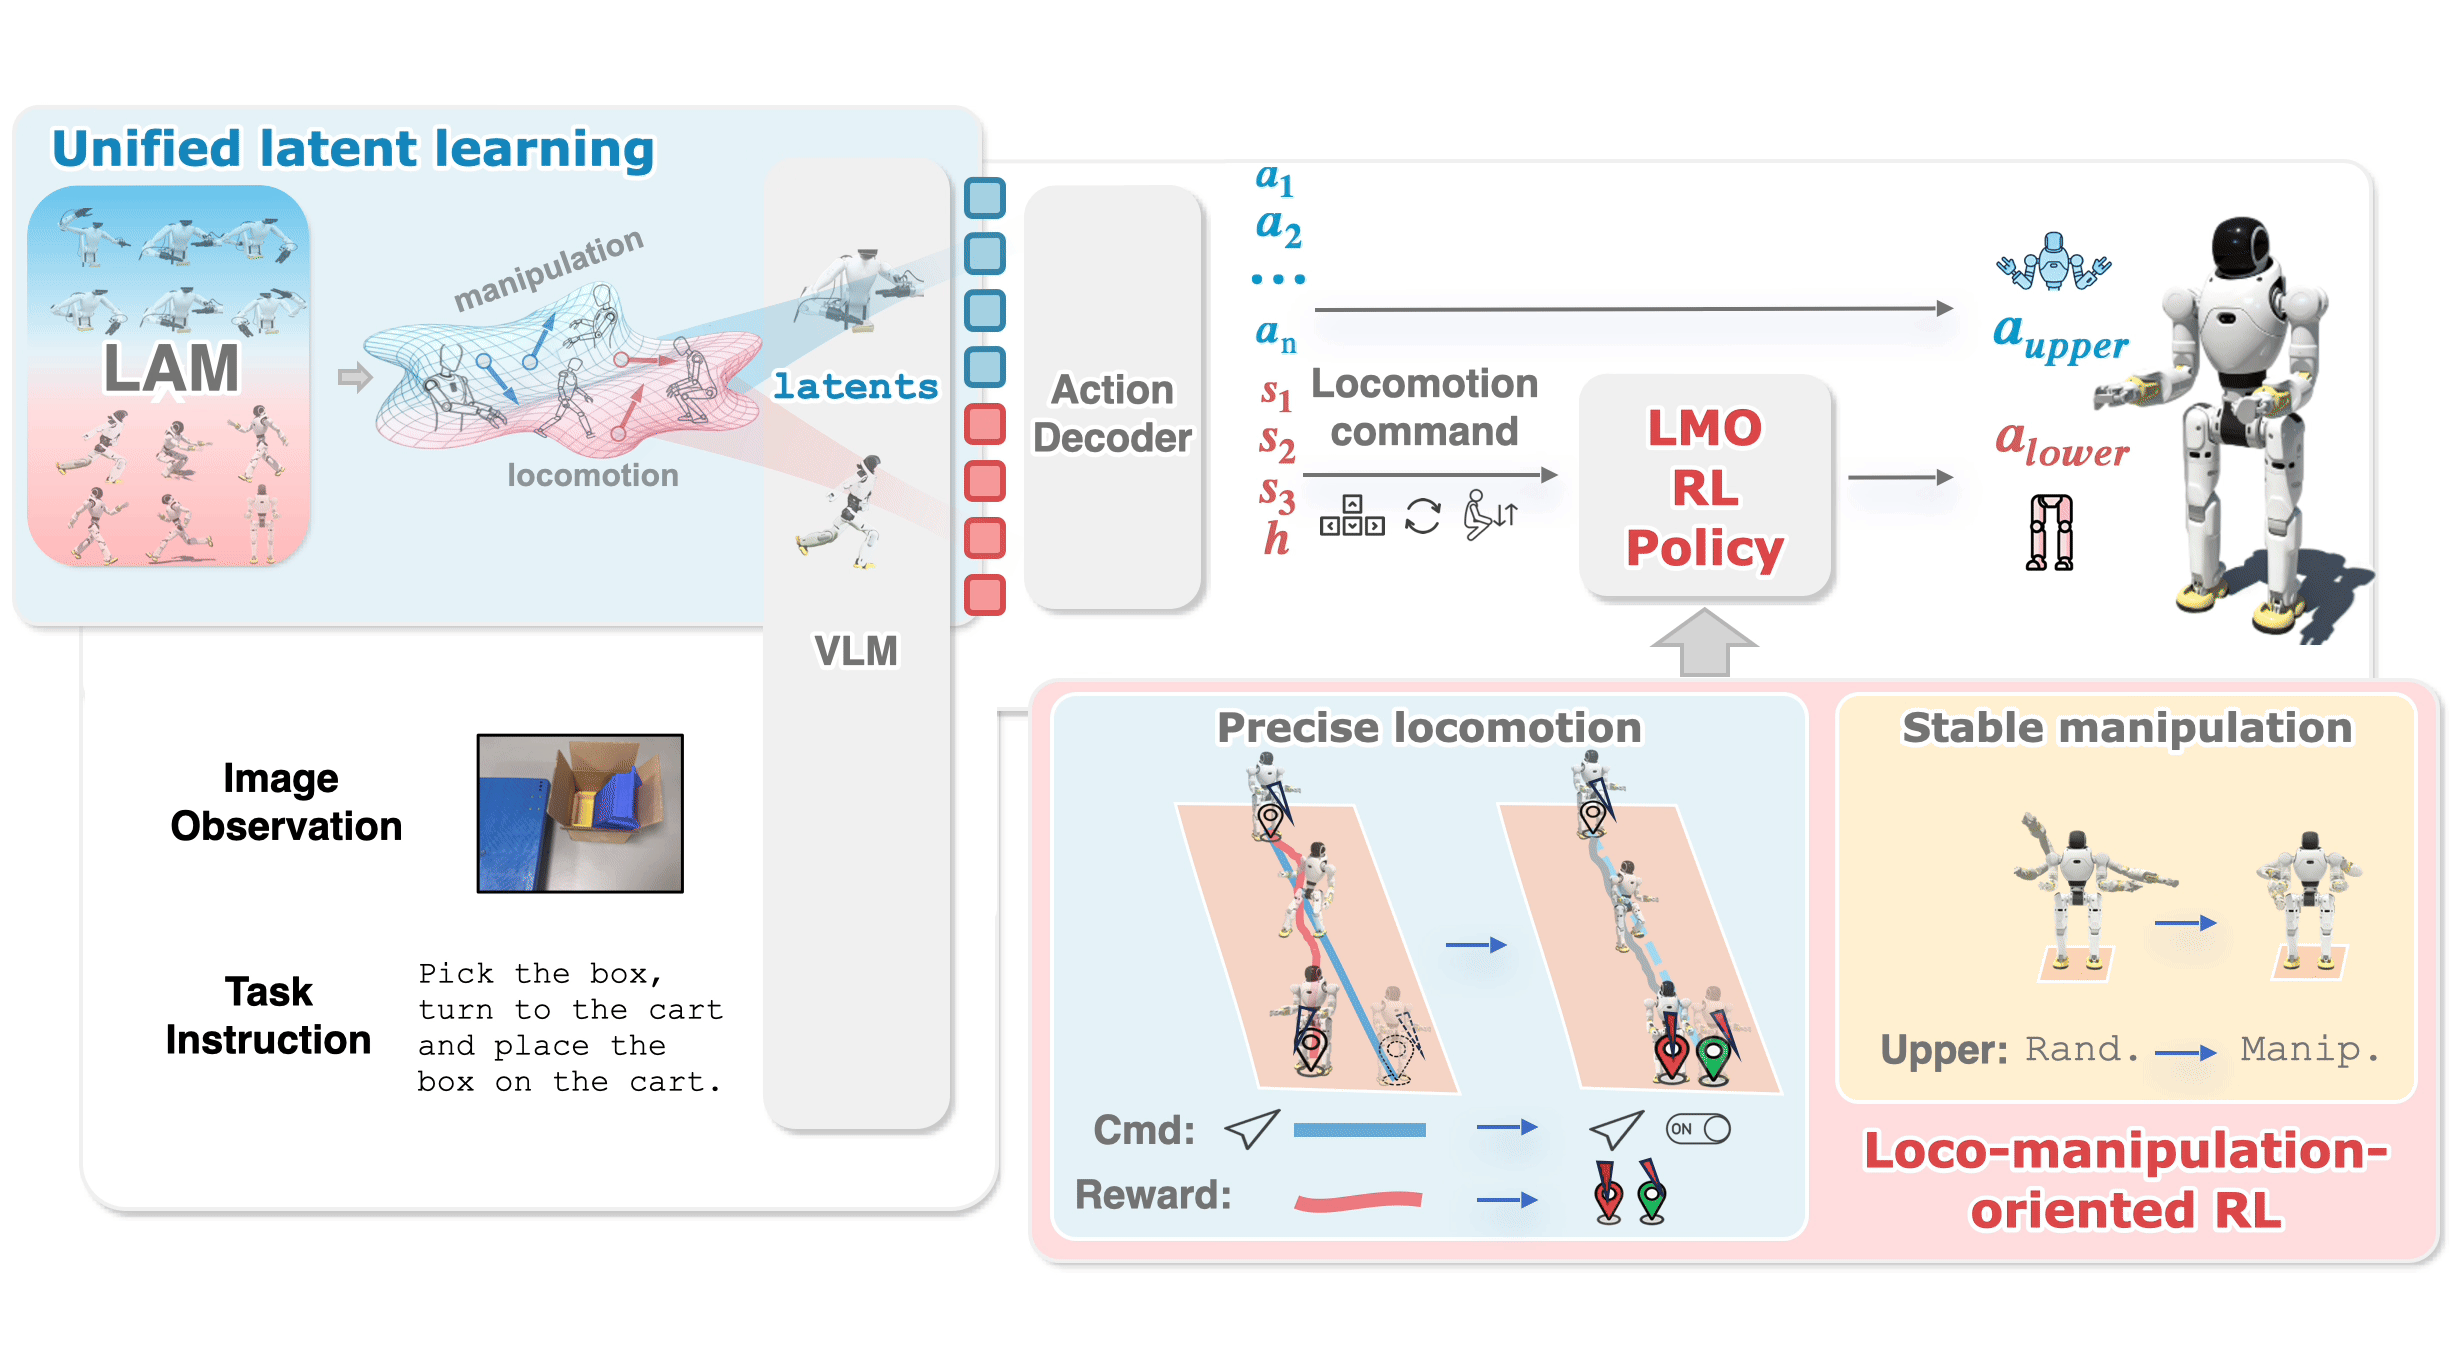
Part 1/7
Mapping the WholeBodyVLA Pipeline
15 min read
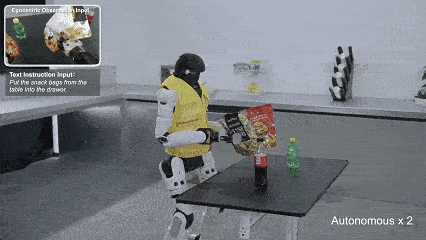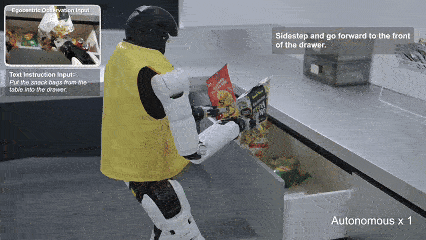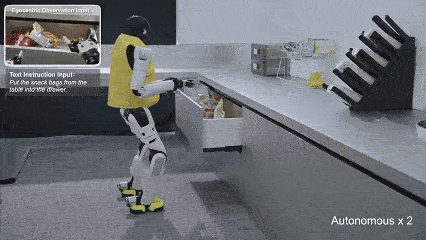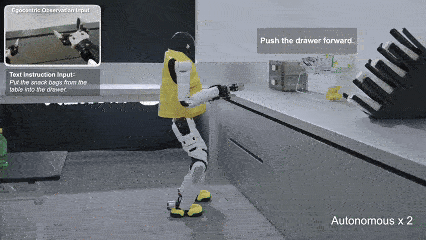
Part 2/7
Ego Videos for Locomotion LAMs
17 min read
Part 3/7
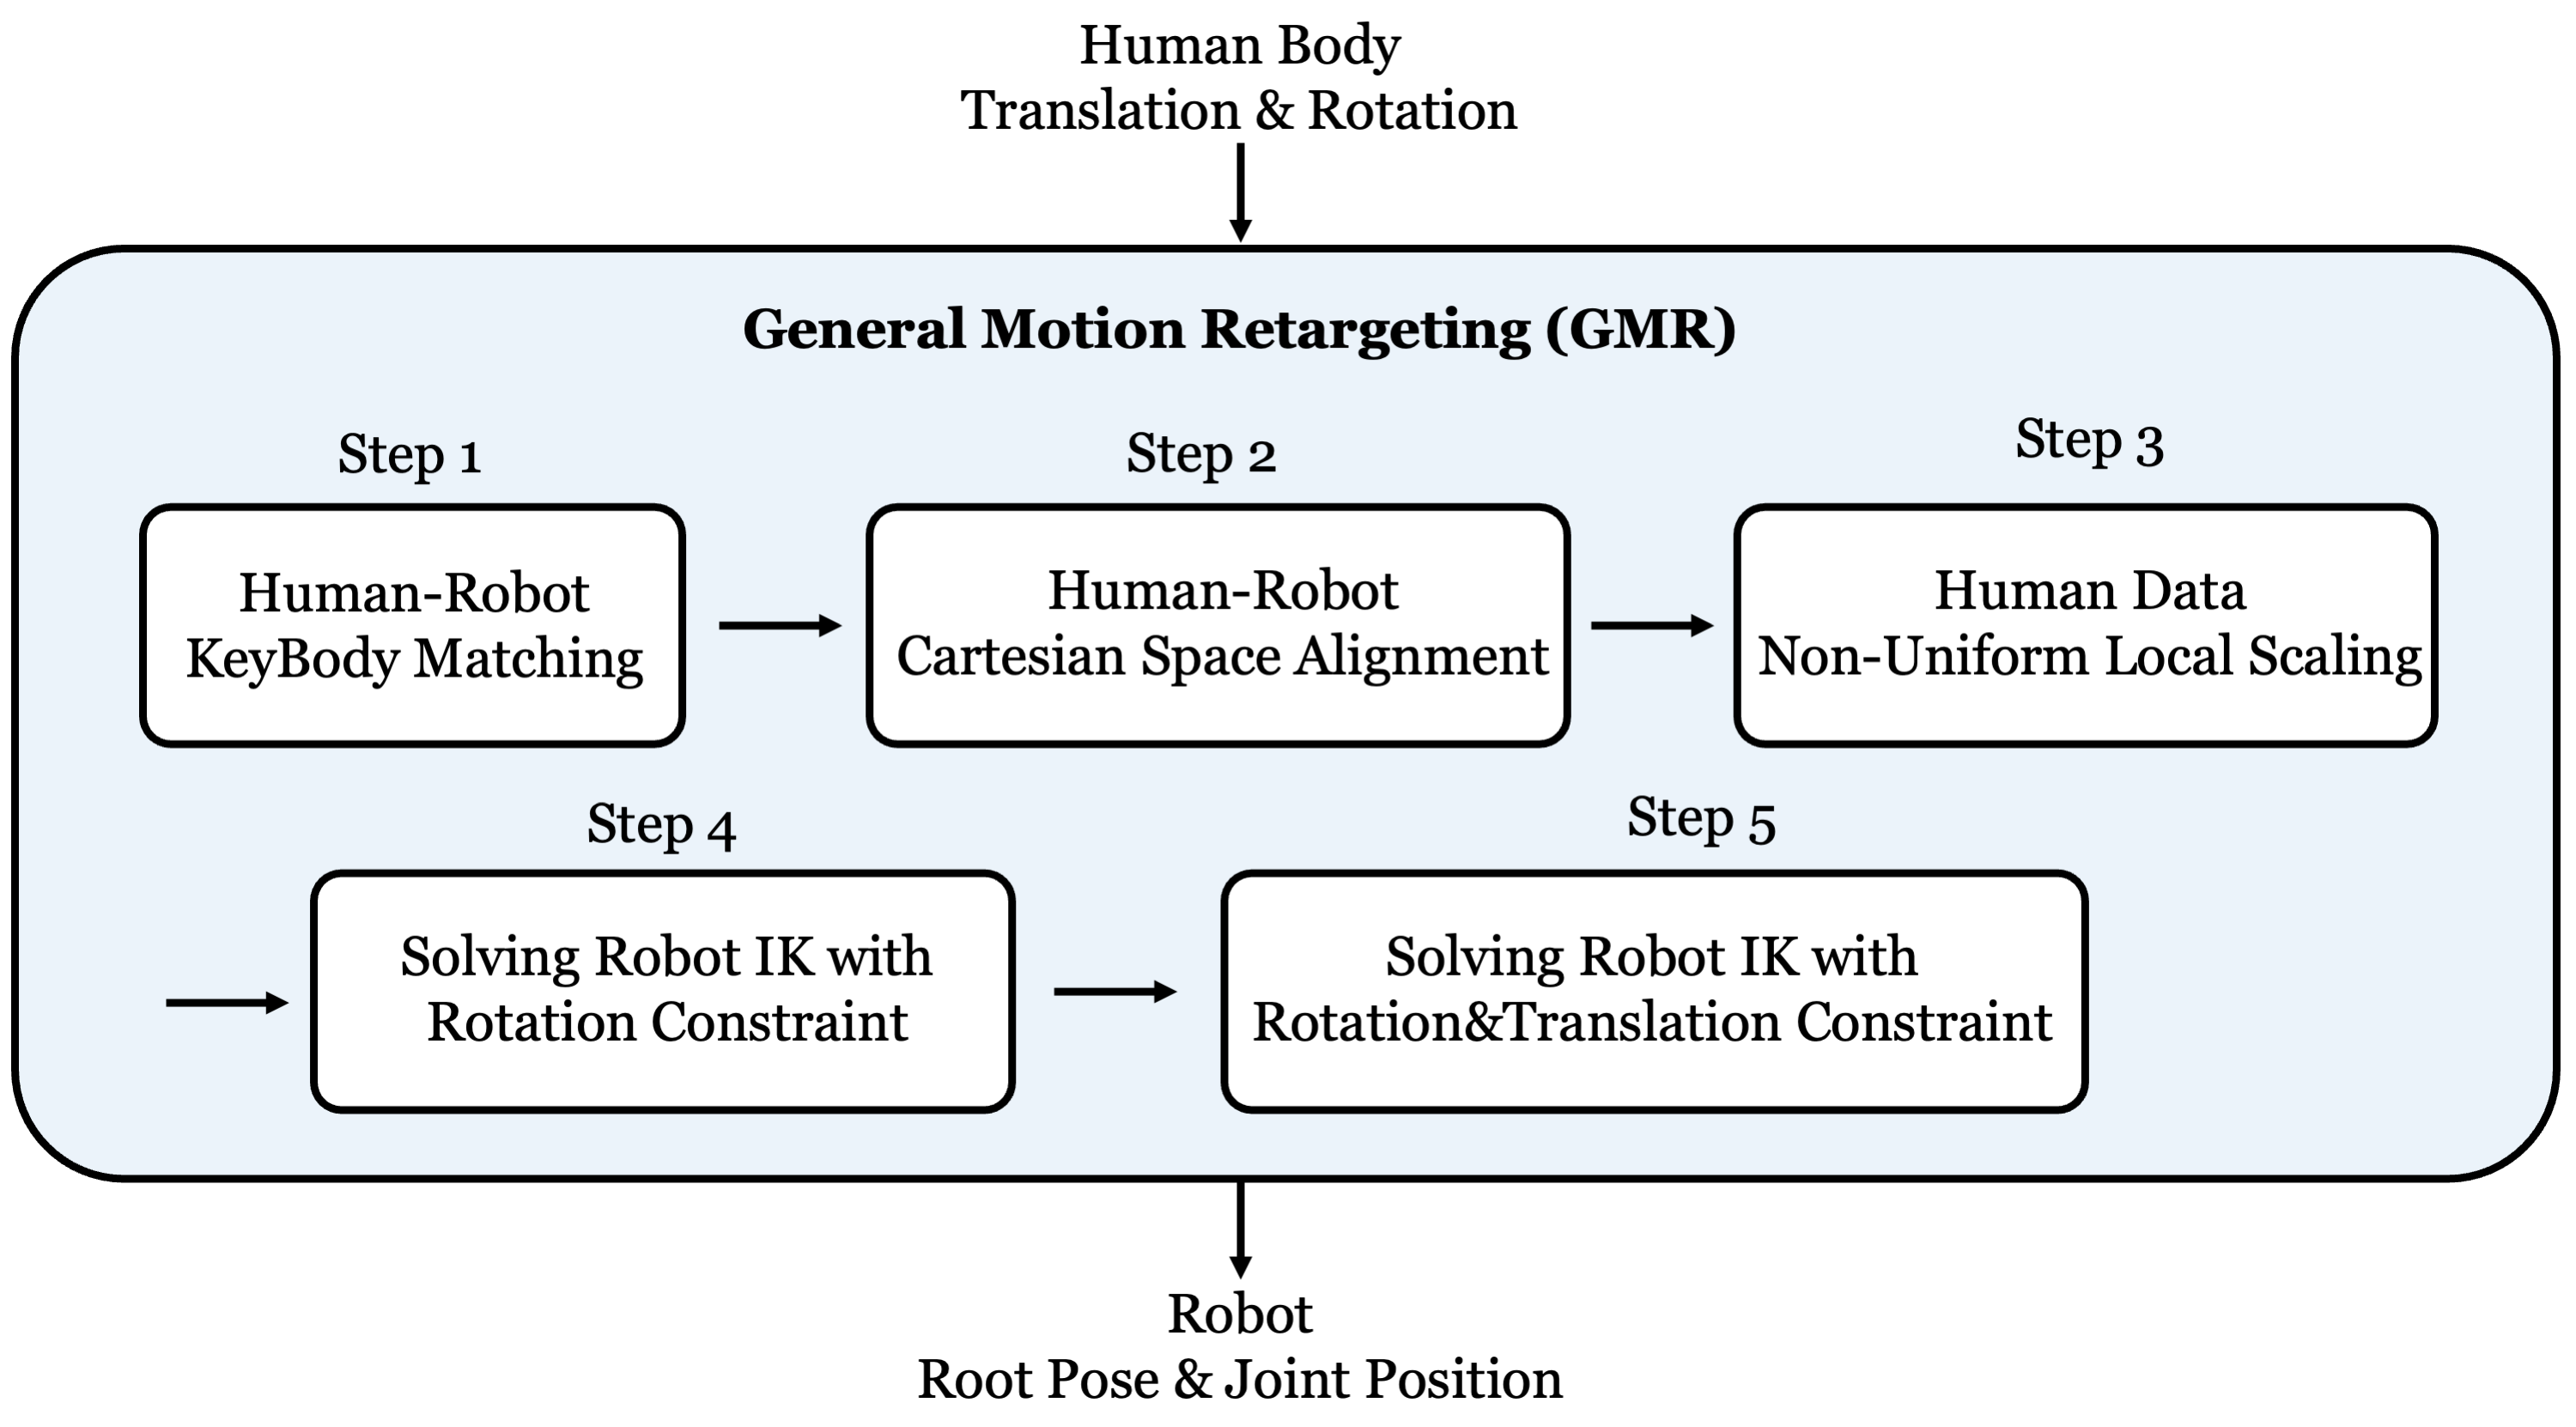
Retarget AMASS and GMR to Robots
18 min read
Part 4/7
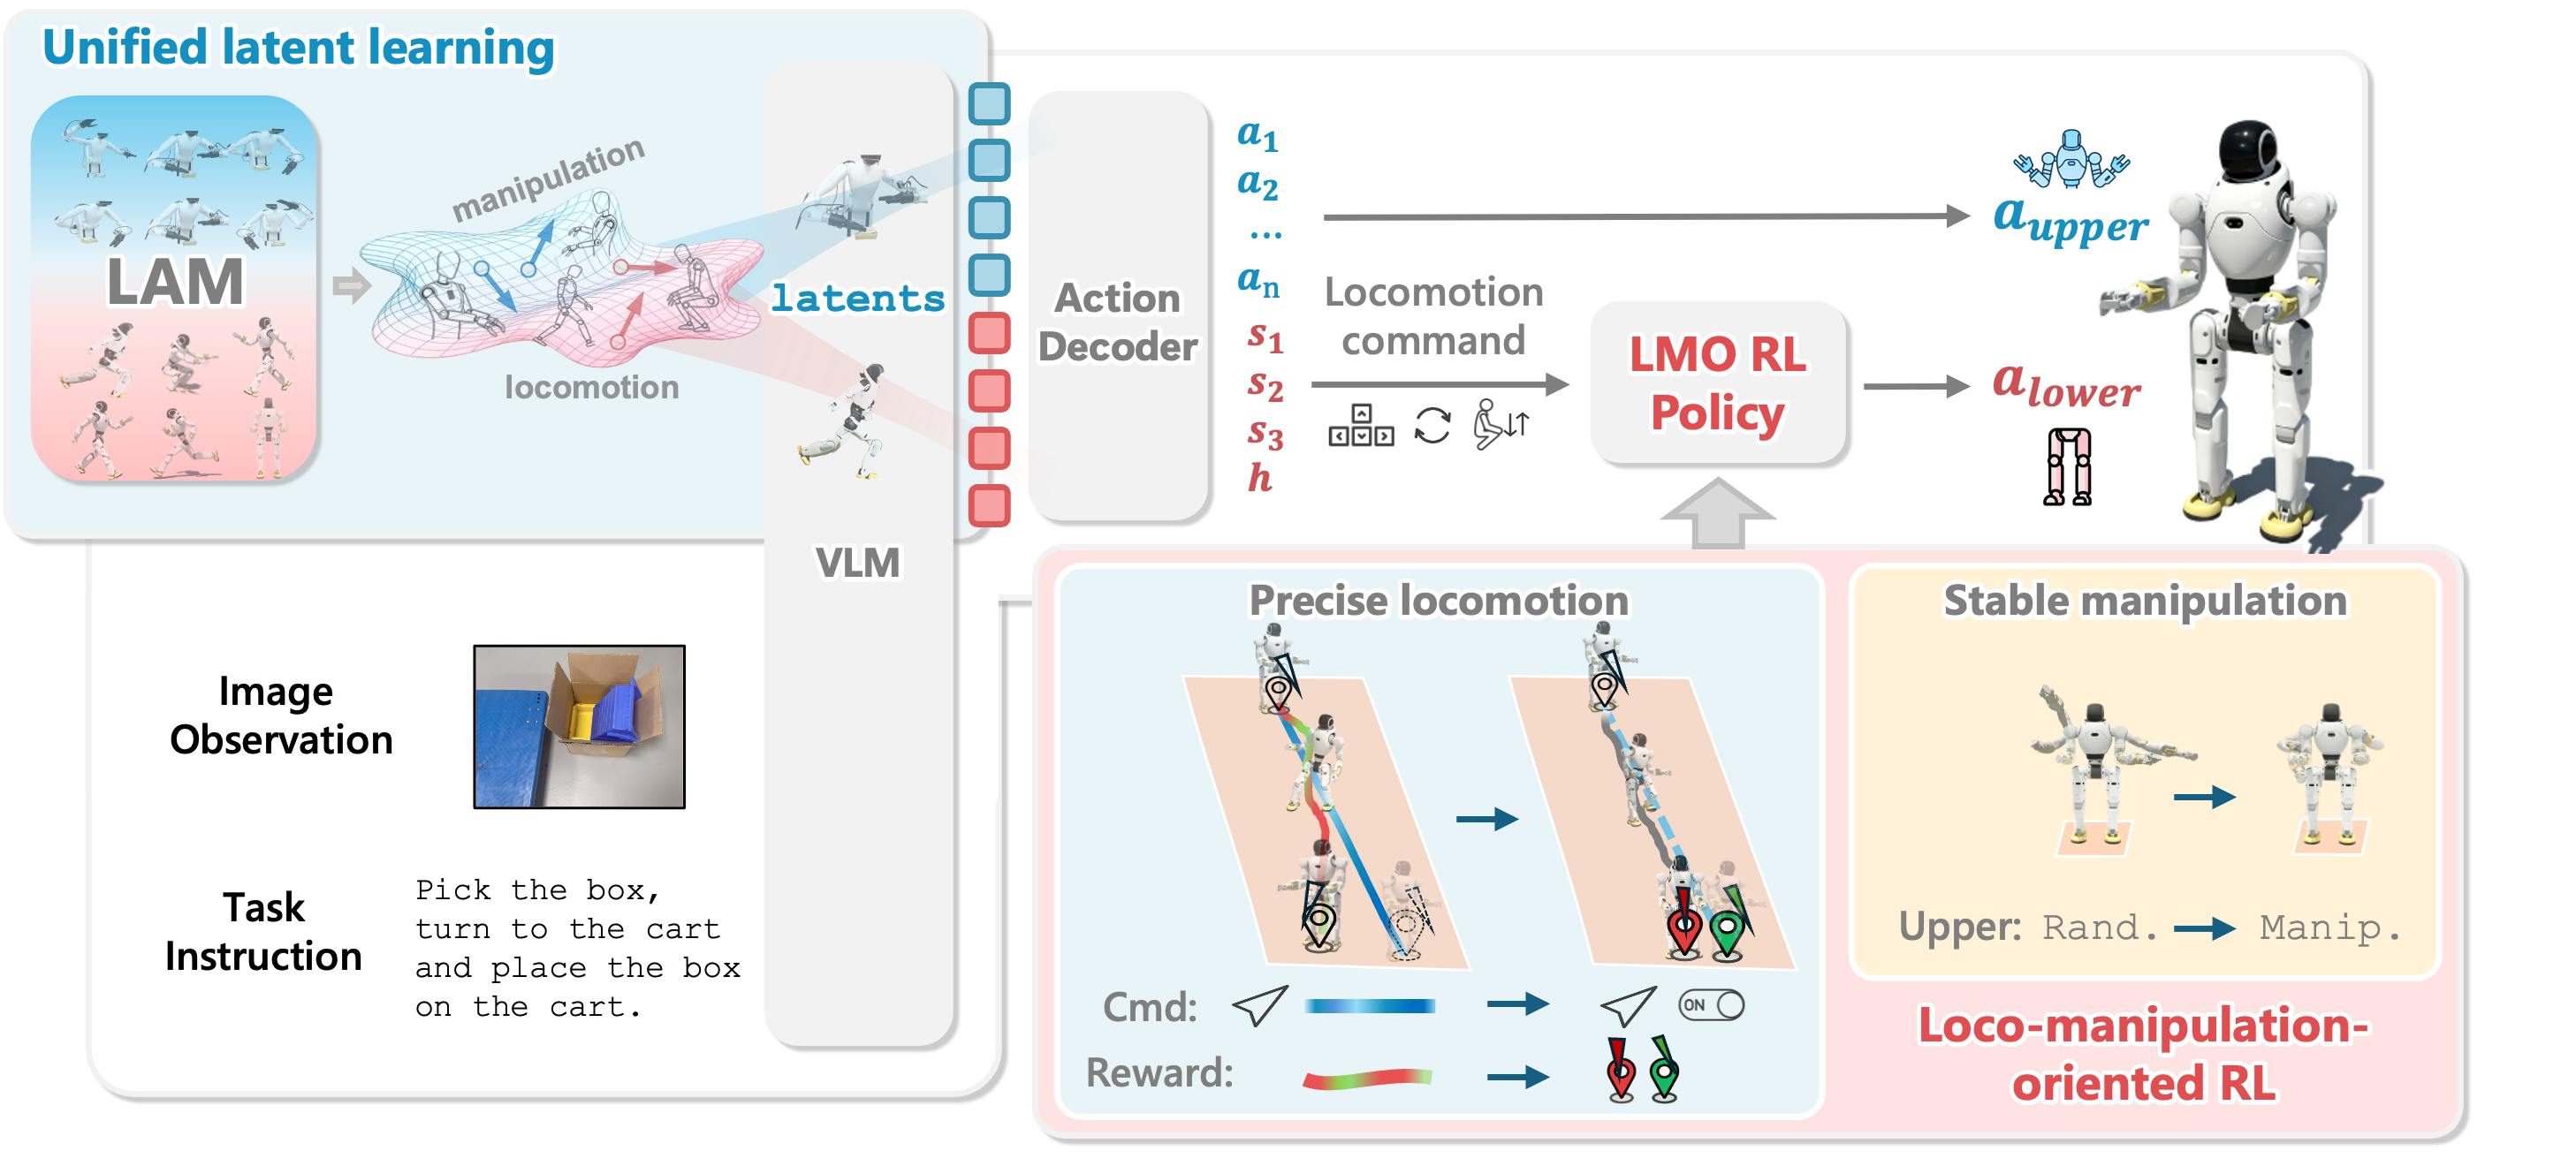
Whole-Body Teleop with TWIST/HOMIE
17 min read
Part 5/7
Training Trackers and LMO RL
16 min read
Part 6/7
Sim-to-Real Before Unitree G1
15 min read

Part 7/7
Evaluating Whole-Body VLAs
14 min read
Humanoid Vla Data Center 2026
· 6 partsPart 1/6
Two-Person Pilot for Humanoid VLA Data
15 min read
Part 2/6
Choosing the Humanoid Teleop Stack
15 min read
Part 3/6
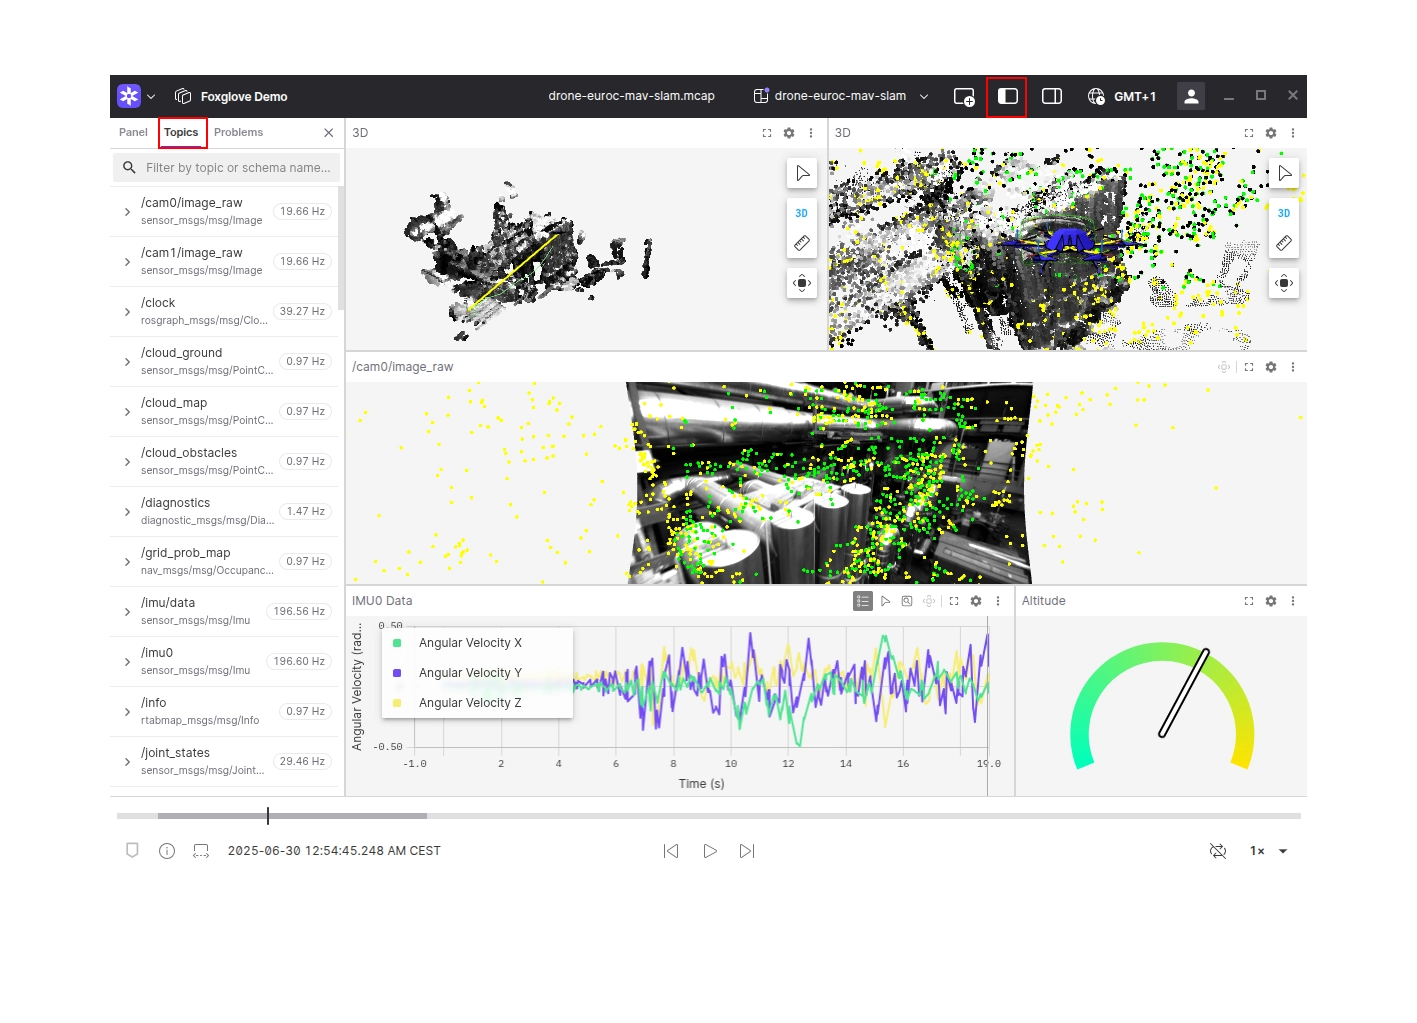
ROS 2 MCAP as the Raw Log Standard
15 min read

Part 4/6
LeRobotDataset and Robo-DM Data Lake
11 min read
Part 5/6
Synthetic Data and QA with Isaac Lab
13 min read
Part 6/6
Scaling to 20 Operators and VLA Evaluation
15 min read
Humanoid Data Ownership 2026
· 6 parts

Unifolm Vla G1 Series
· 5 parts
Part 1/5
unifolm-vla + Unitree G1 (Post 1): WBC+VLA system architecture — from data to real hardware
6 min read
Part 2/5
unifolm-vla + Unitree G1 (Post 2): collecting data with xr_teleoperate + Meta Quest 3
7 min read
Part 3/5
unifolm-vla + Unitree G1 (Post 3): data pipeline — JSON → LeRobot → HDF5 → RLDS
5 min read
Part 4/5
unifolm-vla + Unitree G1 (Post 4): fine-tuning from Qwen2.5-VL-7B — 8-GPU and single-GPU LoRA
7 min read
Part 5/5
unifolm-vla + Unitree G1 (Post 5): deploy inference server, SSH tunnel, and parallel locomotion
7 min read
Grail Humanoid Data Pipeline
· 6 parts
Part 1/6
3D Assets and Terrain in GRAIL
14 min read
Part 2/6
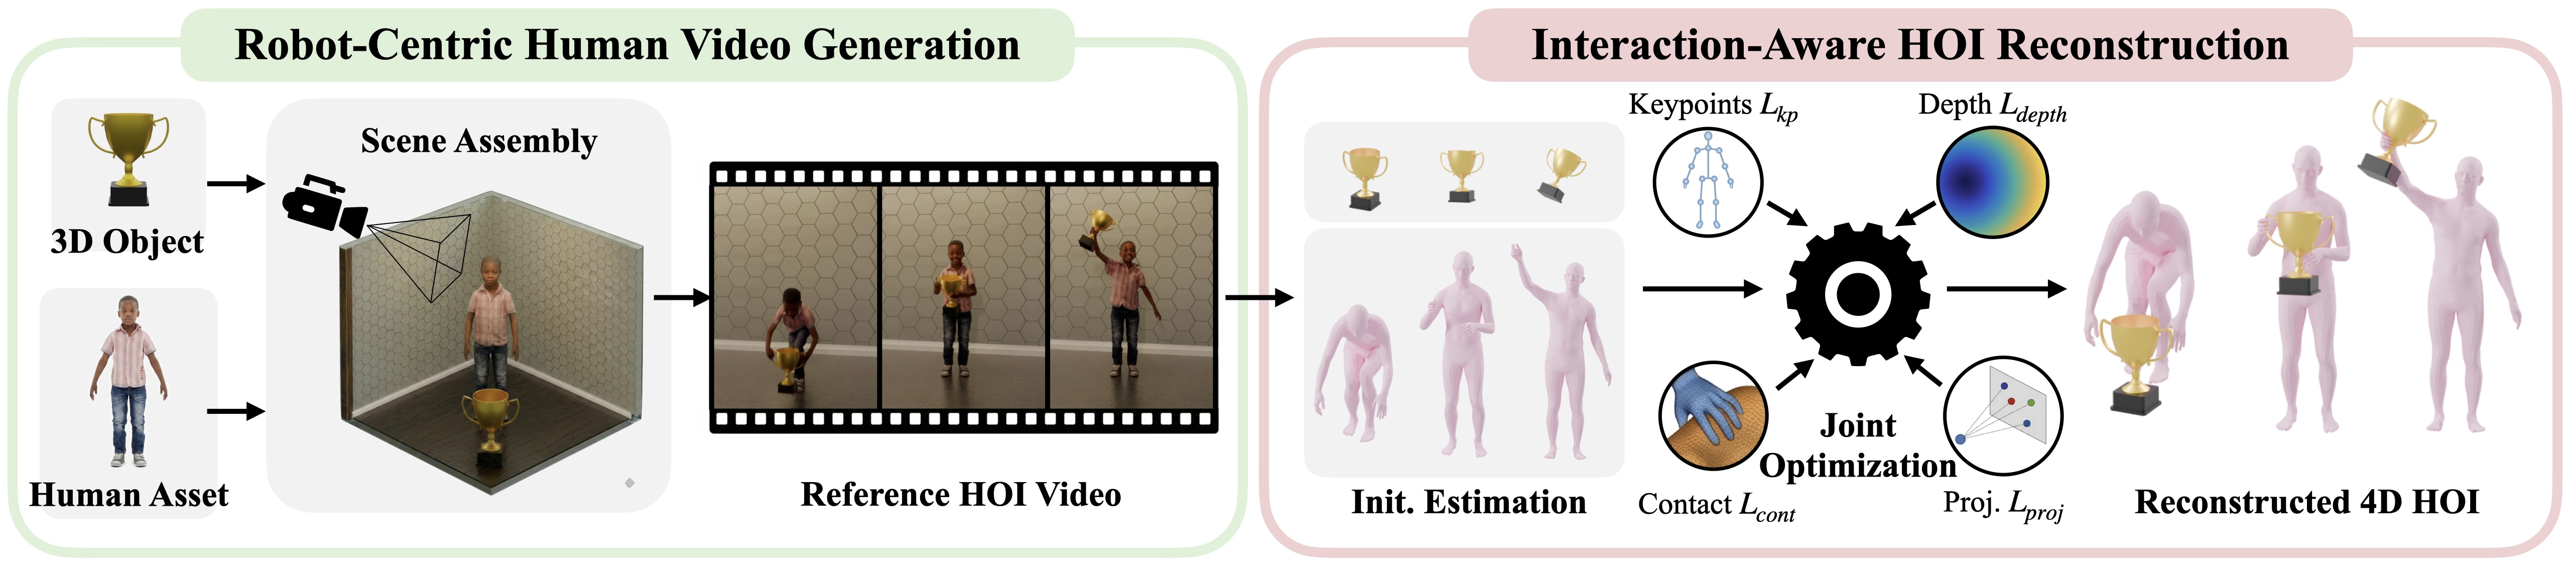
2D HOI Videos with Blender and Kling
15 min read
Part 3/6
4D HOI Reconstruction: GEM, SAM2, MoGe
16 min read
Part 4/6
Static-Object Mode for Terrain and Sitting
15 min read
Part 5/6
Retarget SMPL-X Motions to Unitree G1
14 min read
Part 6/6
Train SONIC, Export, and Evaluate GRAIL
14 min read
AI for Robotics
· 8 partsRobot AI
Part 1/8
RL for Robotics: PPO, SAC and How to Choose Your Algorithm
9 min read
Robot AI
Part 2/8
Imitation Learning: BC, DAgger and DAPG for Robots
11 min read
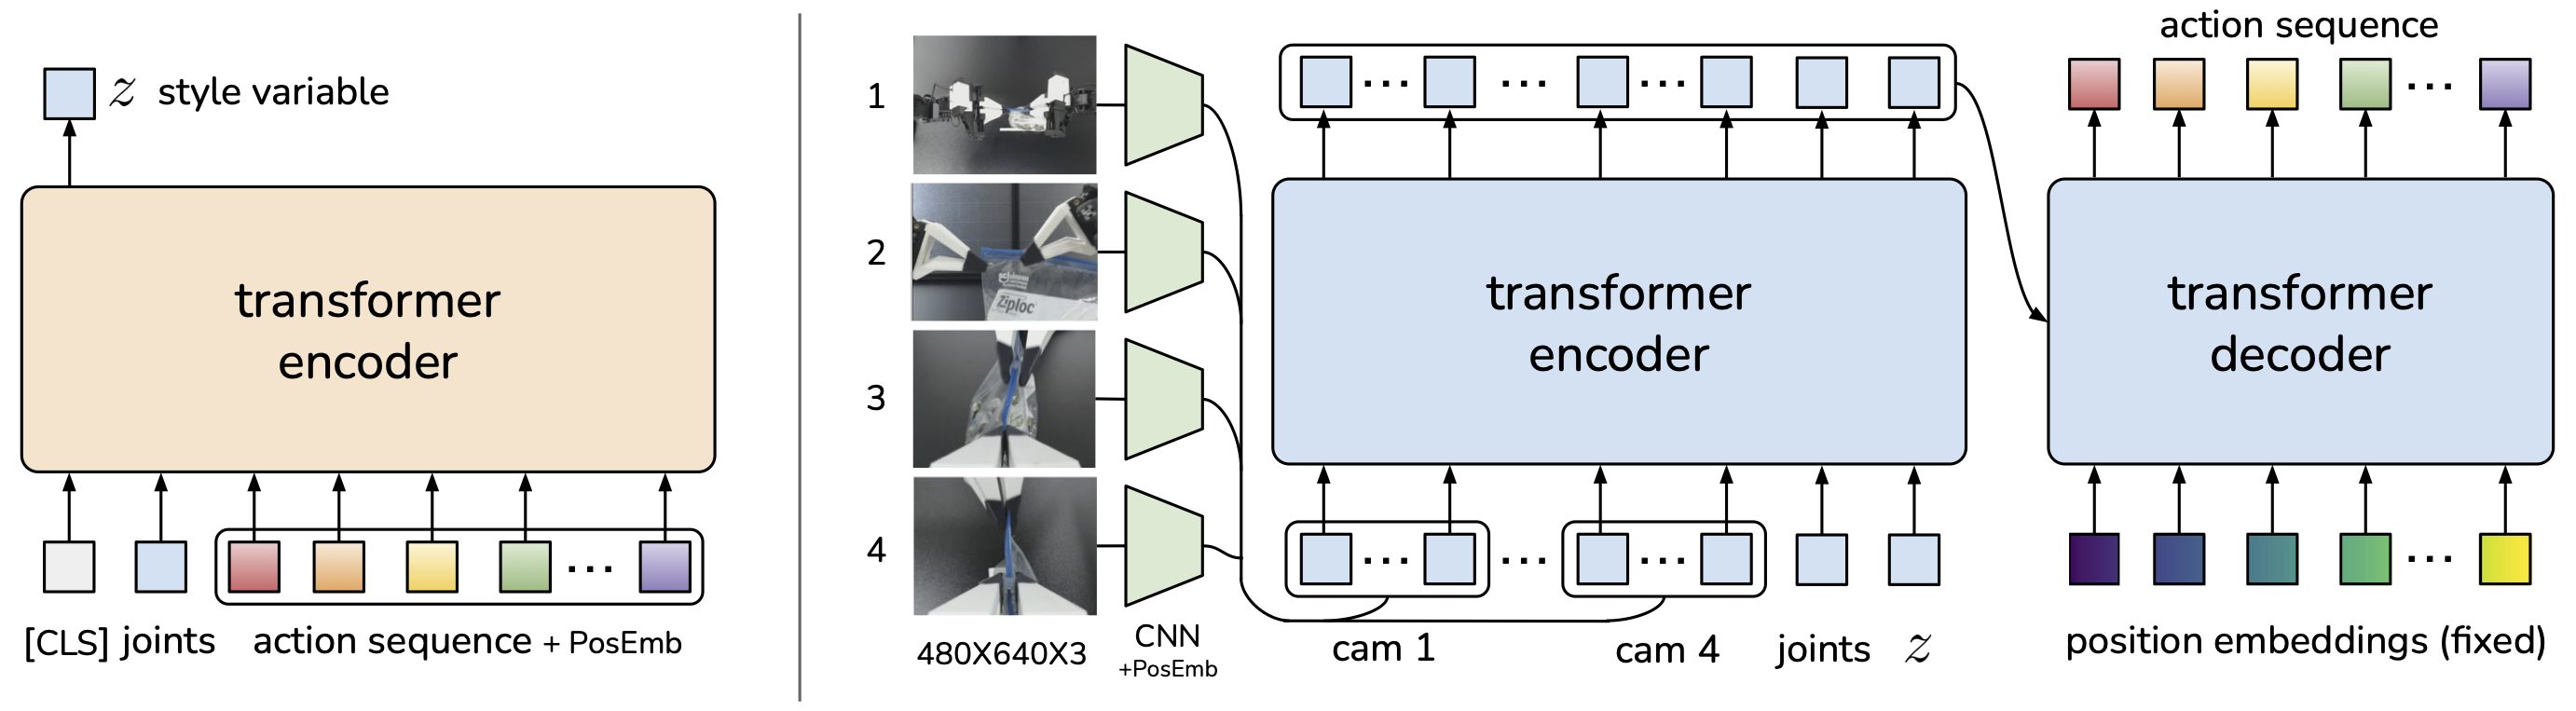
Part 3/8
Action Chunking Transformers (ACT): Architecture in Detail
11 min read
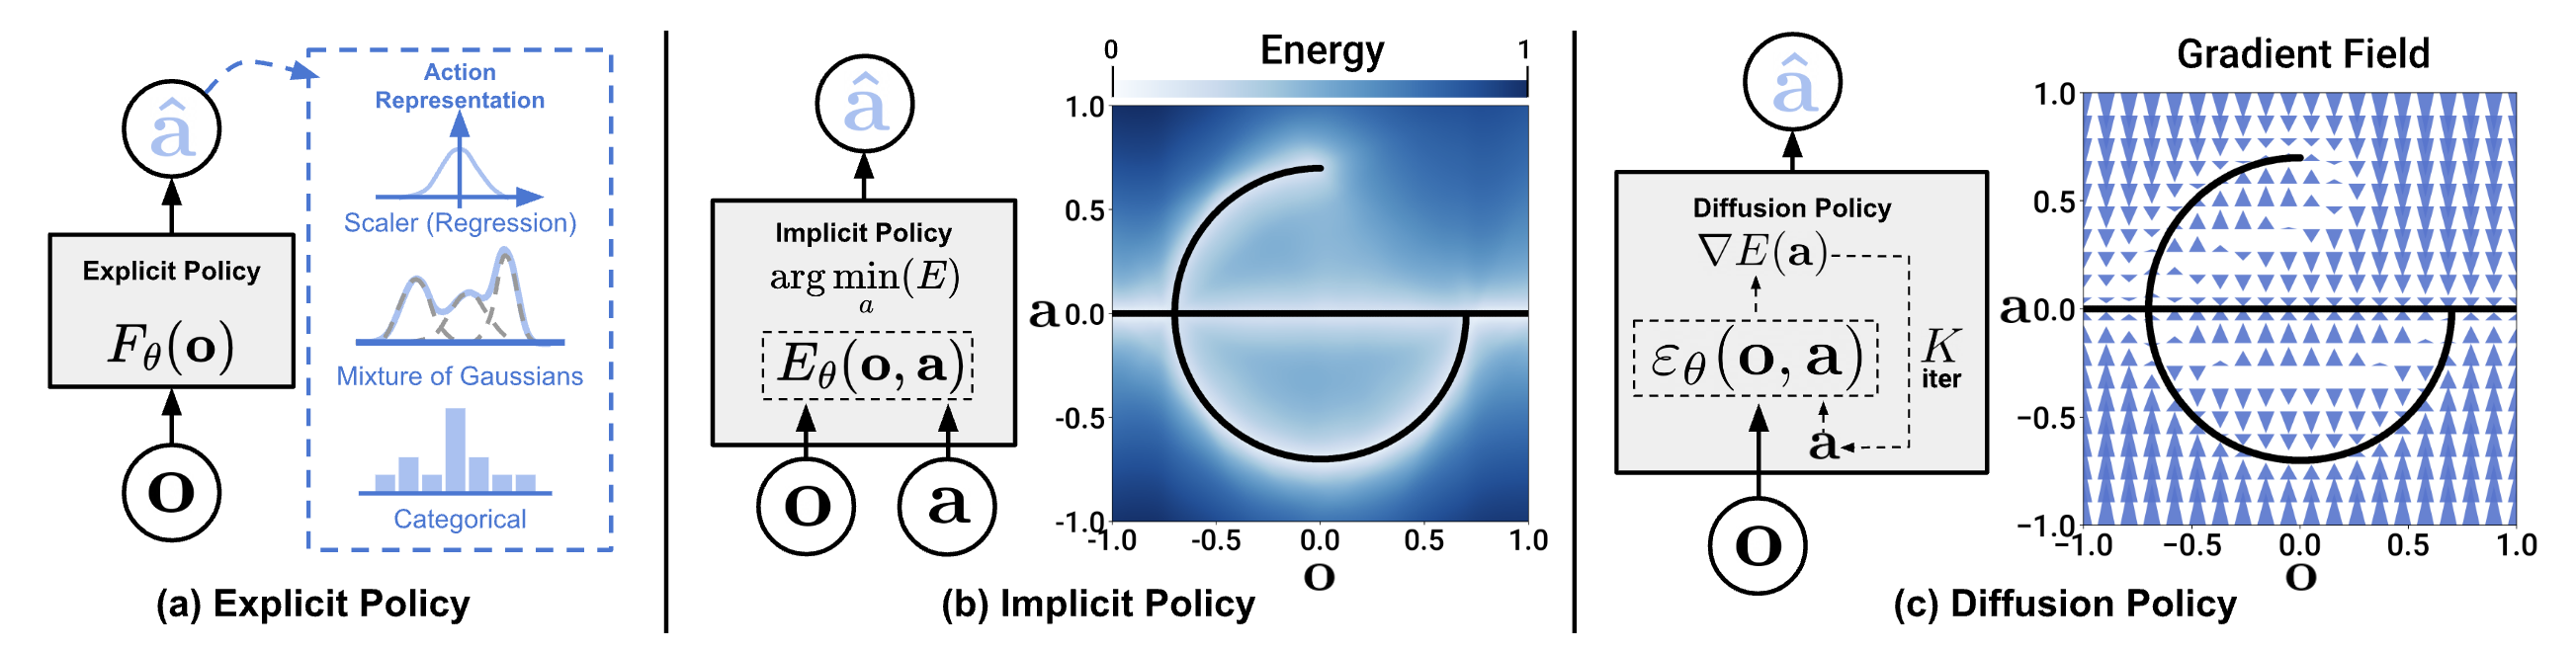
Part 4/8
Diffusion Policy: A Revolution in Robot Manipulation
9 min read
Robot AI
Part 5/8
VLA Models: RT-2 → Octo → OpenVLA → π0
12 min read
Part 6/8
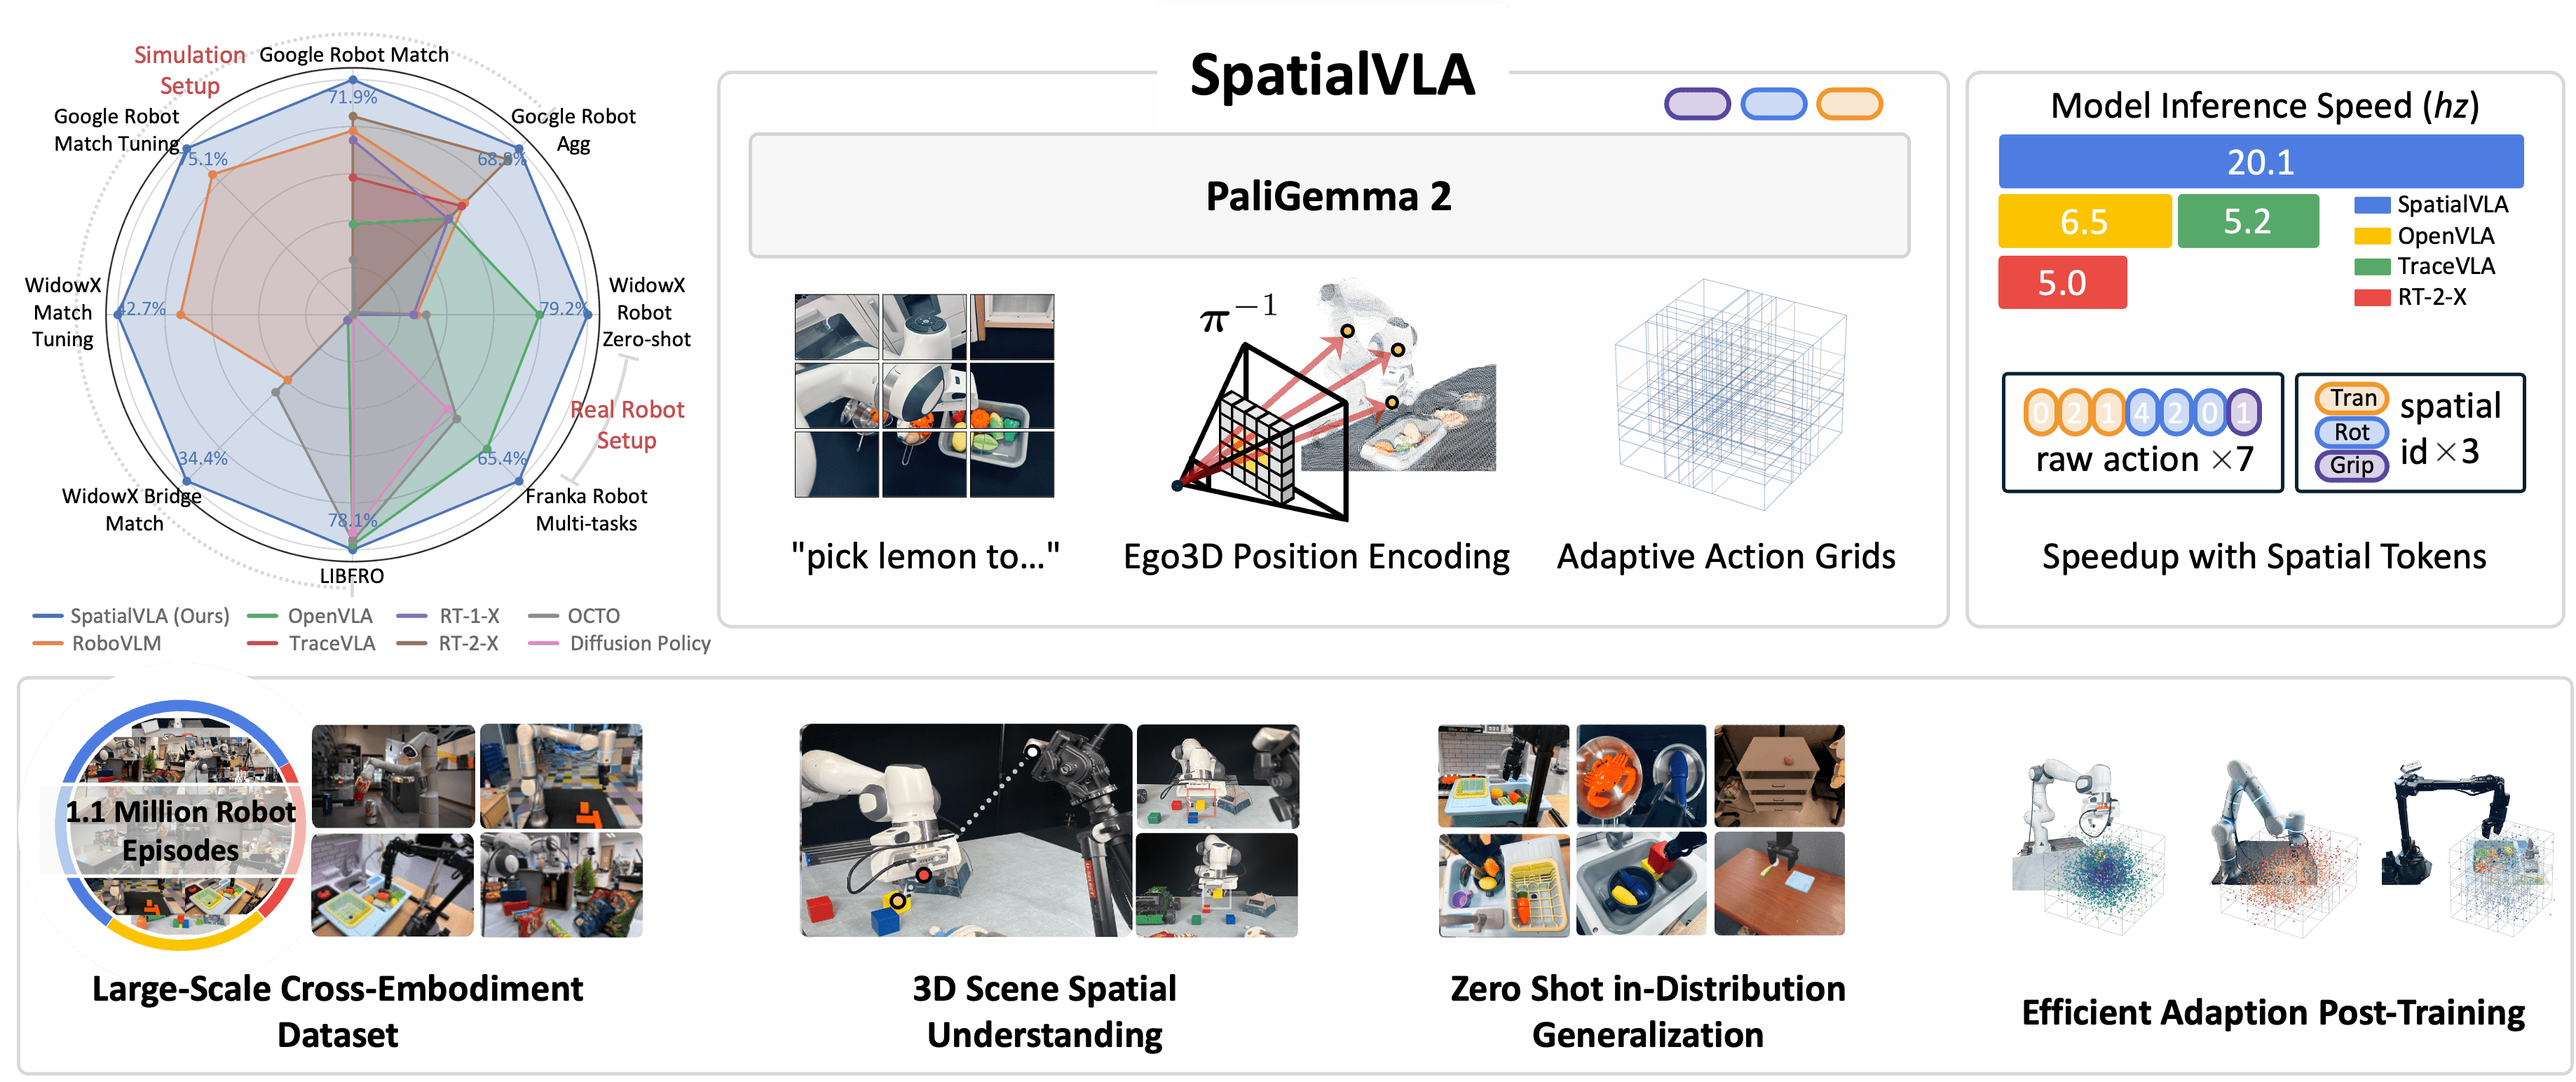
SpatialVLA: 3D Understanding for Robot Manipulation
8 min read
Part 7/8
Hands-on: Fine-tune OpenVLA with LeRobot
13 min read
Part 8/8
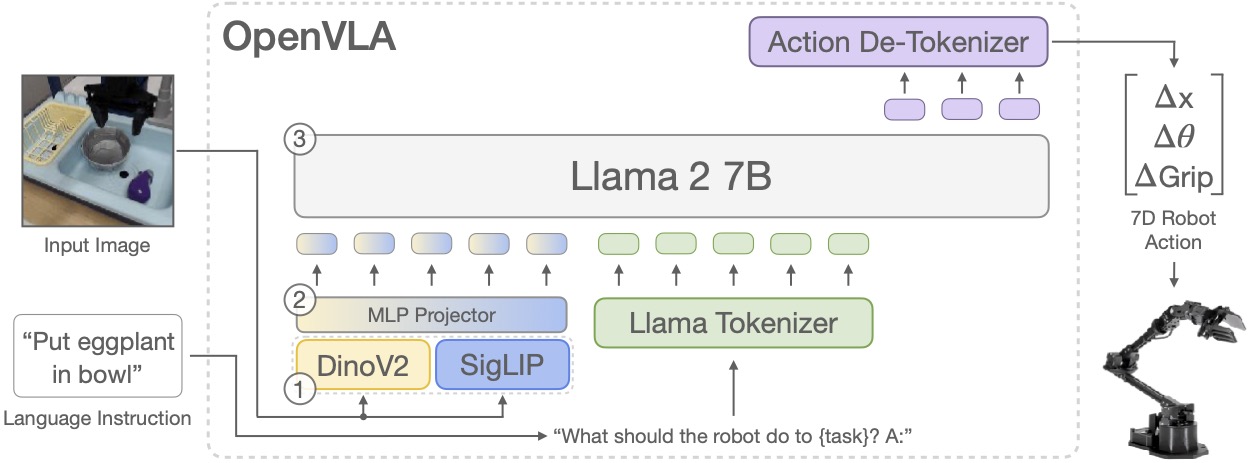
OpenVLA: Open VLA for Robots
15 min read
Umi Vla Series
· 7 parts
Part 1/7
What is UMI? How to collect VLA robot data without teleop
6 min read
Part 2/7
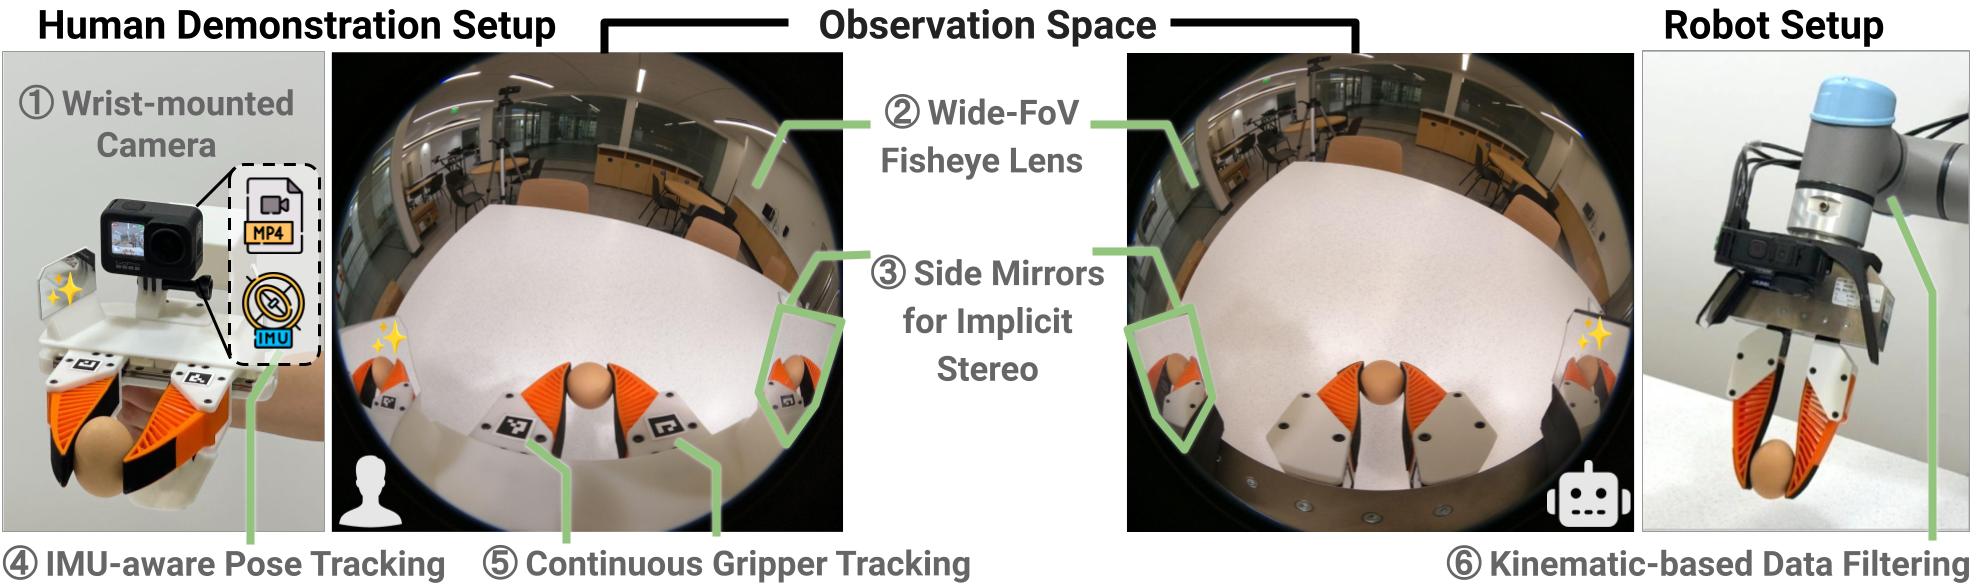
Build your first UMI gripper: 3D printing, assembly, and GoPro smoke test
7 min read
Part 3/7
Collect single-arm UMI demos and run the official SLAM pipeline
7 min read
Part 4/7
Train your first UMI Diffusion Policy and test on a real robot arm
5 min read
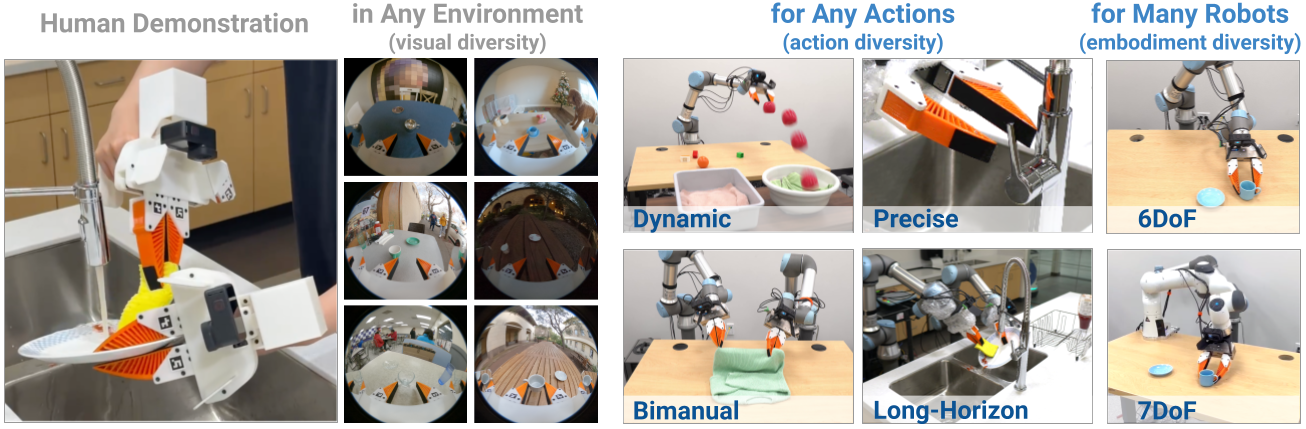
Part 5/7
Go bimanual: UMI two-arm pipeline with official scripts
7 min read
Manipulation
Part 6/7
Upgrading to D405: when to replace GoPro in UMI and how
6 min read
Part 7/7
Whole-body VLA: combining UMI + mocap/VR for full-body humanoid data
7 min read
Groot N1 G1 Series
· 5 parts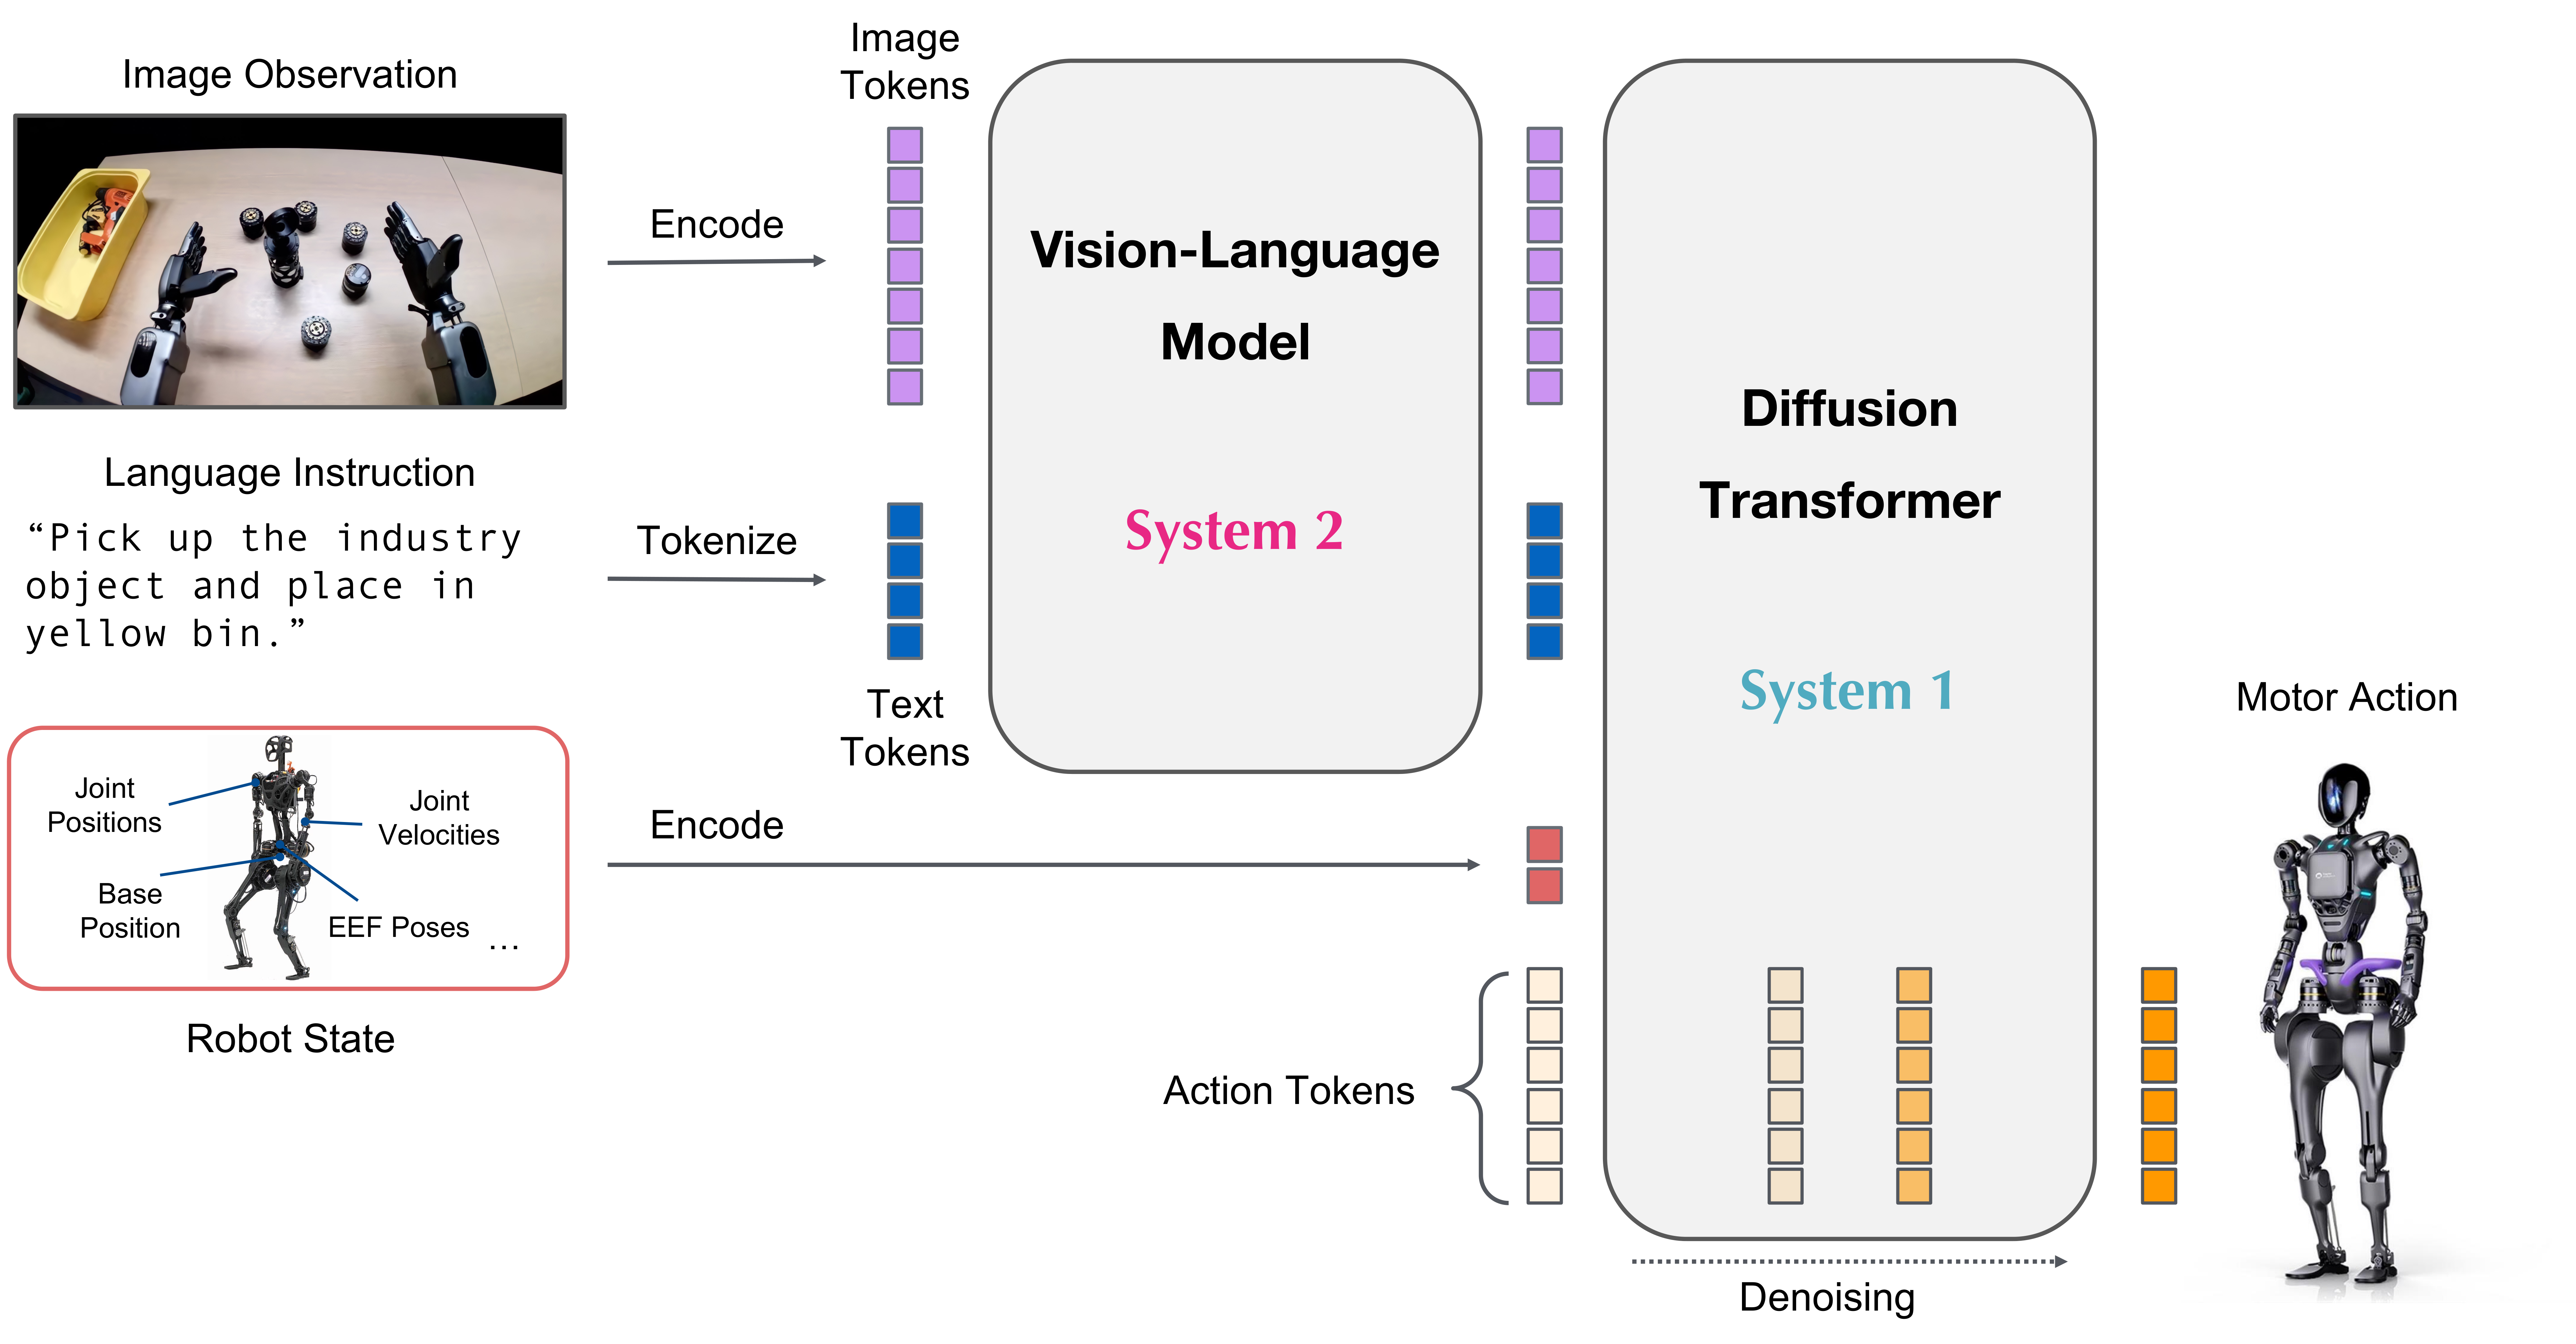
Part 1/5
GR00T N1 + G1: decoupled WBC+VLA architecture, 6Hz-500Hz
6 min read

Part 2/5
GR00T N1 + G1 (Post 2): data collection with xr_teleoperate
5 min read
Part 3/5
GR00T N1 + G1 (Post 3): fine-tuning — GPU, config, script
5 min read
Part 4/5
GR00T N1 + G1 (Post 4): deploying GR00T-WBC — GEAR + SONIC
6 min read
Part 5/5
GR00T N1 + G1 (Post 5): sim2real transfer and eval
6 min read
GR00T Whole-body VLA Data Pipeline
· 4 parts
Vla Wbc Repos
· 3 parts
Psi0 Hands On
· 6 parts
Part 1/6
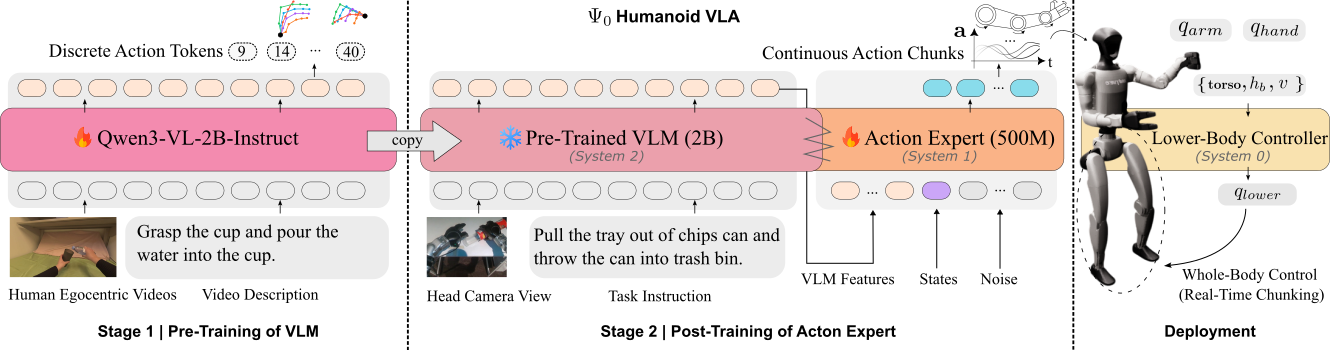
Ψ₀ Hands-On (1): Overview & Key Ideas
12 min read
Part 2/6
Ψ₀ Hands-On (2): The Three-Tier Architecture
15 min read
Part 3/6
Psi0 Hands-On (3): Data Recipe & Pipeline
12 min read
Part 4/6
Psi0 Hands-On (4): Setup & Training Pipeline
14 min read
Part 5/6
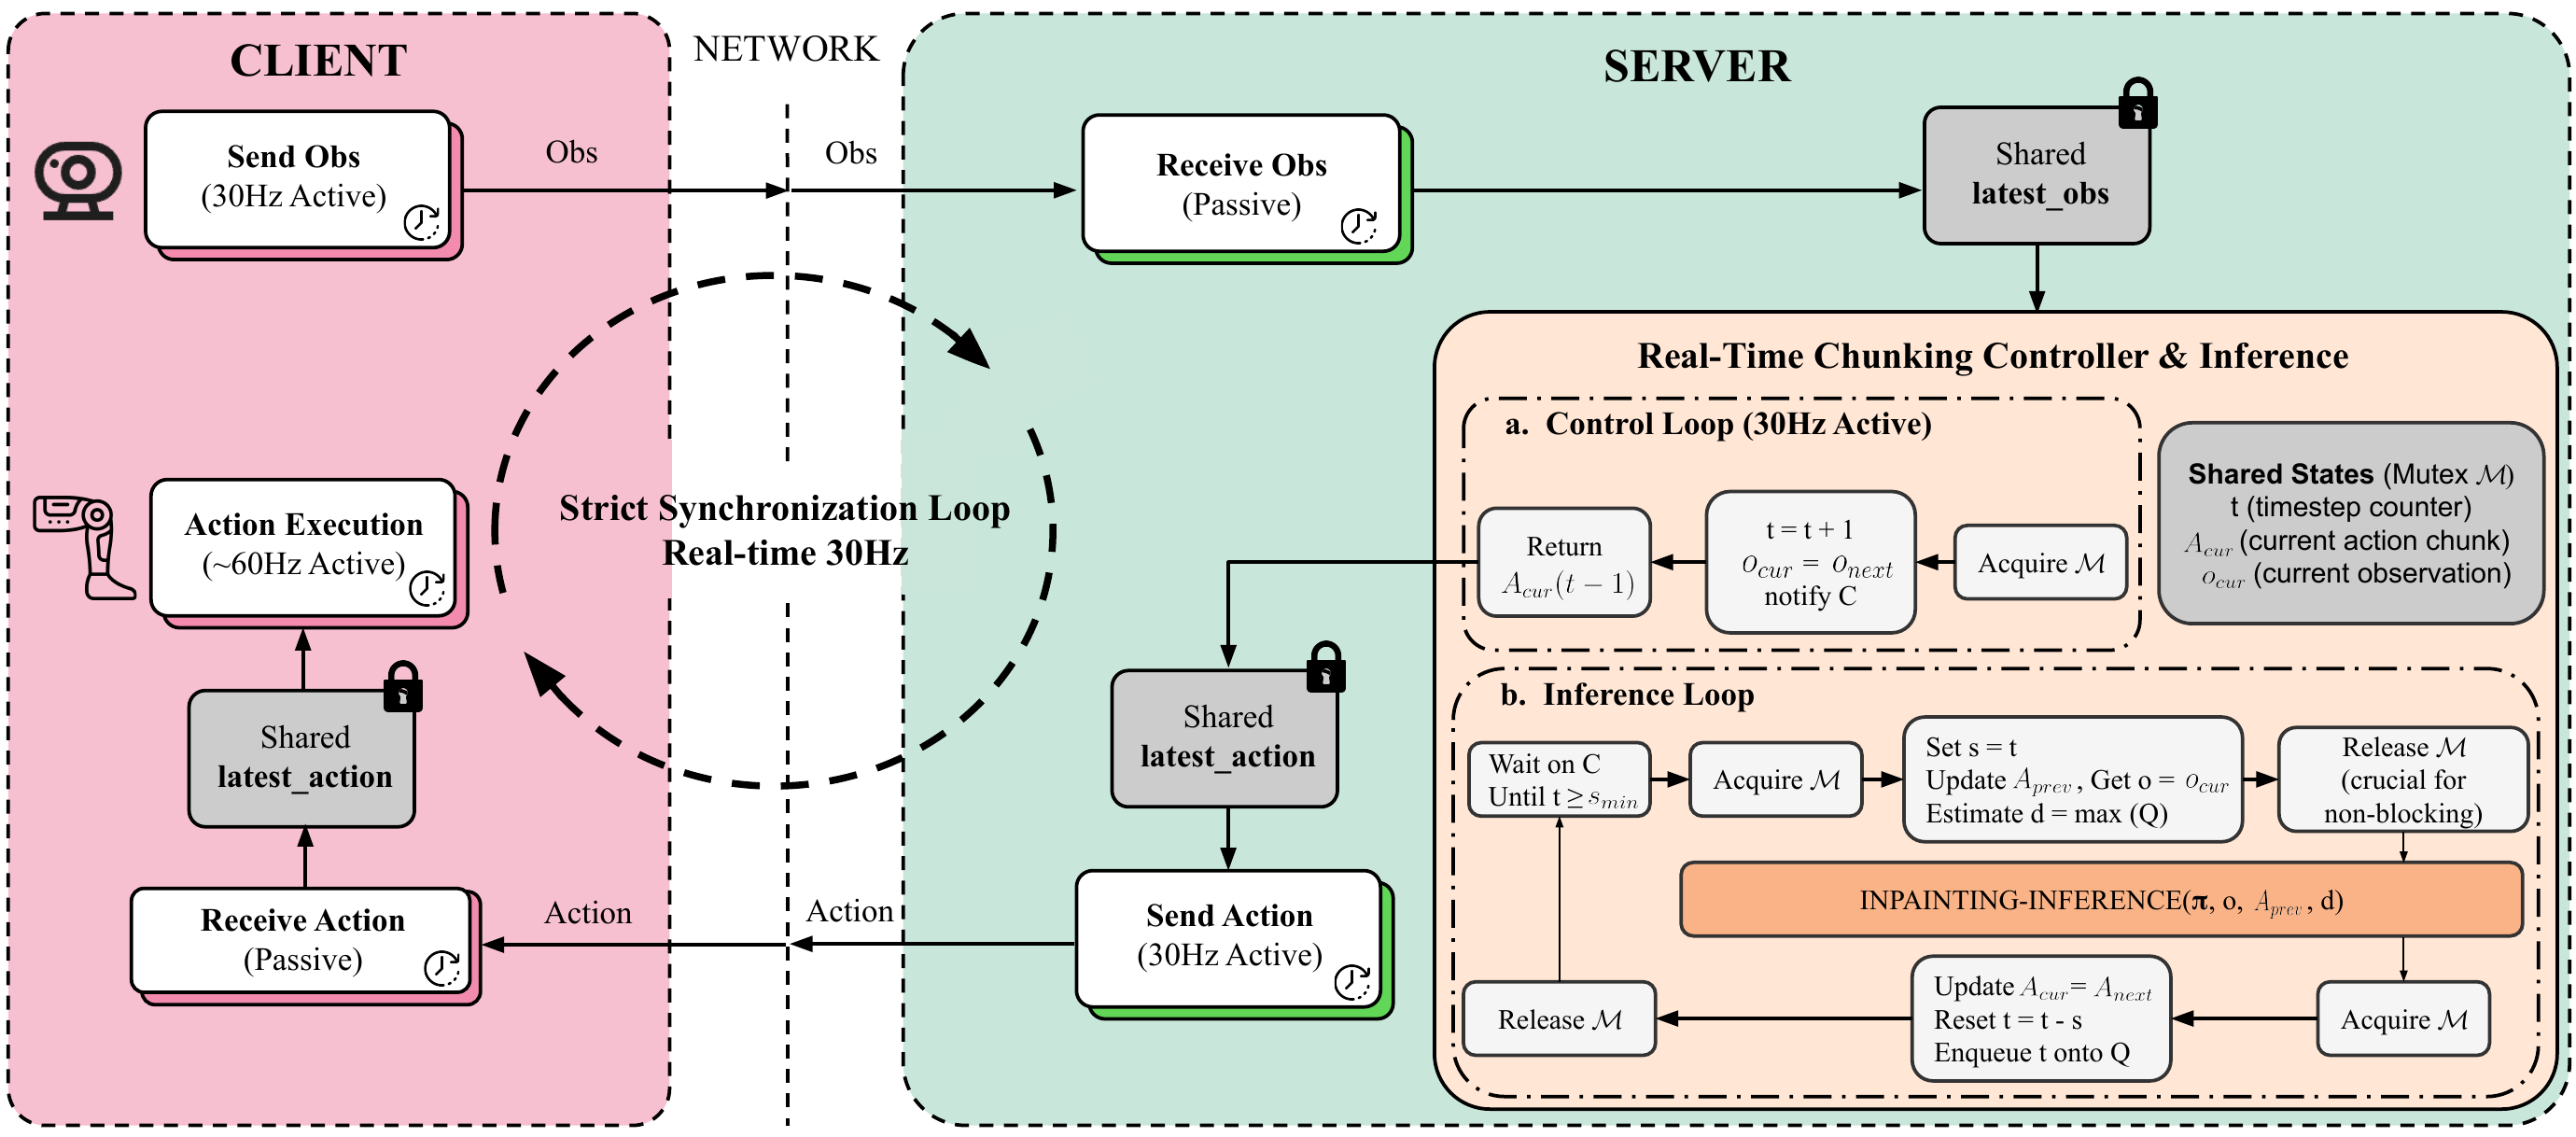
Psi0 Hands-On (5): Inference & Evaluation
13 min read
Part 6/6
What Is an Ablation Study? Explained with Psi0
15 min read
Simplevla Rl
· 11 parts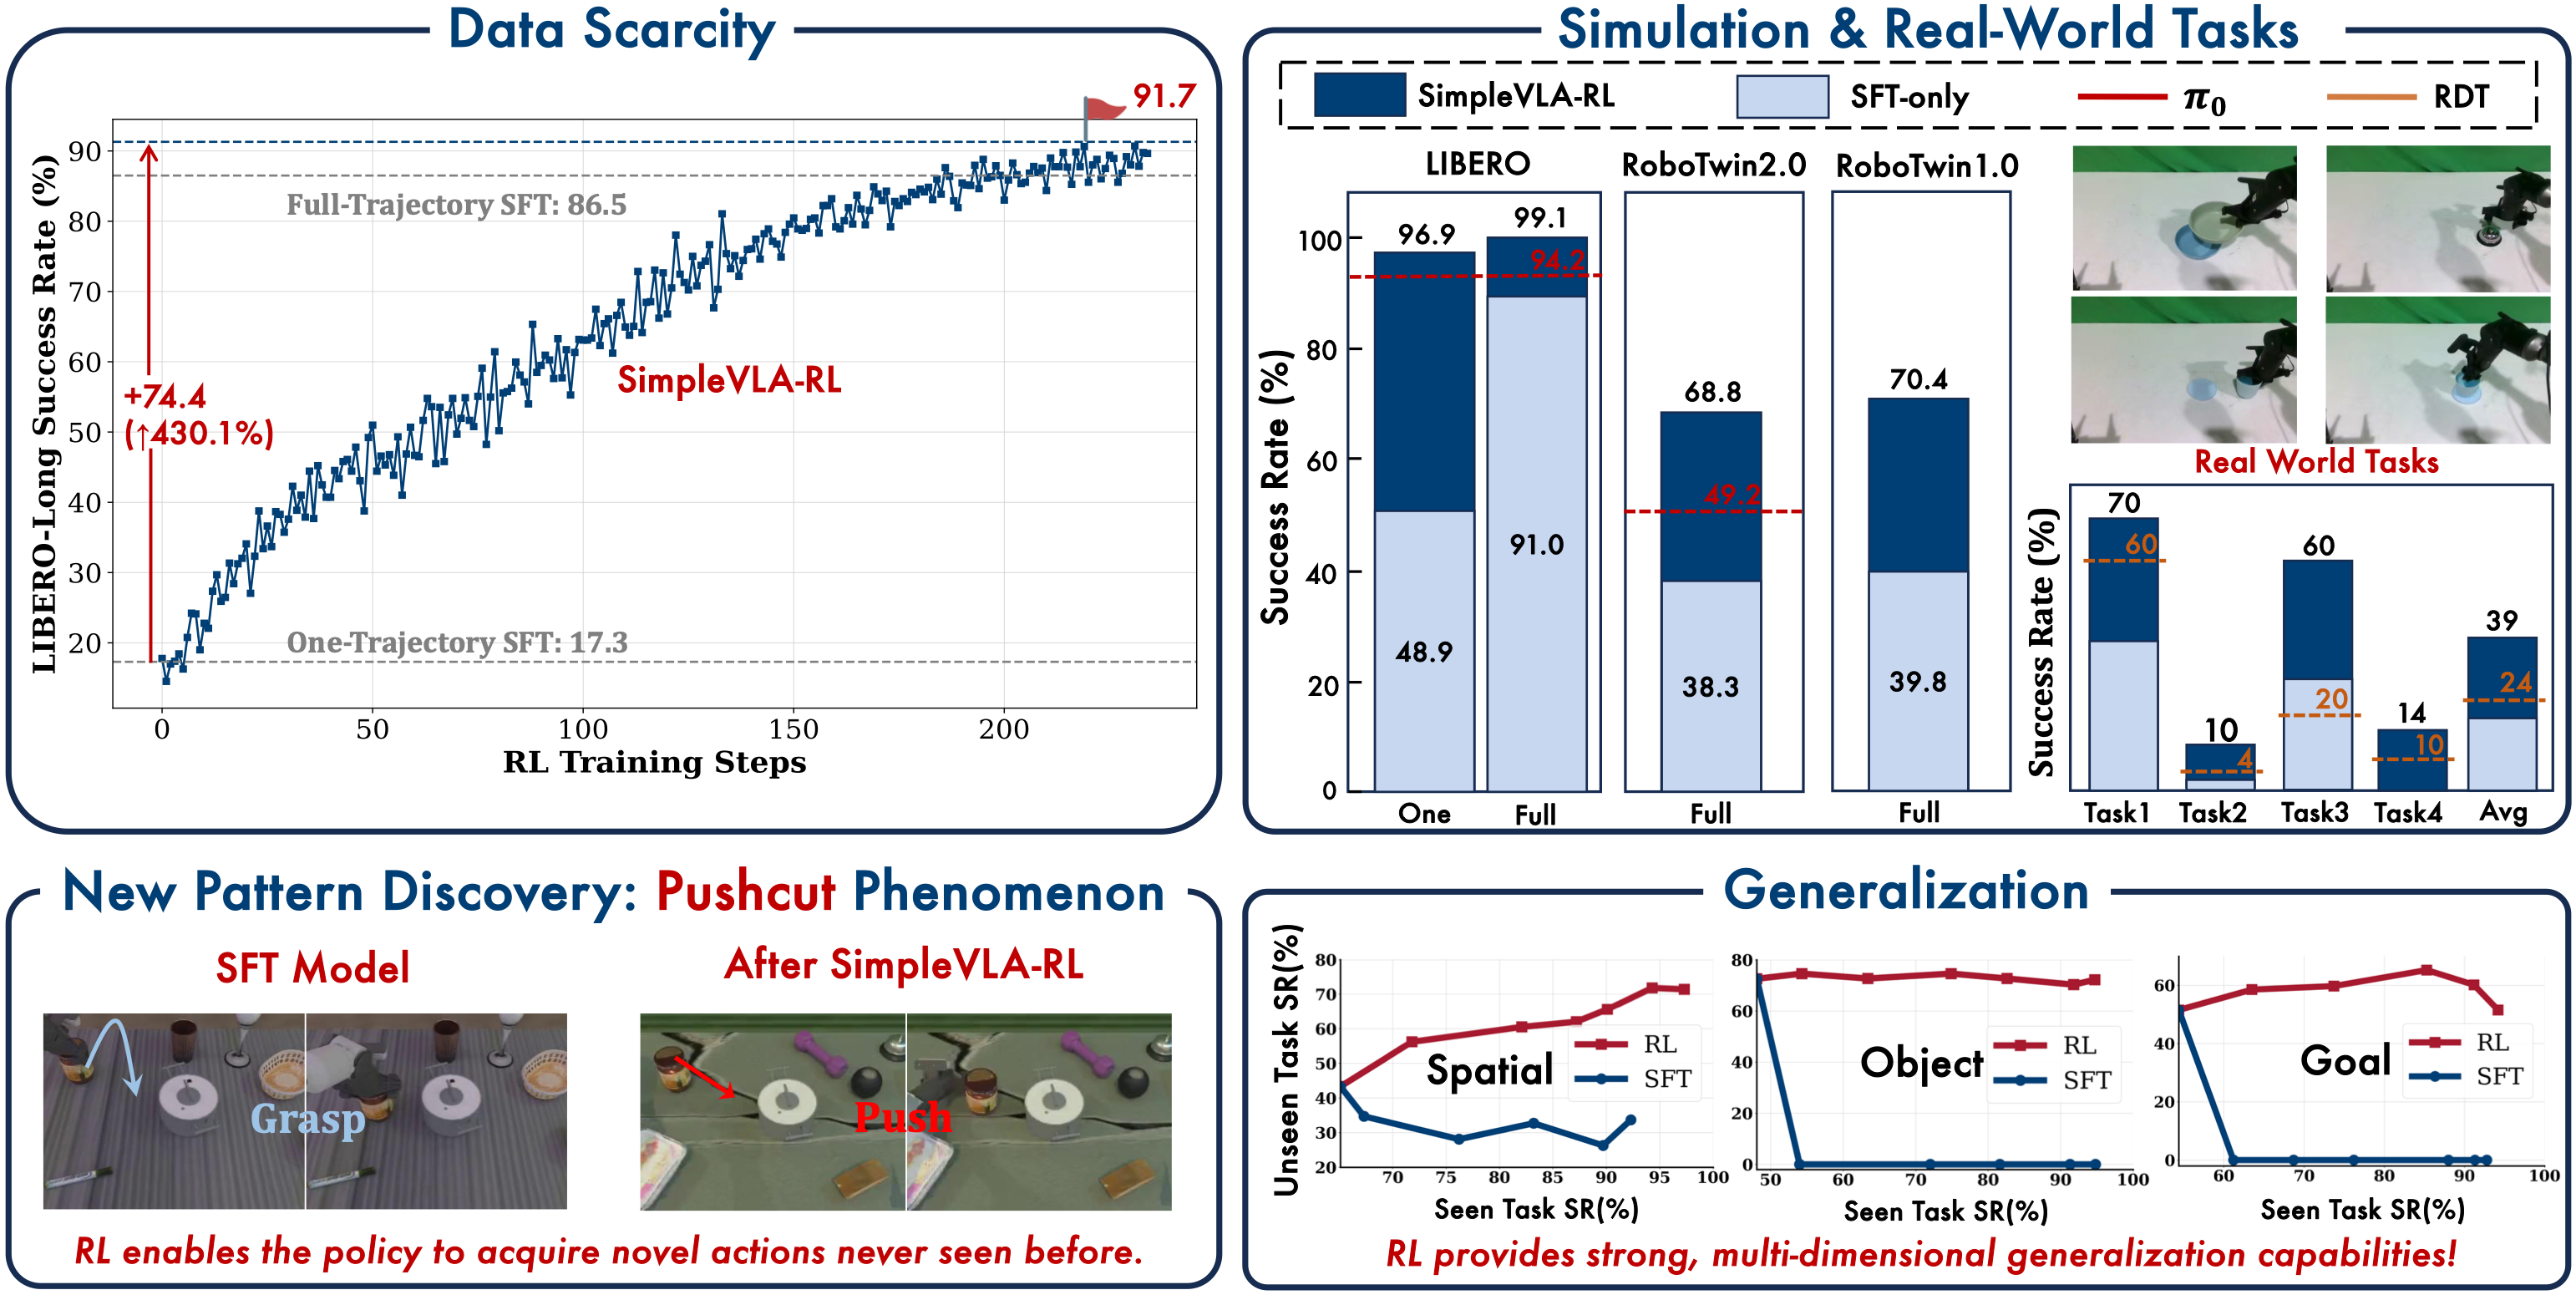
Part 1/11
SimpleVLA-RL (1): Overview & Key Ideas
9 min read
Part 2/11
SimpleVLA-RL (2): Architecture & Algorithm
14 min read
Part 3/11
SimpleVLA-RL (3): Setup & Training
11 min read
Part 4/11
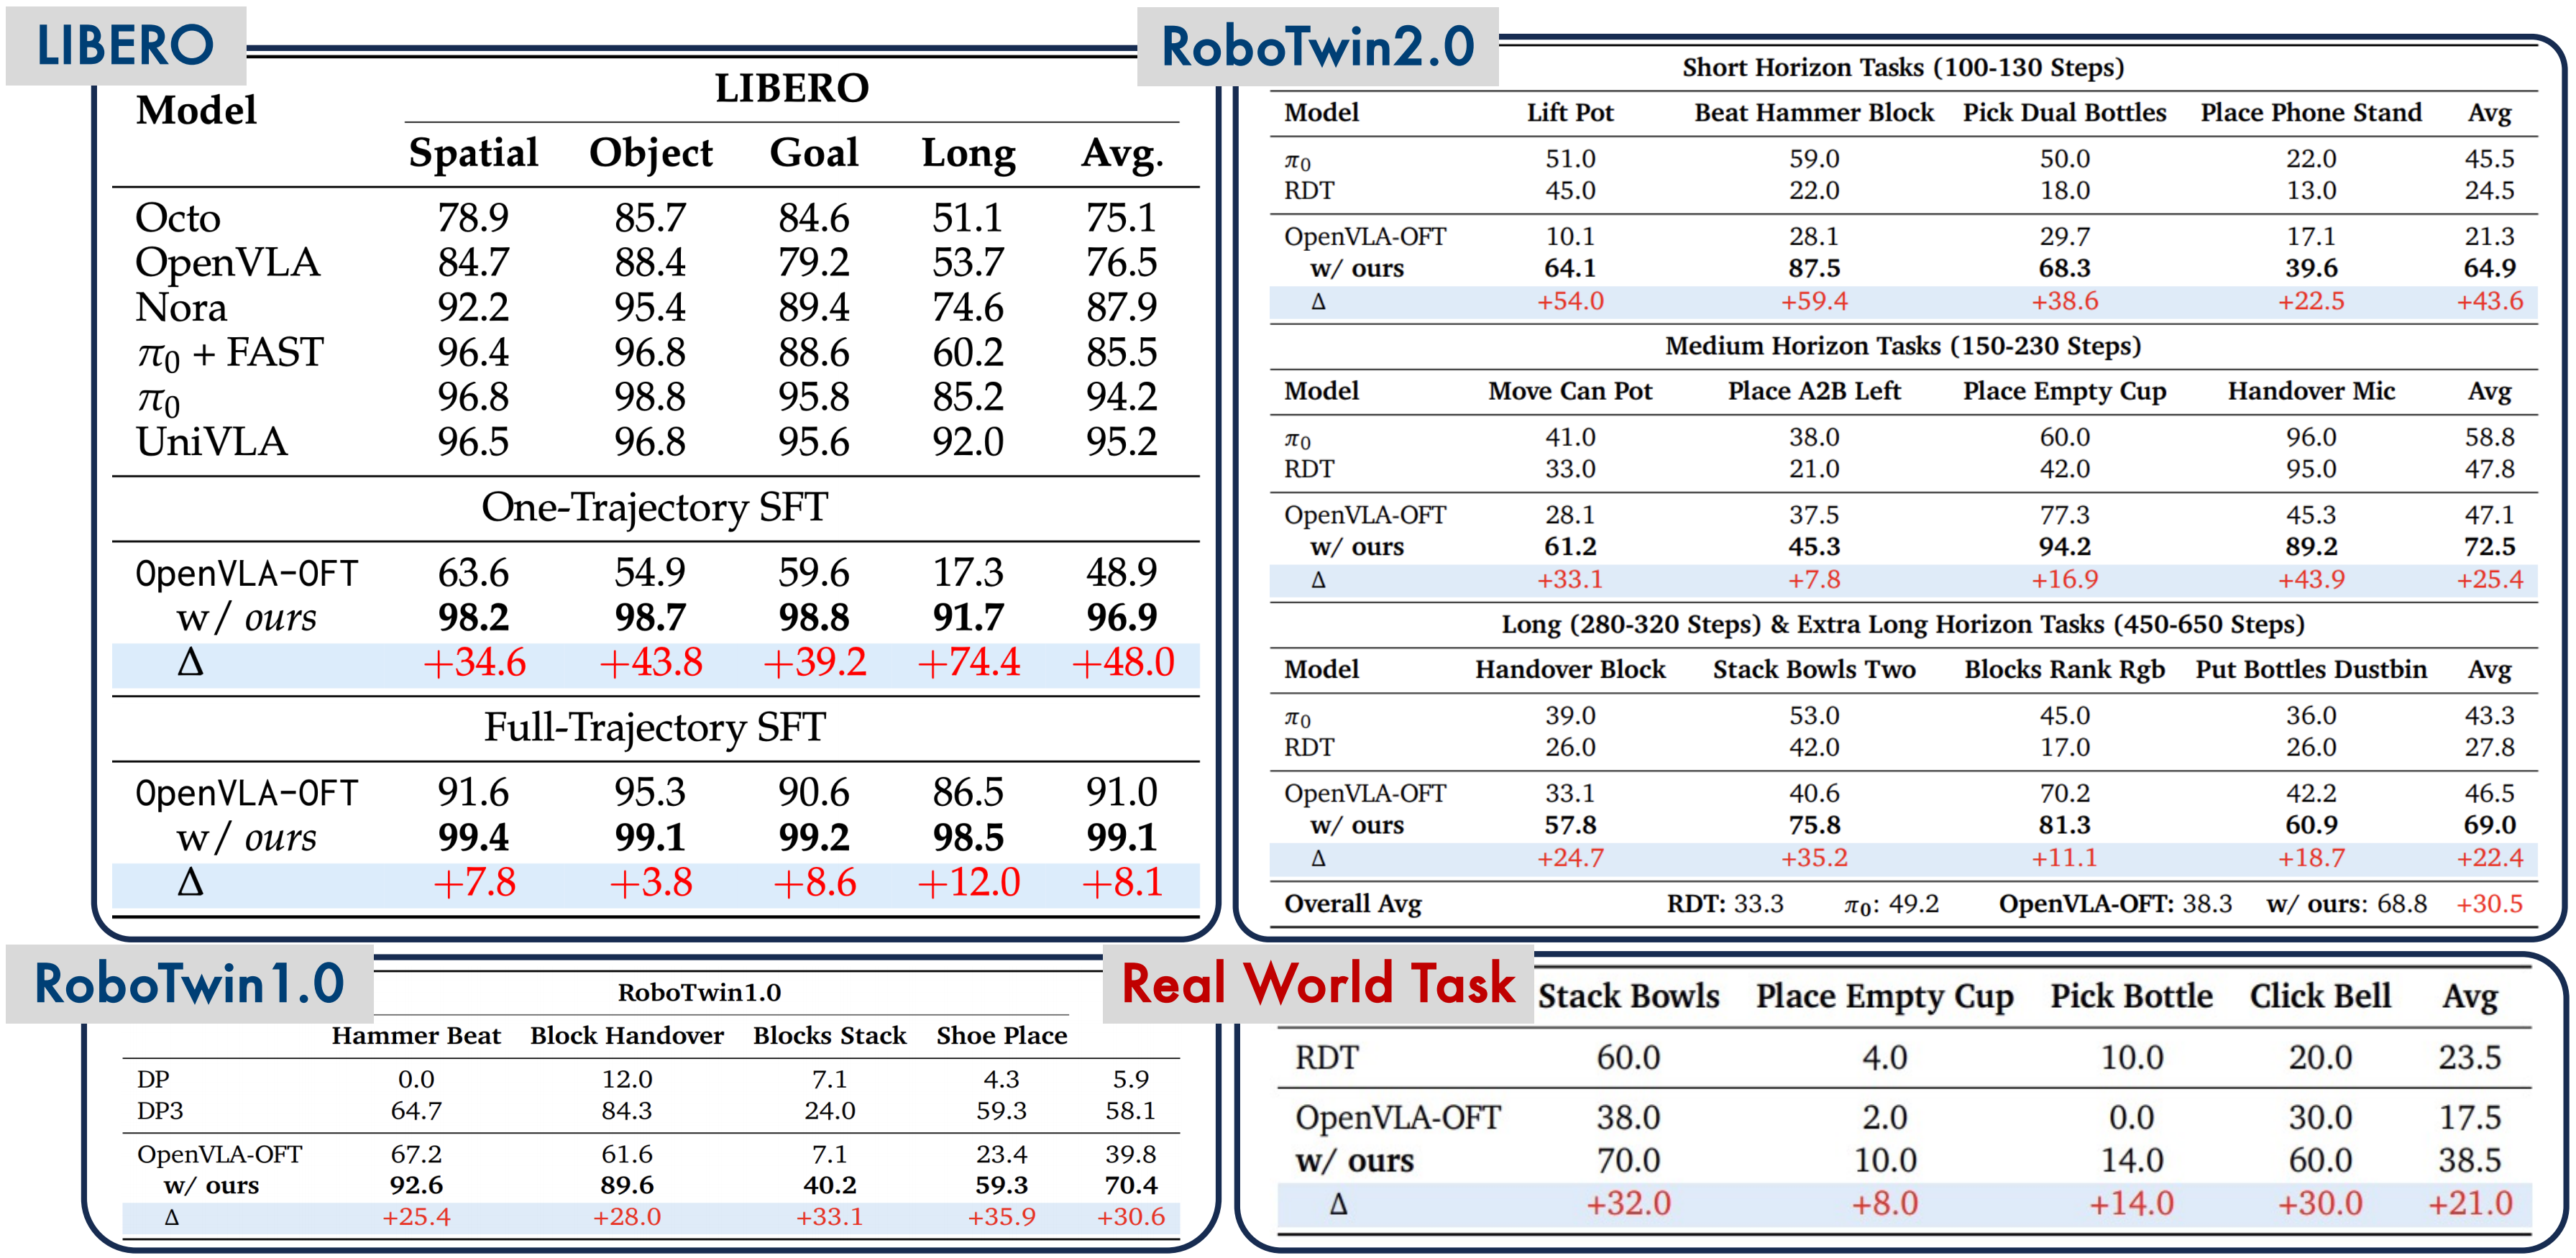
SimpleVLA-RL (4): Results & Key Takeaways
12 min read
Whole-body VLA
Part 5/11
SimpleVLA-RL (5): Comparison with LeRobot
11 min read
Part 6/11
SimpleVLA-RL (6): OpenArm — Training Roadmap
12 min read
Whole-body VLA
Part 7/11
SimpleVLA-RL (7): Collecting Data for OpenArm
14 min read
Part 8/11
SimpleVLA-RL (8): Training & Deploying on OpenArm
13 min read
Part 9/11
SimpleVLA-RL (9): OpenArm Simulation & Data Collection
17 min read

Part 10/11
SimpleVLA-RL (10): SFT & RL Training for OpenArm
15 min read

Part 11/11
SimpleVLA-RL (11): Sim-to-Real Transfer for OpenArm
16 min read
RL Locomotion for Humanoid Robots
· 10 parts
Part 1/10
RL Locomotion for Humanoids: Fundamentals & Environment Setup
10 min read
Part 2/10
Reward Engineering for Bipedal Walking: The Art of Reward Design
10 min read

Part 3/10
Unitree G1: Training a Walking Policy from Scratch in Isaac Lab
9 min read

Part 4/10
Unitree G1: Terrain Adaptation & Robust Walking
8 min read
Part 5/10
Unitree H1: Full-size Humanoid Locomotion Training
8 min read
Part 6/10
Unitree H1: Running, Turning & Dynamic Motions
8 min read
Part 7/10
Unitree H1-2: Enhanced Locomotion with New Hardware
7 min read
Part 8/10
Loco-Manipulation: Walking While Carrying & Manipulating Objects
7 min read
Part 9/10
Humanoid Parkour: Jumping, Climbing & Obstacle Courses
7 min read
Humanoid
Part 10/10
Sim-to-Real for Humanoids: Deployment Best Practices
9 min read
RL for Robot Manipulation
· 8 partsManipulation
Part 1/8
RL for Manipulation: MDP, Reward Design & Environment Setup
12 min read
Manipulation
Part 2/8
Grasping with RL: Stable Grasp & Object Variety
11 min read
Part 3/8
RL Force Control: Balancing a Cup of Water
10 min read
Manipulation
Part 4/8
Precision Pick-and-Place: Position & Orientation Control
7 min read
Manipulation
Part 5/8
Carrying & Transporting Objects: Stability During Motion
8 min read
Part 6/8
Contact-Rich Manipulation: Assembly, Insertion & Peg-in-Hole
7 min read
Manipulation
Part 7/8
Tool Use: Teaching Robots to Use Tools with RL
7 min read
Manipulation
Part 8/8
Multi-Step Manipulation: Curriculum Learning for Long-Horizon Tasks
8 min read
Simulation for Robotics
· 6 partsSimulation
Part 1/6
Simulation for Robotics: MuJoCo vs Isaac Sim vs Gazebo
9 min read
Part 2/6
Getting Started with MuJoCo: From Installation to First Robot Simulation
10 min read
Part 3/6
NVIDIA Isaac Lab: GPU-Accelerated RL Training from Zero
11 min read
Part 4/6
Domain Randomization: The Key to Sim-to-Real Transfer
9 min read
Simulation
Part 5/6
Sim-to-Real Pipeline: From Training to Real Robot
15 min read
Simulation
Part 6/6
Digital Twins and ROS 2: Simulation in Manufacturing
10 min read
ROS 2 A to Z
· 7 parts
Part 1/7
ROS 2 A to Z Part 1: Setup and First Node
9 min read
Part 2/7
ROS 2 A to Z (Part 2): Topics, Services, and Actions
9 min read
Part 3/7
ROS 2 A to Z (P3): Parameters, Launch, Lifecycle
7 min read
Part 4/7
ROS 2 A to Z (P4): TF2, URDF and RViz2
7 min read
Part 5/7
ROS 2 A to Z (P5): ros2_control and Hardware
11 min read
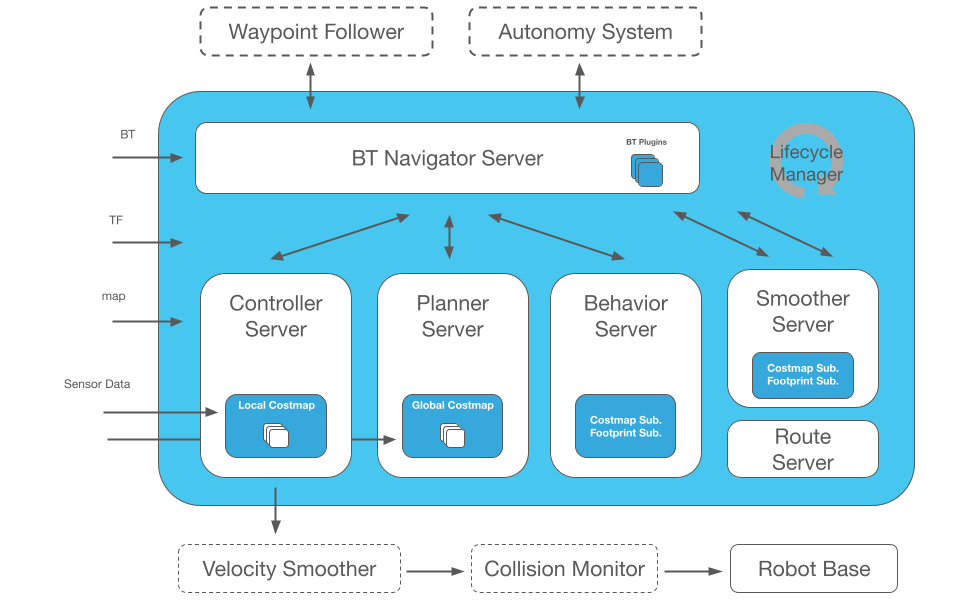
Part 6/7
ROS 2 A to Z (P6): Nav2 — Autonomous Navigation
10 min read
Part 7/7
ROS 2 A to Z (P7): Simulation, rosbag2 and Debug
8 min read
Robot Manipulation Masterclass
· 7 parts
Part 1/7
Robot Grasping 101: Analytical to Learning-Based
8 min read
Part 2/7
Imitation Learning for Manipulation: BC, DAgger, ACT
8 min read
Part 3/7
Diffusion Policy in Practice: From Theory to Code
7 min read
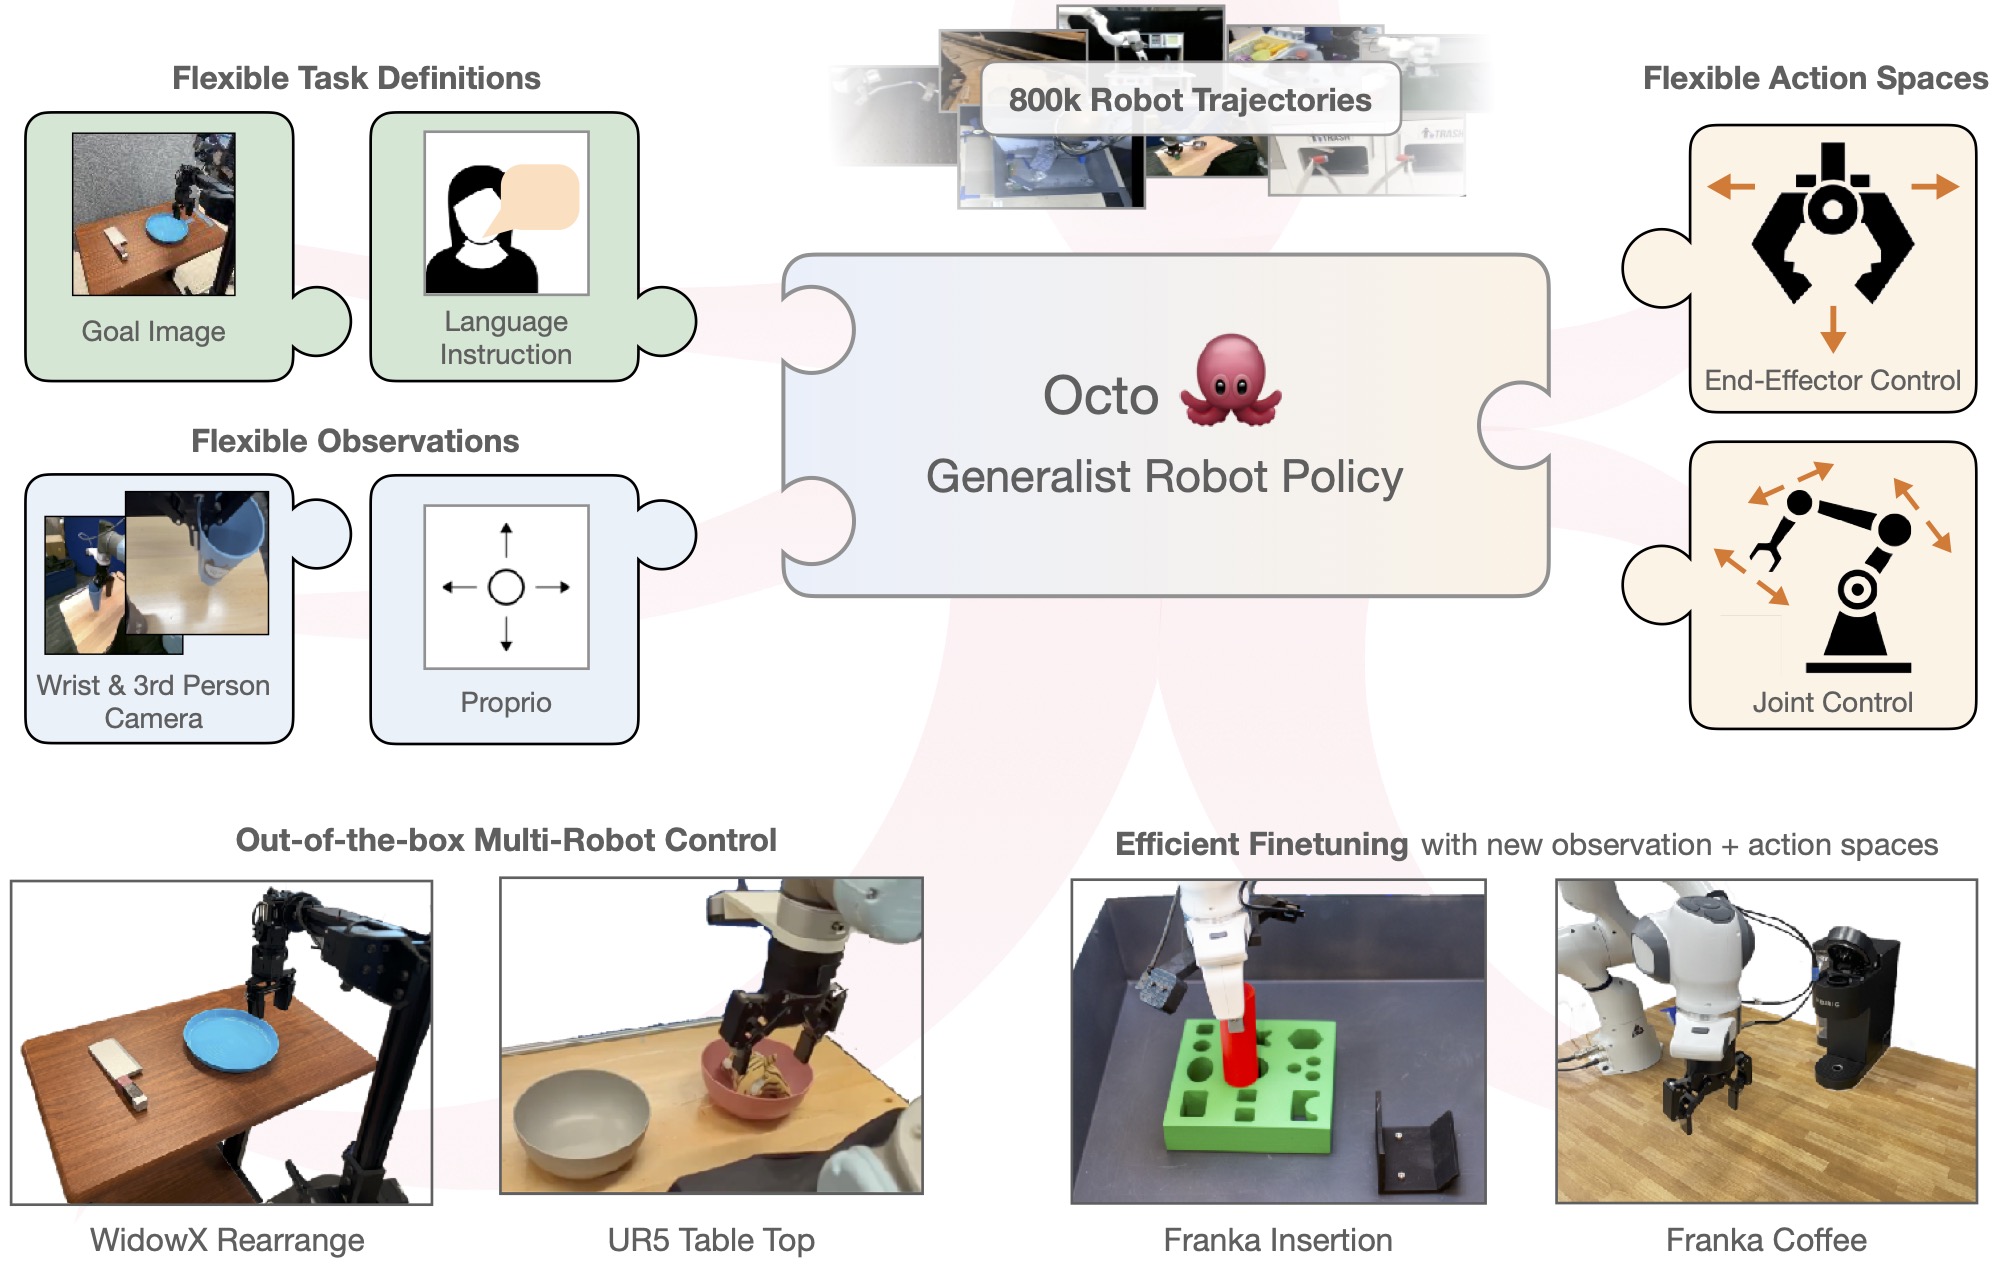
Part 4/7
VLA for Manipulation: RT-2, Octo, pi0 in Practice
8 min read
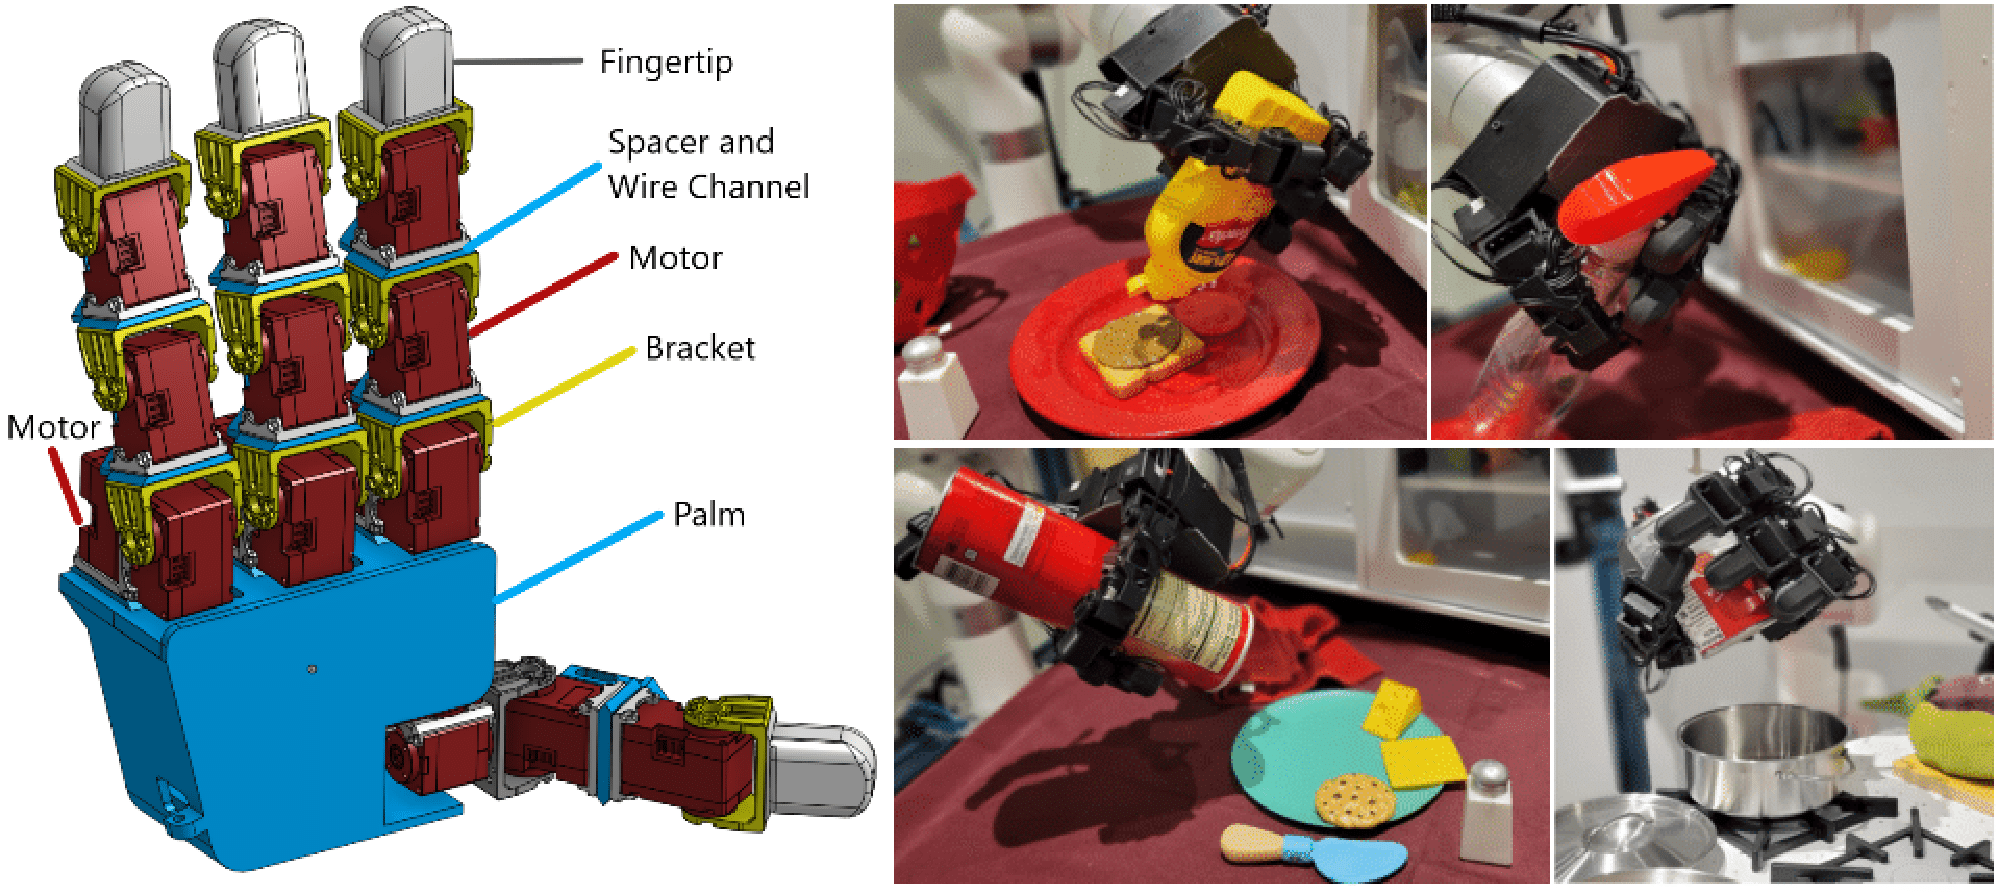
Part 5/7
Dexterous Manipulation: Teaching Robot Hands
7 min read
Part 6/7
Bimanual Manipulation: Teaching Robots to Use Both Arms
7 min read
Part 7/7
Building Manipulation Systems with LeRobot: Zero to Deploy
8 min read
Locomotion: Zero to Hero
· 7 parts
Part 1/7
Locomotion Basics: From ZMP to CPG
11 min read
Part 2/7
RL for Locomotion: PPO, Reward Shaping and Curriculum
10 min read
Part 3/7
Quadruped Locomotion: legged_gym to Unitree Go2
10 min read
Part 4/7
Walk These Ways: Adaptive Locomotion One Policy
9 min read
Part 5/7
Robot Parkour: Jumping and Climbing with RL
9 min read

Part 6/7
Bipedal Walking: Controlling 2-Legged Robots with RL
10 min read
Part 7/7
Sim-to-Real for Locomotion: Reality and Experience
12 min read
Humanoid Robot Engineering
· 6 partsHumanoid
Part 1/6
Humanoid Robots 2026: Complete Platform Overview
8 min read
Humanoid
Part 2/6
Humanoid Control Basics: IK to Task-Space Control
8 min read
Part 3/6
Whole-Body MPC: Real-Time Full-Body Control
6 min read
Part 4/6
RL for Humanoid: From Humanoid-Gym to Sim2Real
8 min read

Part 5/6
Loco-Manipulation: Walking and Manipulating Simultaneously
8 min read
Humanoid
Part 6/6
The Future of Humanoids: Opportunities for Engineers
9 min read
Modern Navigation
· 5 parts
Part 1/5
SLAM A to Z: LiDAR, Visual and How Robots Localize
8 min read
Part 2/5
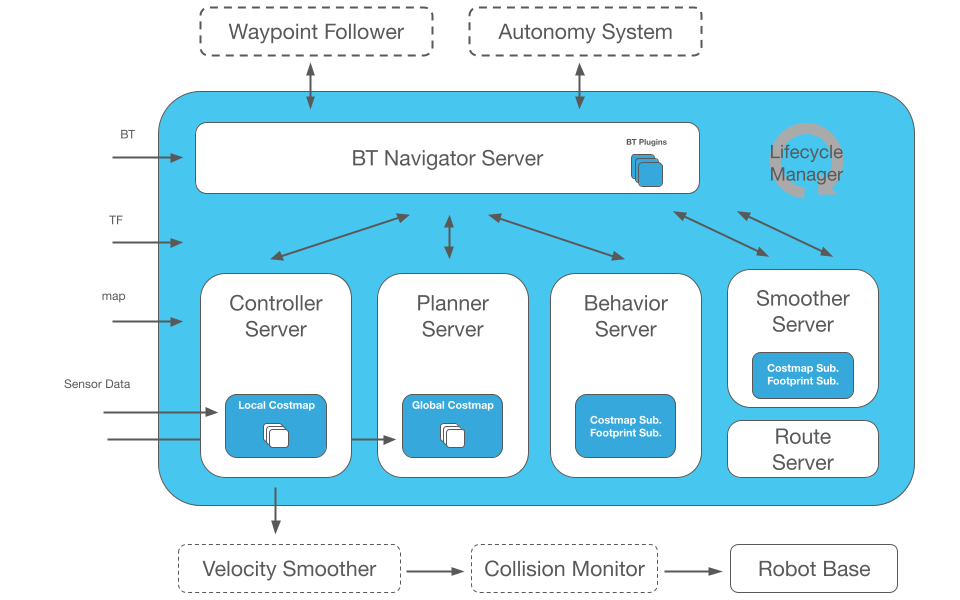
ROS 2 Nav2: Complete Navigation for AMR
7 min read
Part 3/5
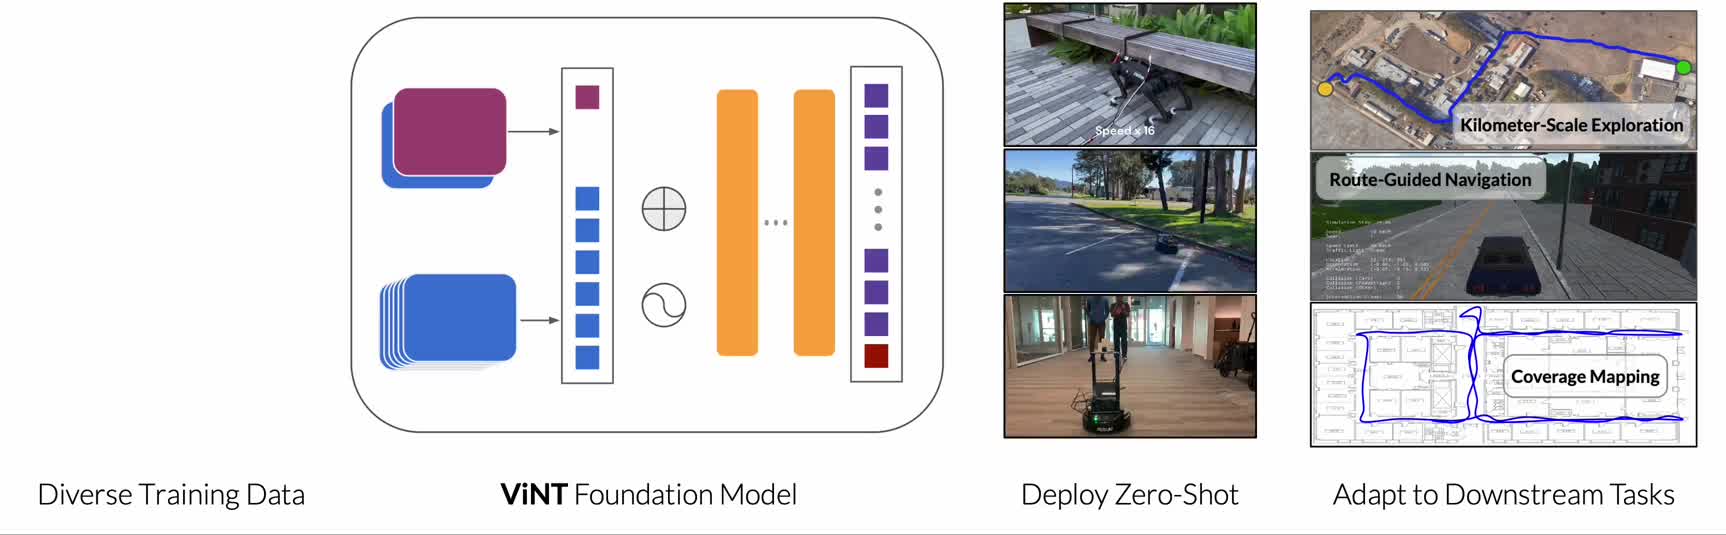
Learning-based Navigation: GNM, ViNT and NoMaD
8 min read
Part 4/5
Vision-Language Navigation: Robot Following Instructions
8 min read
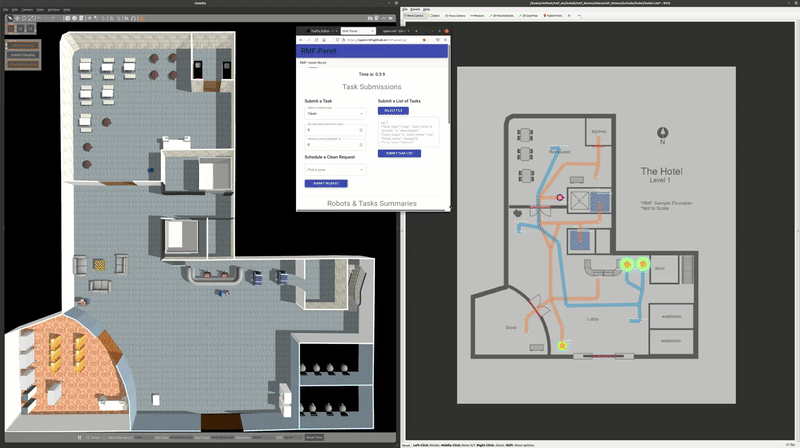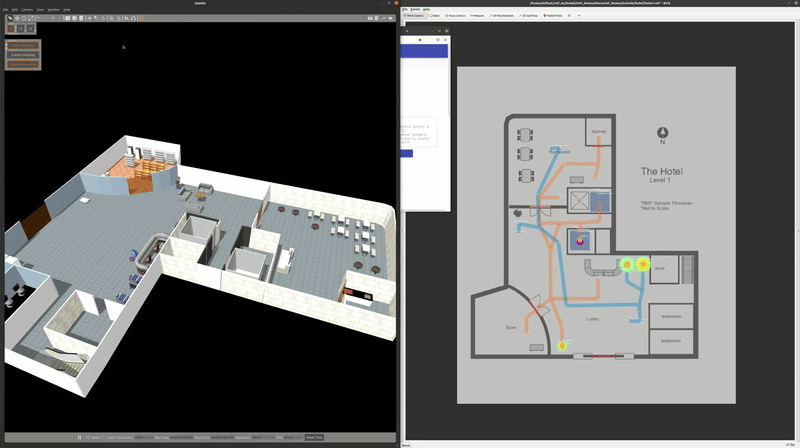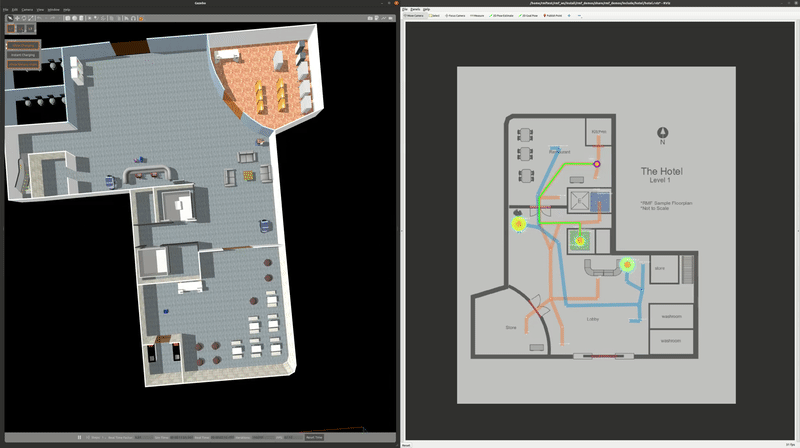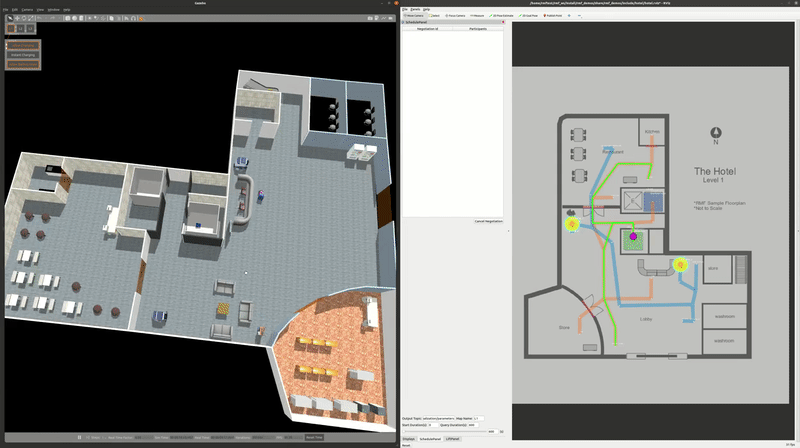
Part 5/5
Outdoor Navigation and Multi-Robot Coordination
10 min read
Trending
- 1
SimpleMemVLA: Native Video Memory for Long-Horizon VLA
11 min read - 2
FluxVLA Engine: Hands-On Guide to the One-Stop VLA Platform
9 min read - 3
DSPv2: Dense Policy for Whole-Body Mobile Manipulation
14 min read - 4
ADAS Validation: ISO 26262, SOTIF, and Euro NCAP 2026
17 min read - 5
IntentVLA: Fixing Observation Aliasing in Robot Manipulation
13 min read