Other
Everything that does not fit a single pillar — tooling, infrastructure, and cross-cutting robotics engineering.
19 articles in this topic
How to Monitor ROS 2 Robots Remotely: Complete 2026 Guide
Step-by-step tutorial to monitor ROS 2 robots from anywhere — battery, CPU, status, heartbeat, alerts. Working code, 10-minute setup. Free for 3 robots.
Formant Alternatives: 5 Robot Fleet Platforms for 2026
Looking for a Formant alternative in 2026? Honest comparison of 5 fleet management platforms — pricing, ROS 2 support, features, and which fits your team.
AWS RoboMaker Alternatives 2026: 5 Platforms for ROS 2 Teams
AWS RoboMaker shut down in September 2025. Here are the 5 best alternatives for ROS 2 fleet management in 2026 — honest comparison, pricing, migration guide.
InOrbit Alternatives 2026: 5 AMR Fleet Platforms Compared
Looking for InOrbit alternatives for your AMR warehouse fleet? Honest comparison of 5 platforms — pricing, VDA 5050, MiR/OTTO support.
Freedom Robotics Alternatives 2026: 5 Fleet Platforms
Freedom Robotics works well, but maybe not for you. Honest comparison of 5 alternatives — pricing, ROS 2, free tier, live video. Includes VnRobo, Formant.
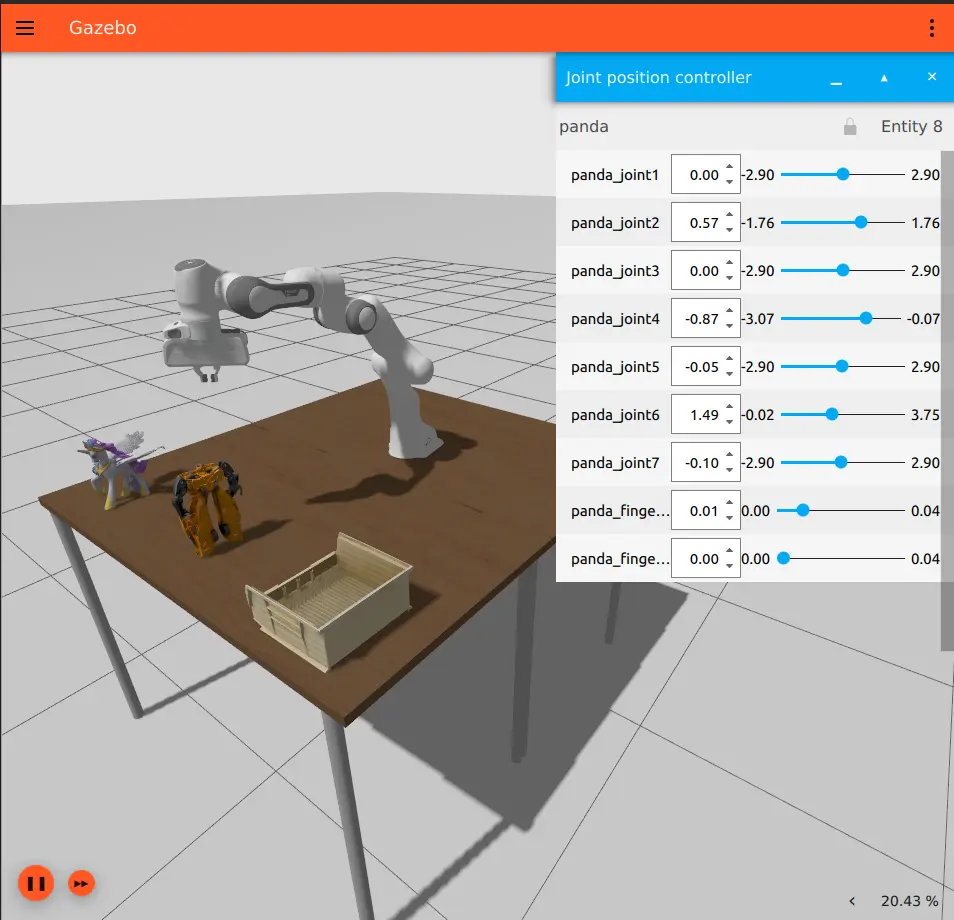
ROS 2 A to Z (P7): Simulation, rosbag2 and Debug
Simulate robots in Gazebo Harmonic, record/replay data with rosbag2 (MCAP), and master the ROS 2 debugging toolkit — the series finale for beginners (Jazzy, June 2026).
MQTT Protocol: Robot-to-Cloud Communication
MQTT protocol for robots and IoT — setting up brokers, QoS levels, topic design and sending telemetry from robots to cloud.

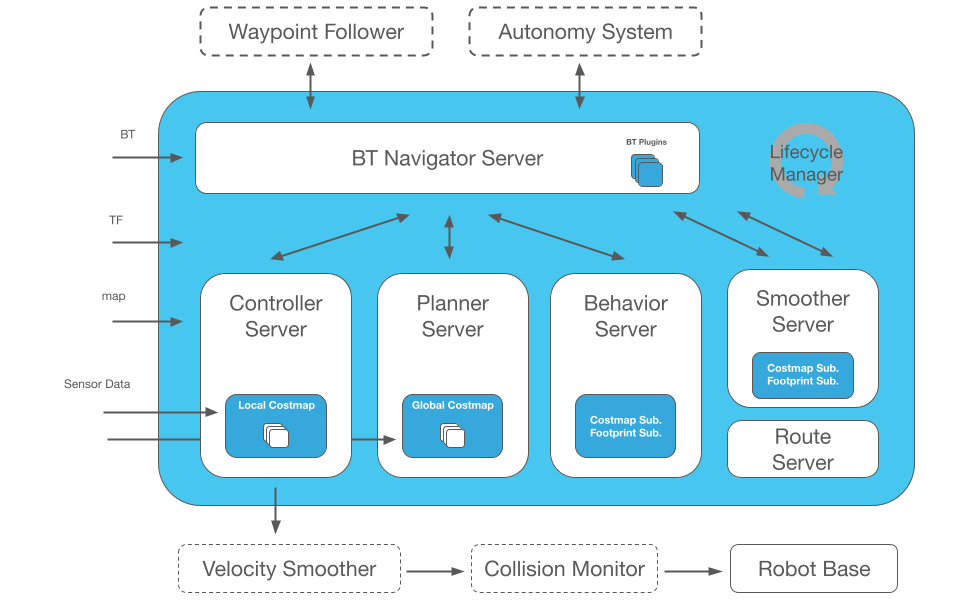
ROS 2 A to Z (P6): Nav2 — Autonomous Navigation
Configure the Nav2 stack for autonomous SLAM mapping and automatic movement — from simulation to reality (Jazzy, updated June 2026).
Writing Hardware Interface for ros2_control
Guide to creating custom hardware interface — connecting ros2_control to motor driver via serial/CAN bus.

ROS 2 A to Z (P5): ros2_control and Hardware
Connect ROS 2 to real hardware — write a C++ hardware interface for motor drivers and read encoders with the ros2_control framework (Jazzy, updated June 2026).

ROS 2 A to Z (P4): TF2, URDF and RViz2
Describe your robot's shape with URDF, track coordinate relationships between its parts with TF2, and visualize it all in RViz2 — C++ and Python examples (Jazzy, June 2026).

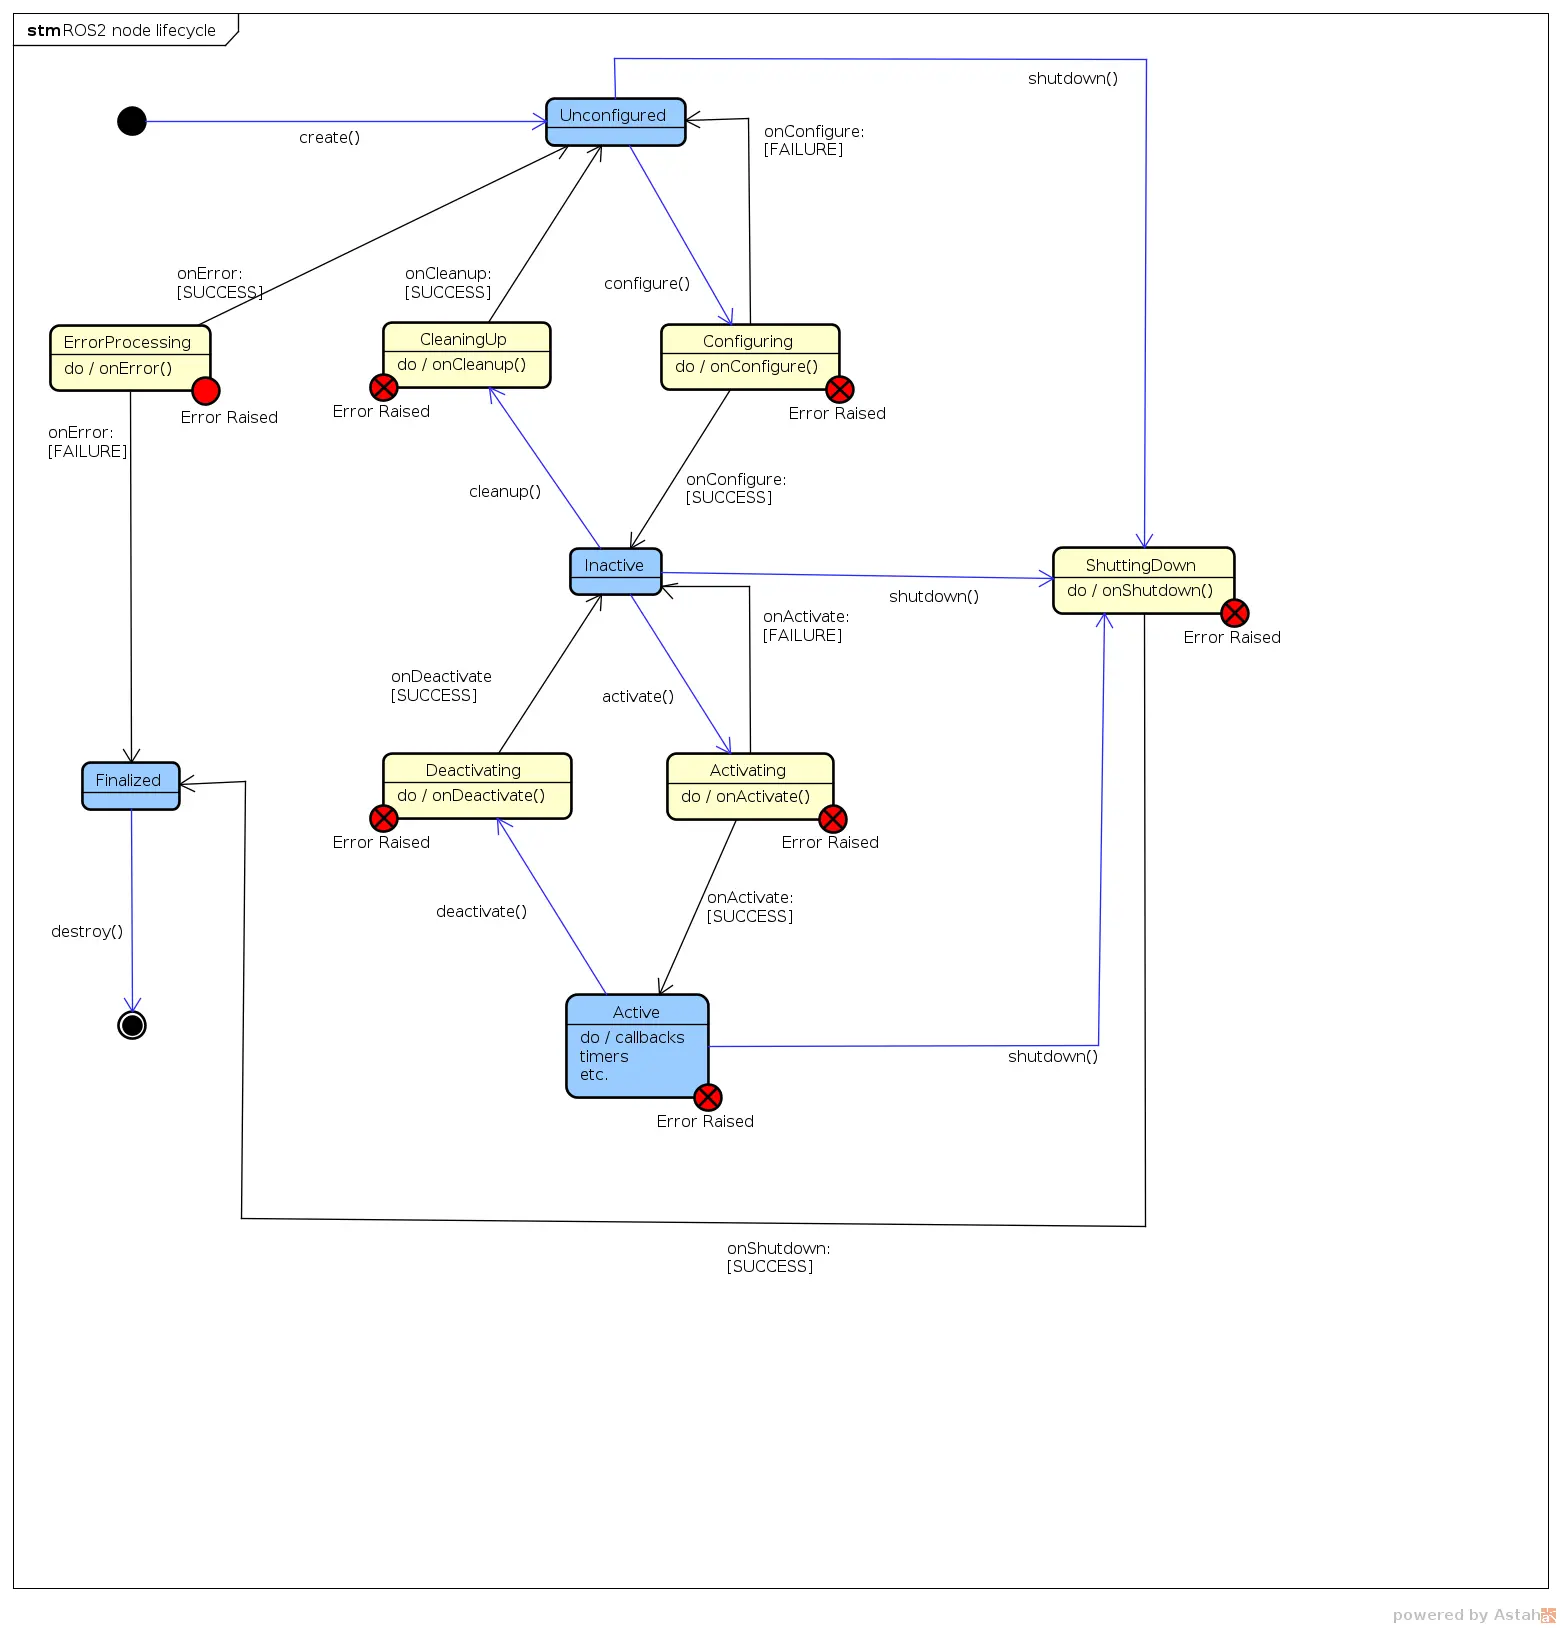
ROS 2 A to Z (P3): Parameters, Launch, Lifecycle
Configure nodes flexibly with Parameters, bring up a whole system with Launch files, and manage node lifecycle with Lifecycle nodes — full C++ and Python examples (Jazzy, June 2026).

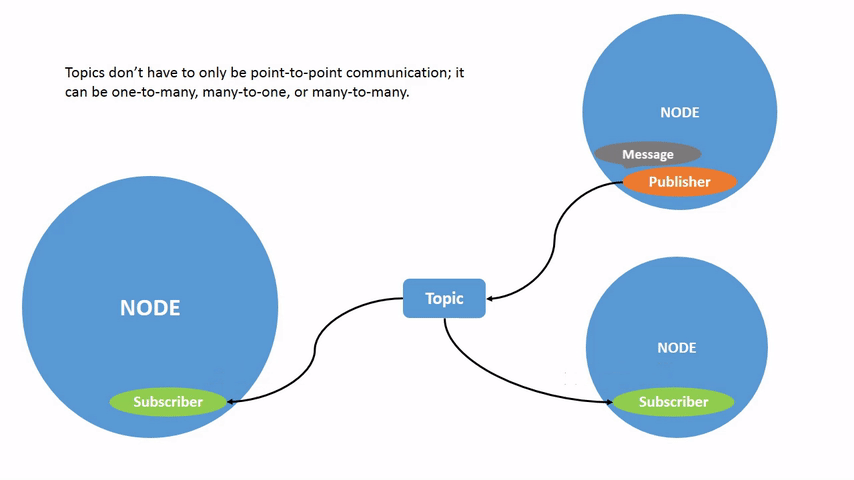
ROS 2 A to Z (Part 2): Topics, Services, and Actions
Master the 3 core communication primitives in ROS 2 — when to use Topic, Service, or Action for your robot.
PID Control for Robots: From Theory to Practice
Deep understanding of PID controller — tuning Kp Ki Kd, anti-windup, and practical DC motor control with Python.

ROS 2 A to Z Part 1: Setup and First Node
Install ROS 2 Jazzy on Ubuntu 24.04 and write your first publisher/subscriber node (Python & C++) — the starting point for robotics engineers (updated June 2026).

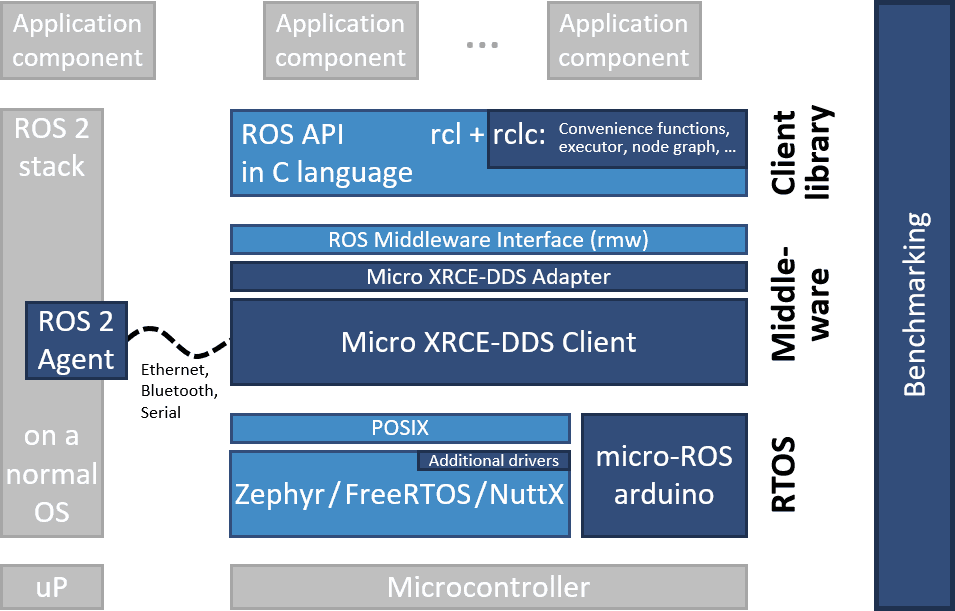
Micro-ROS: Connecting Microcontrollers to ROS 2 Ecosystem
Micro-ROS brings ROS 2 to microcontrollers like ESP32 and STM32, extending ROS 2 ecosystem down to embedded layer.
Deploy IoT Applications with Docker and Docker Compose
Guide to deploying IoT applications with Docker and Docker Compose on edge devices — consistent packaging, management and easy maintenance.
Introduction to ROS 2: Next-Generation Robot Programming Framework
ROS 2 provides powerful distributed architecture, real-time support, and security — ideal for industrial and autonomous robots.
Siemens S7-1200 PLC Programming: From Basics to Application
Overview of PLC programming with TIA Portal — from hardware configuration, ladder diagram writing to SCADA integration in automation systems.