All posts
Page 8 of 18

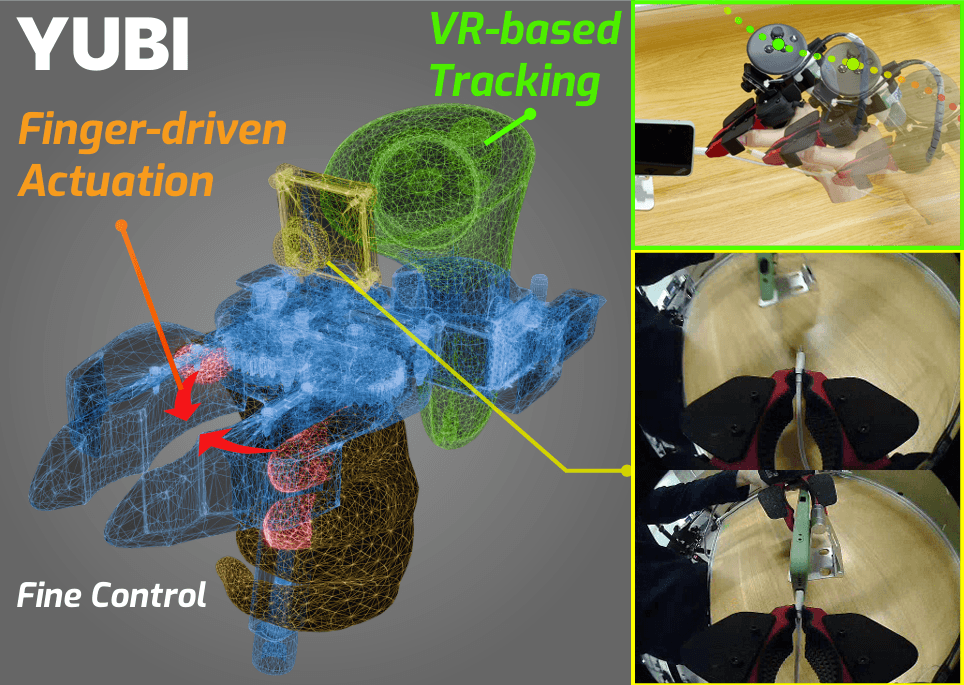
A beginner guide to building YUBI, collecting bimanual LeRobot data, and training/deploying VLA policies.

A practical guide to running Omega-QVLA for compressing GR00T N1.5 and pi0.5 to W4A4 for edge VLA manipulation.
A practical ProcVLM guide: turn robot videos into dense progress rewards for RL fine-tuning VLA manipulation policies.

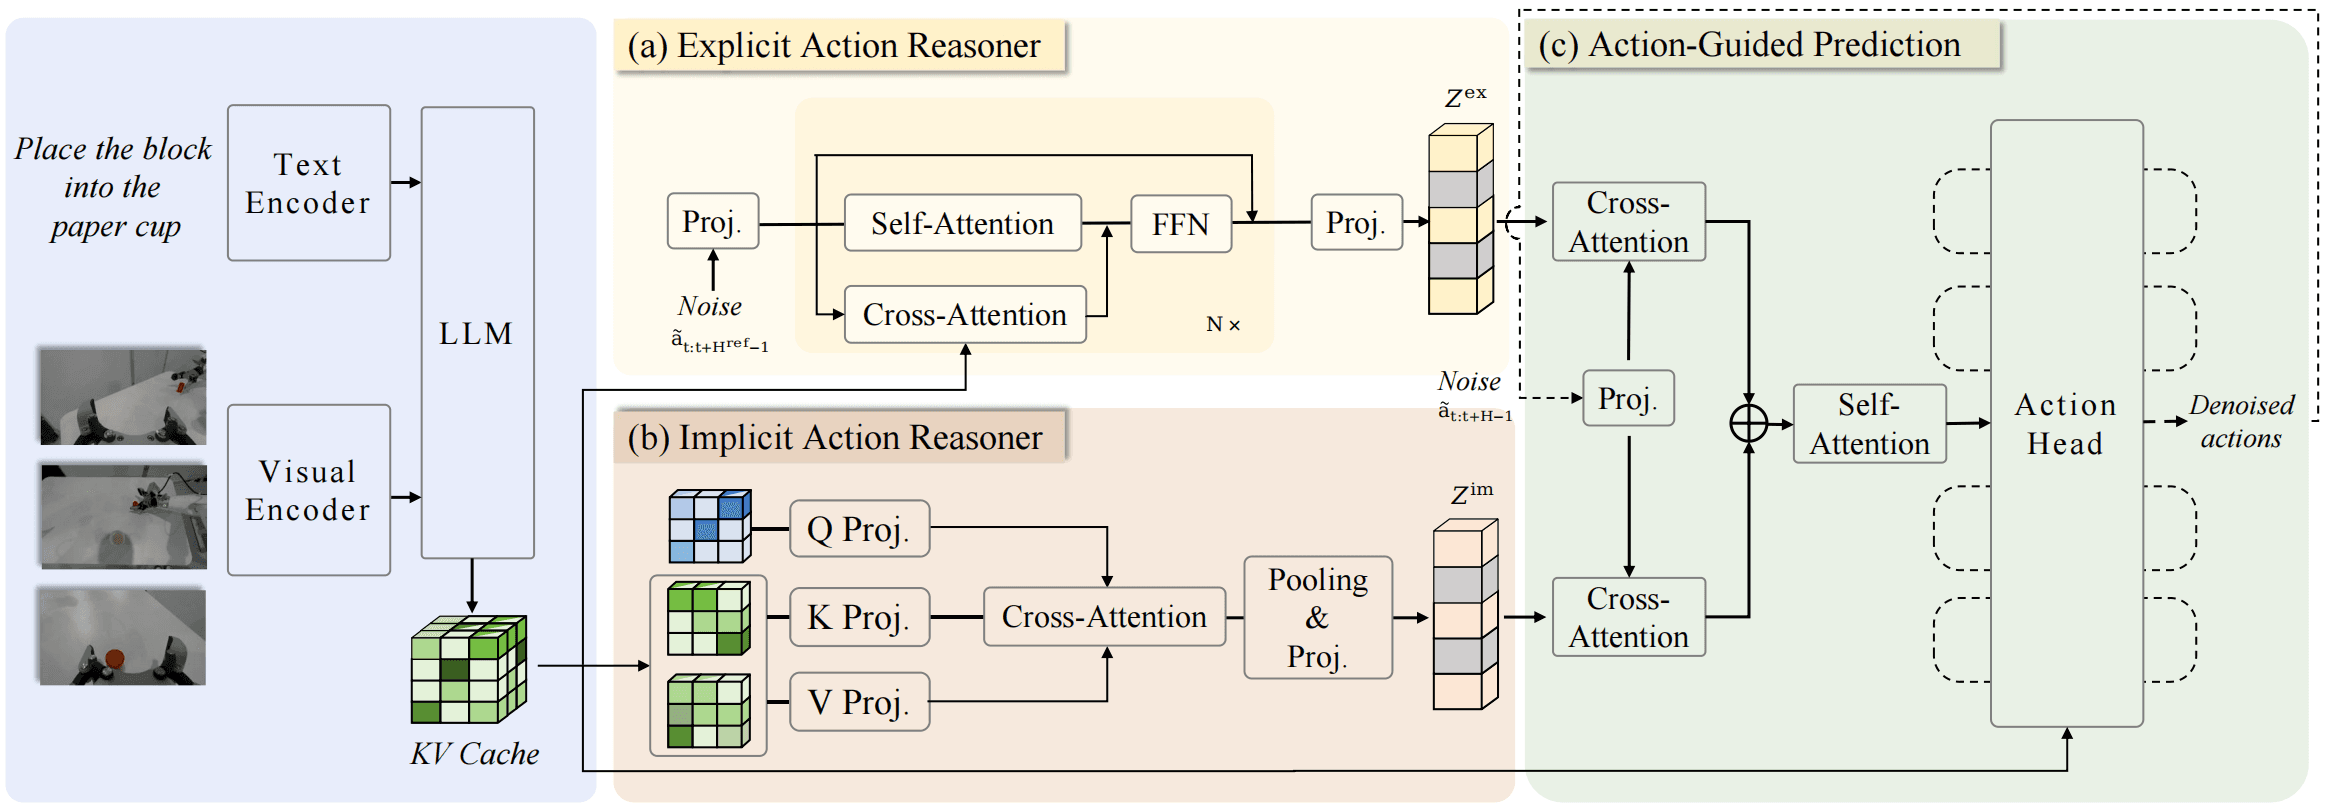
A beginner guide to ACoT-VLA: action chain-of-thought, EAR/IAR architecture, LeRobot-format data, training, inference, and results.
A comprehensive analysis of Vietnam's robot market in 2026 — from TOSY to foreign robots in FDI factories, from logistics AMRs to manufacturing arms. Opportunit

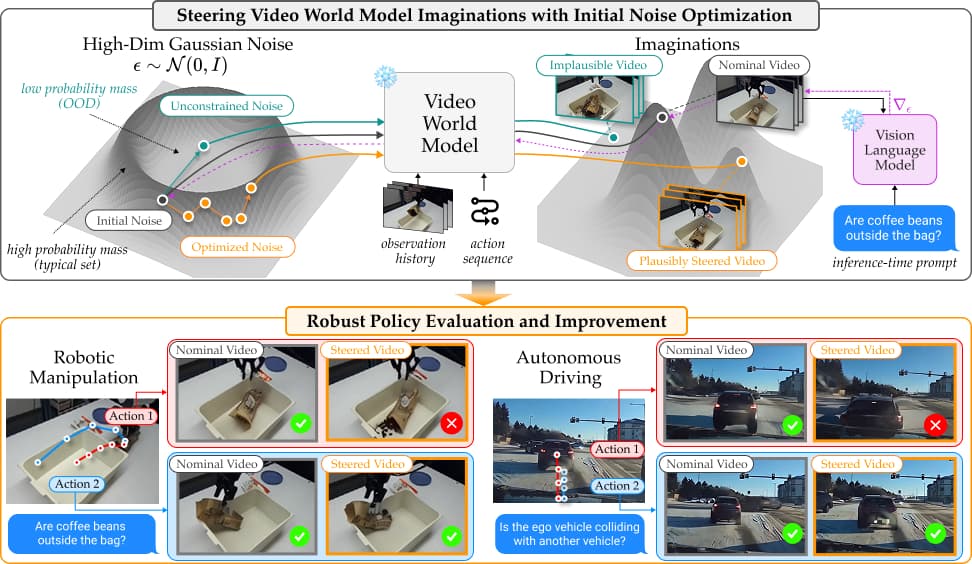
A beginner-friendly guide to StressDream: stress-test robot manipulation policies with video world models before deployment.
Train VIRAL and DoorMan for Unitree G1 in Isaac Lab: setup, teacher-student training, DAgger, GRPO, inference, and sim-to-real.

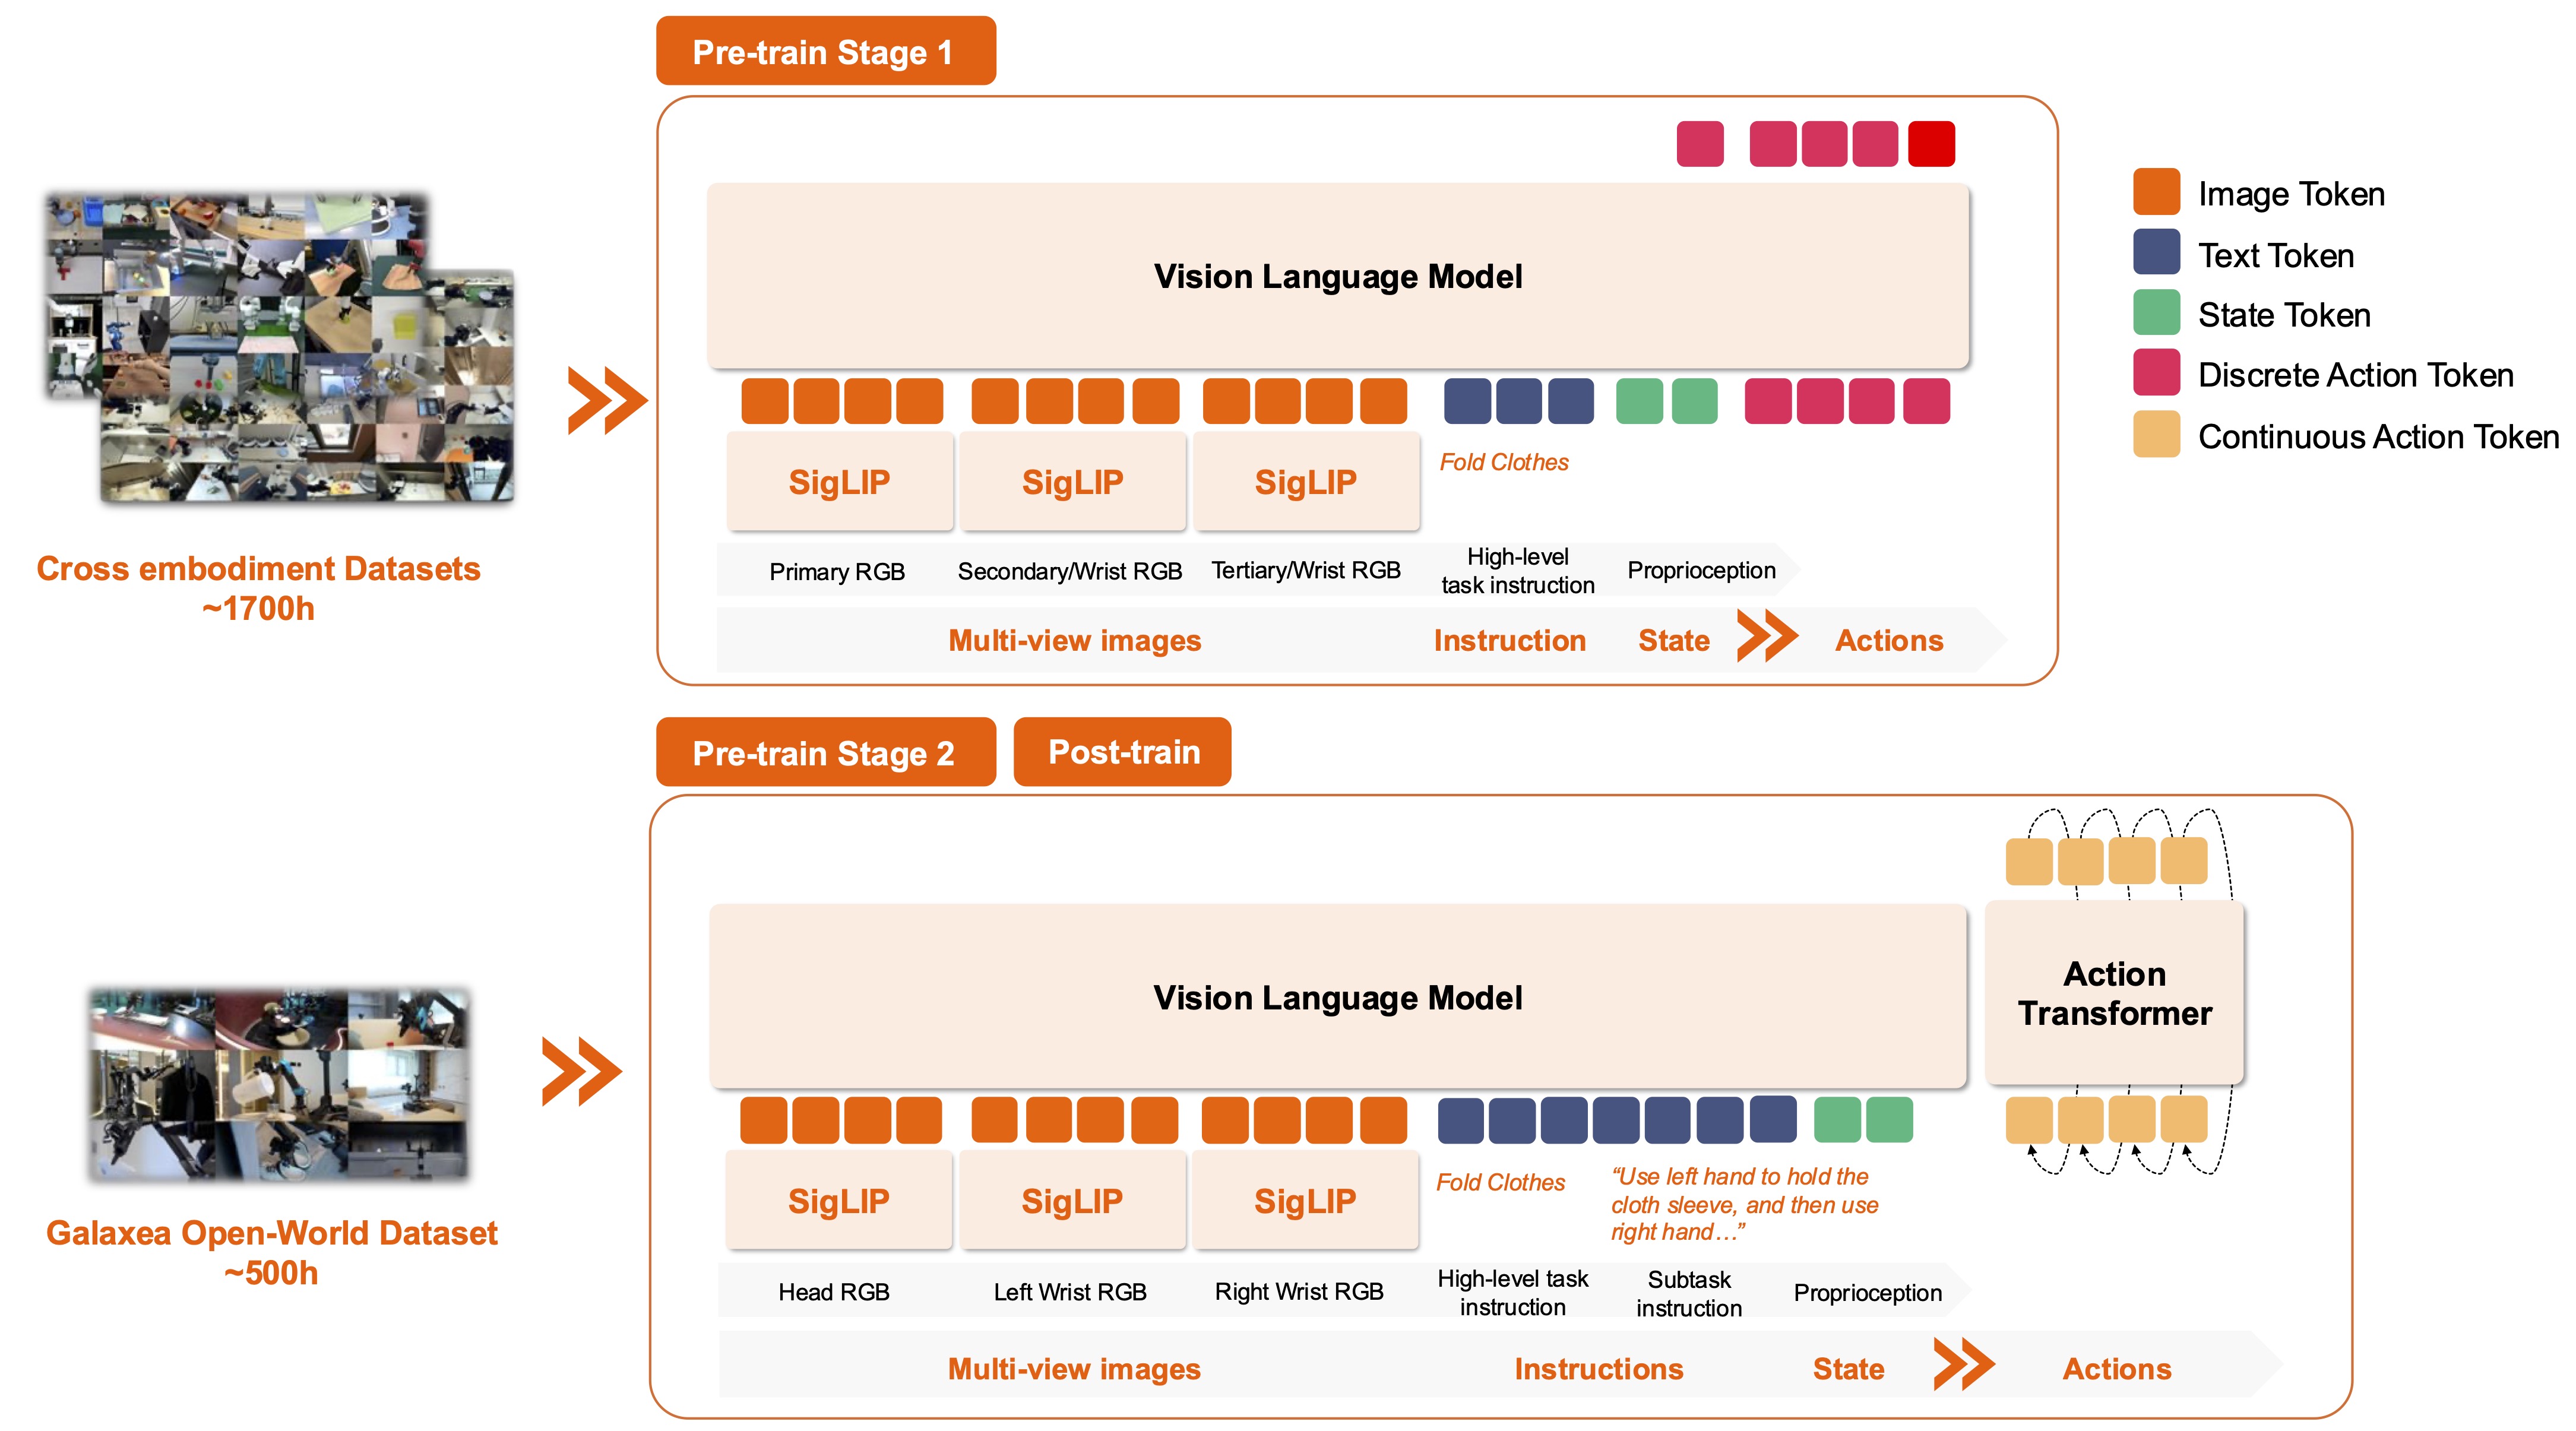
A practical guide to fine-tuning GalaxeaVLA G0Tiny 250M with LeRobot datasets for real robot manipulation.

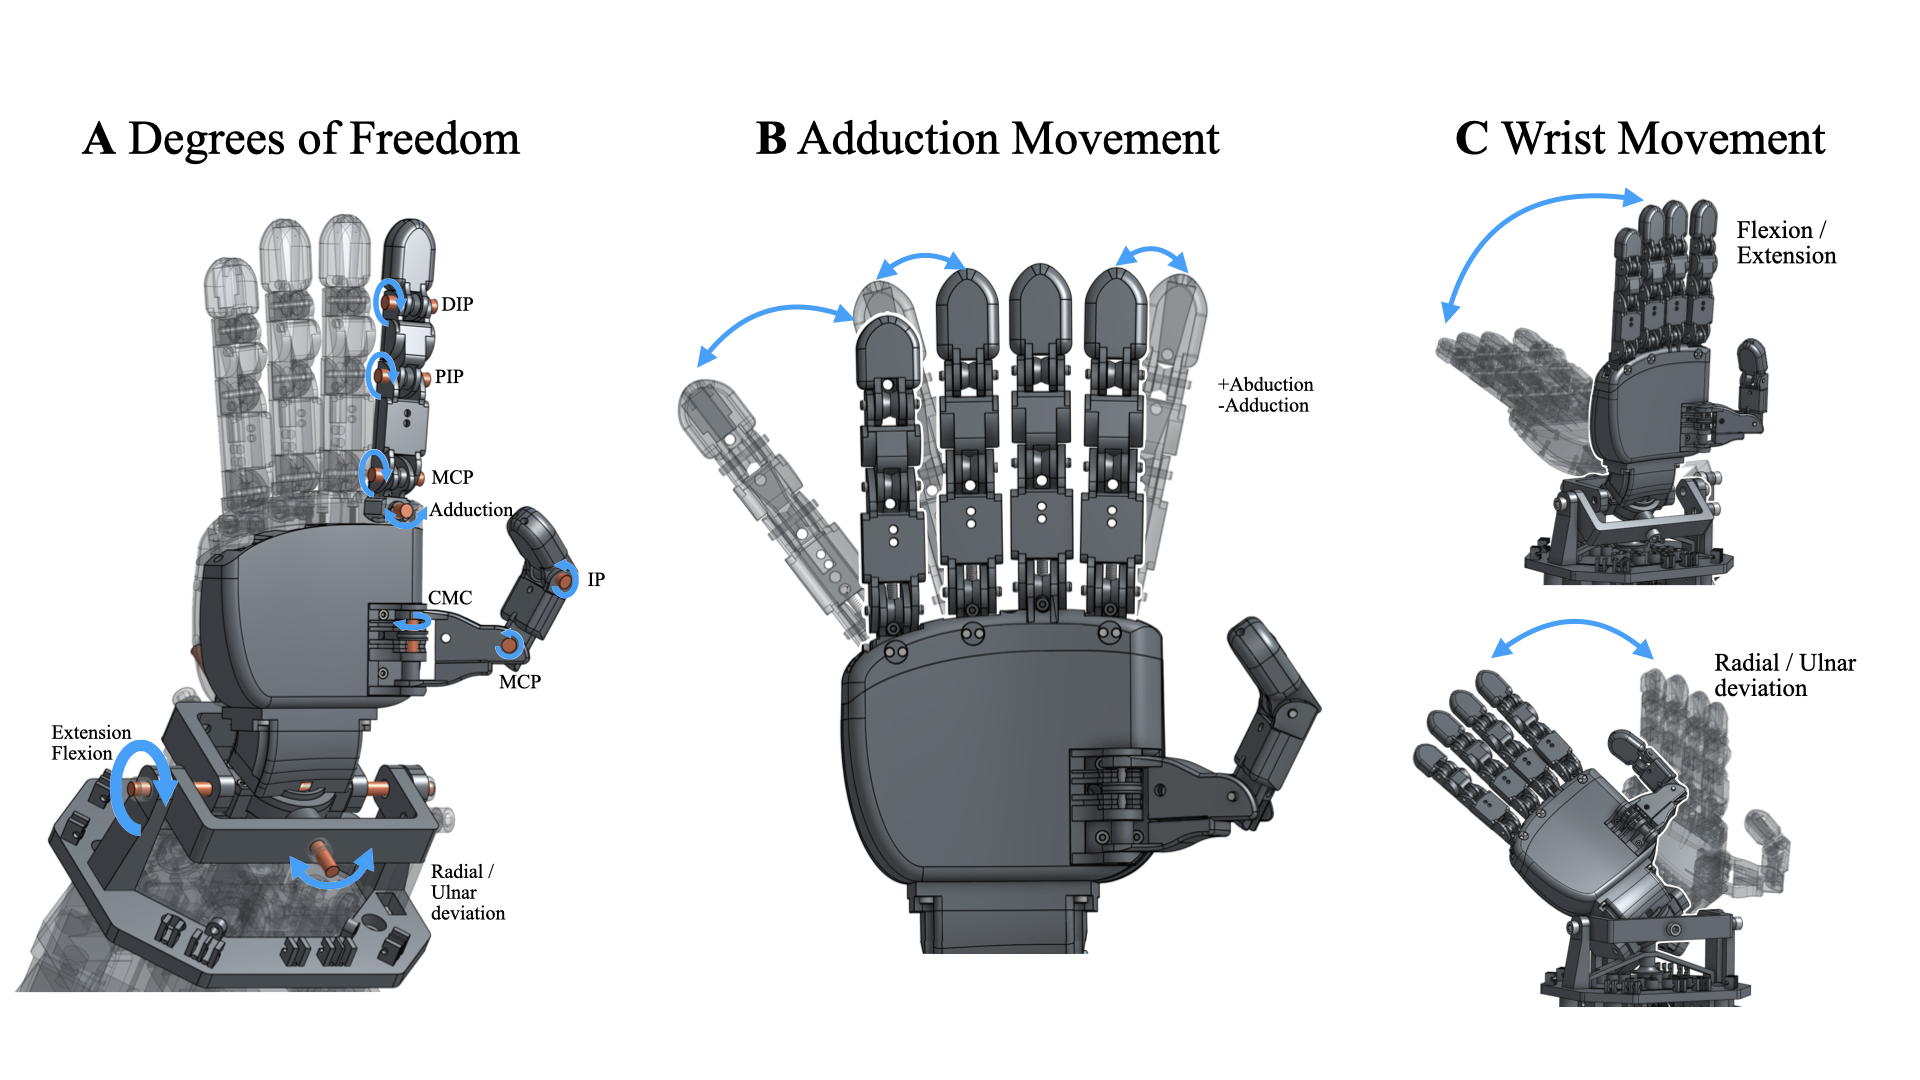
A beginner-friendly guide to building RUKA-v2, a tendon-driven open-source robot hand for dexterous manipulation and policy learning.

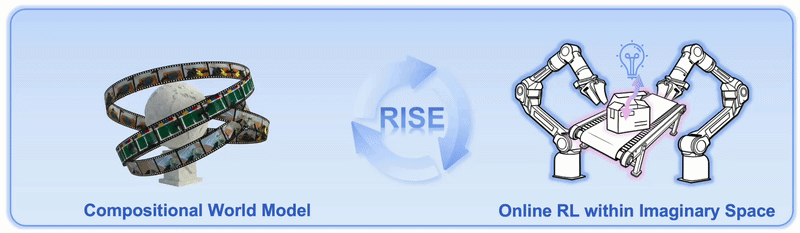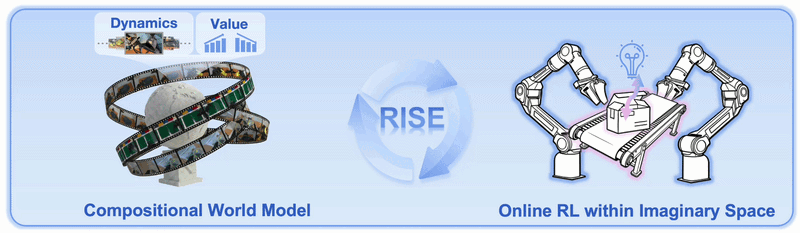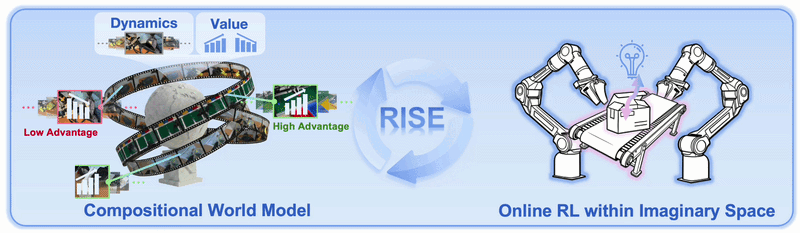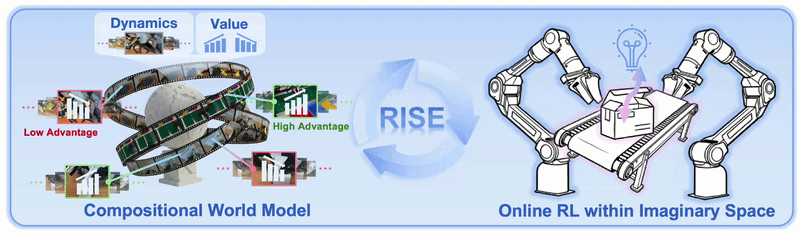
RISE uses a compositional world model to improve VLA robot policies with RL in imagination, reducing real-world trials.

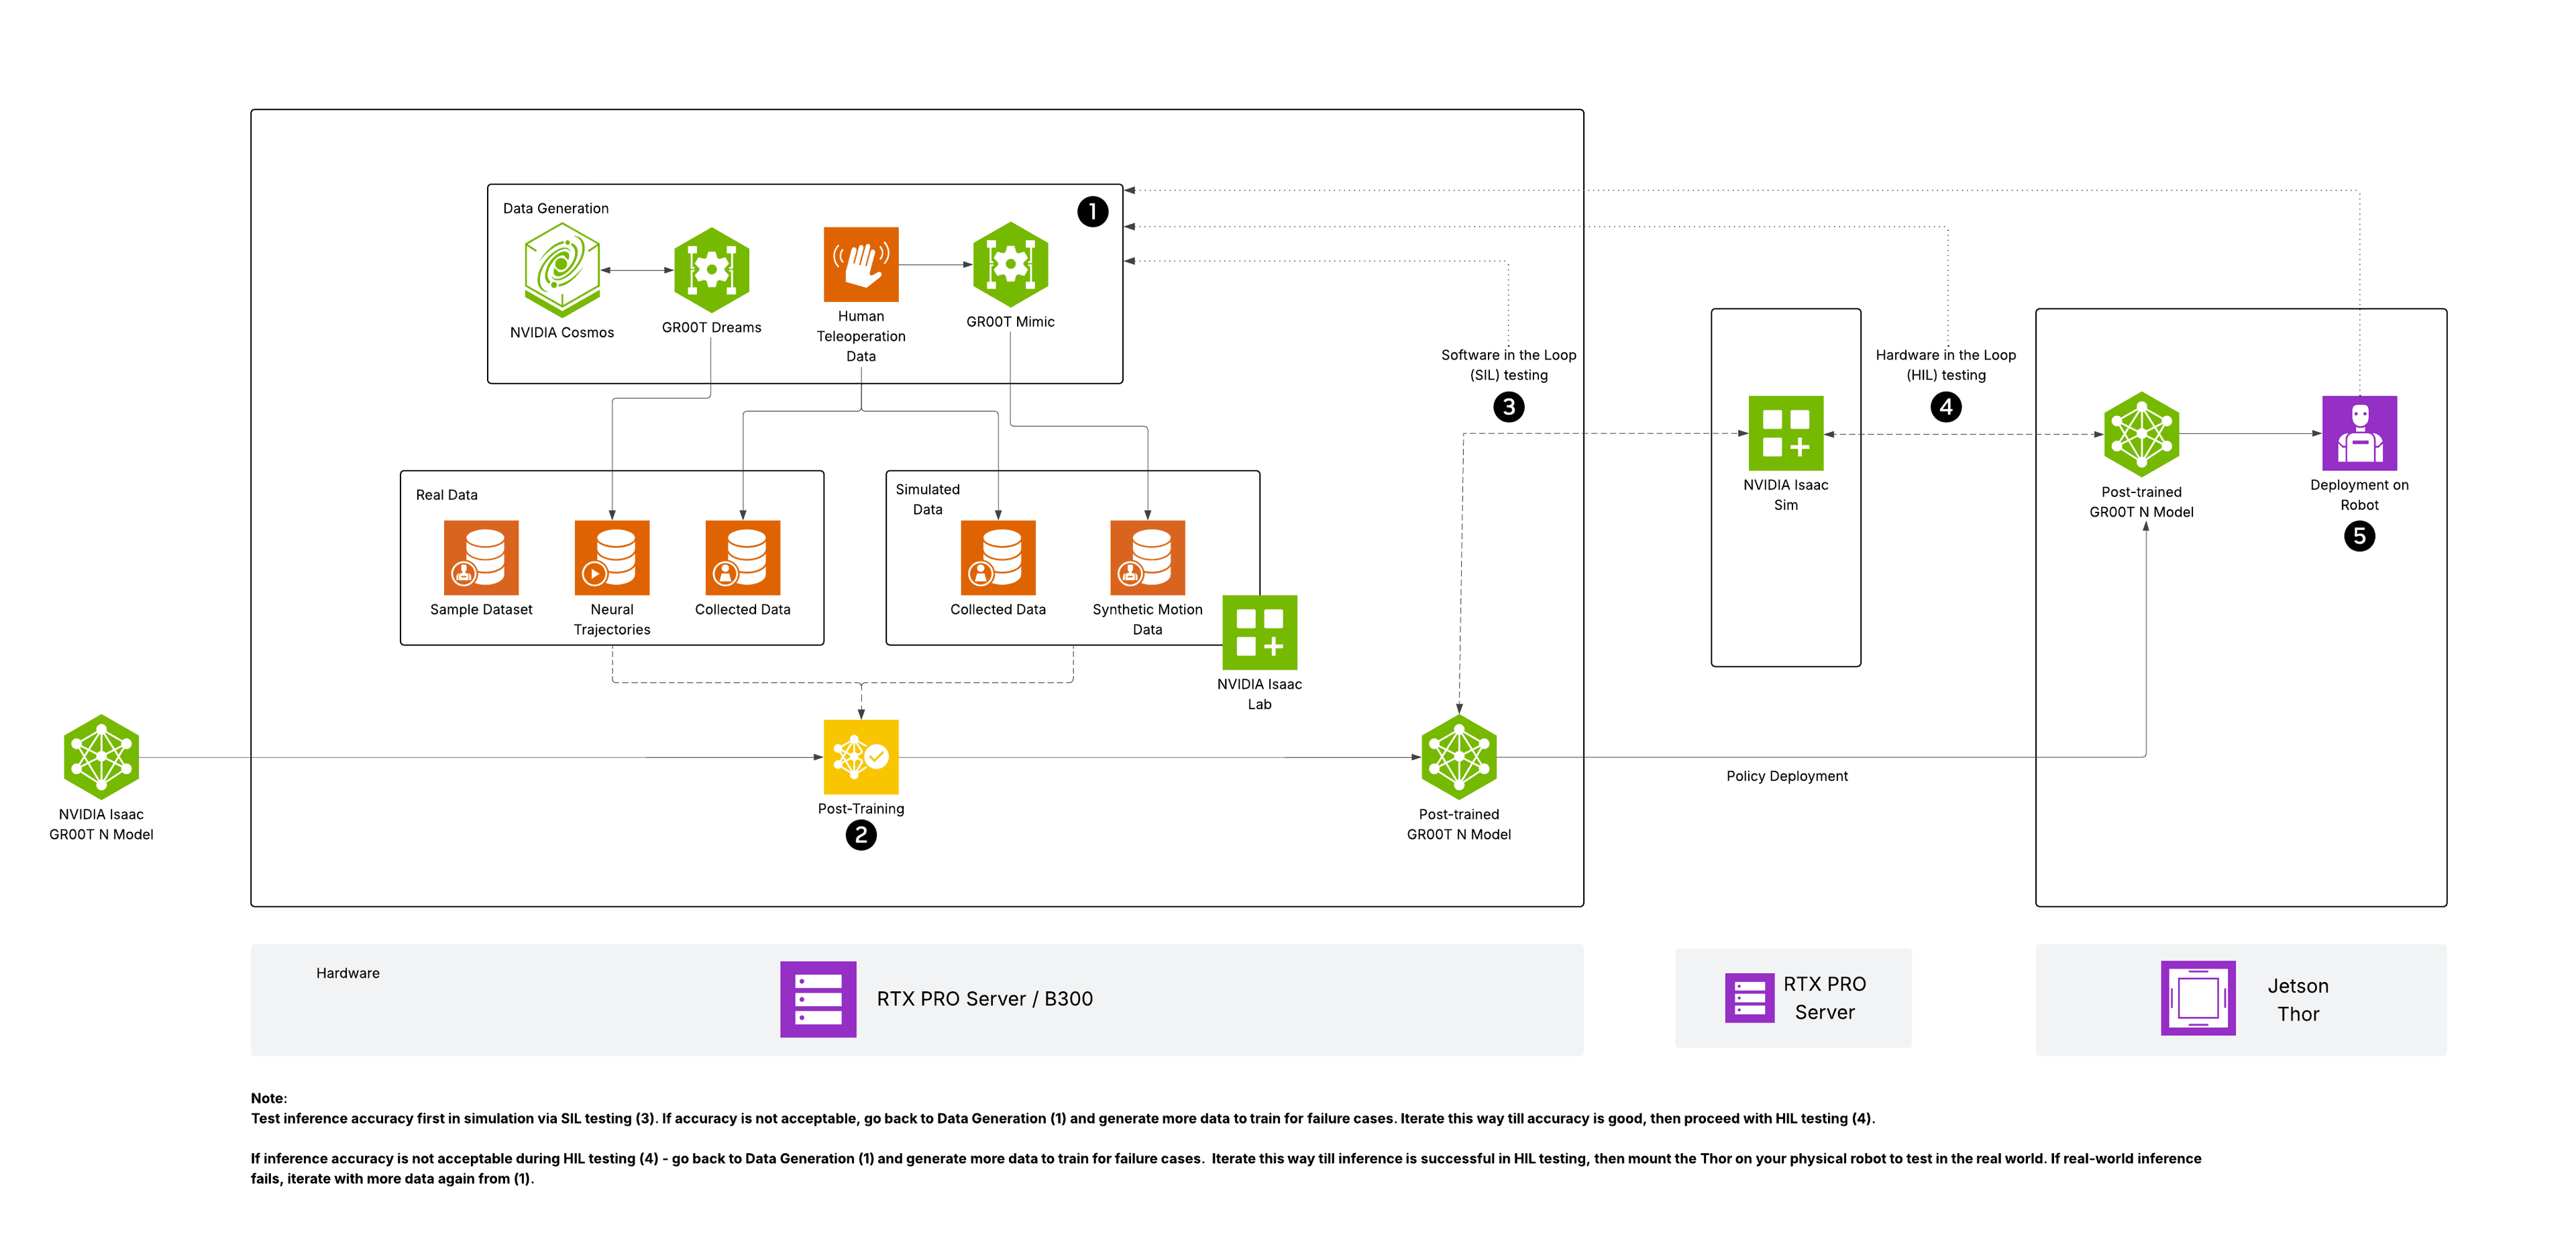
A beginner-friendly deep dive into GR00T N1.7, SONIC, data collection, fine-tuning, inference, and humanoid whole-body VLA.
A beginner guide to GR00T whole-body VLA synthetic data, LeRobot format, modality.json, fine-tuning, inference, and results.