All posts
Page 7 of 18

A beginner-friendly guide to MPC-RL: MPC-shaped PPO rewards, repo setup, training, inference, and results for humanoid locomotion and pushing.

A practical guide to ETH's course from MDPs, imitation learning and RL to VLA/foundation models for robotics.

DIRECT learns when a robot planner should use cheap or expensive VLM compute, preserving success while reducing latency.

A practical guide to LIBERO-Occ and Viewpoint Imagination for evaluating, training, and running VLA policies under occlusion.

Run LabVLA — the first VLA model for scientific lab robots, combining Qwen3-VL-4B with DiT flow-matching and LeRobot v2 format. 71.1% on LabUtopia benchmark.

A practical guide to LeCAR-Lab ASAP: motion tracking, delta action training, policy fine-tuning, and Unitree G1 sim-to-real deployment.

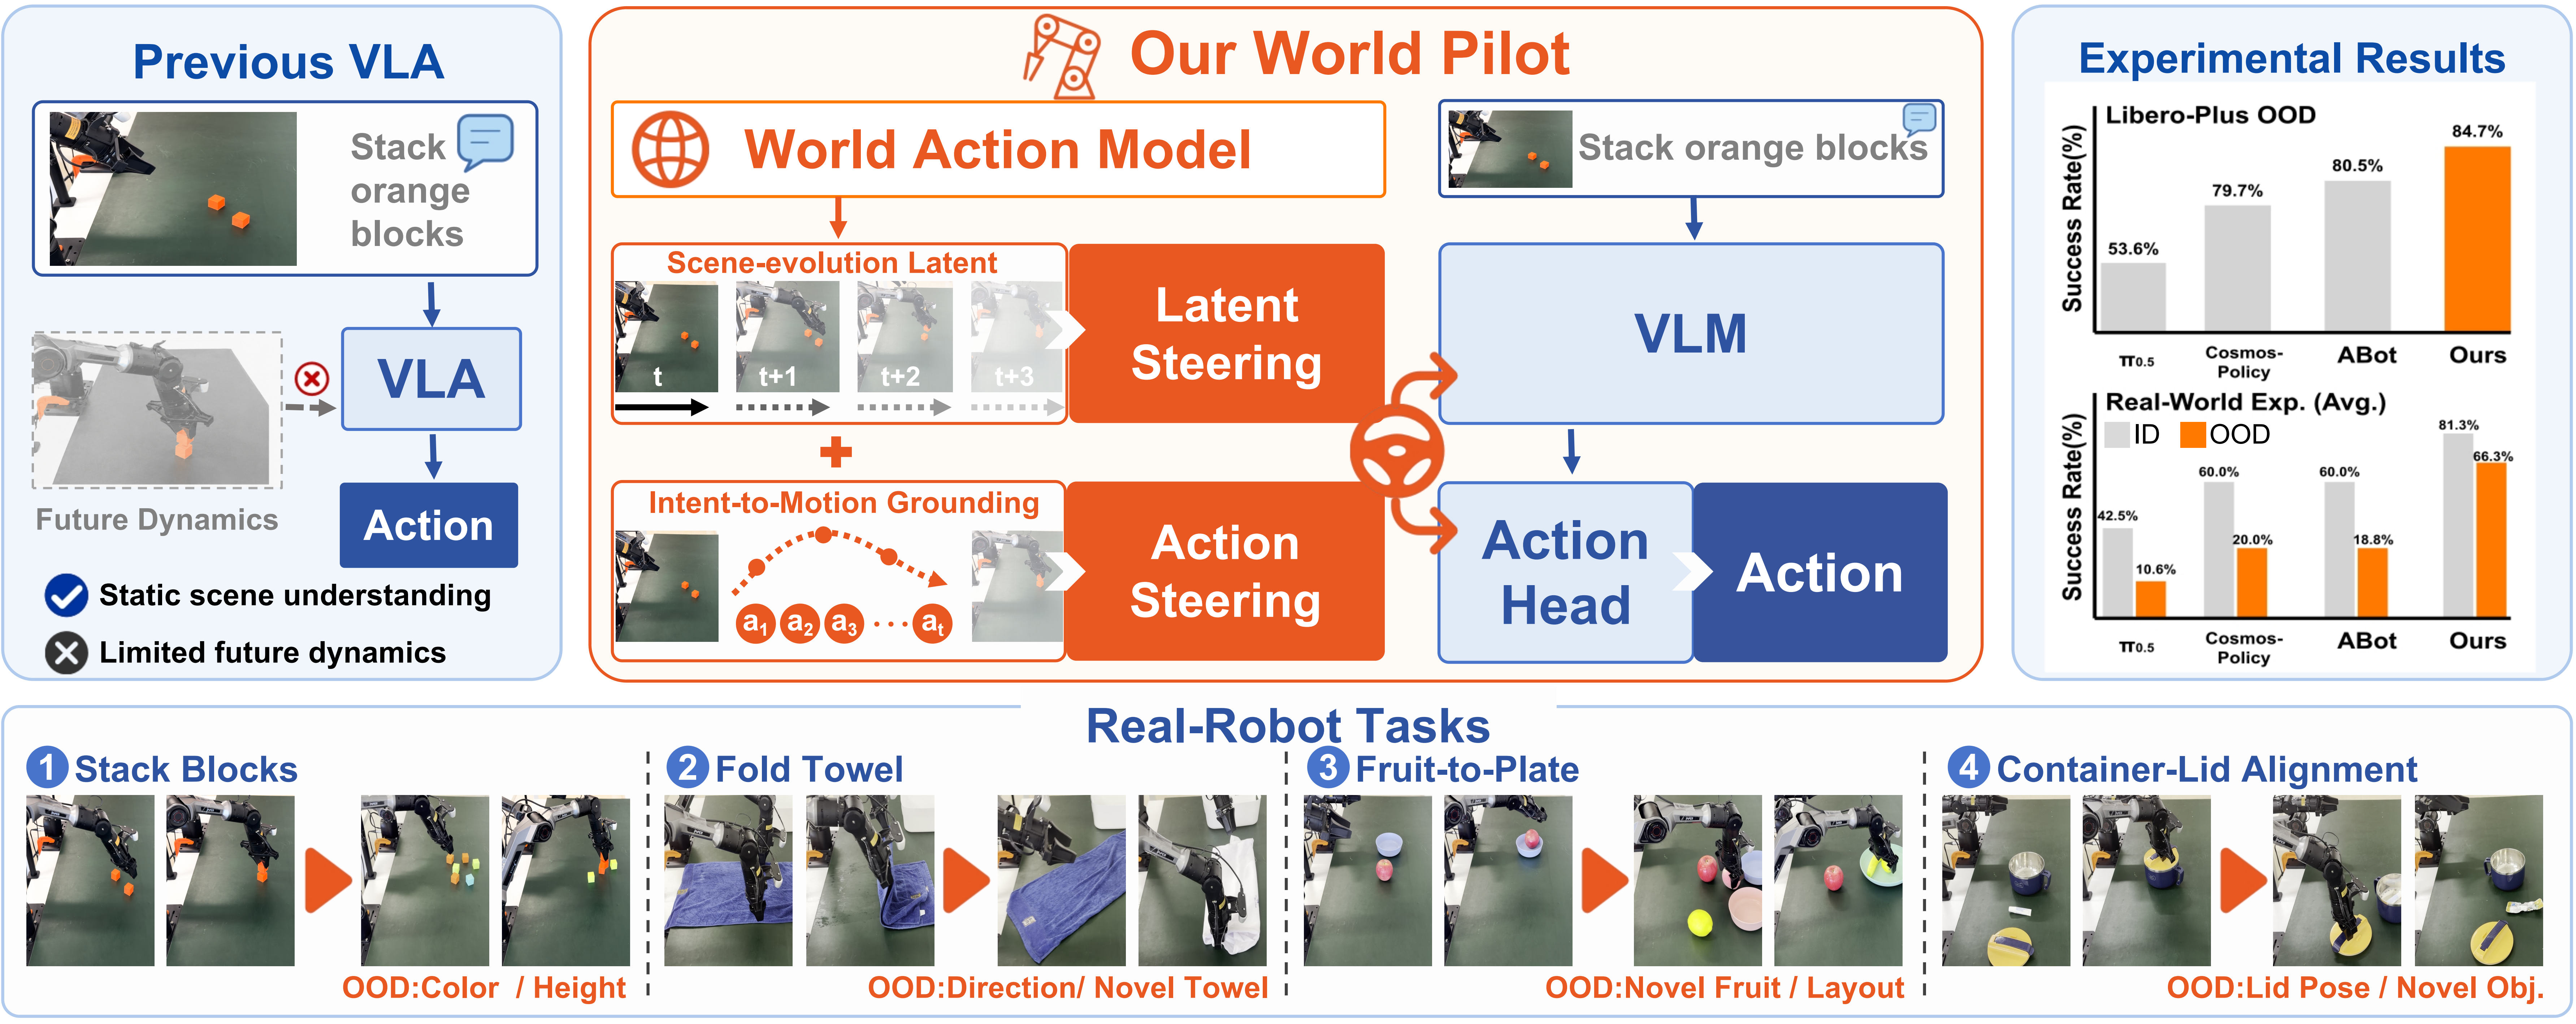
A practical World Pilot guide for using World-Action Priors to improve zero-shot OOD robustness in VLA robots.

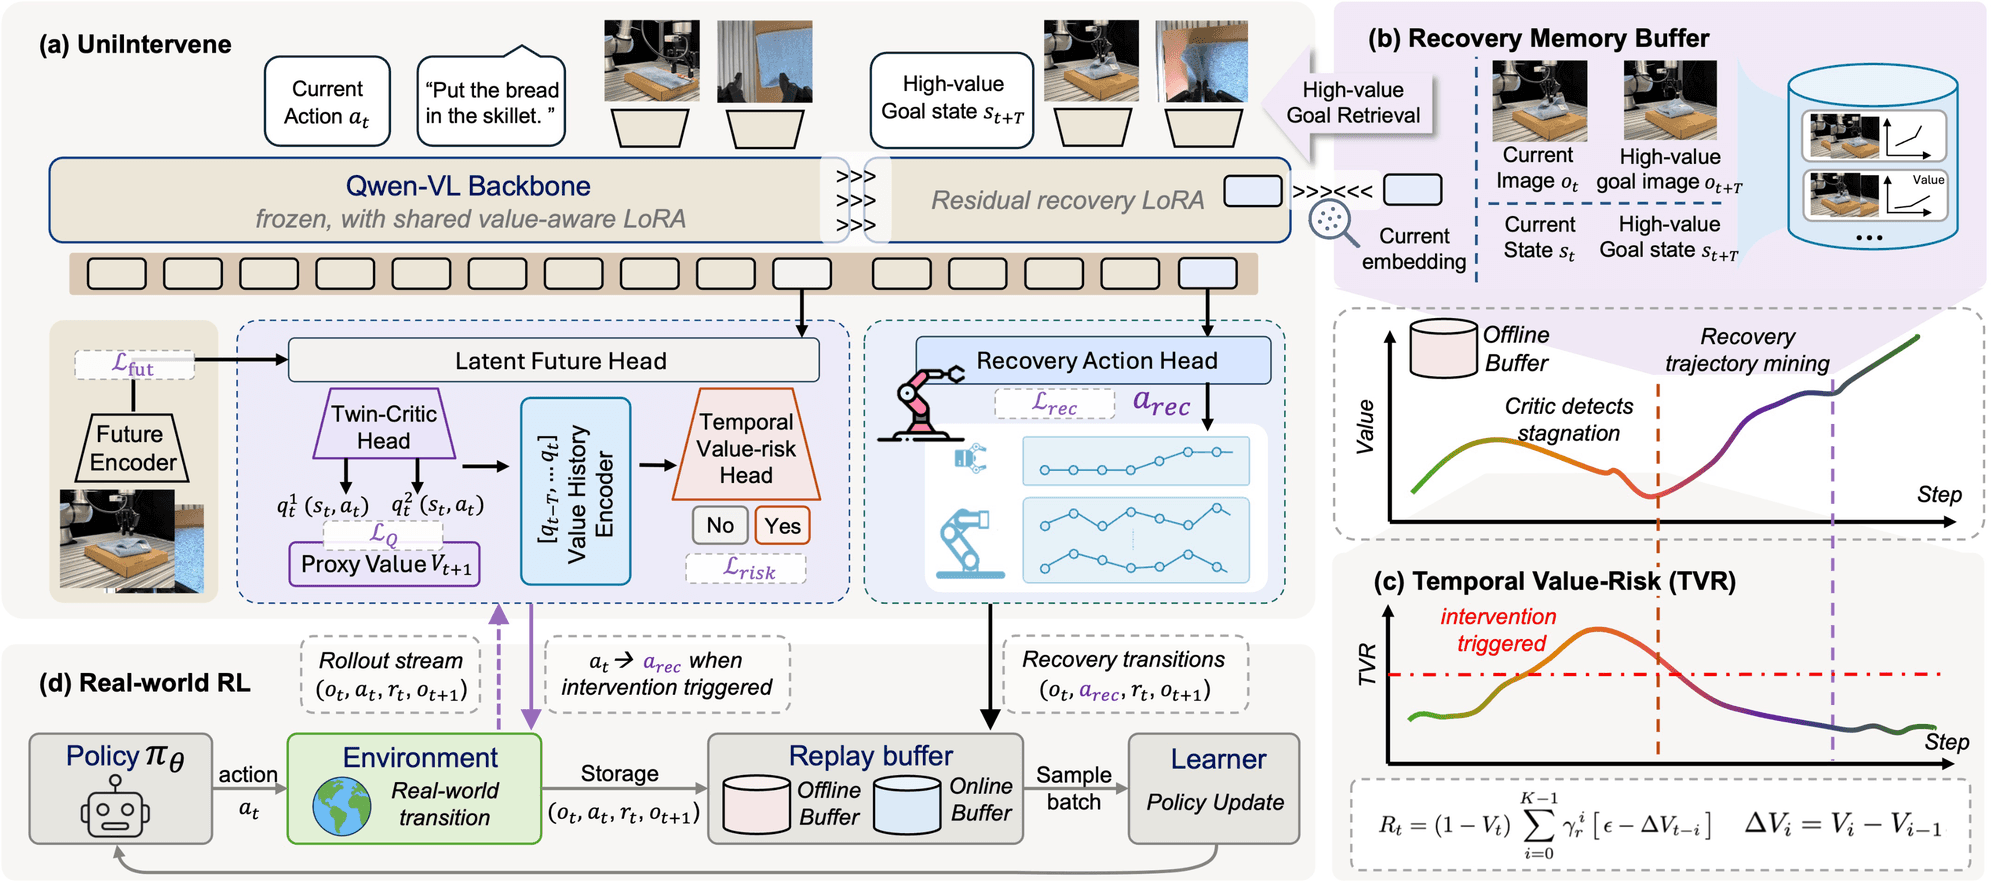
A practical guide to UniIntervene: value-risk triggering and memory-guided recovery for real-world robot RL fine-tuning.

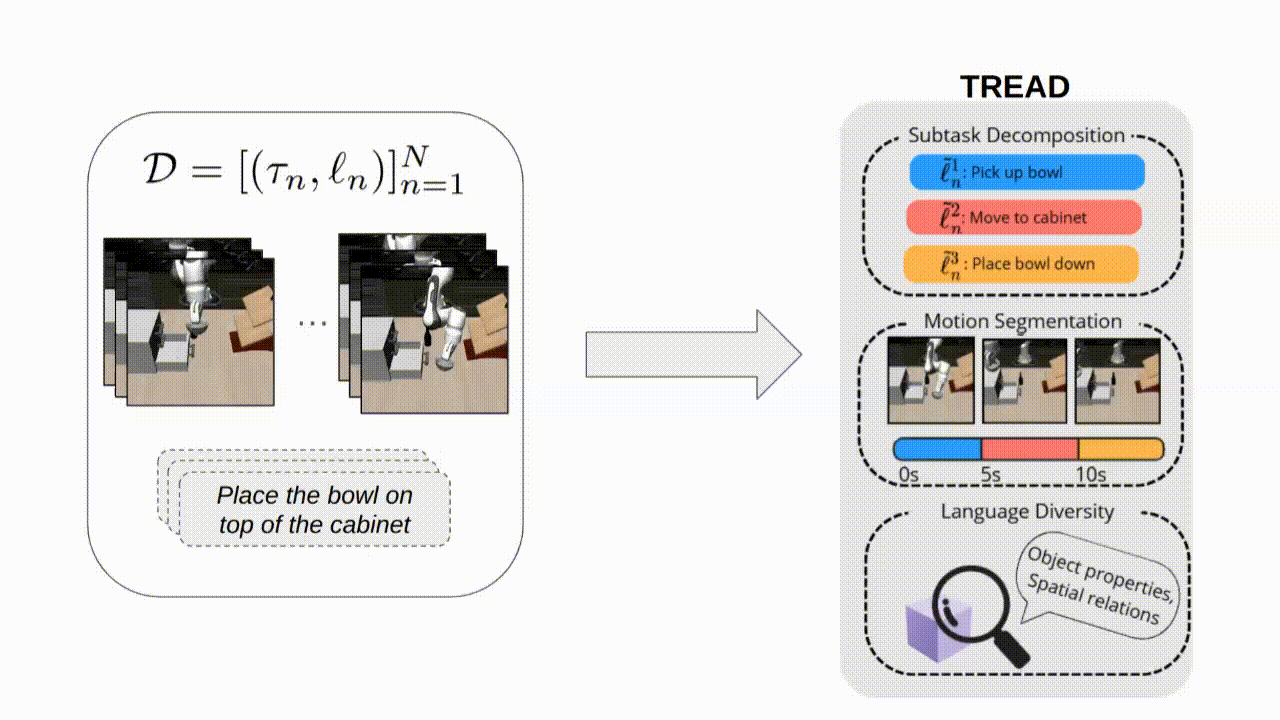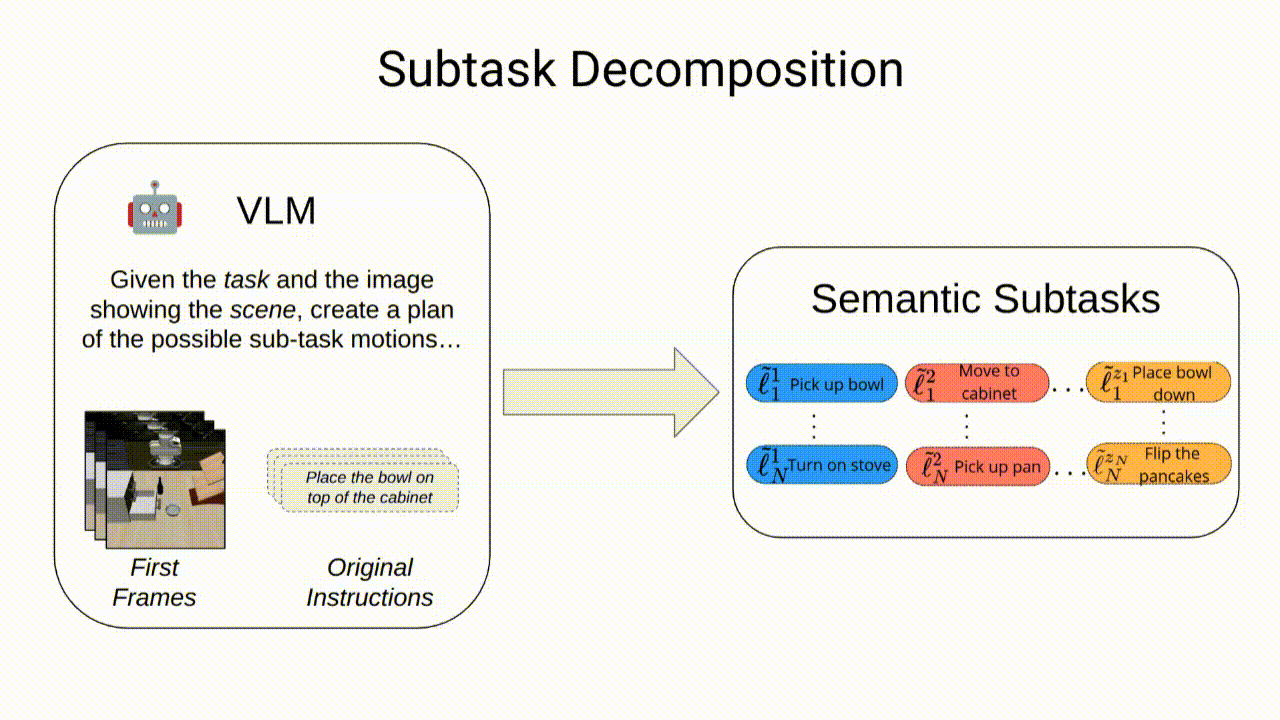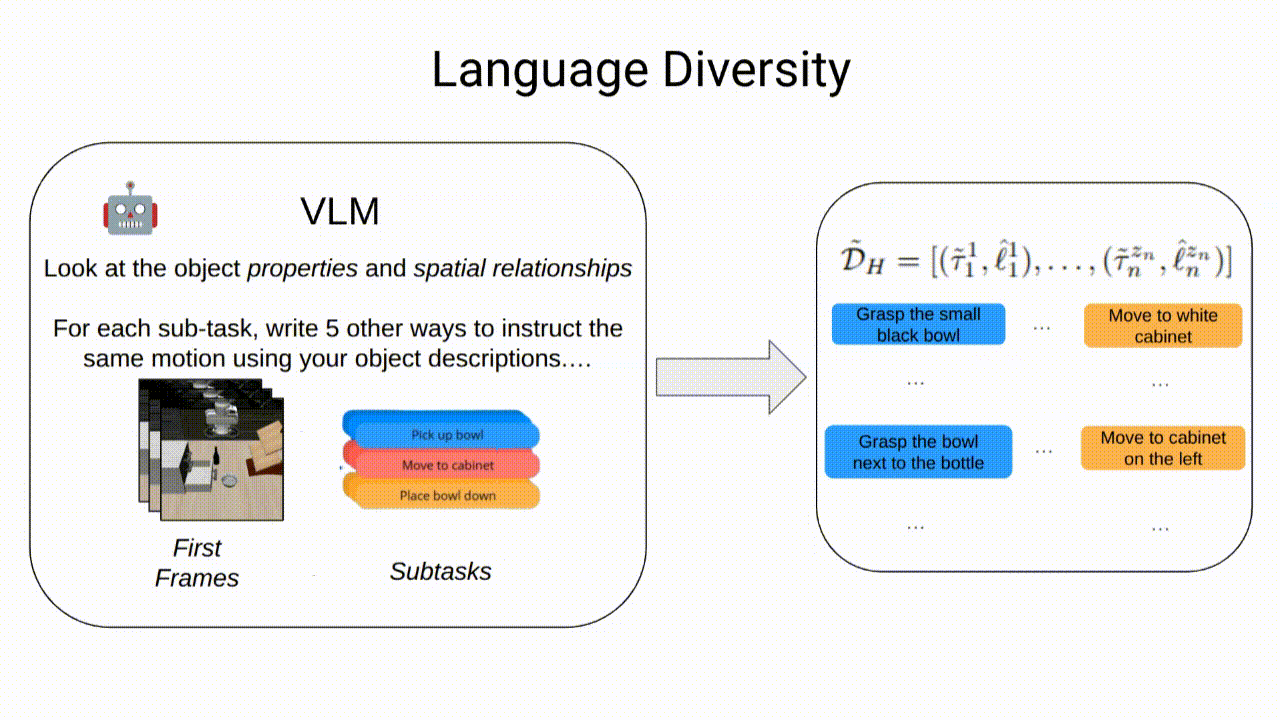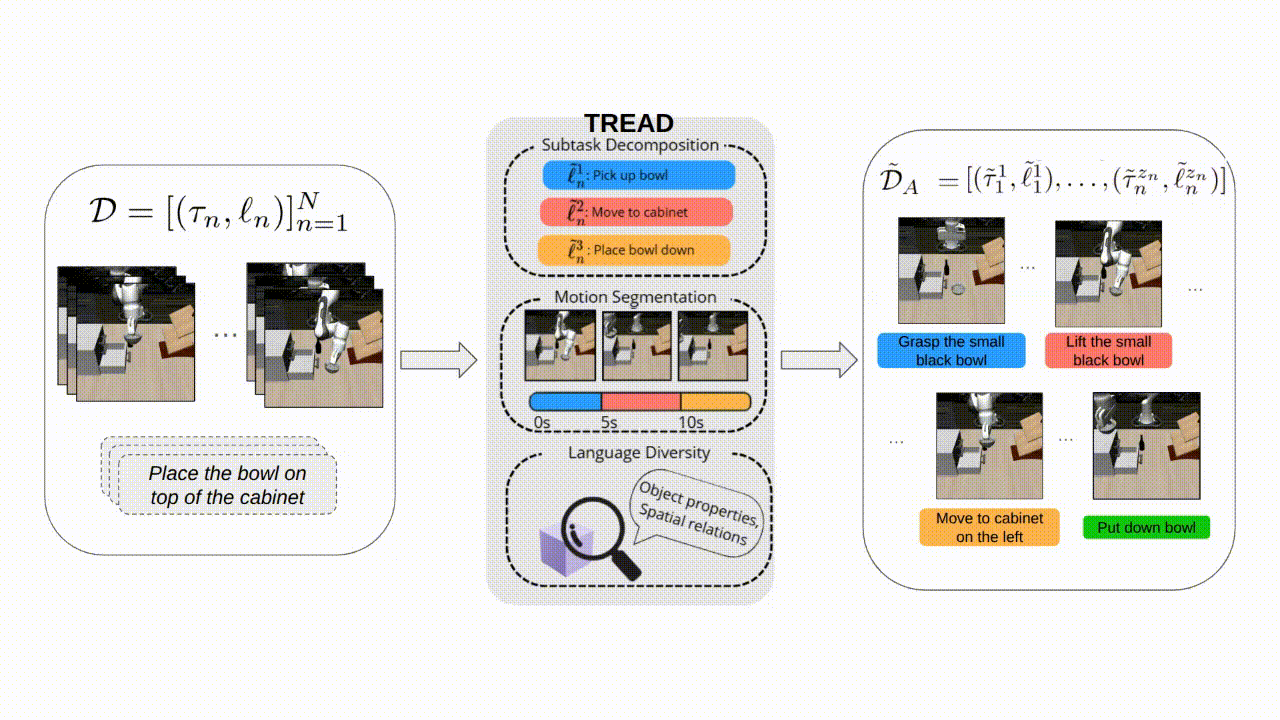
A practical guide to TREAD: segment robot trajectories, relabel subtasks with VLMs, and fine-tune stronger VLAs on LIBERO.

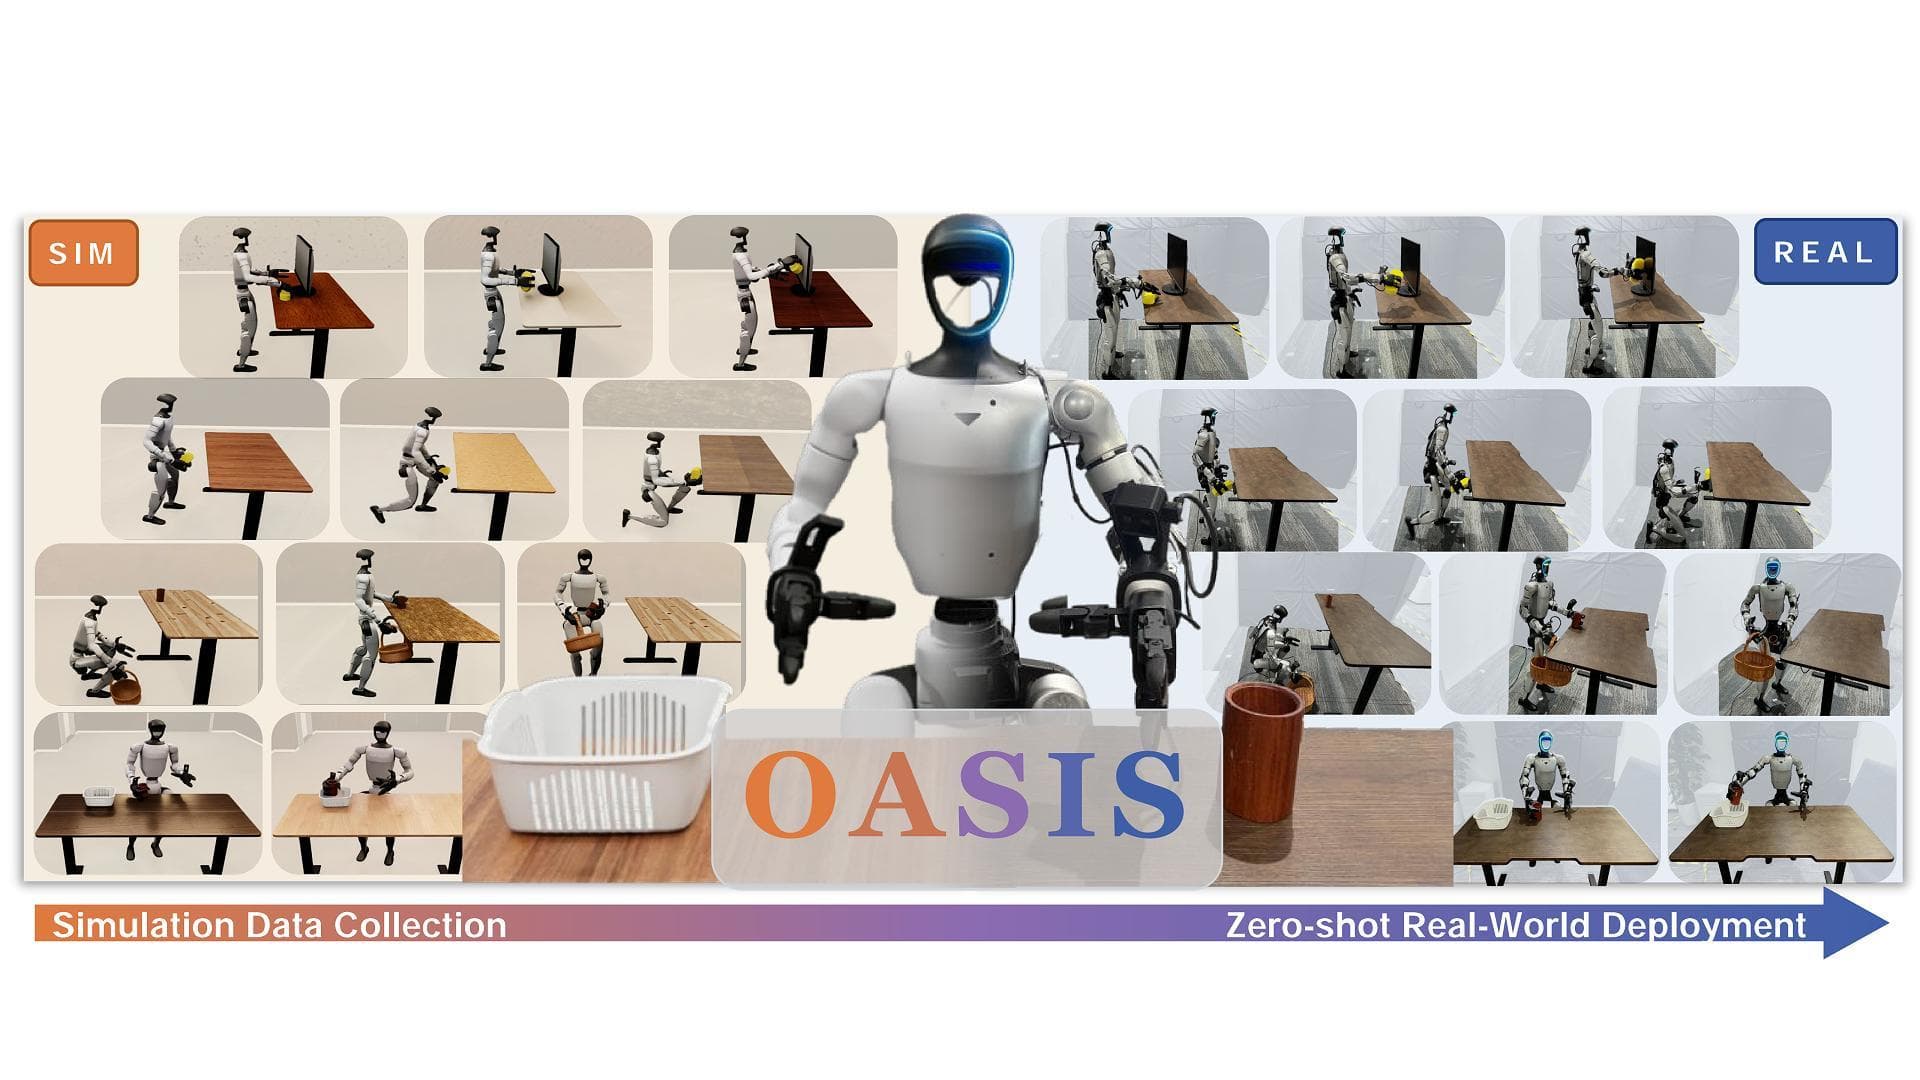
A practical OASIS guide: build assets, teleoperate in Isaac Lab, render randomized trajectories, train whole-body policies, and deploy zero-shot.

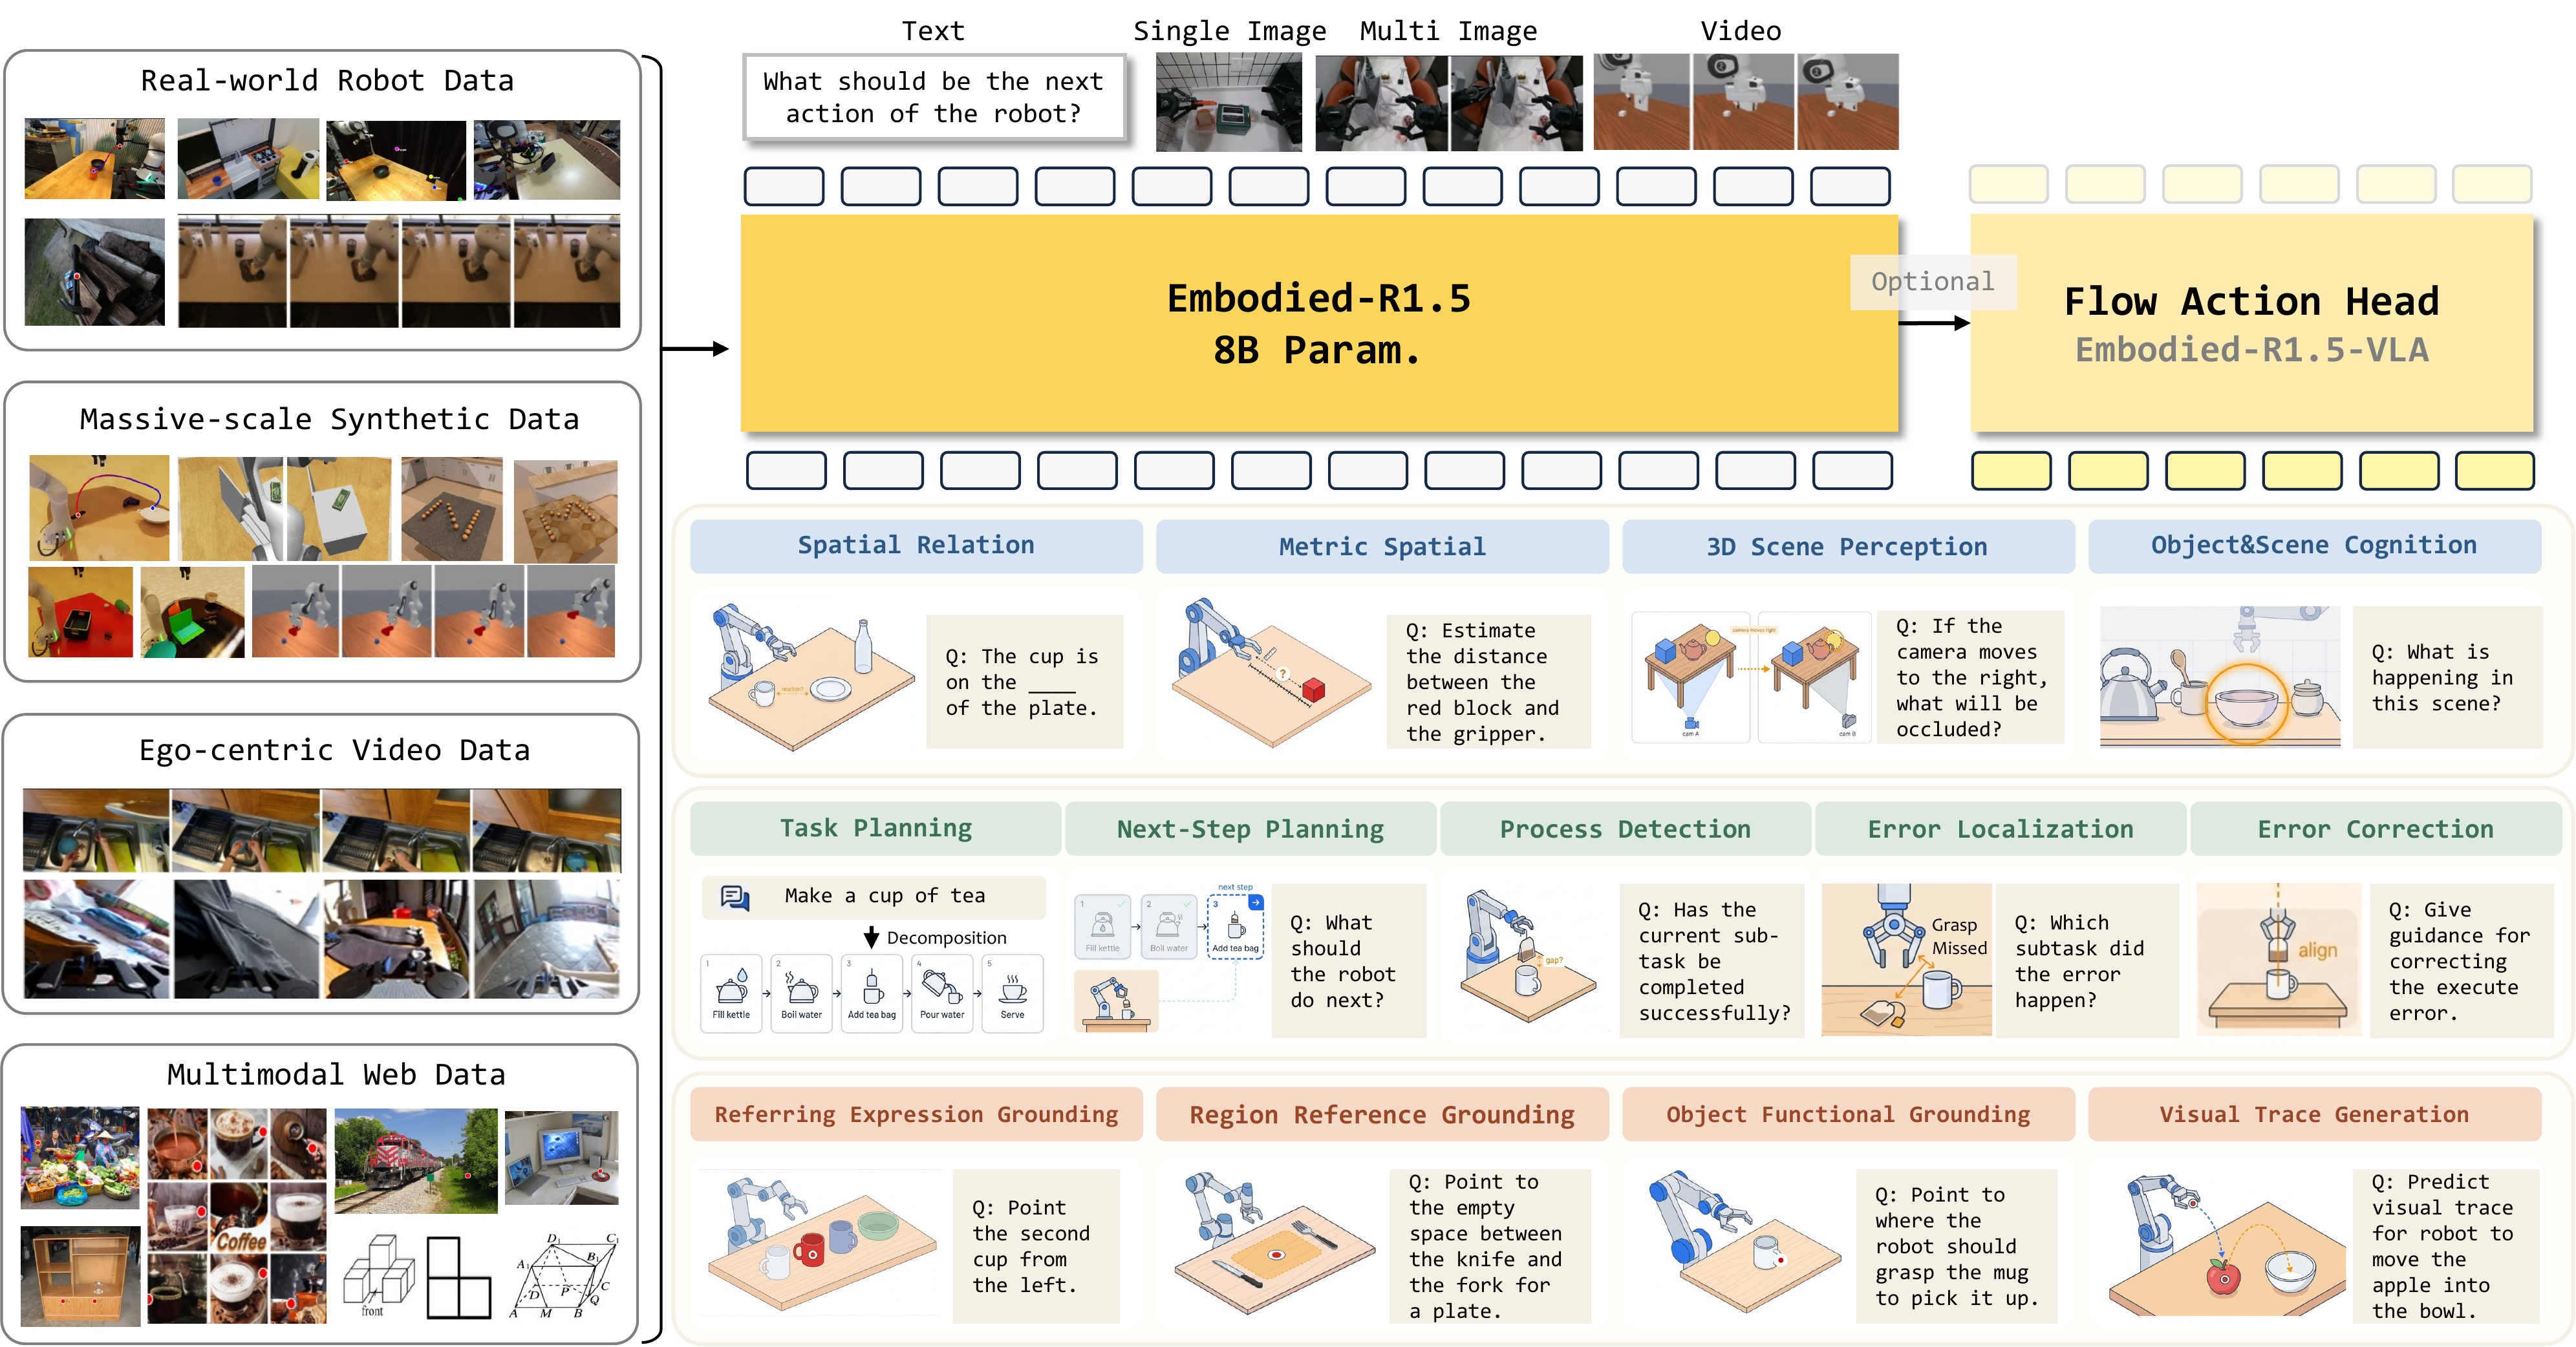
Install, evaluate on LIBERO, and fine-tune Embodied-R1.5-VLA for robot manipulation using open-source checkpoints.

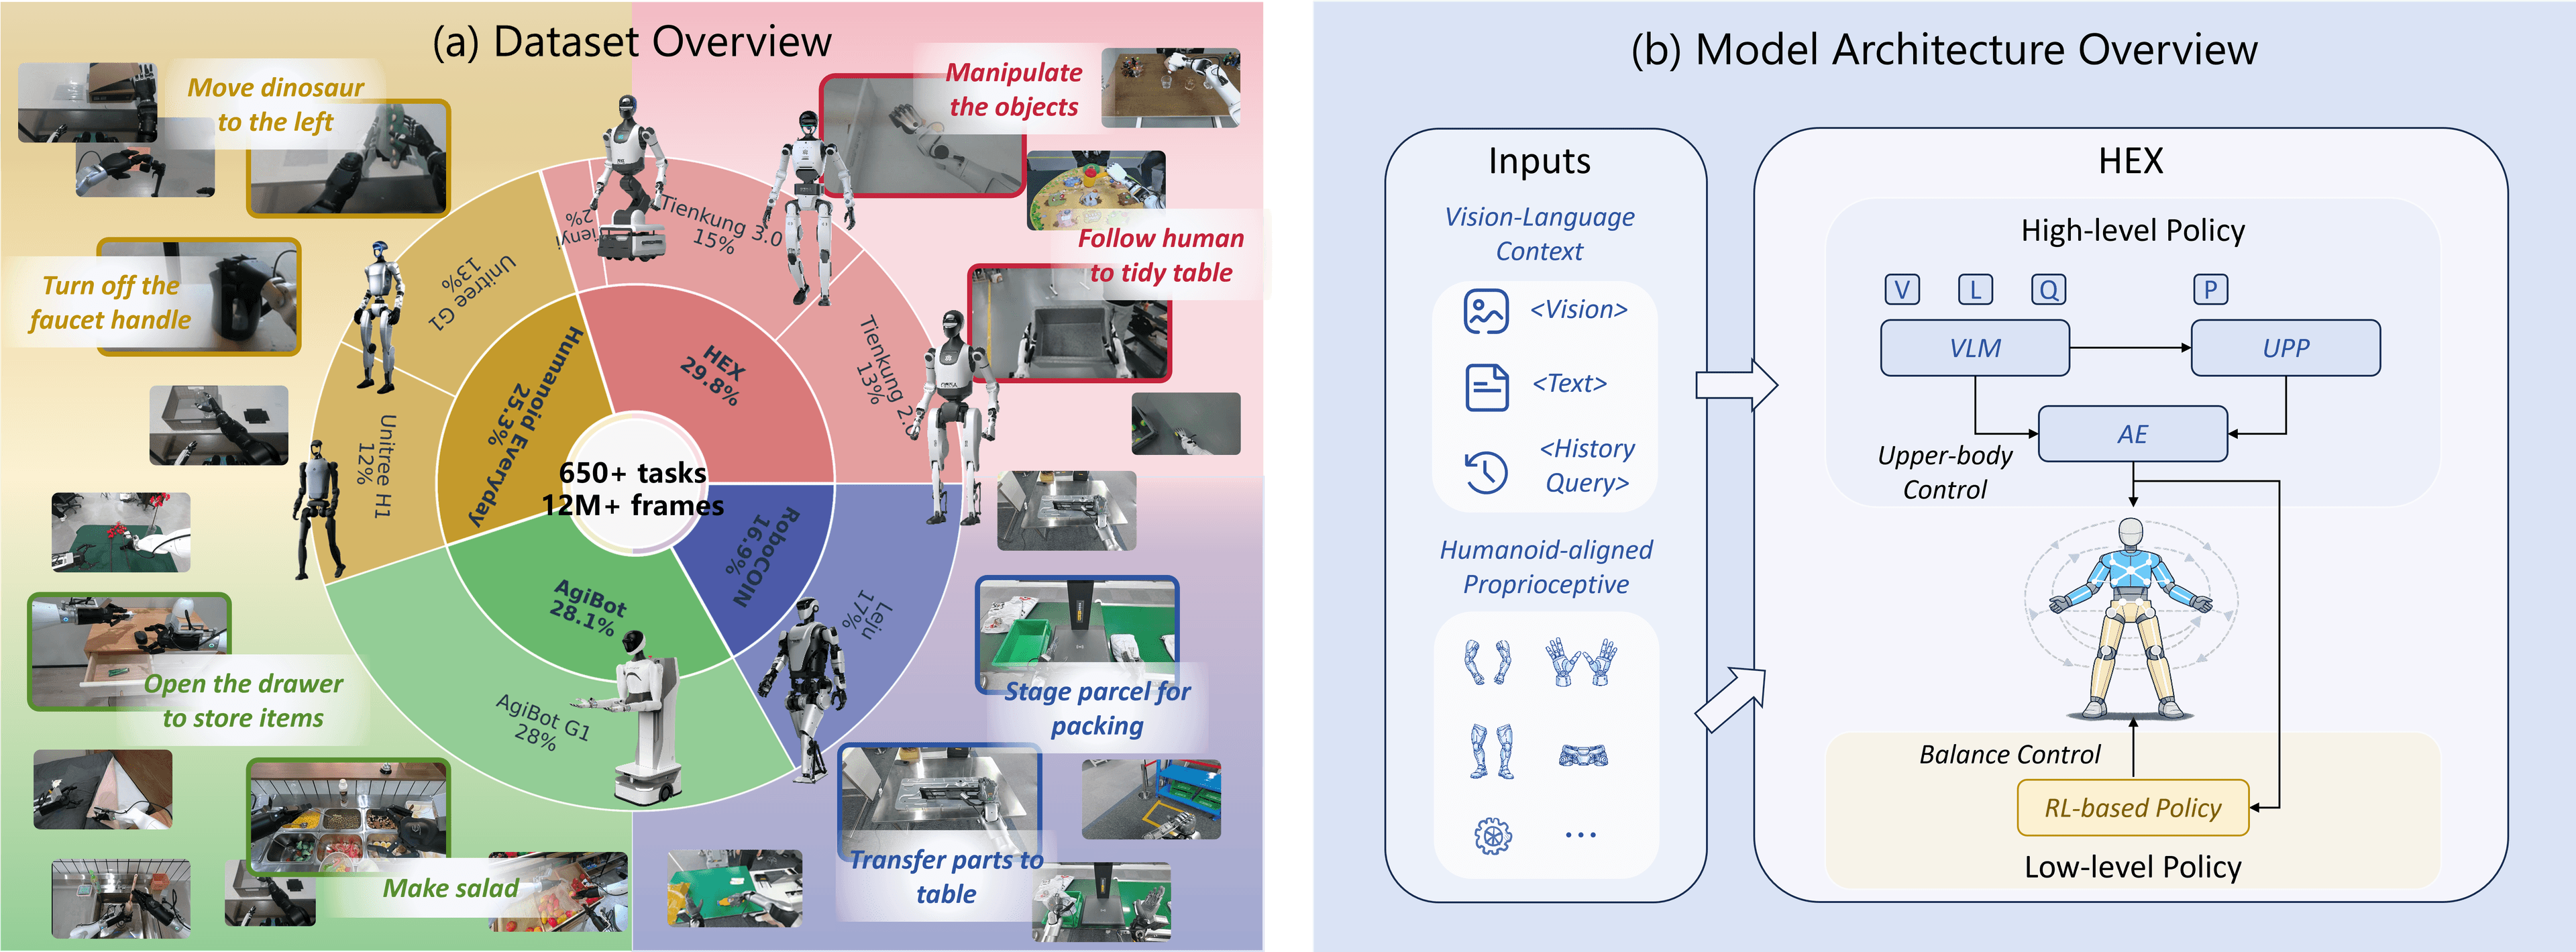
HEX is the first whole-body VLA for full-sized humanoids, supporting 7 embodiments, open-source, built on Qwen3-VL + MoE UPP + DiT flow-matching.