All posts
Page 9 of 18

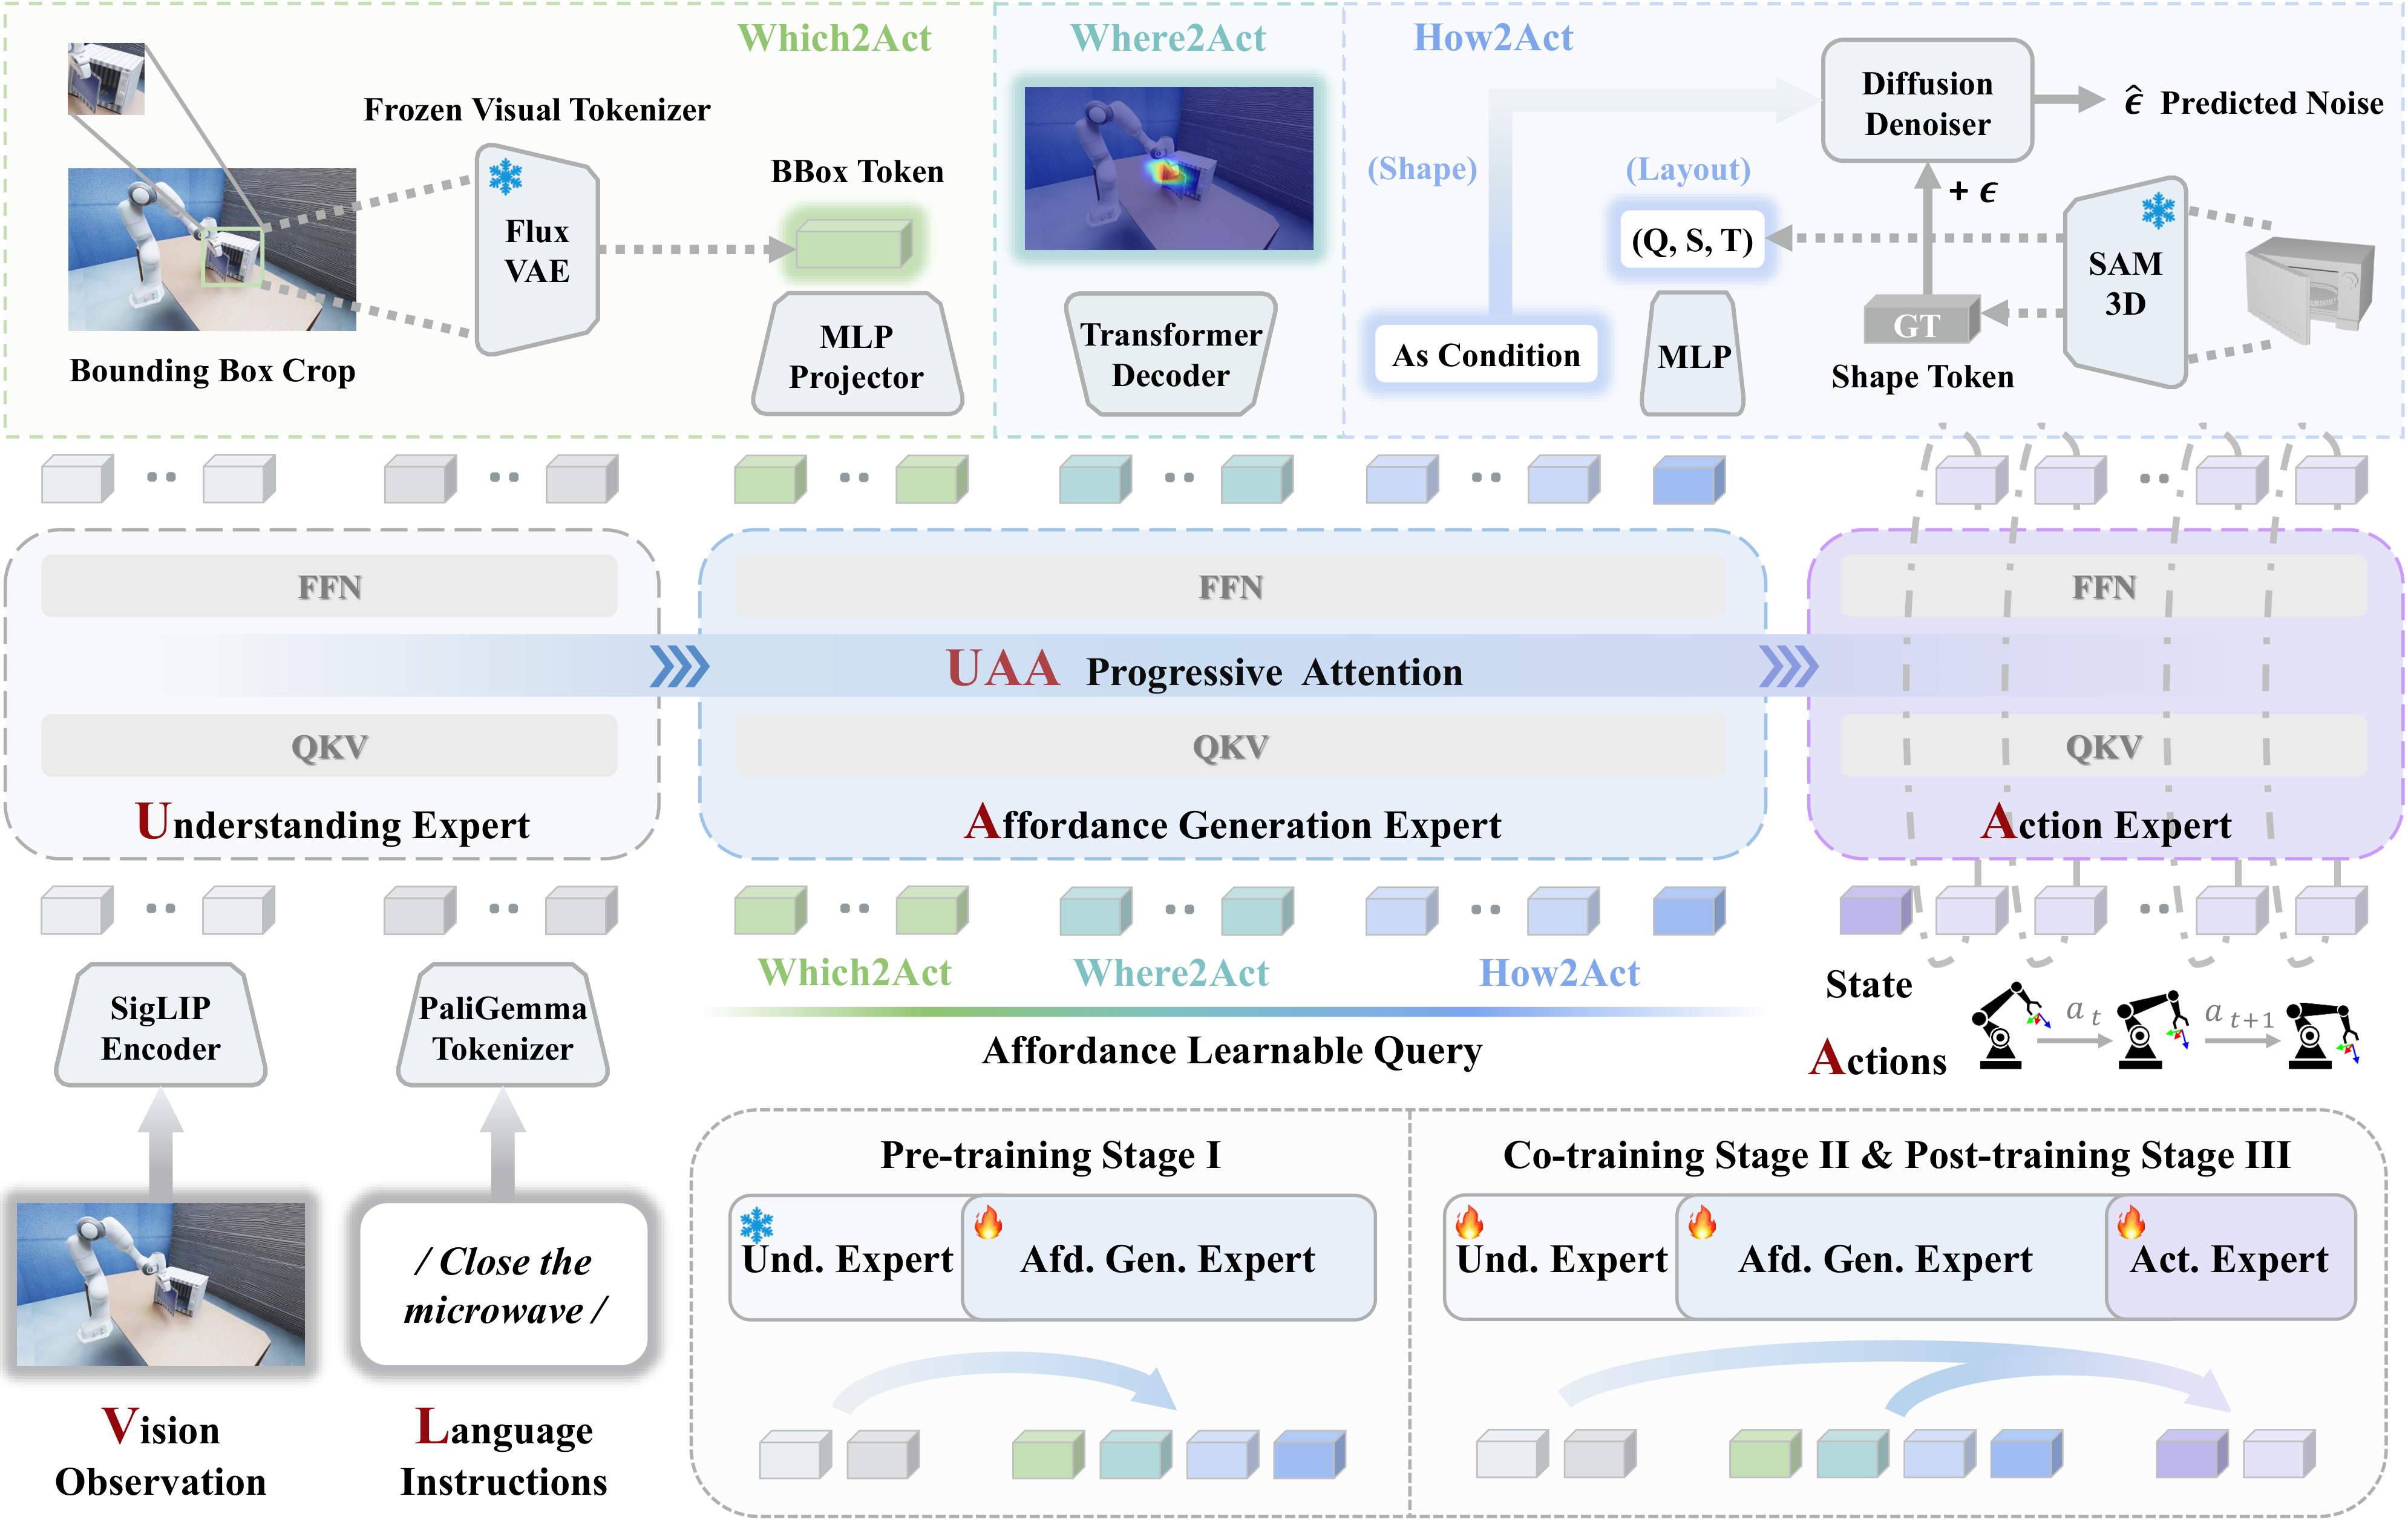
A beginner-friendly guide to AffordanceVLA: paper idea, Which2Act/Where2Act/How2Act architecture, GitHub setup, training, inference, and results.
Wall-OSS-0.5 is an open-source 4B VLA for zero-shot real-robot manipulation, integrated with LeRobot and gradient-bridged co-training.

A practical guide to installing, running, fine-tuning, and deploying OpenEAI-VLA, an open Qwen3-VL-4B VLA for low-cost robot arms.
MOV.AI is a full robotics OS — but maybe not what you need. Honest comparison of 5 alternatives: pricing, ROS 2 support, complexity, free tiers.

A practical GRAIL guide for creating synthetic data from 3D assets and video priors to fine-tune whole-body VLA policies on Unitree G1.

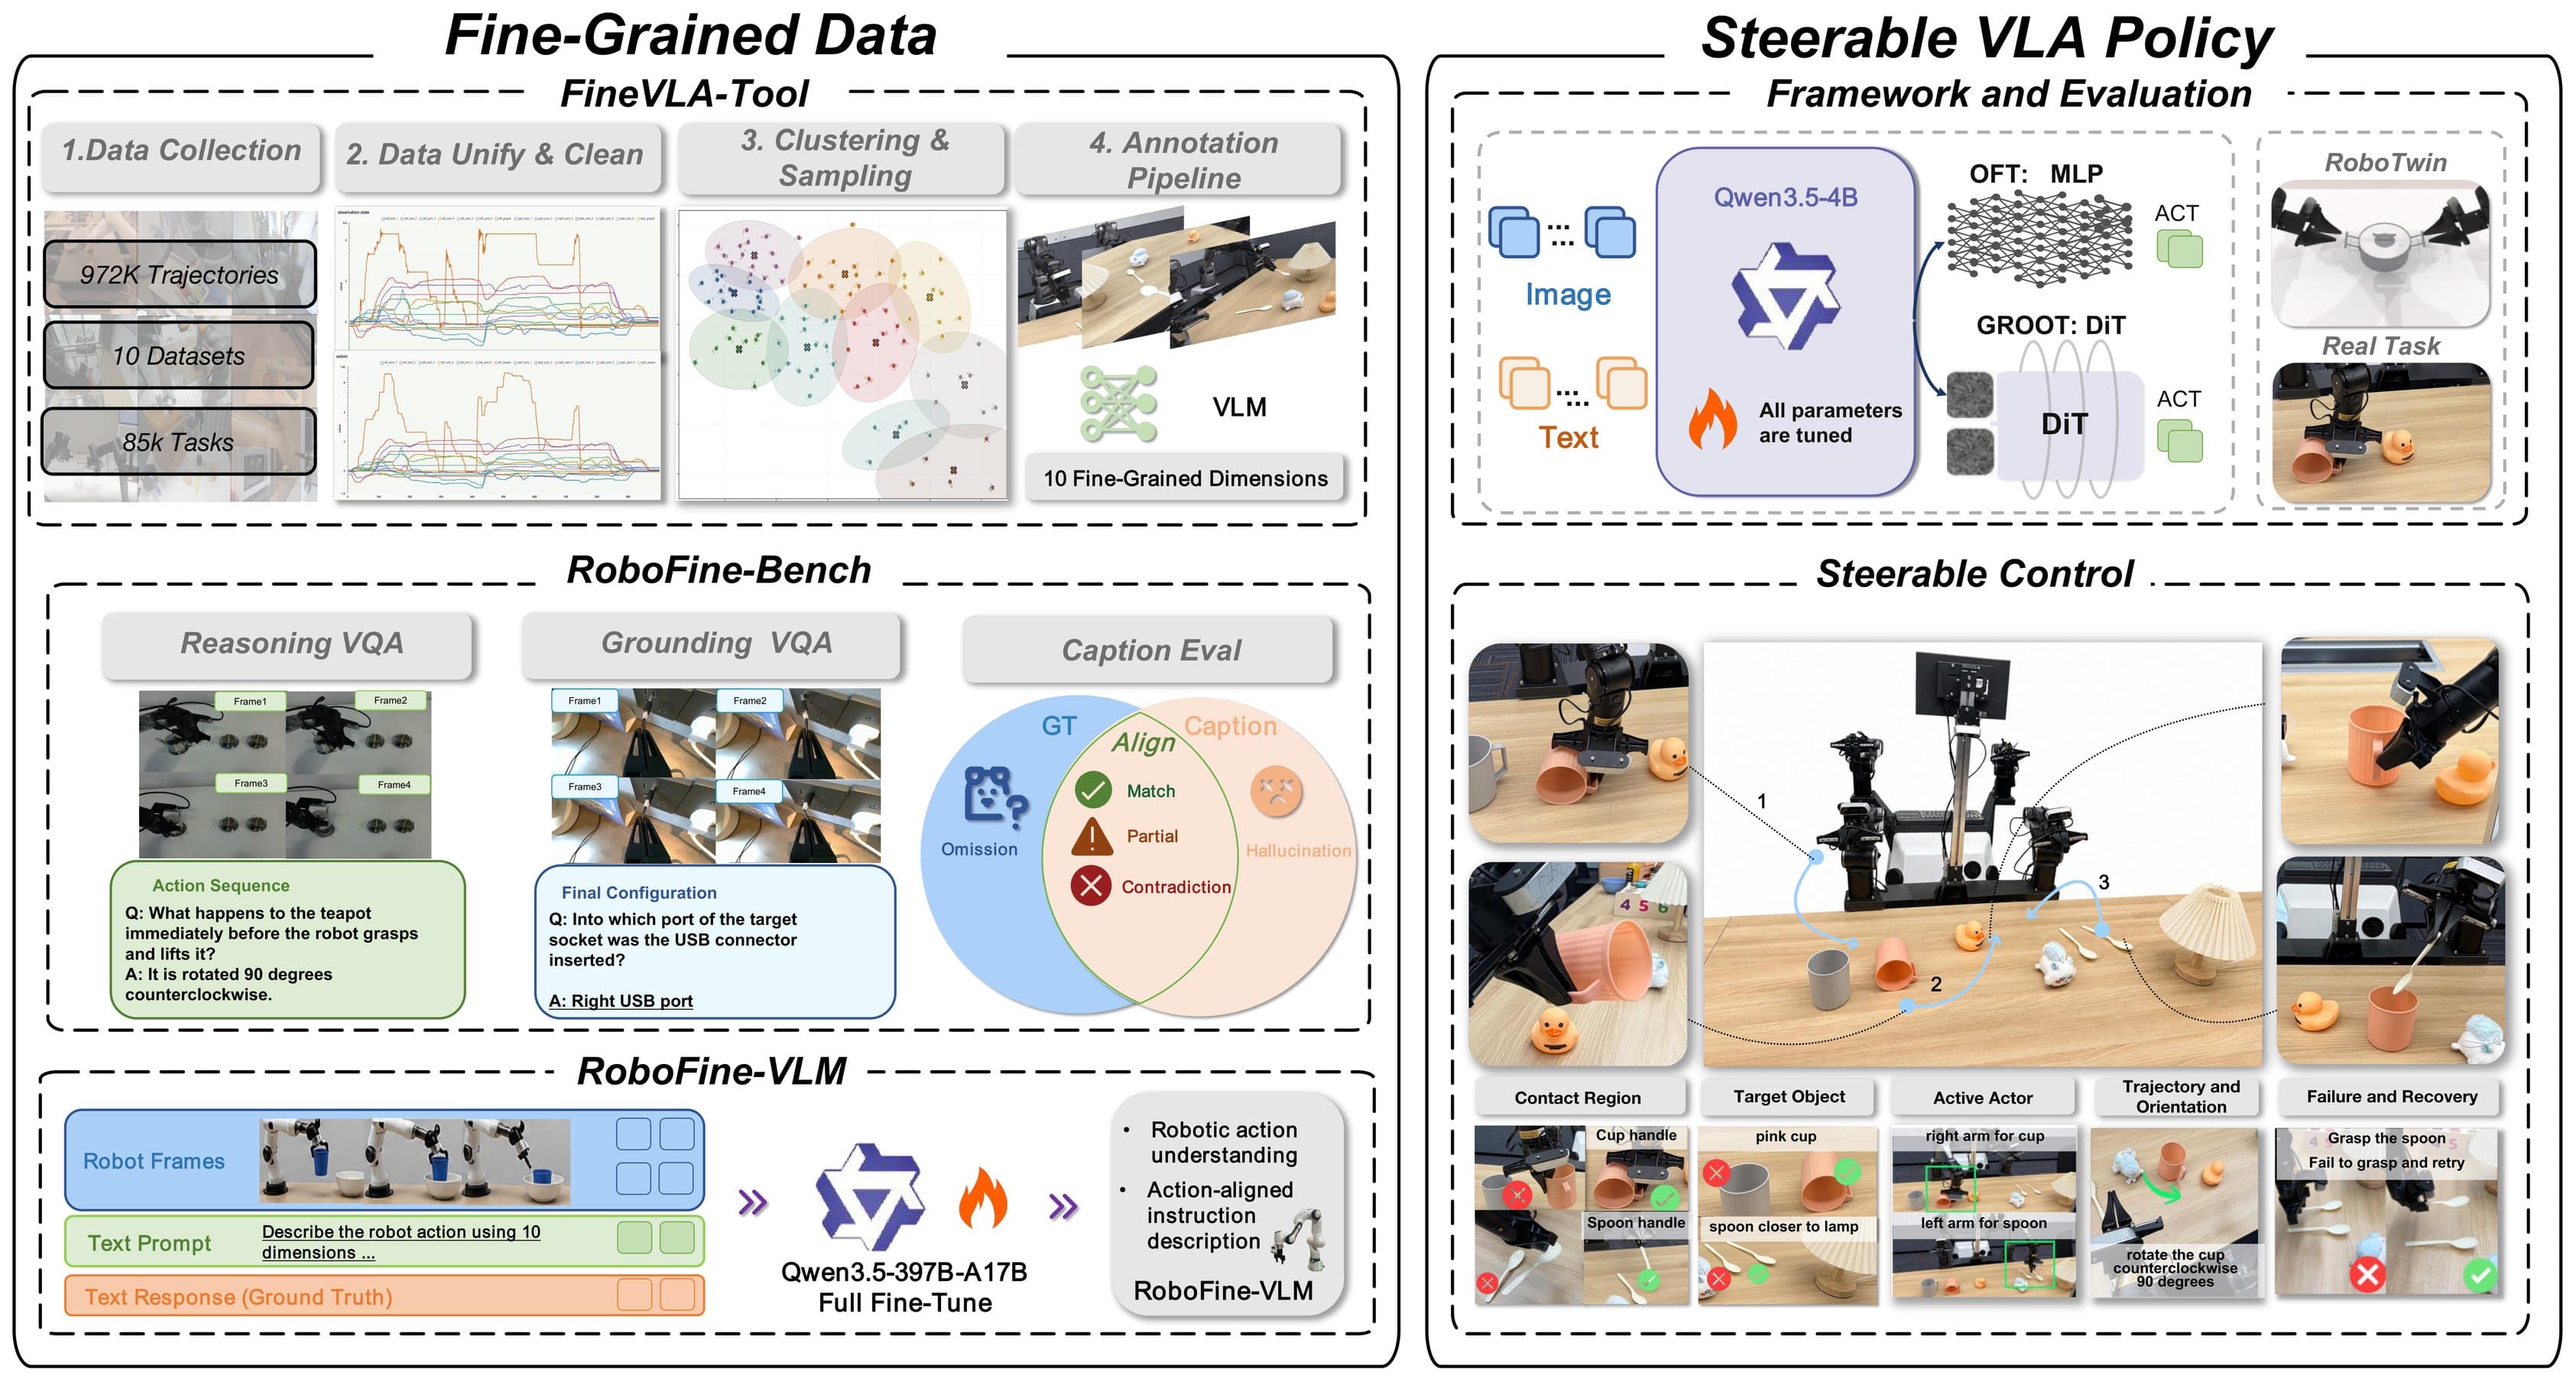
A practical FineVLA guide covering the paper idea, architecture, installation, training, inference, and results.
A practical comparison of Jetson Orin Nano, Orin NX, and cloud GPUs for humanoid robots across ROS 2, cameras, VLA inference, logging, training, and budget.
A practical guide to humanoid robot cameras: head RGB-D, wrist cameras, RealSense, OAK-D, latency, ROS 2, calibration, and affiliate placement.
A practical software stack for humanoid robots: realtime control, ROS 2, simulators, teleop data, LeRobot, VLA policies, deployment, and monitoring.
A practical roadmap for humanoid robot hardware: compute, actuators, cameras, IMU, power, safety, logging, and natural affiliate placements.

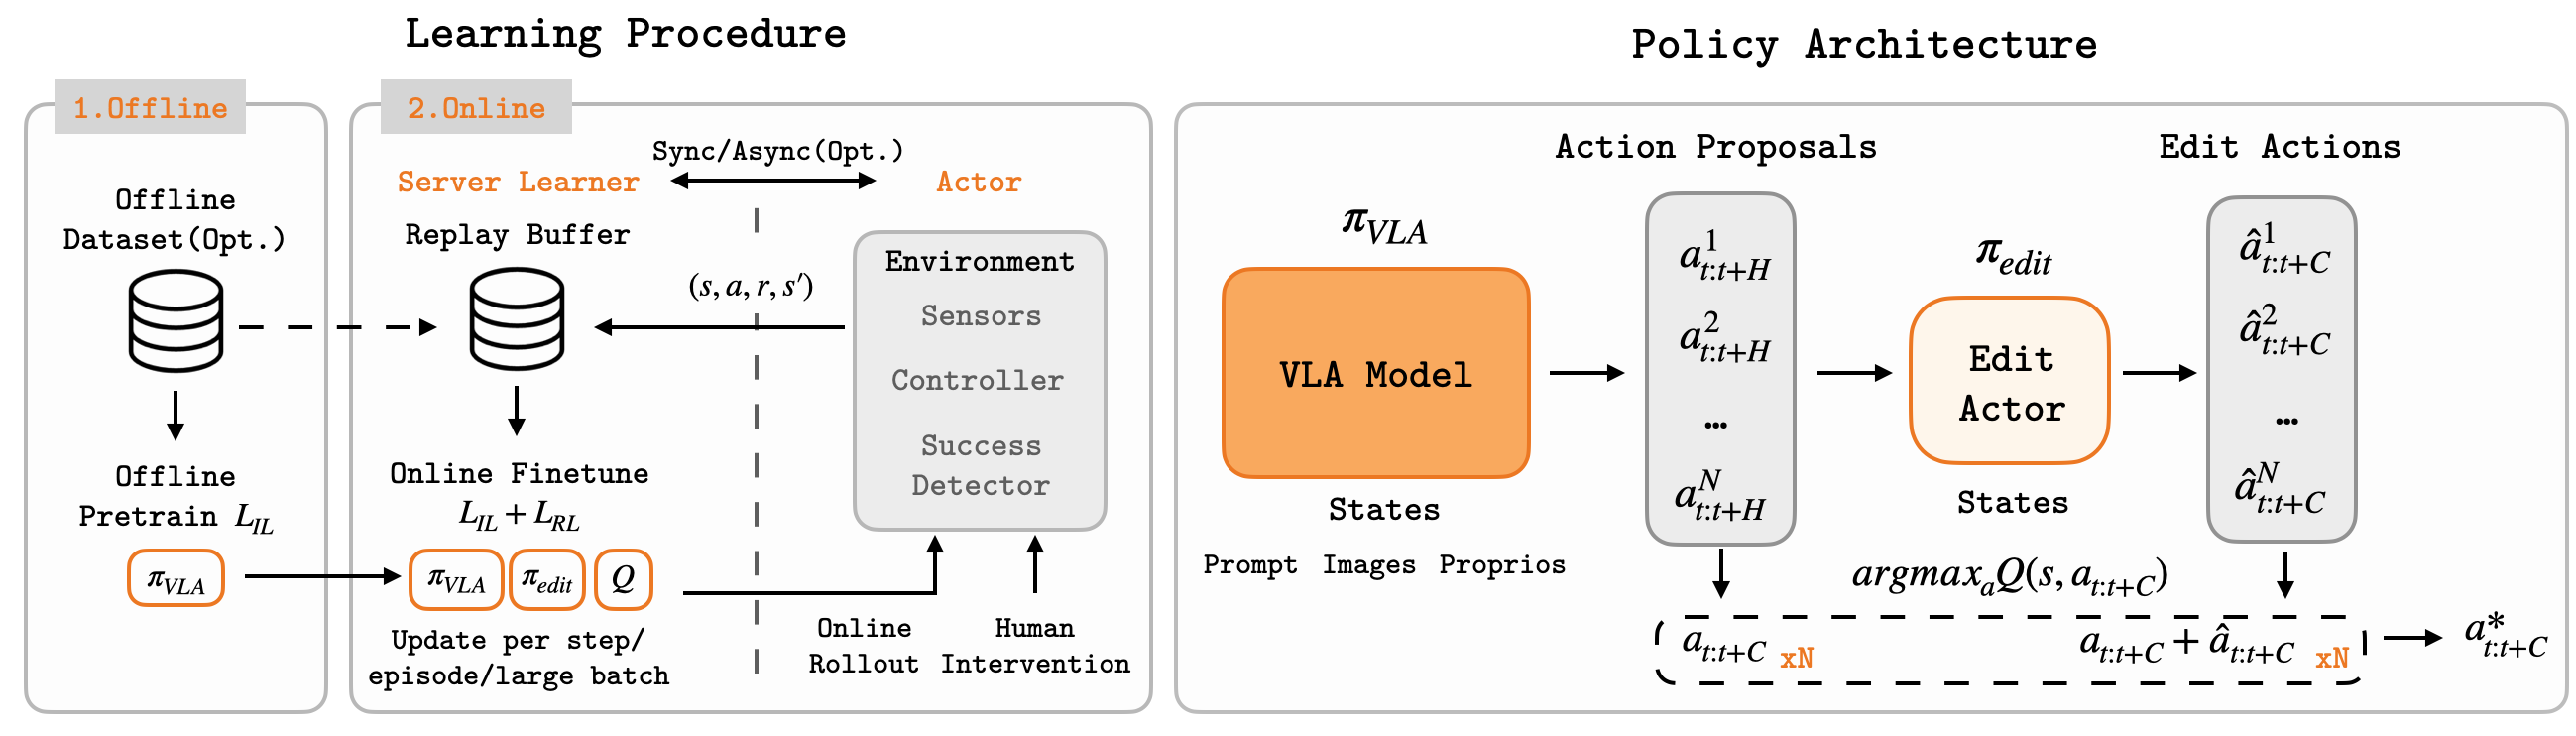
A practical guide to open-source EXPO-FT: fine-tuning π0.5 VLA with online RL in 19.1 minutes of robot data.

Guide to OpenHelix — install, train and deploy a Dual-System VLA achieving SOTA on CALVIN ABC-D with LLaVA-7B + 3D Diffuser Actor, beginner-friendly.