VnRoboVnRobo
AboutPricingBlogContact
🇻🇳VISign InStart Free Trial
🇻🇳VI
VnRobo logoVnRobo logo

AI infrastructure for next-generation industrial robots.

Product

  • Features
  • Pricing
  • Knowledge Base
  • Services

Company

  • About Us
  • Blog
  • Contact

Legal

  • Privacy Policy
  • Terms of Service

© 2026 VnRobo. All rights reserved.

Made with♥in Vietnam
VnRoboVnRobo
AboutPricingBlogContact
🇻🇳VISign InStart Free Trial
🇻🇳VI

All posts

Blog

Page 11 of 18

← Back to Blog
Tutorial
WholeBodyVLA Tutorial: Teleop → Train → Deploy Humanoid
wholebodyvlavlahumanoid
wholebody-vla

WholeBodyVLA Tutorial: Teleop → Train → Deploy Humanoid

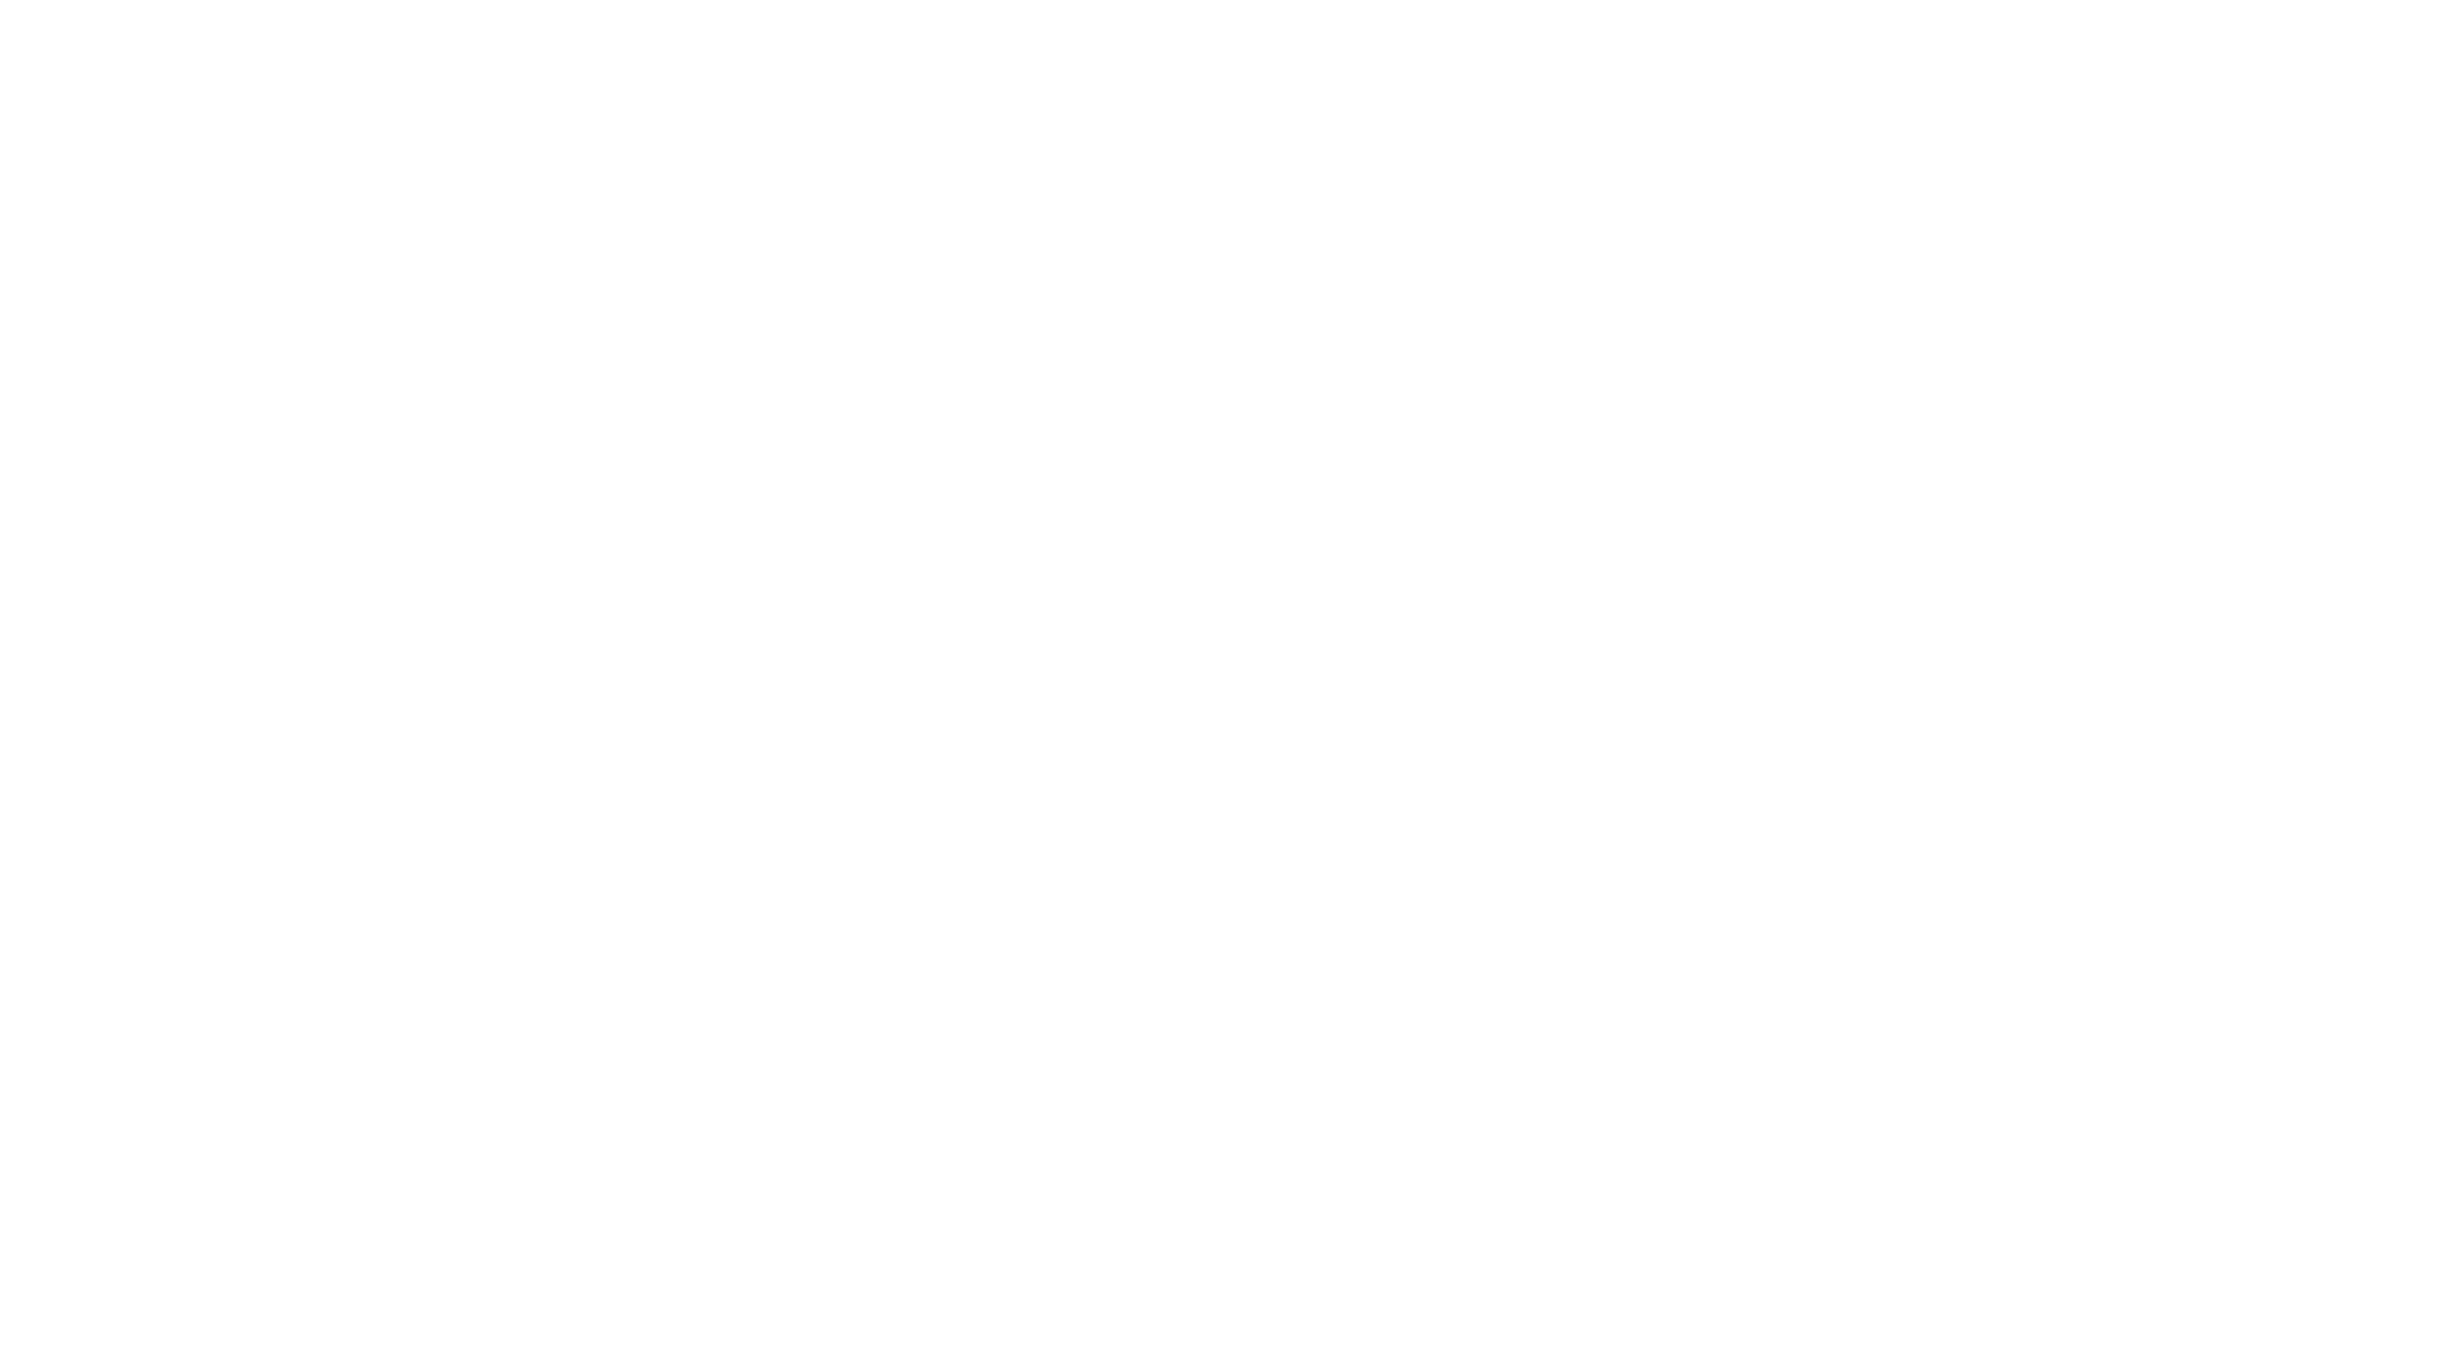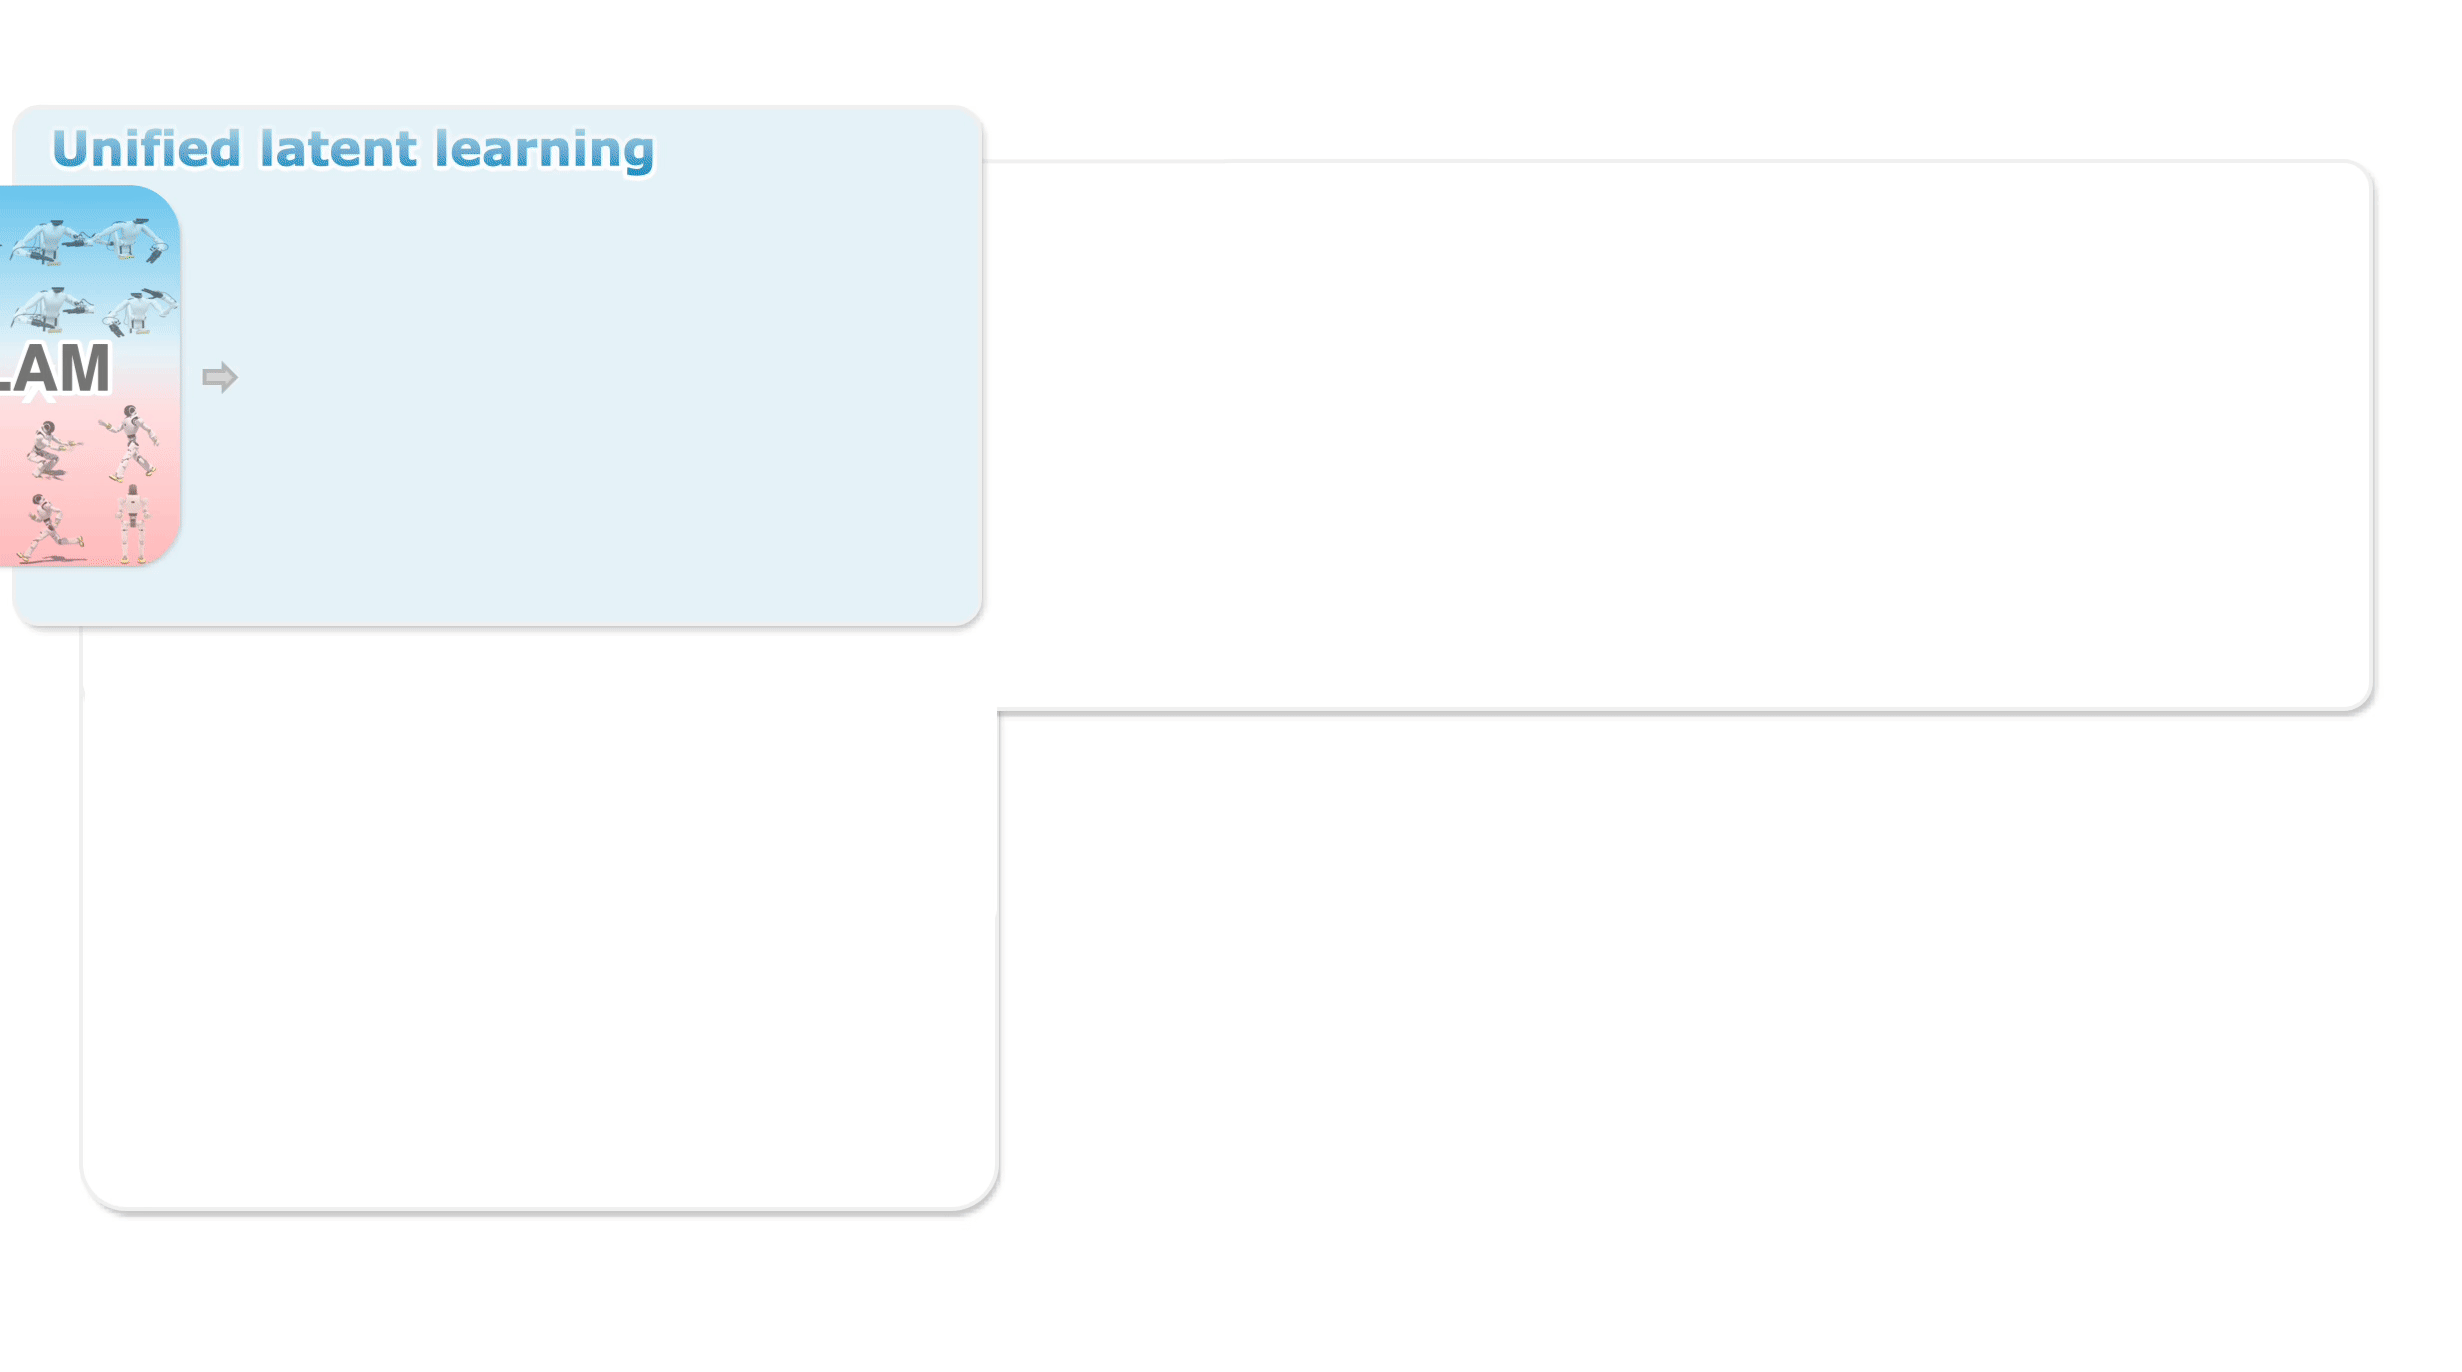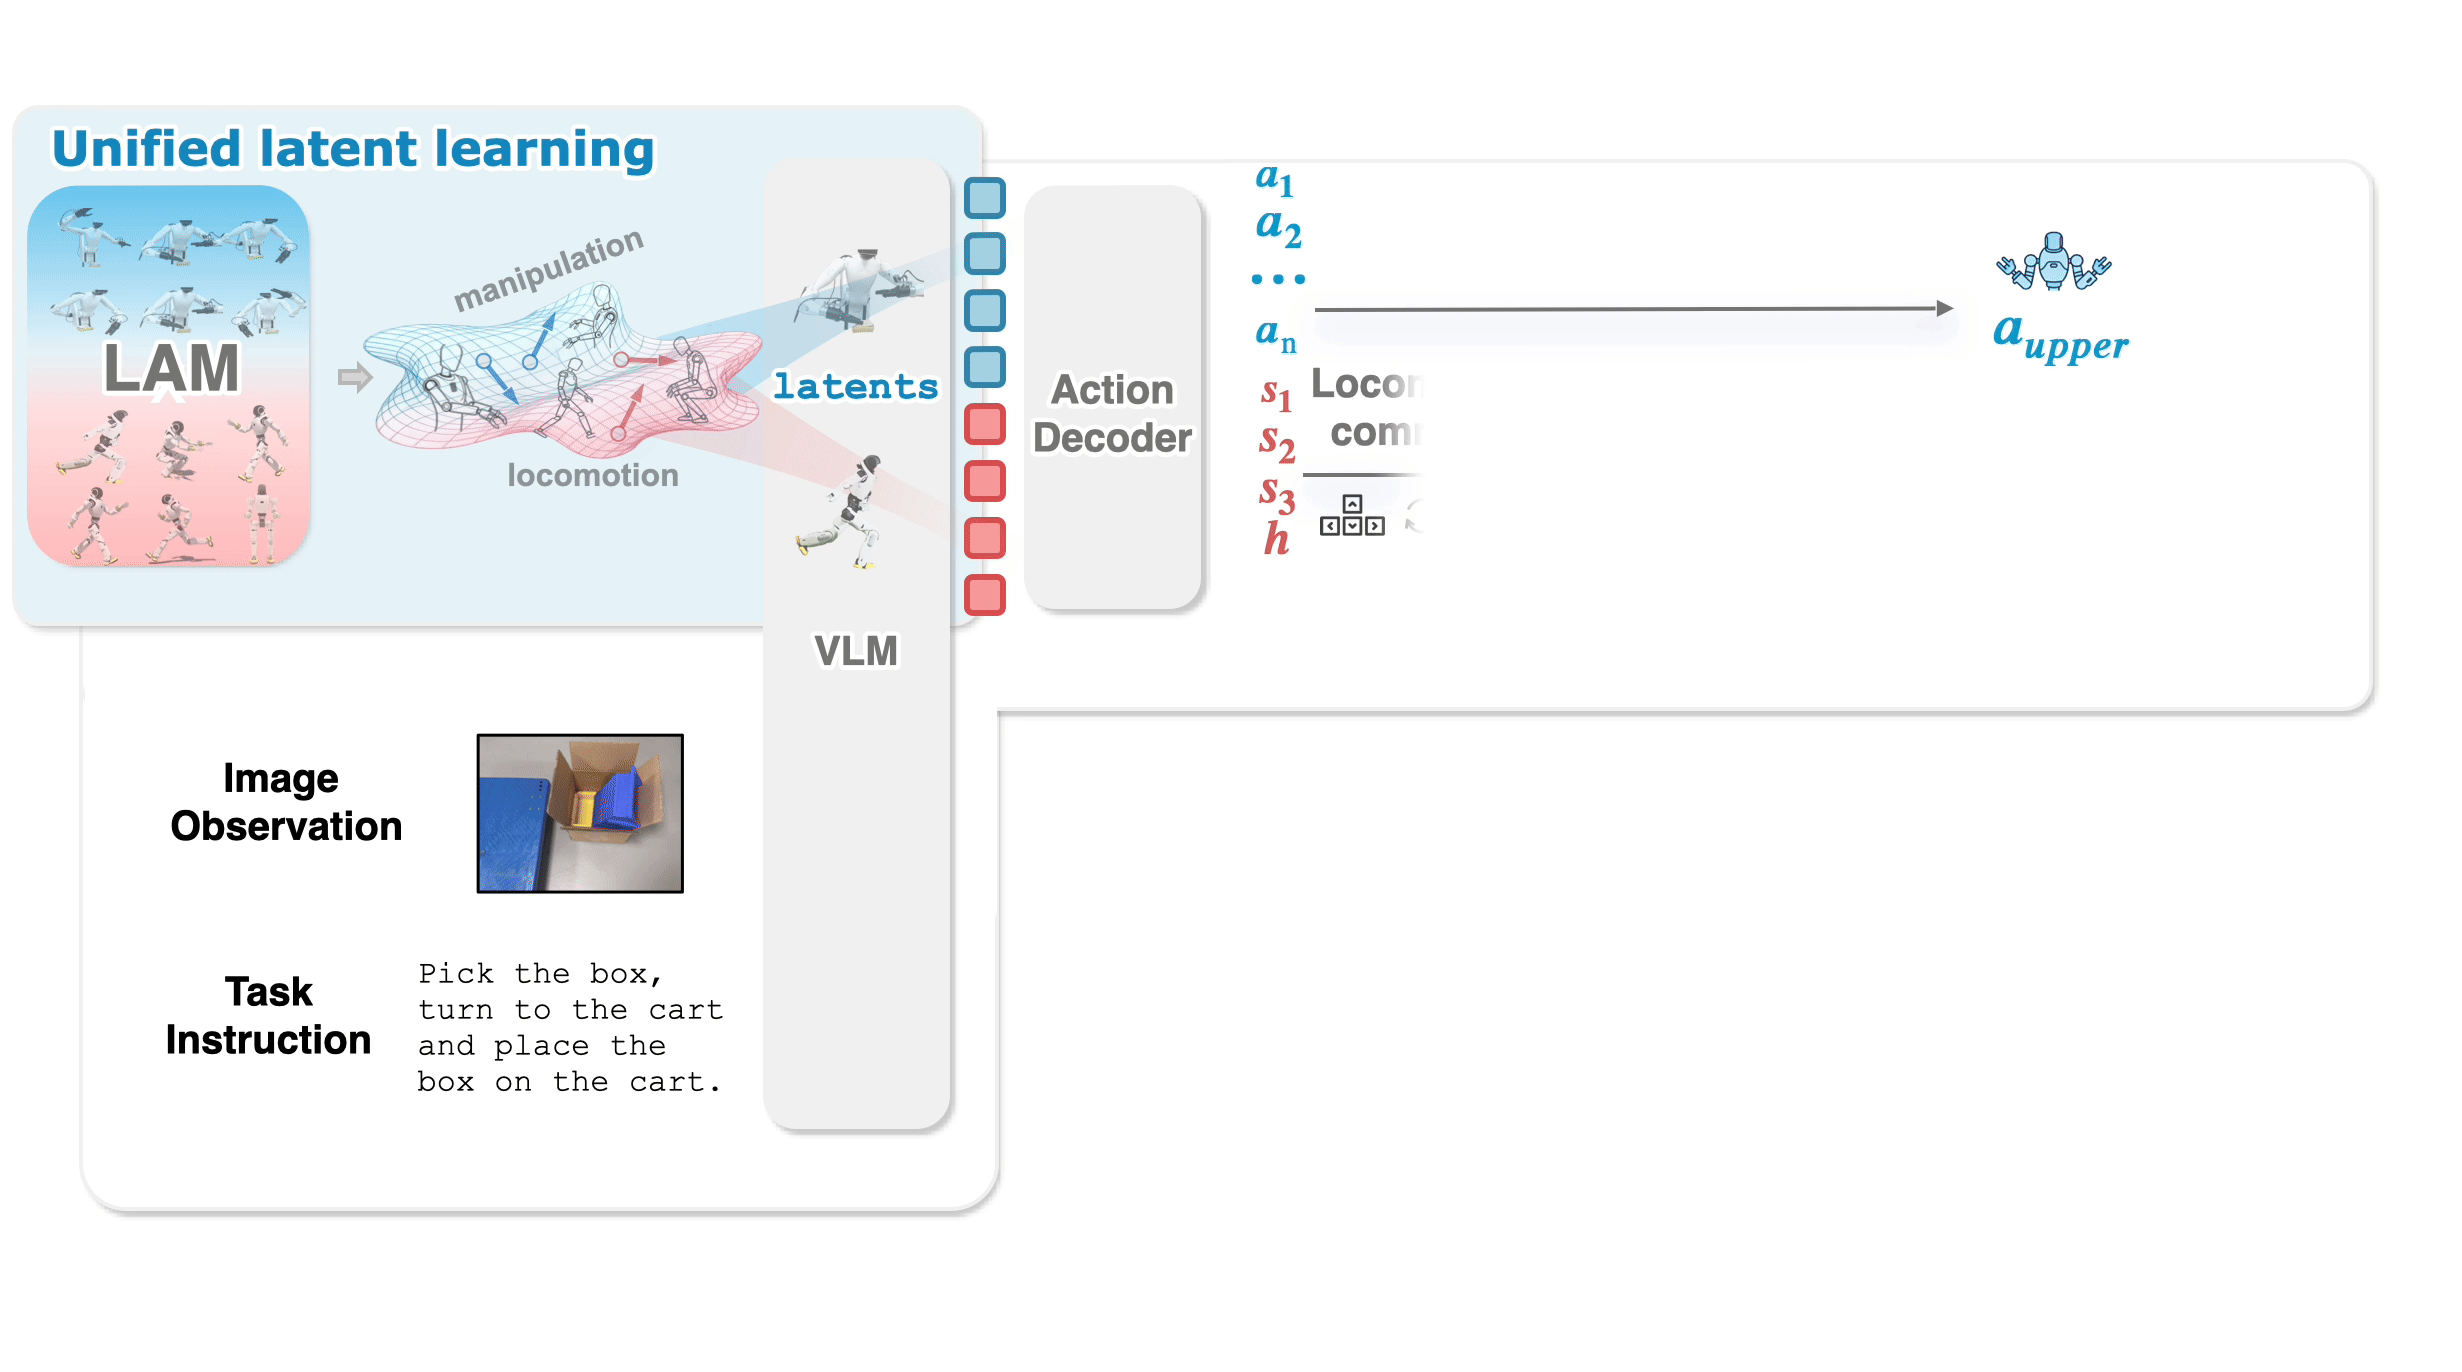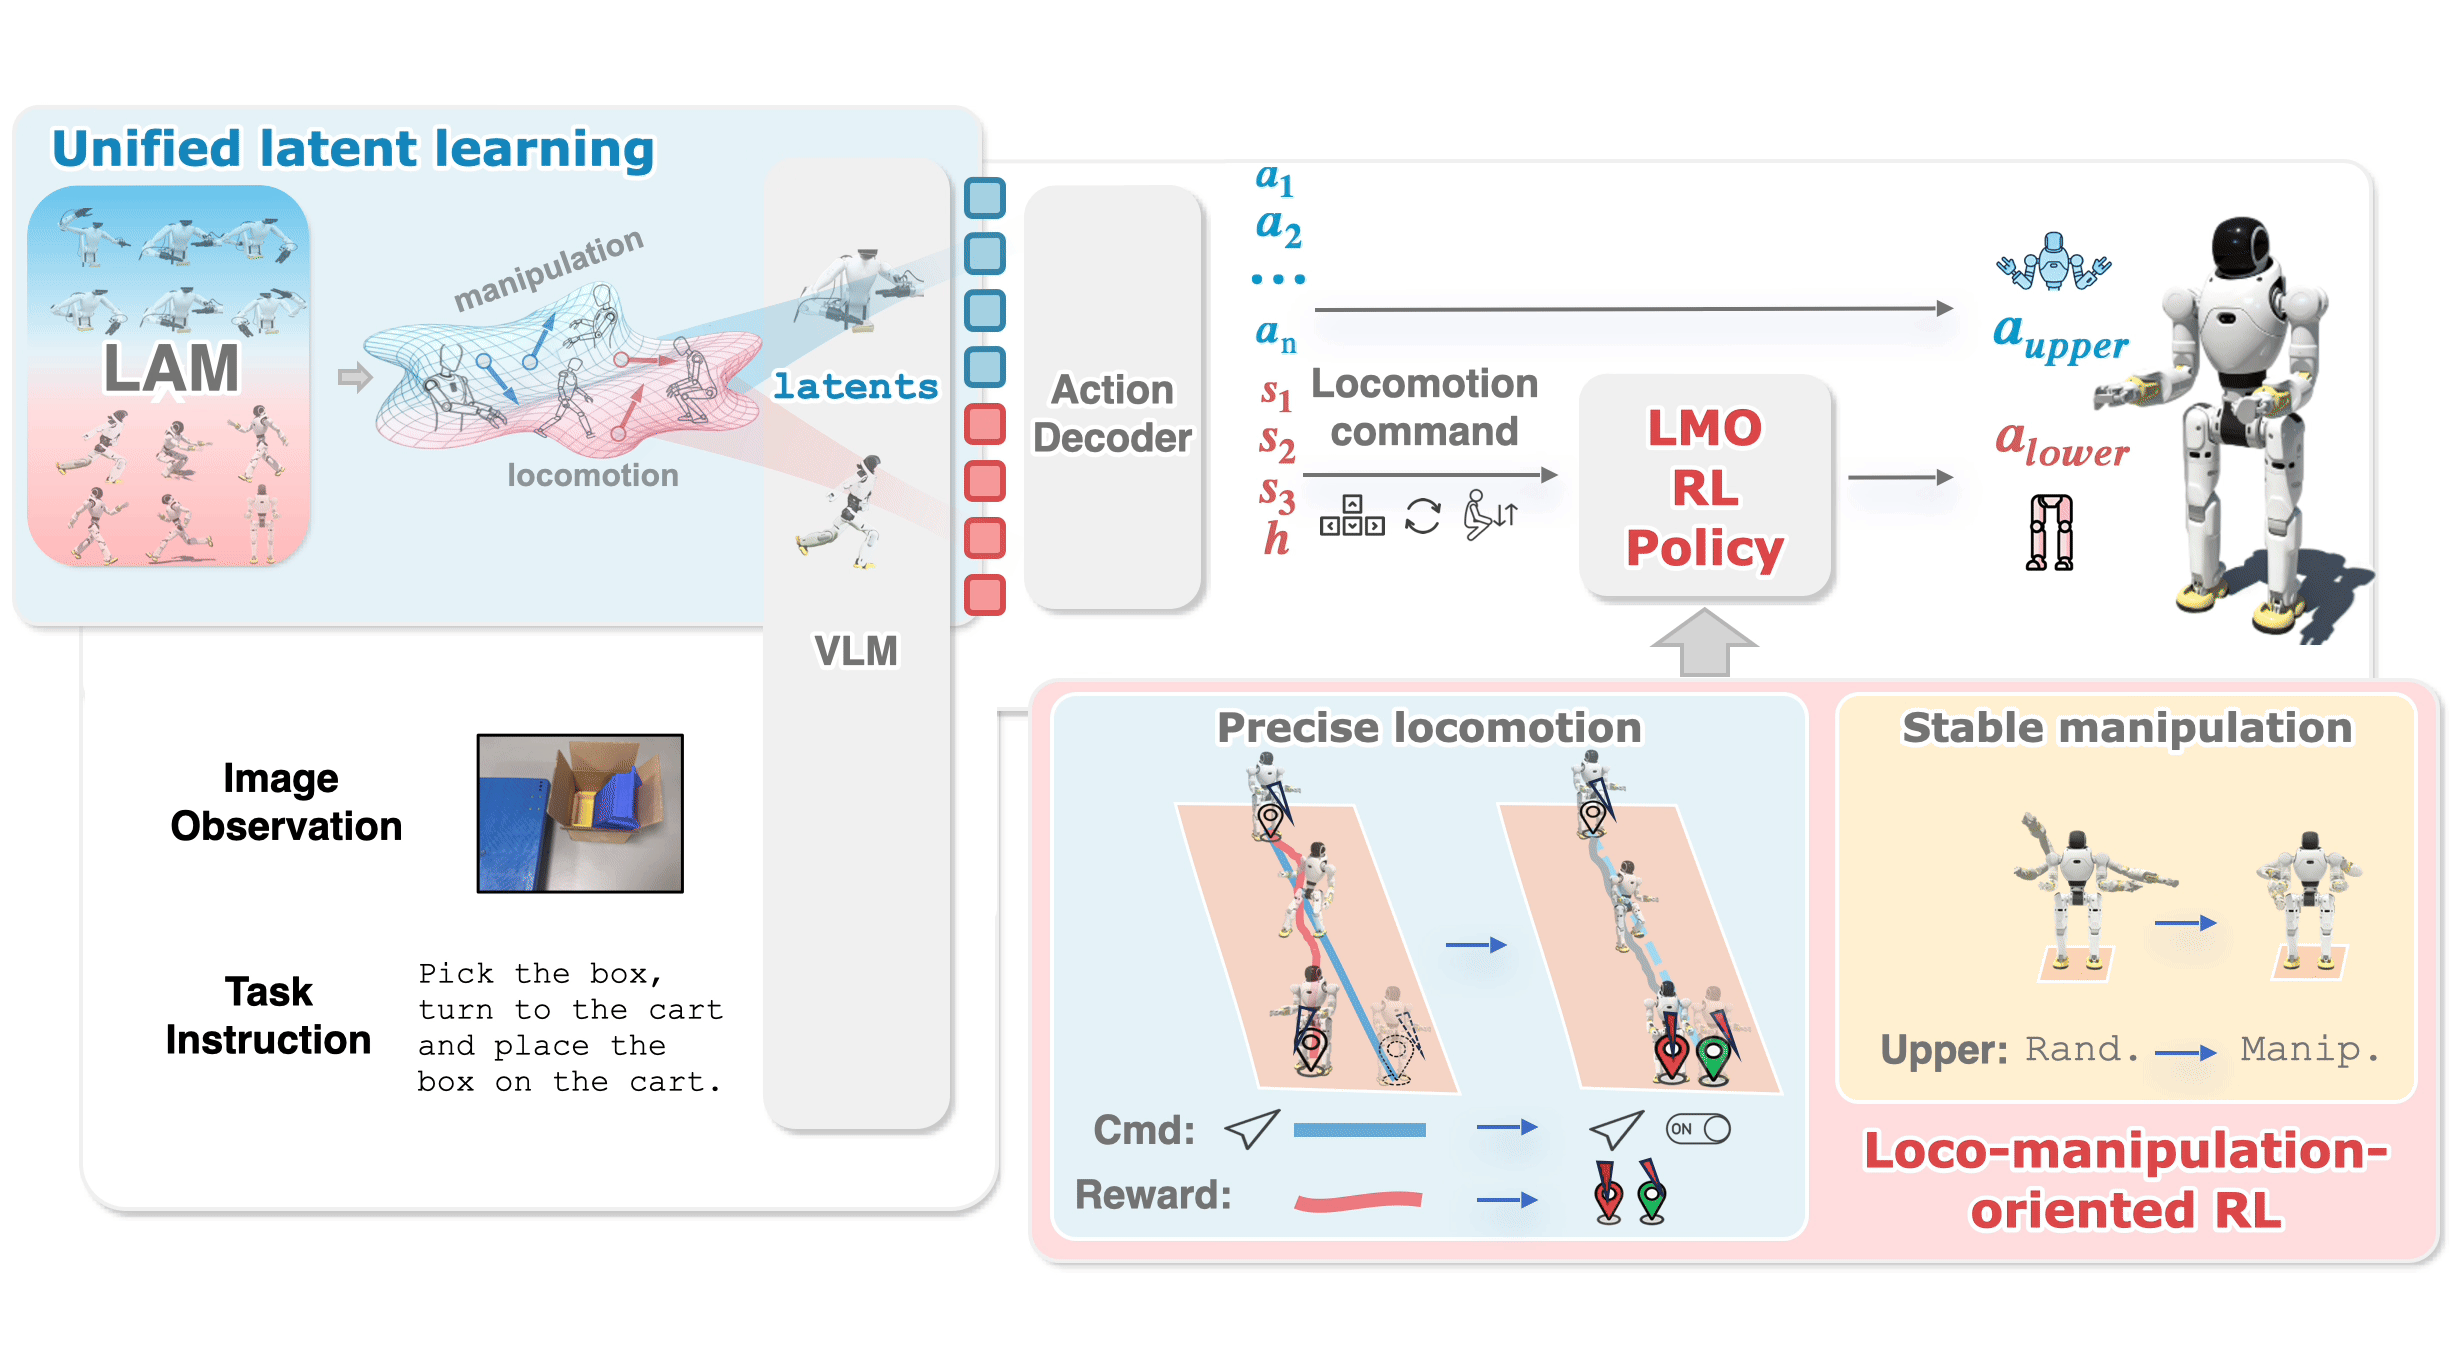
ICLR 2026 — hands-on pipeline from teleop collection through unified latent VLA training to whole-body loco-manipulation deployment on AgiBot X2.

5/11/202610 min read
NT
Tutorial
Ark v1.5: Python Framework for Robot Learning Sim-to-Real
ark-frameworkpythonimitation-learning
ai

Ark v1.5: Python Framework for Robot Learning Sim-to-Real

A step-by-step guide to Ark v1.5 — Python-first robot learning framework with a Gym-style API, native ROS, ACT and Diffusion Policy out of the box.

5/8/202610 min read
NT
Tutorial
Booster Gym: Train Humanoid T1 Sim-to-Real with Isaac Gym
humanoidisaac-gymreinforcement-learning
humanoid

Booster Gym: Train Humanoid T1 Sim-to-Real with Isaac Gym

Detailed guide to Booster Gym — open-source end-to-end RL framework training Booster T1 humanoid walking from teleop to real-world deployment.

5/6/202611 min read
NT
Tutorial
VLA-0: State-of-the-Art Robot VLA Without Changes
vlanvidianvlabs
wholebody-vla

VLA-0: State-of-the-Art Robot VLA Without Changes

NVIDIA NVlabs proves action as text reaches 94.7% on LIBERO, beating pi_0 and GR00T-N1 with zero architecture modification — just Qwen2.5-VL-3B.

5/4/202612 min read
NT
Tutorial
RDT2: Zero-Shot Cross-Embodiment Foundation Model for Bimanual UR5e/Franka
rdt2foundation-modelbimanual
wholebody-vla

RDT2: Zero-Shot Cross-Embodiment Foundation Model for Bimanual UR5e/Franka

Detailed guide to RDT2 from THU-ML — a foundation model that zero-shot deploys to bimanual UR5e and Franka, with open-source code.

5/1/20269 min read
NT
Tutorial
SO-101 Sim-to-Real Training: Isaac Lab & LeRobot Guide
so-101isaac-lablerobot
manipulation

SO-101 Sim-to-Real Training: Isaac Lab & LeRobot Guide

Step-by-step guide to train SO-101 robot arm in NVIDIA Isaac Lab, collect teleop data, fine-tune GR00T N1.5, and deploy the policy on real hardware.

4/29/202611 min read
NT
Tutorial
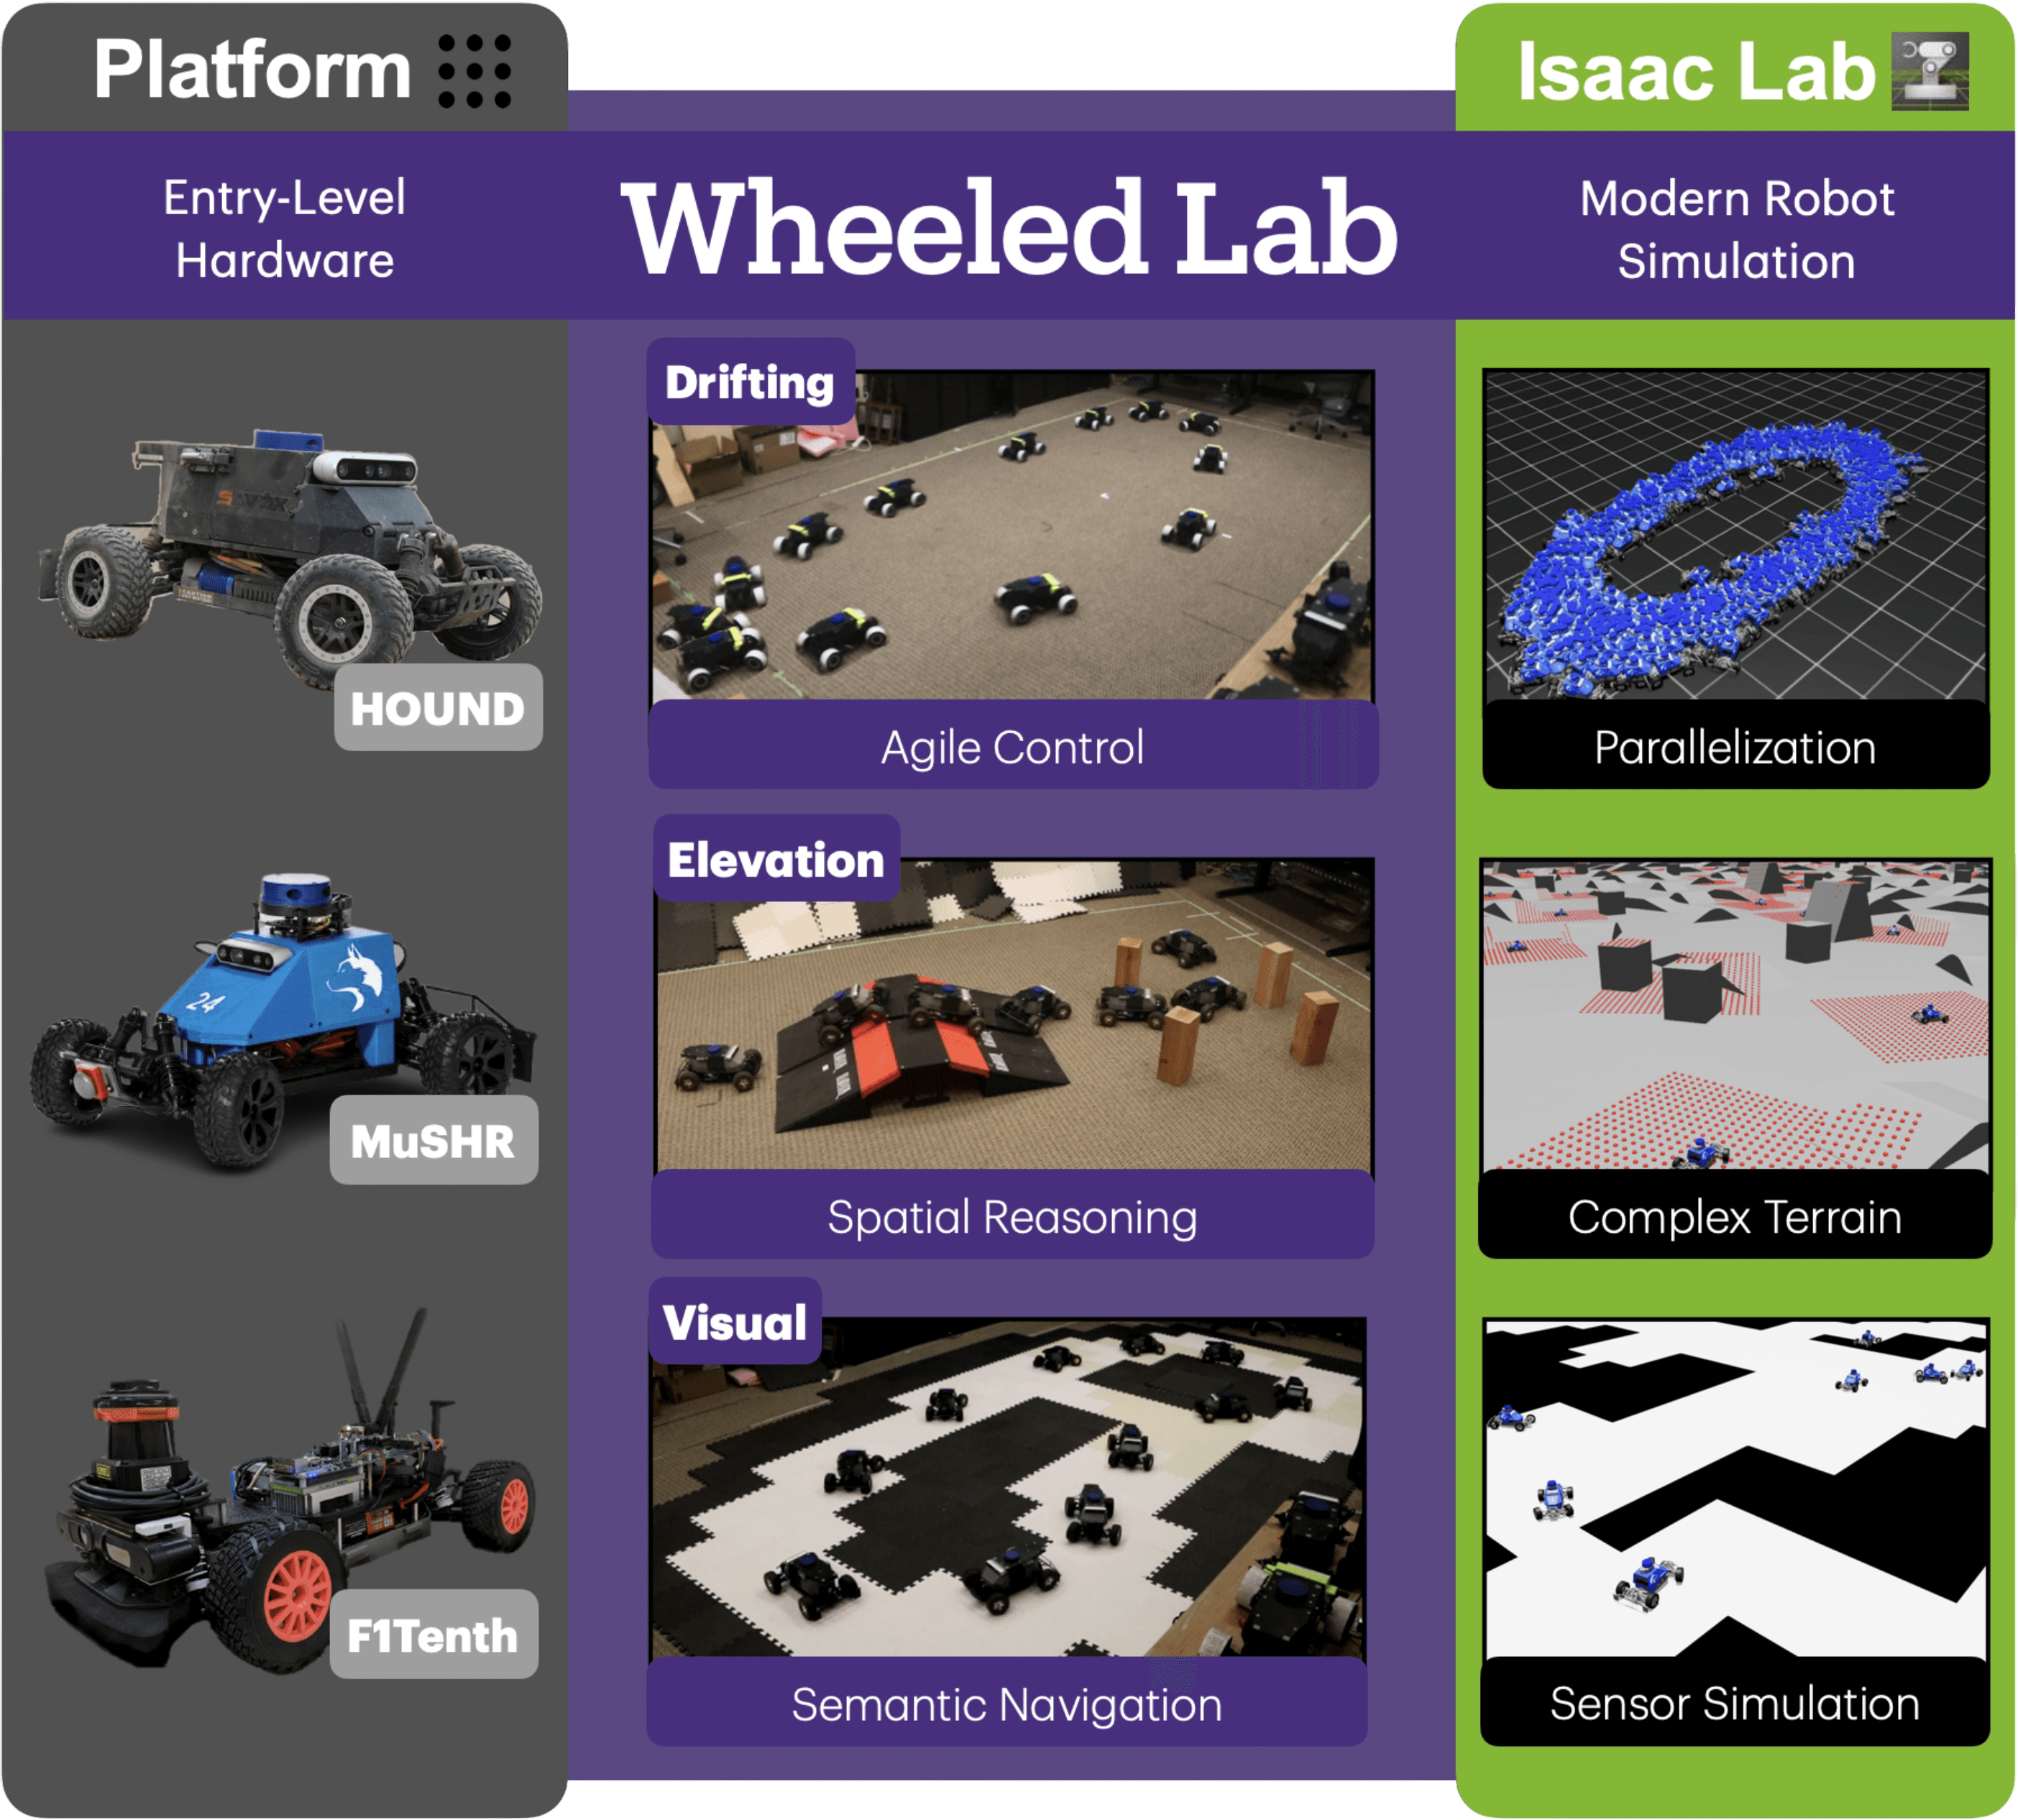
Wheeled Lab: Train RC Car Drift Sim-to-Real with Isaac Lab
isaac-labsim2realwheeled-robot
simulation

Wheeled Lab: Train RC Car Drift Sim-to-Real with Isaac Lab

Beginner-friendly walkthrough of Wheeled Lab — open-source ecosystem to train RC cars to drift, climb, and visually navigate in Isaac Lab and deploy zero-shot t

4/27/20269 min read
NT
Tutorial
Humanoid
humanoidreinforcement-learningsac
humanoid

LIFT humanoid ICLR 2026: SAC pretrain + world model finetune

Reproduce LIFT (ICLR 2026): pretrain SAC in MuJoCo Playground, then sim2sim fine-tune a physics-informed world model in Brax for Booster T1 and Unitree G1.

4/24/202611 min read
NT
Research
DeepMind Ping-Pong Robot: AI Plays Table Tennis
ai-perceptionreinforcement-learningmanipulation
research

DeepMind Ping-Pong Robot: AI Plays Table Tennis

How Google DeepMind built a table tennis robot that beats amateur humans using hierarchical RL, LLC-HLC architecture, and zero-shot sim-to-real transfer.

4/22/202610 min read
NT
Tutorial
Xiaomi-Robotics-0: Run 4.7B VLA on Consumer GPU
vlaqwendiffusion-transformer
ai

Xiaomi-Robotics-0: Run 4.7B VLA on Consumer GPU

Step-by-step guide to install and run Xiaomi-Robotics-0 — a 4.7B VLA combining Qwen3-VL and Diffusion Transformer with 80ms real-time inference on RTX 4090.

4/22/202610 min read
NT
Deep Dive
Robot AI
dense-modelsrobot-perception6d-pose-estimation
ai

Dense Models in Robotics: From DON to DenseMatcher

Explore Dense Object Nets, DenseFusion, and DenseMatcher — three dense visual descriptor technologies revolutionizing how robots see and grasp objects.

4/22/202612 min read
NT
Research
OpenHelix: Dual-System VLA for Robot Manipulation
vladual-systemrobot-manipulation
wholebody-vla

OpenHelix: Dual-System VLA for Robot Manipulation

OpenHelix: the open-source dual-system VLA pairing LLaVA-7B (System 2) with a 3D diffusion policy (System 1) via a learned ACT token, achieving SOTA on CALVIN.

4/21/202610 min read
NT
Previous1…910111213…18Next
VnRobo logoVnRobo logo

AI infrastructure for next-generation industrial robots.

Product

  • Features
  • Pricing
  • Knowledge Base
  • Services

Company

  • About Us
  • Blog
  • Contact

Legal

  • Privacy Policy
  • Terms of Service

© 2026 VnRobo. All rights reserved.

Made with♥in Vietnam