All posts
Page 12 of 18

Hands-on guide to AGIBOT WORLD 2026 — the world's largest real-world robot dataset, the GO-1 ViLLA model, installation walkthrough, and the ICRA 2026 challenge.

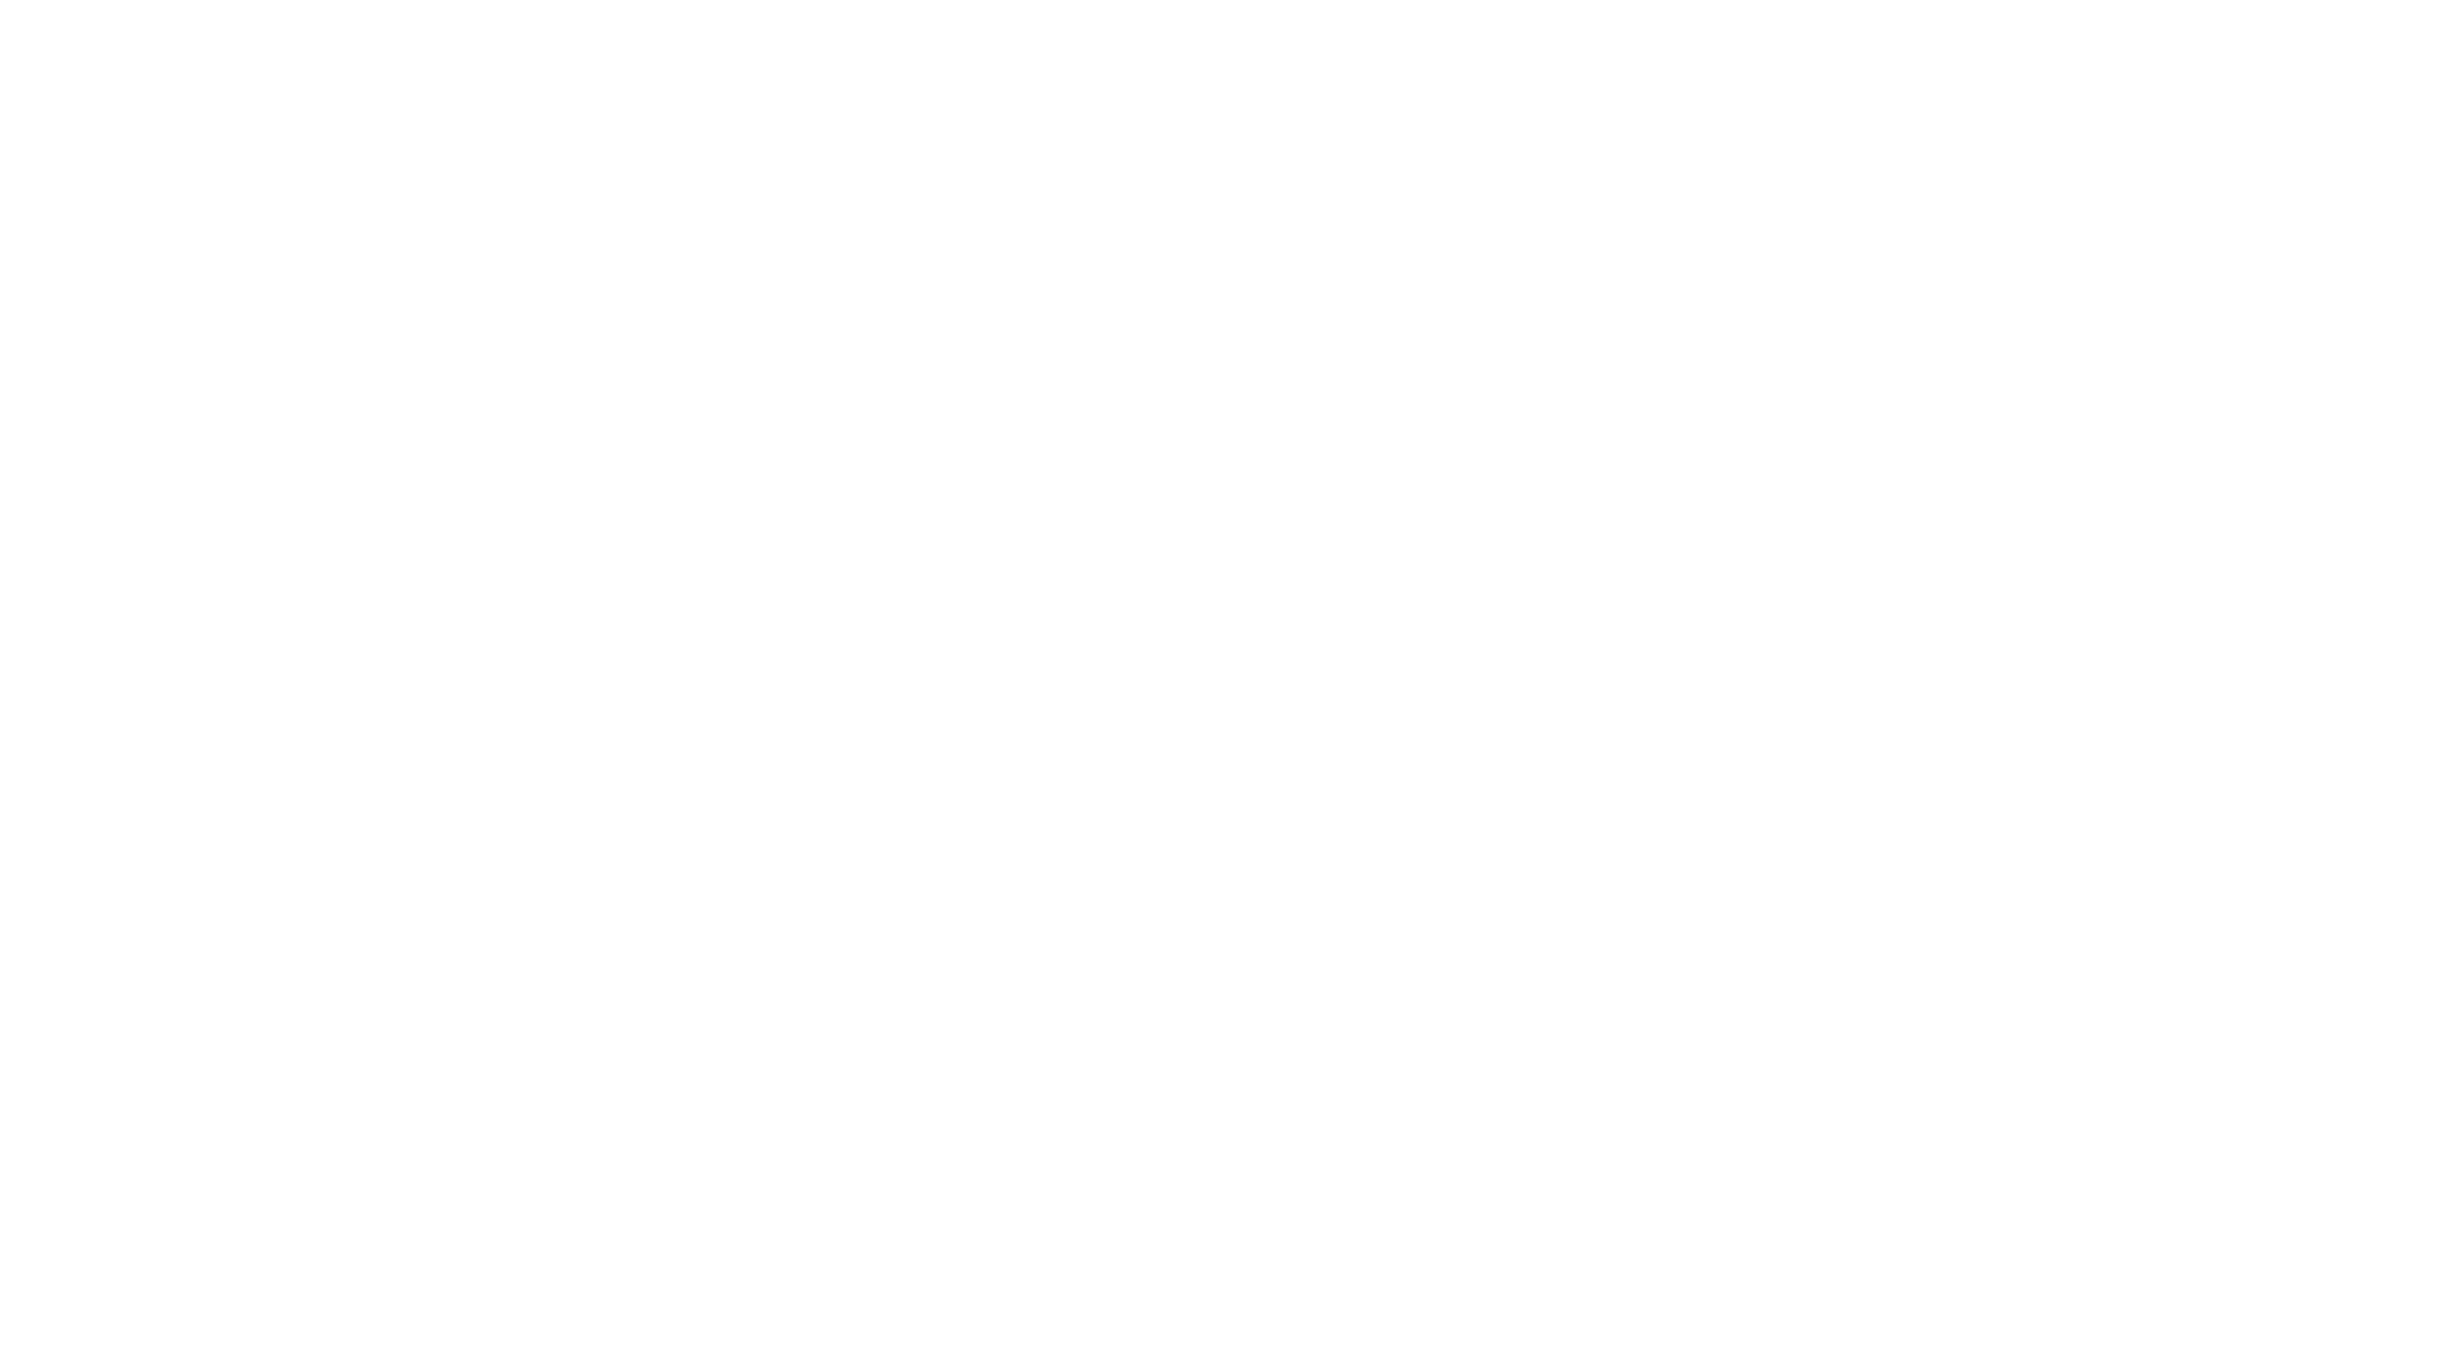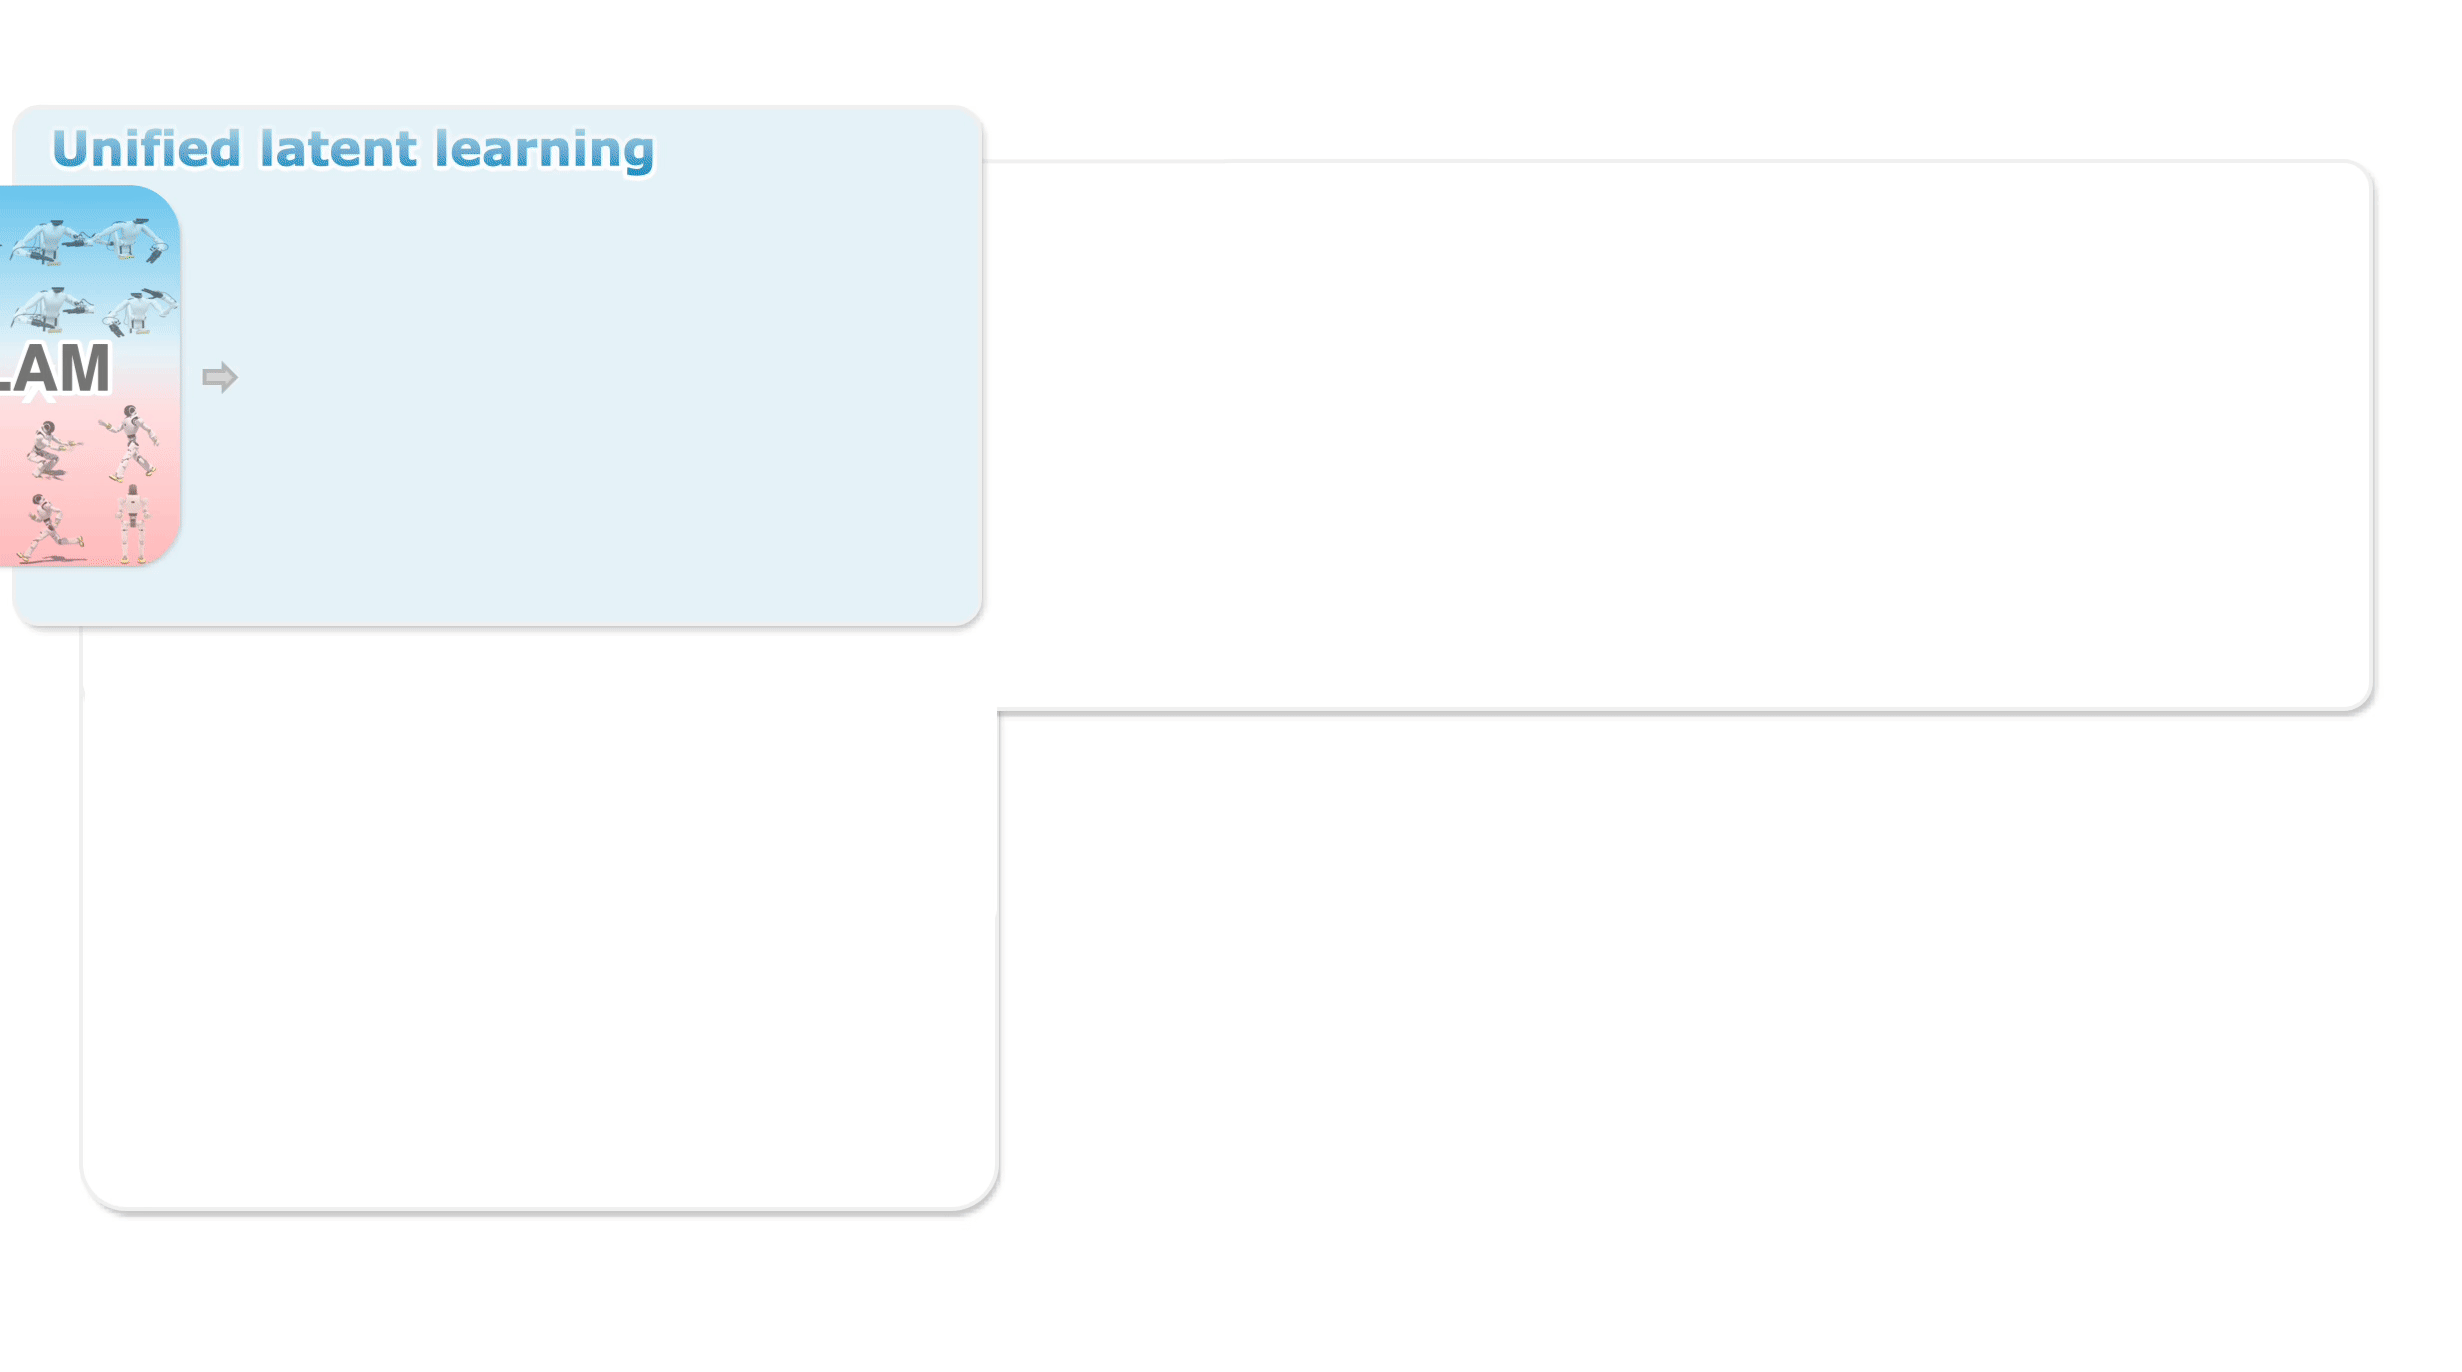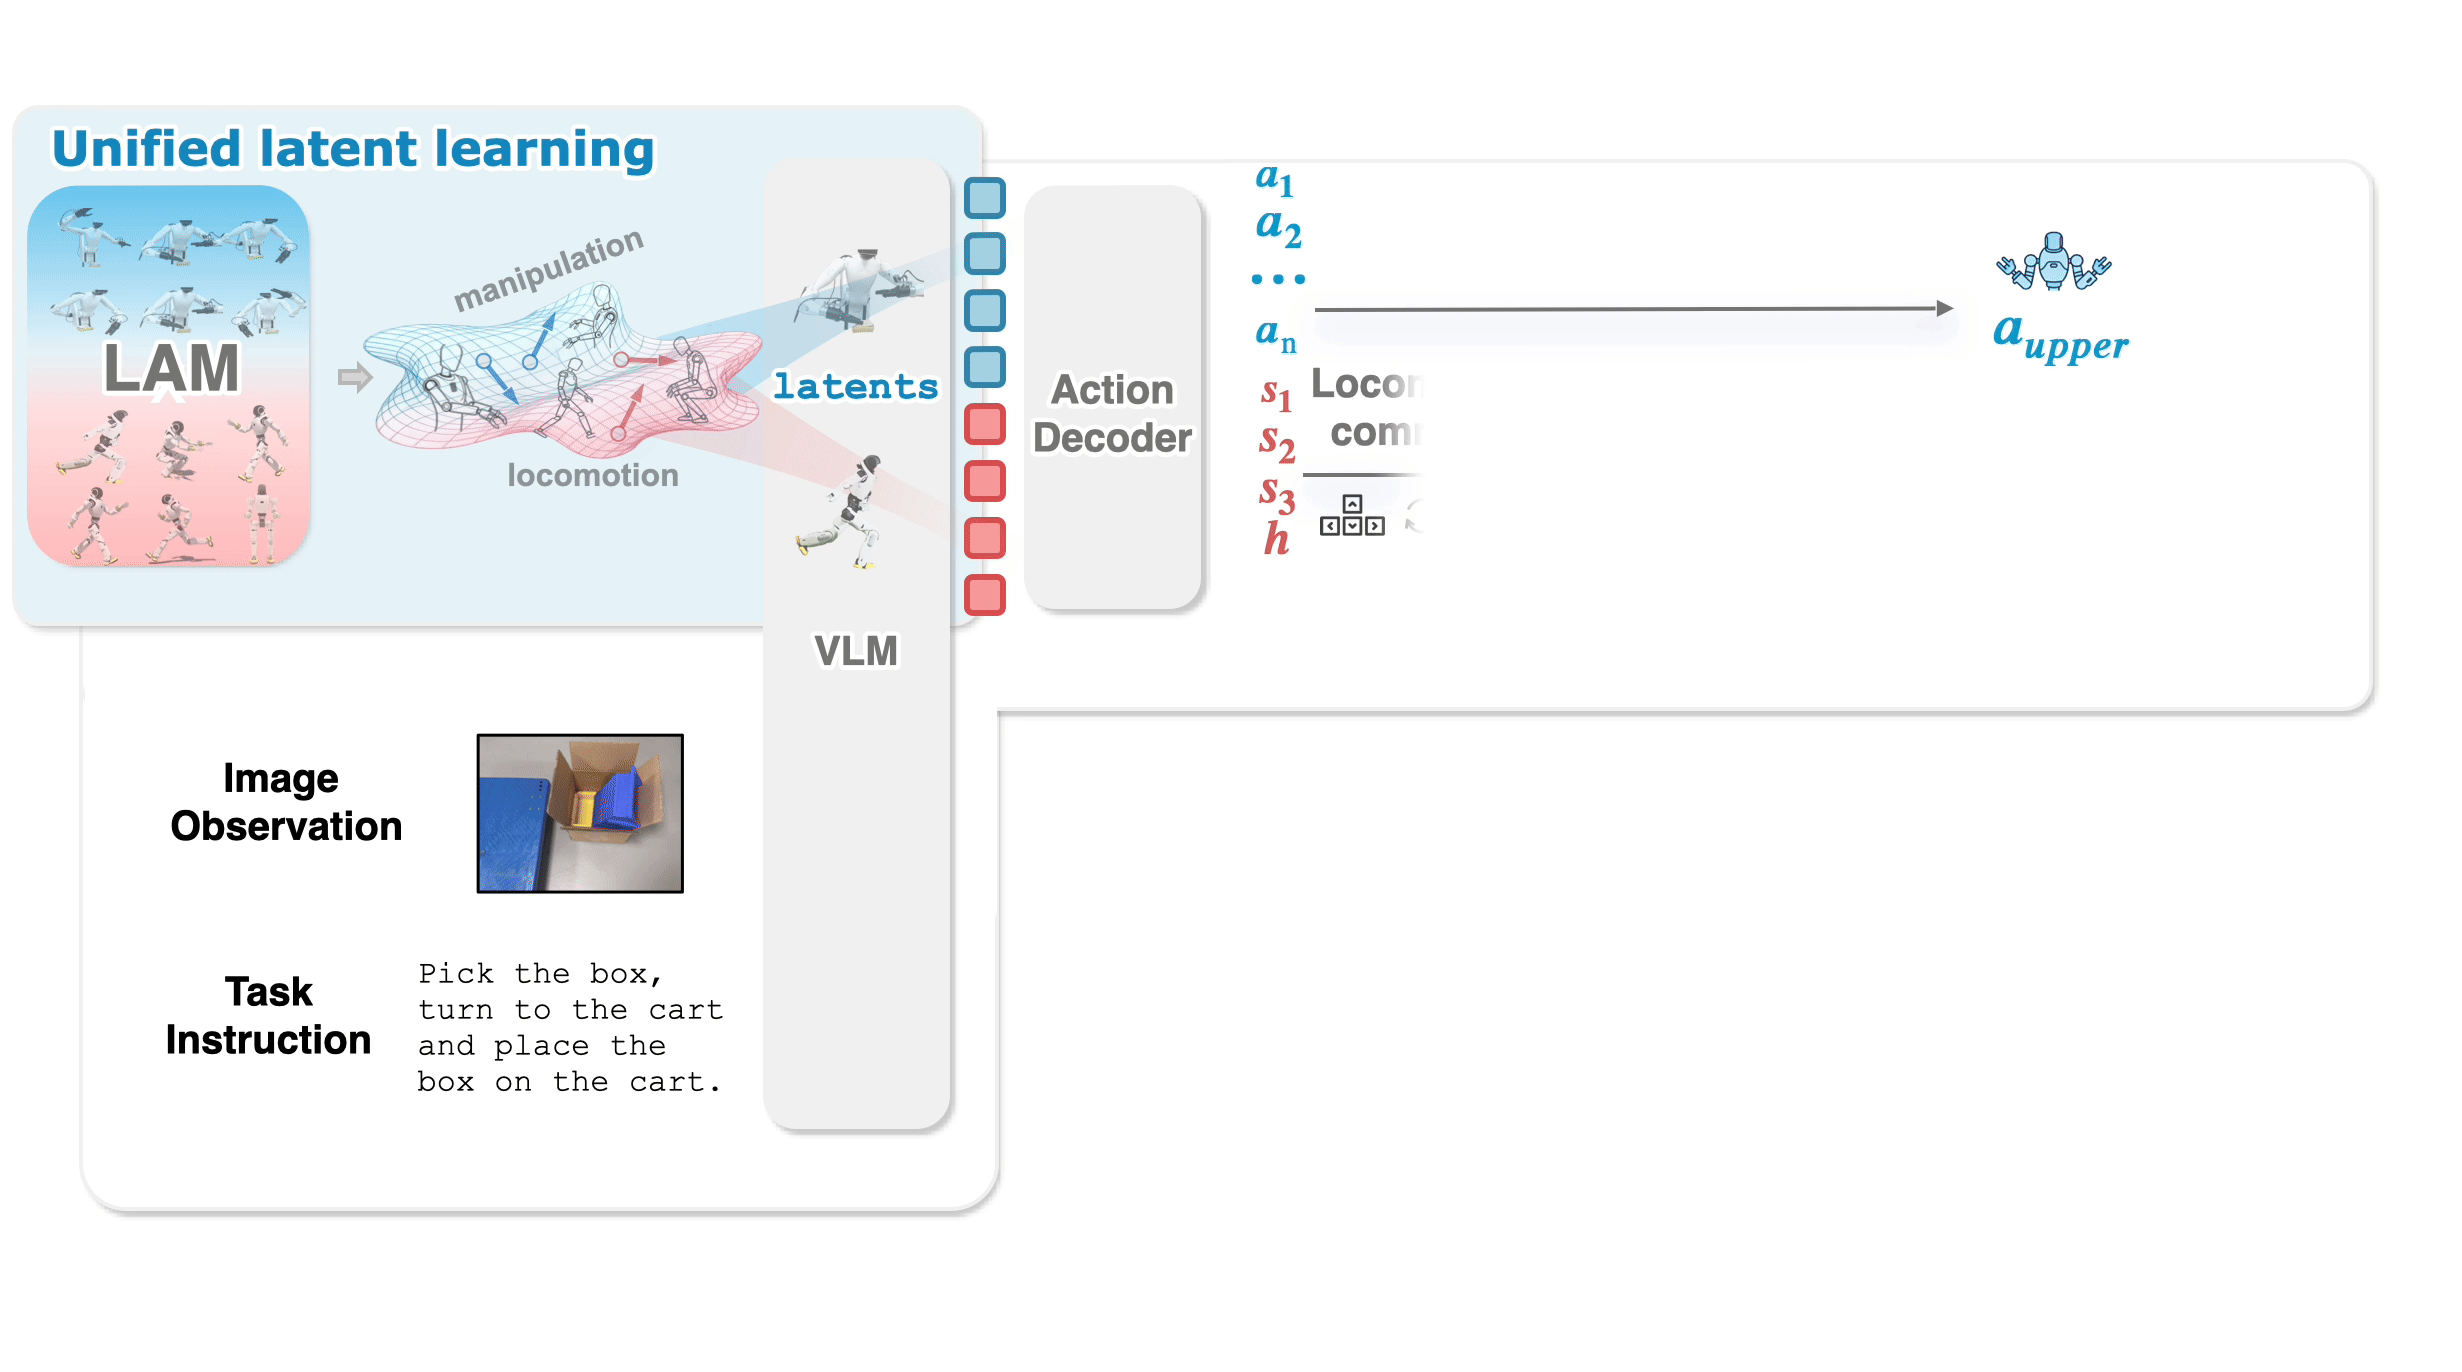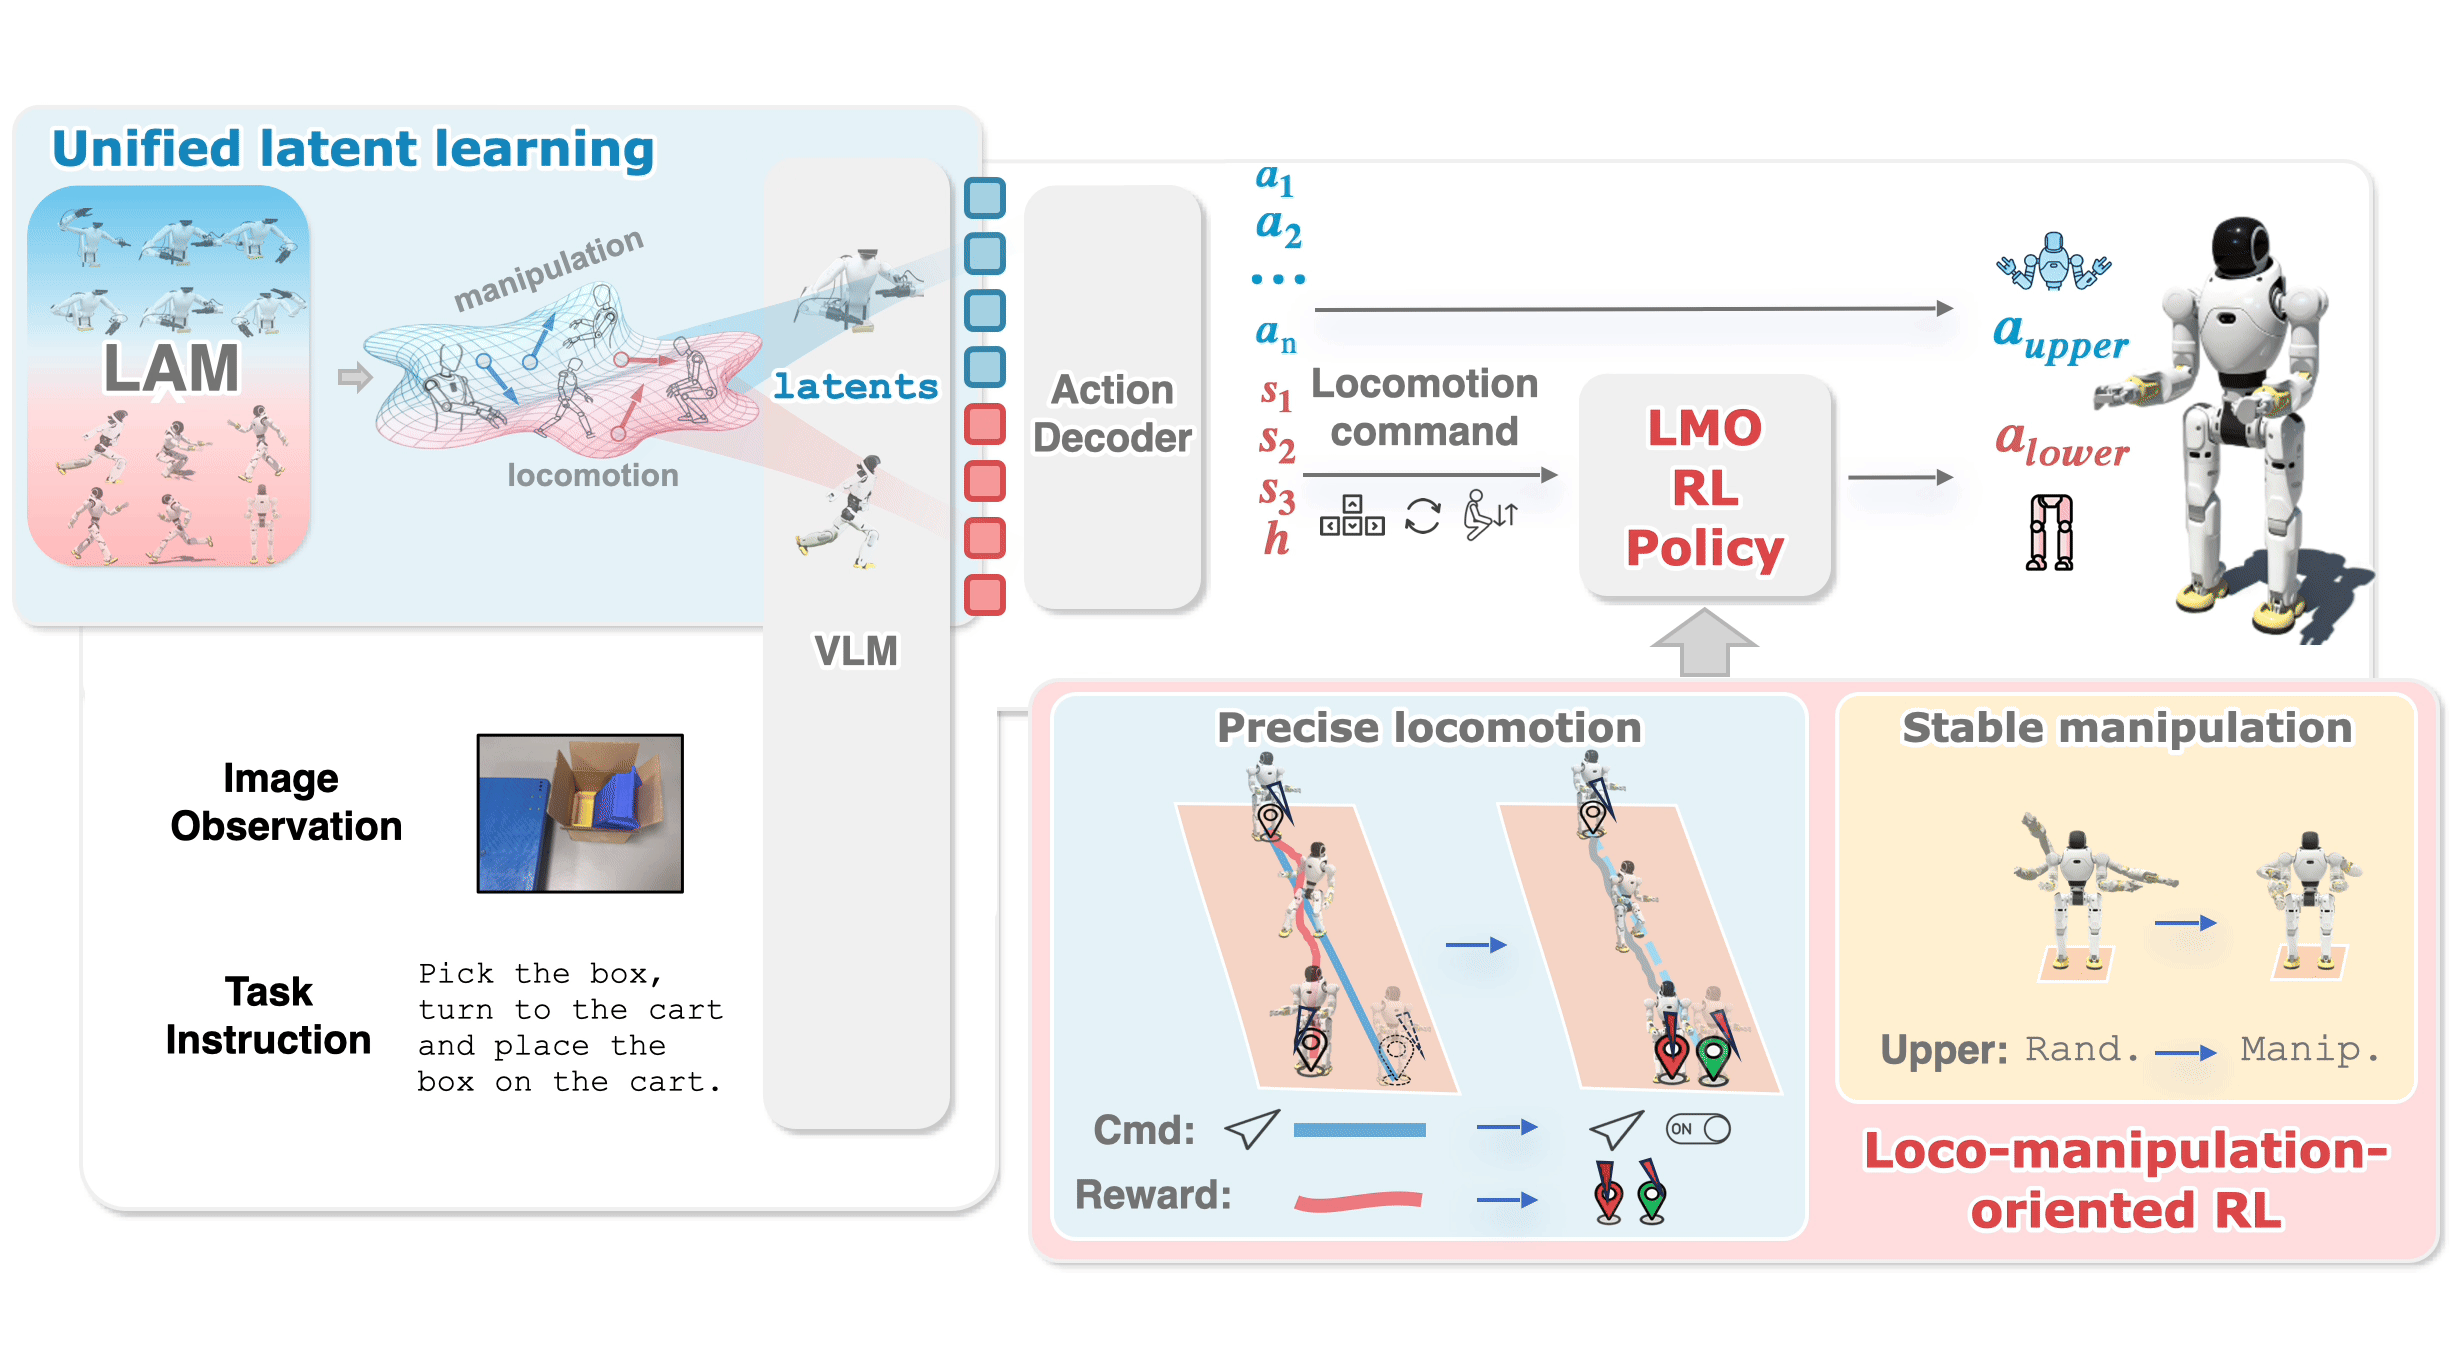
Step-by-step guide to the complete WholebodyVLA training pipeline — egocentric data collection, LAM training, VLA fine-tuning, LMO RL policy, and inference depl

A comprehensive guide to RoboTwin 2.0 — the scalable synthetic data framework for bimanual robots, featuring MLLM code generation and strong domain randomizatio

Complete guide to fine-tuning NVIDIA GR00T N1.7 with EgoScale's 20,854-hour egocentric video dataset — from setup to deploying your policy on a humanoid robot.
Reproduce SteadyTray on IsaacLab — train a Unitree G1 humanoid to carry a tray without dropping objects using a two-stage Residual RL architecture.

Hands-on guide to NVIDIA Newton 1.0 — the fastest open-source GPU physics engine for sim-to-real robotics, 475x faster than MJX.
Step-by-step guide to fine-tune NVIDIA GR00T N1.6 — the 3B VLA model combining Cosmos Reason 2 for controlling humanoid robots from images and language.

Deploy task planning for robot manipulation on NVIDIA Jetson AGX Orin 64GB — from cuTAMP and cuMotion to VLM inference at the edge.
Step-by-step tutorial to monitor ROS 2 robots from anywhere — battery, CPU, status, heartbeat, alerts. Working code, 10-minute setup. Free for 3 robots.
Looking for a Formant alternative in 2026? Honest comparison of 5 fleet management platforms — pricing, ROS 2 support, features, and which fits your team.
Deep dive into NVIDIA GEAR-SONIC — training a whole-body controller for humanoid robots with BONES-SEED dataset and VR teleoperation.
AWS RoboMaker shut down in September 2025. Here are the 5 best alternatives for ROS 2 fleet management in 2026 — honest comparison, pricing, migration guide.