All posts
Page 14 of 18

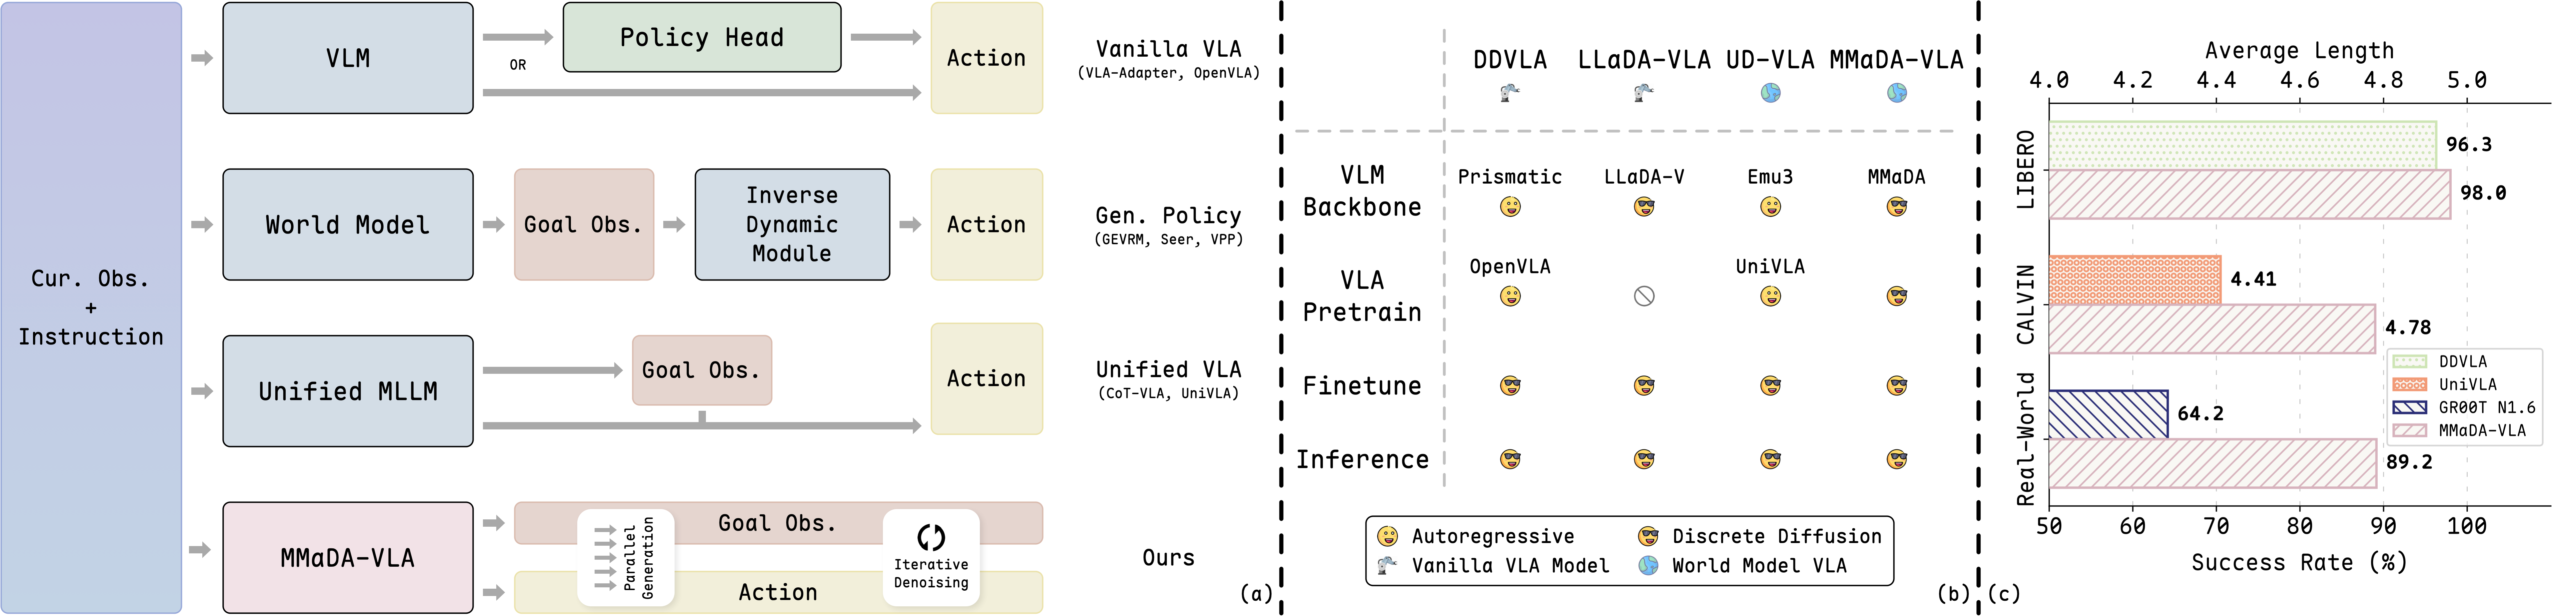
MMaDA-VLA unifies language, vision and robot actions into a single token space via discrete diffusion — a new paradigm for VLA models.

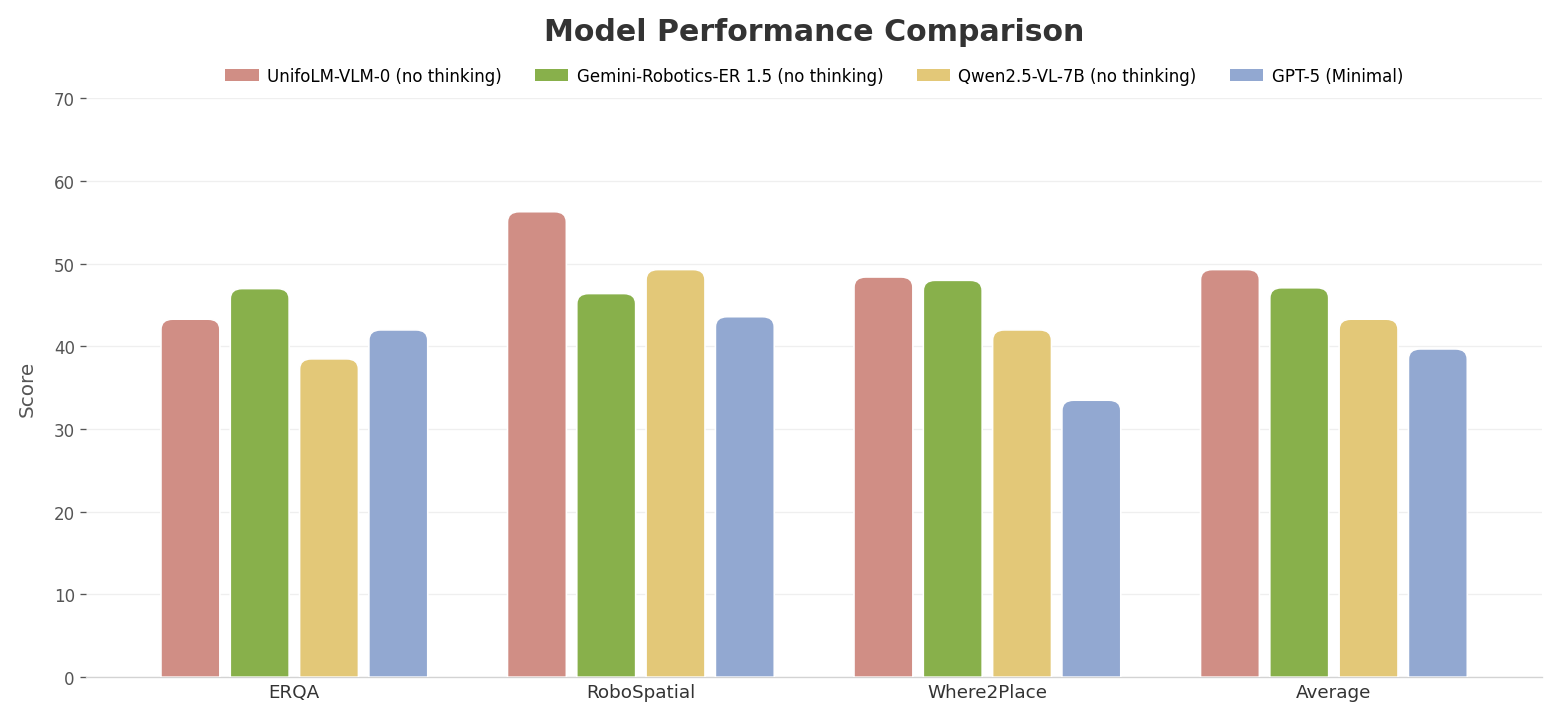
Analysis and implementation guide for UnifoLM-VLA-0 — the first open-source VLA model running directly on the G1 humanoid

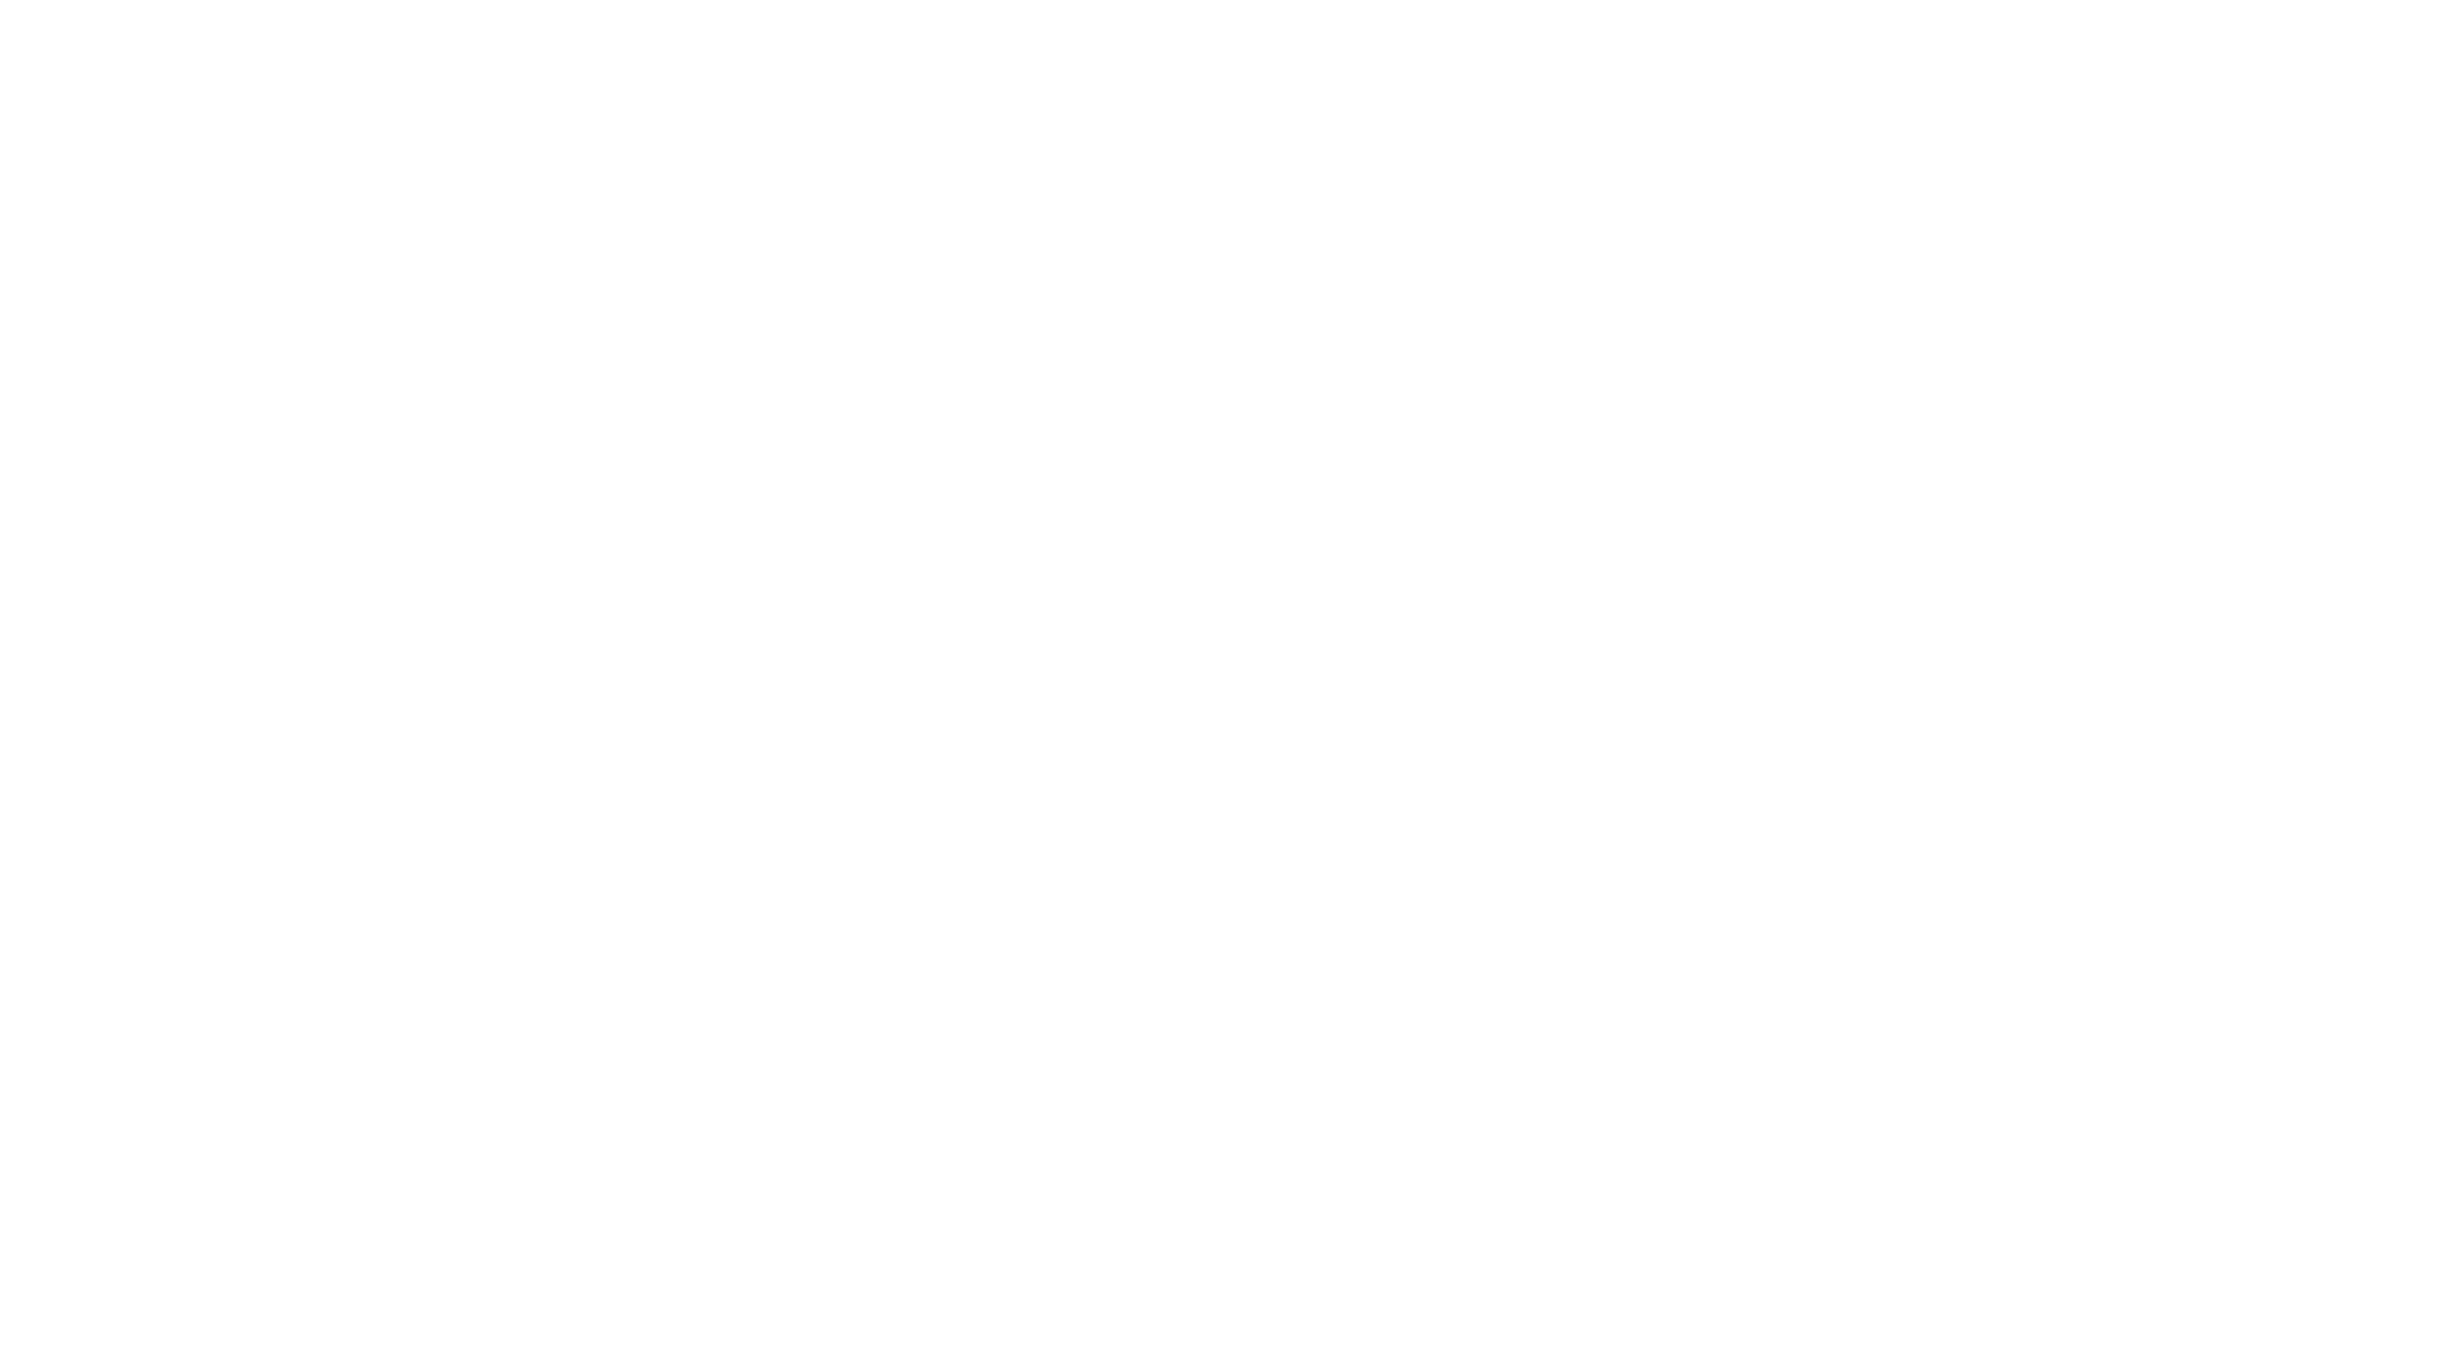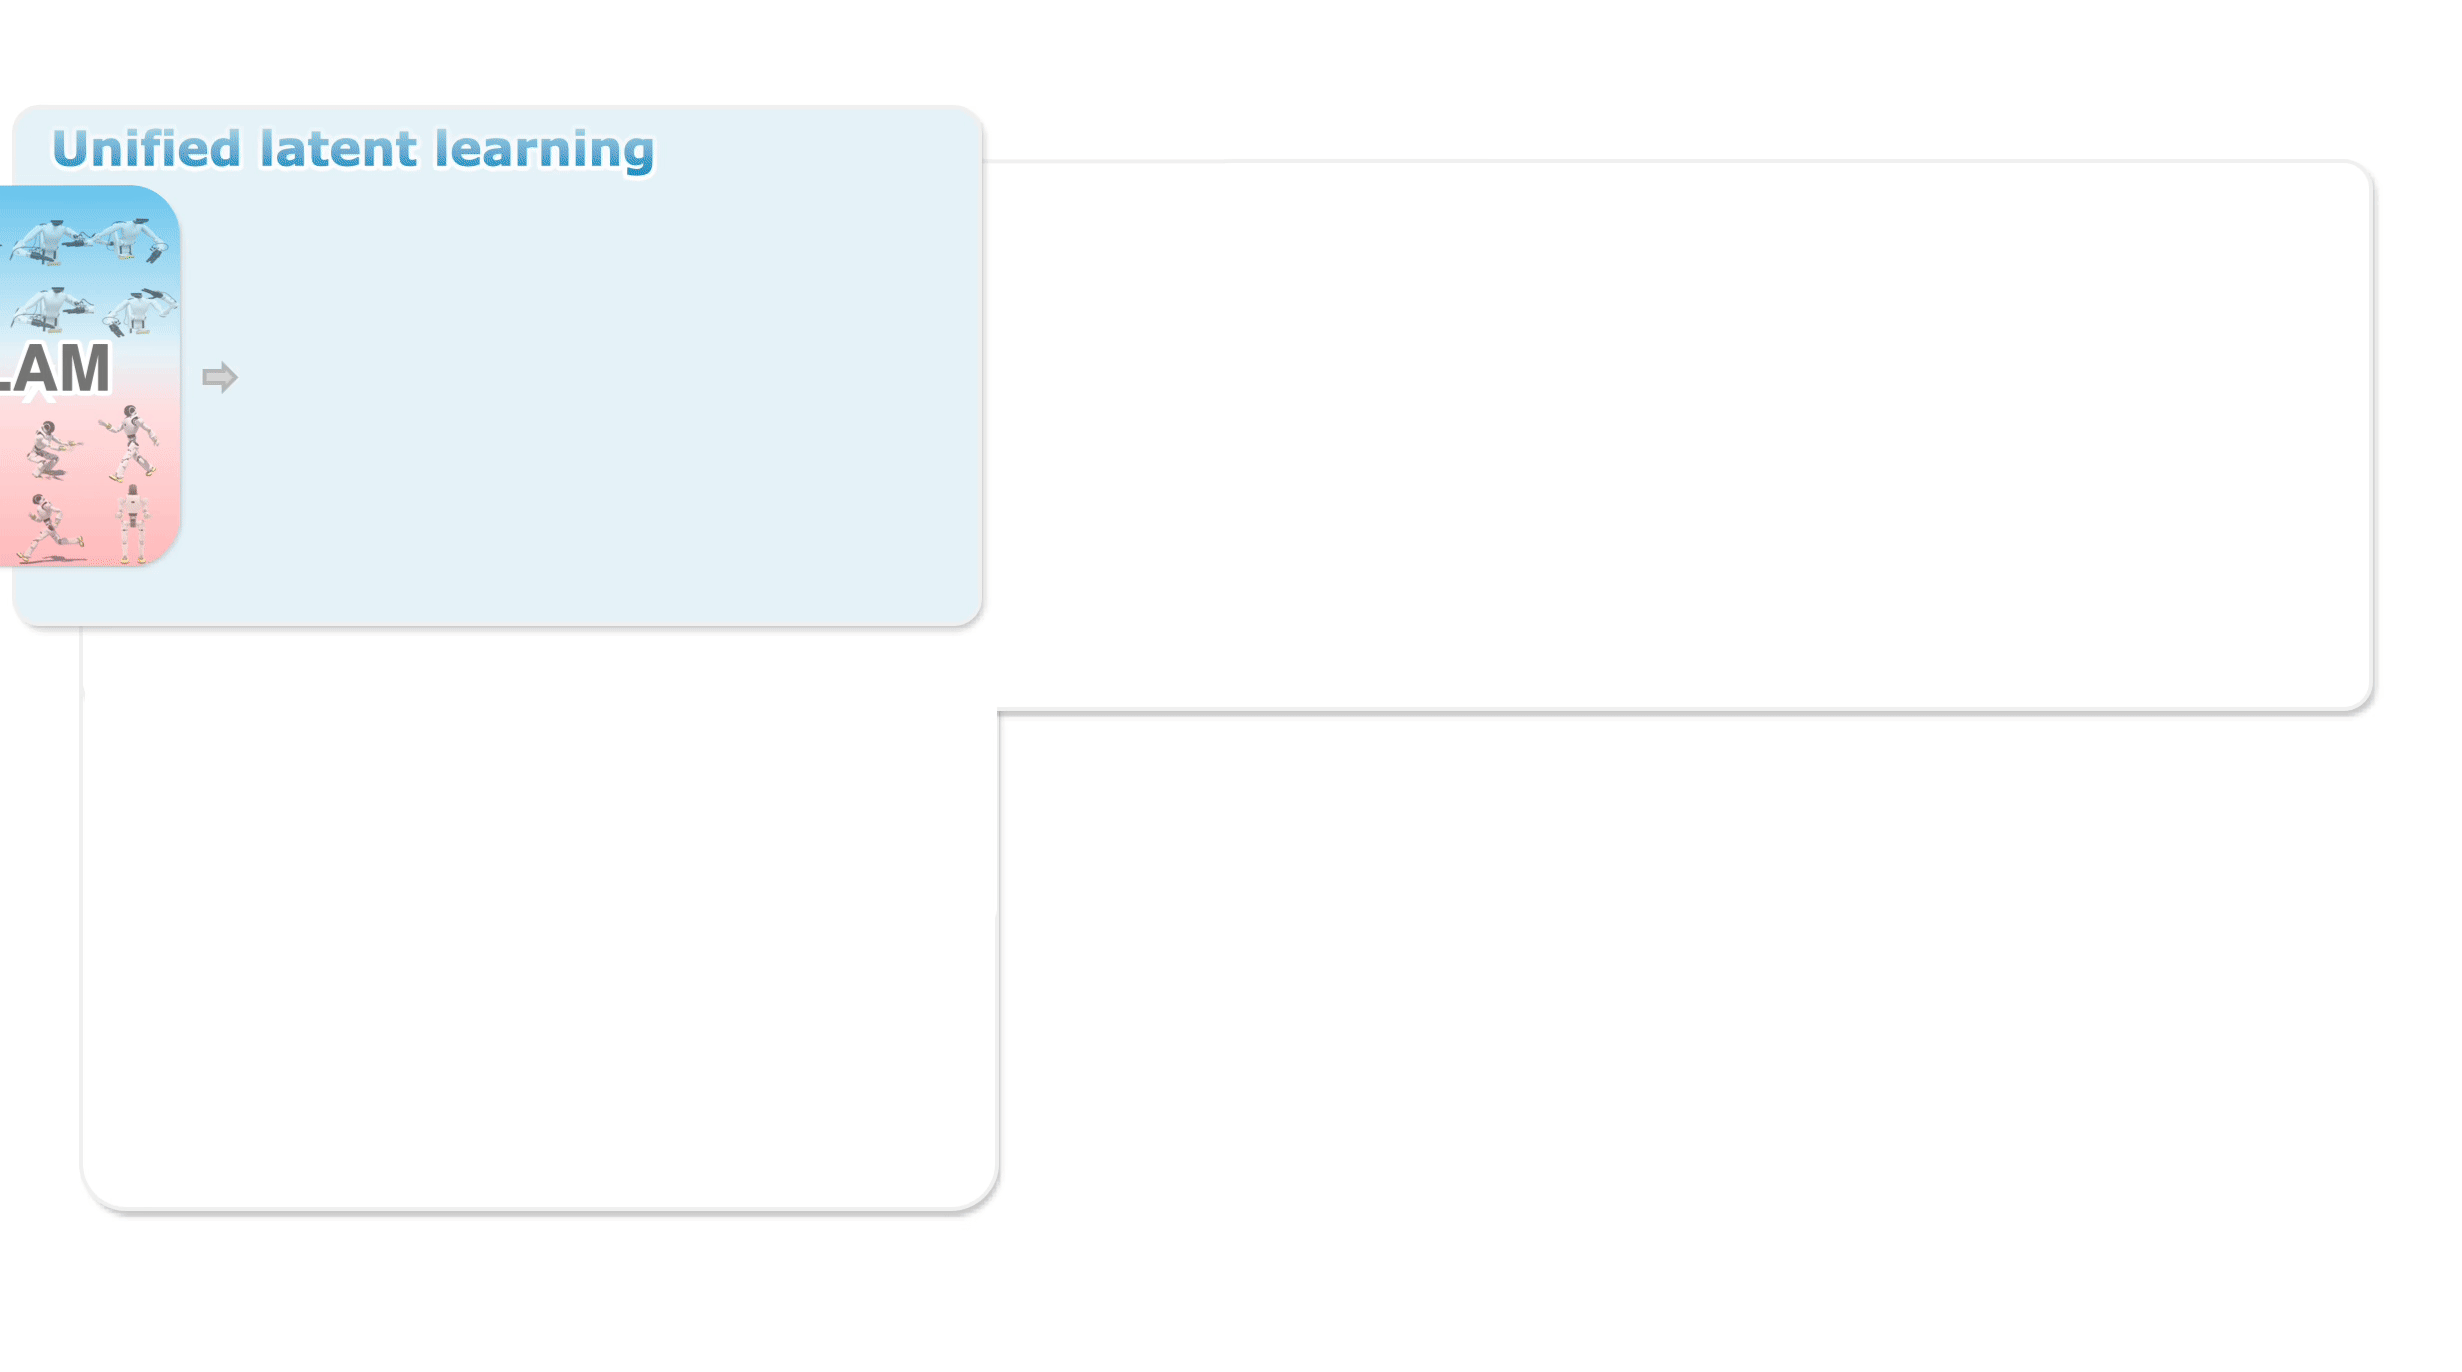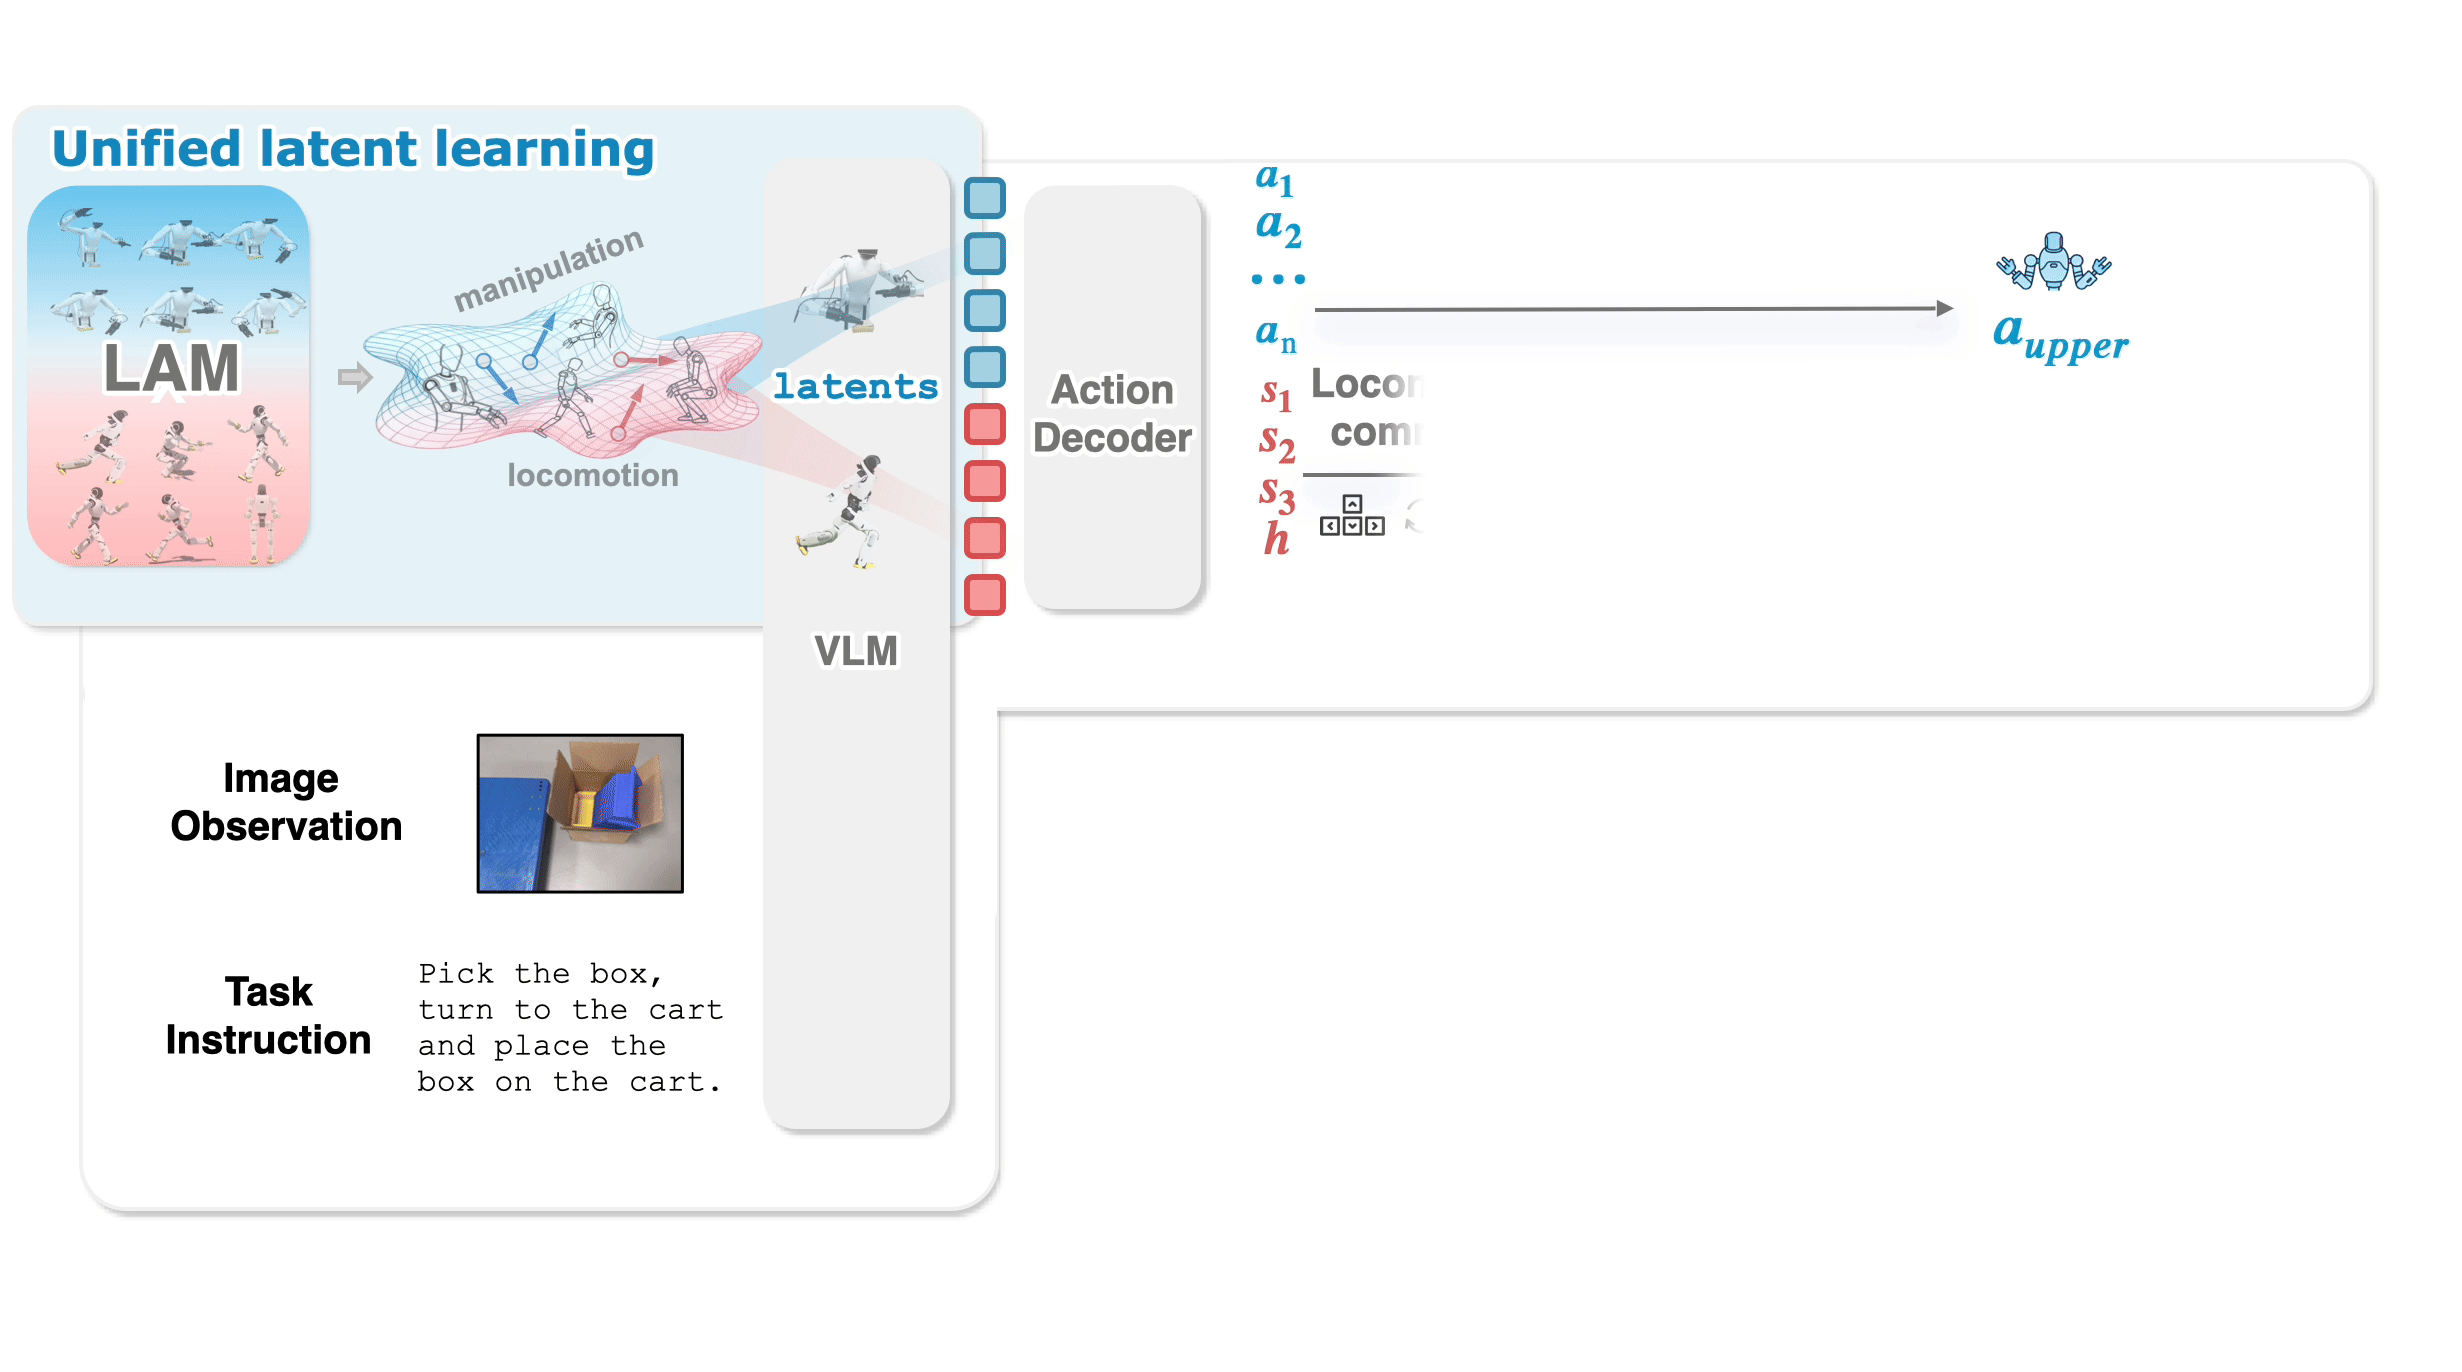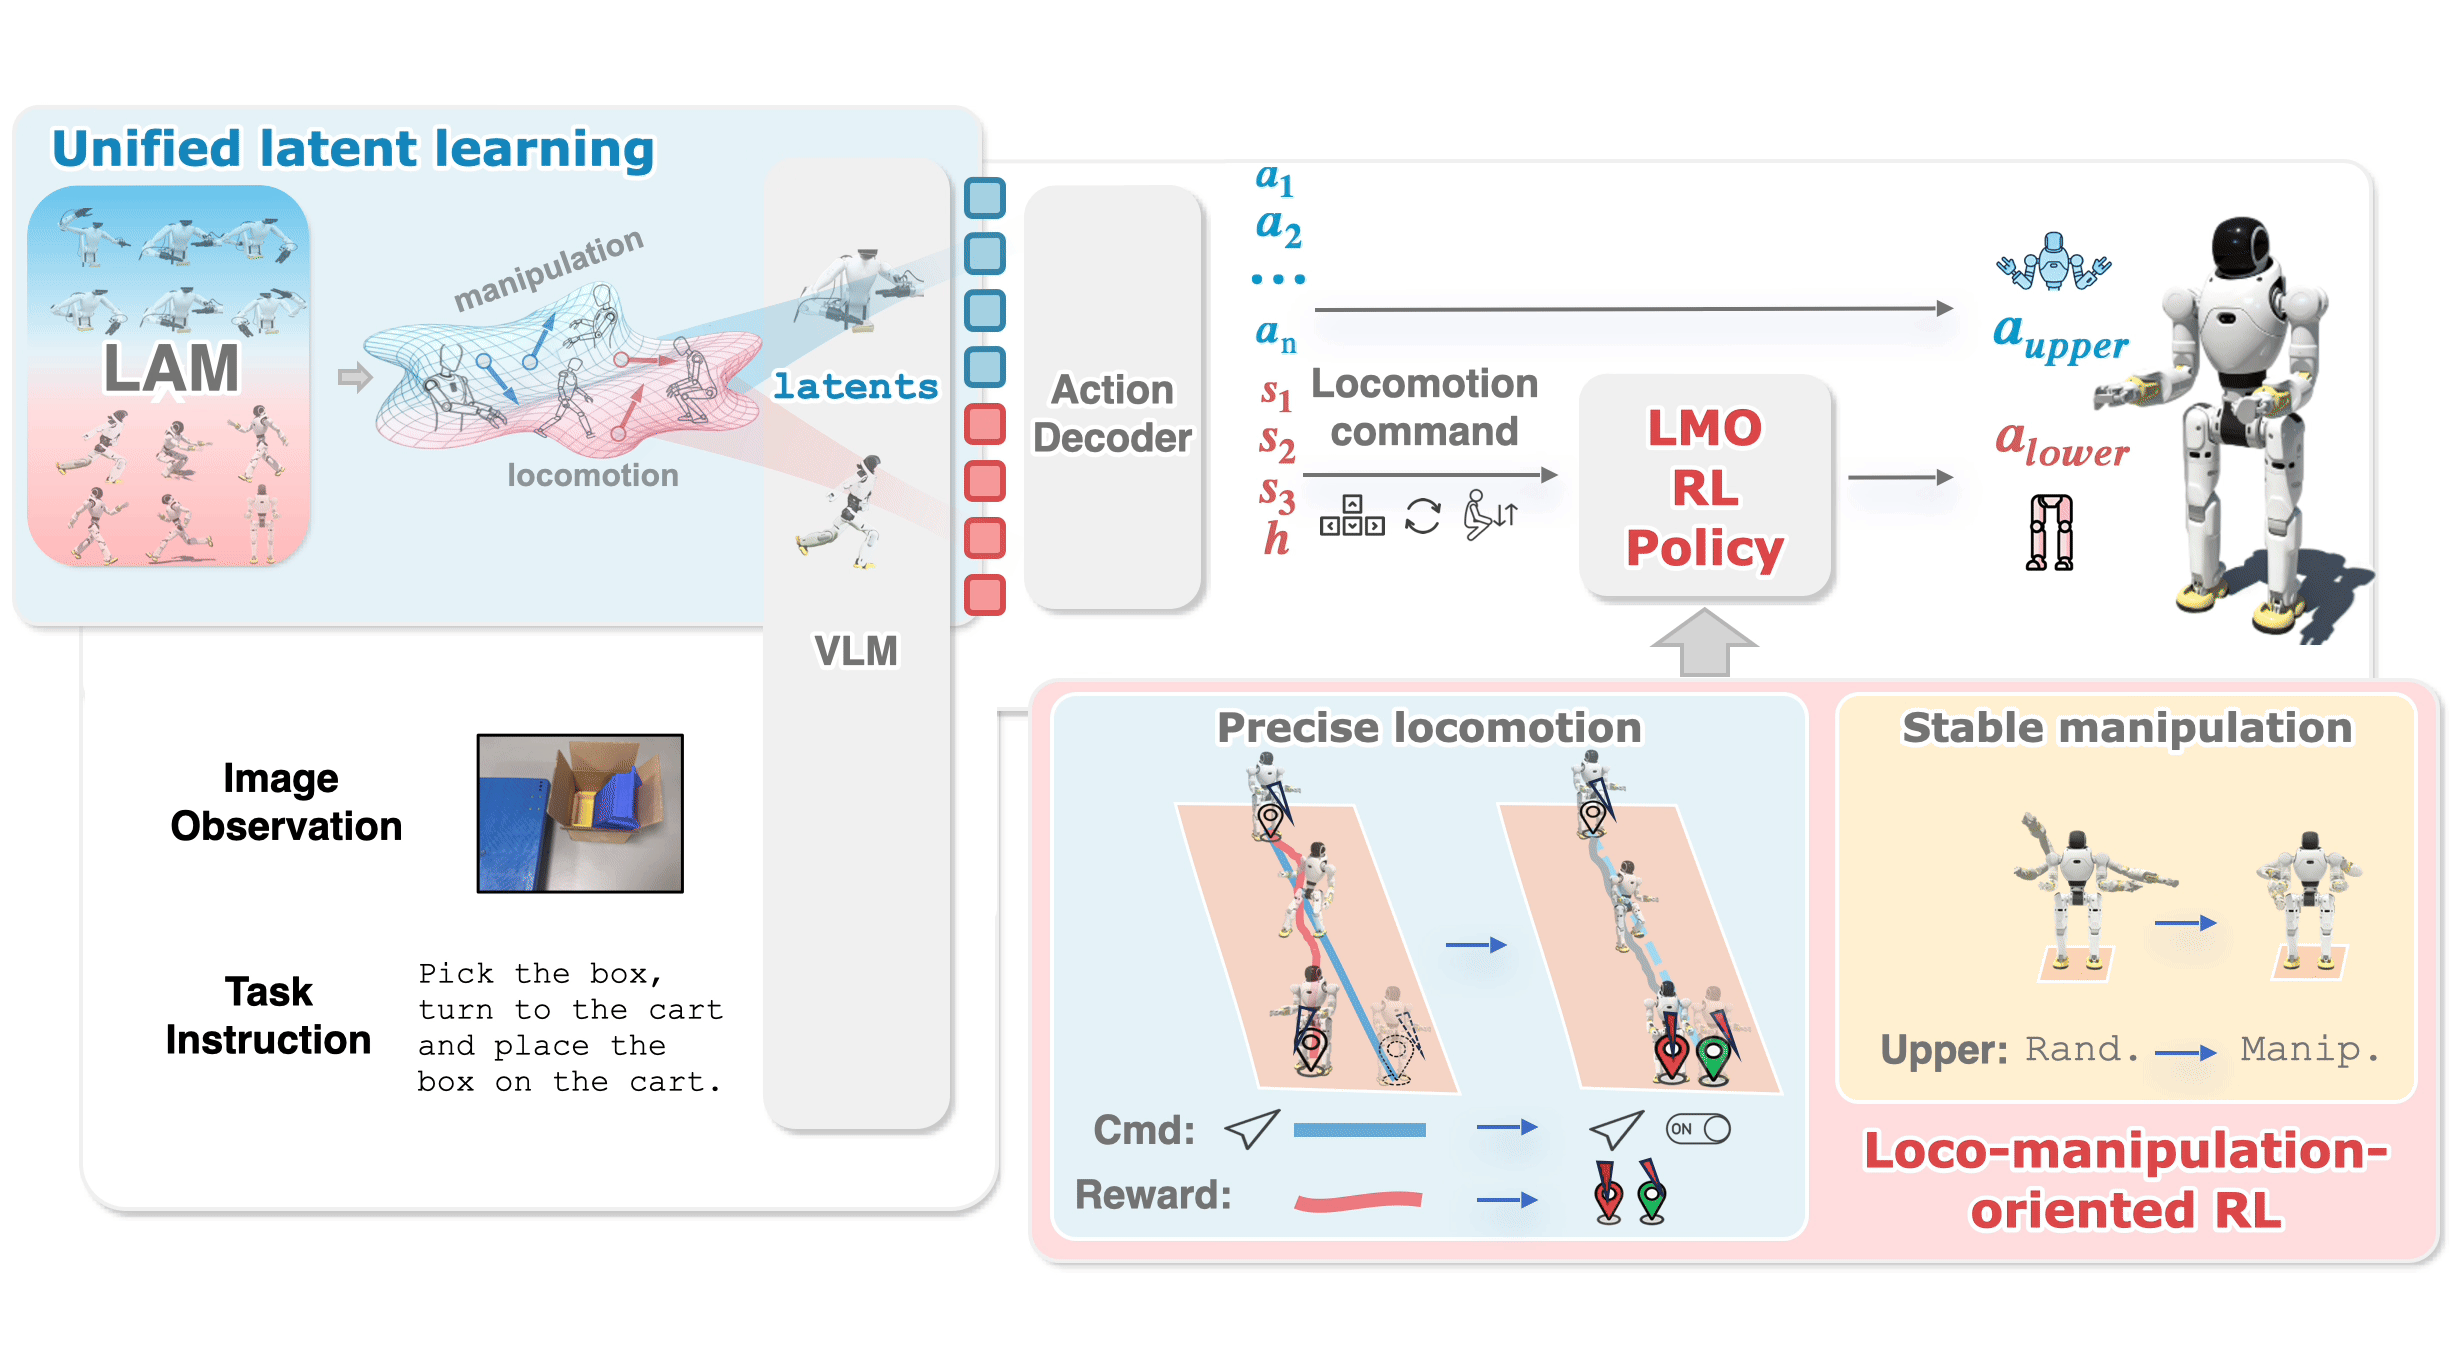
ICLR 2026 — learning manipulation from egocentric video, combining VLA + RL for locomotion-aware control

Online RL framework for VLA — surpasses pi0-FAST on 40 tasks, discovers first inference scaling law for robotics

Force-Adaptive RL expands the manipulation envelope for humanoids — deployed on Unitree H1-2, 73.84% success rate

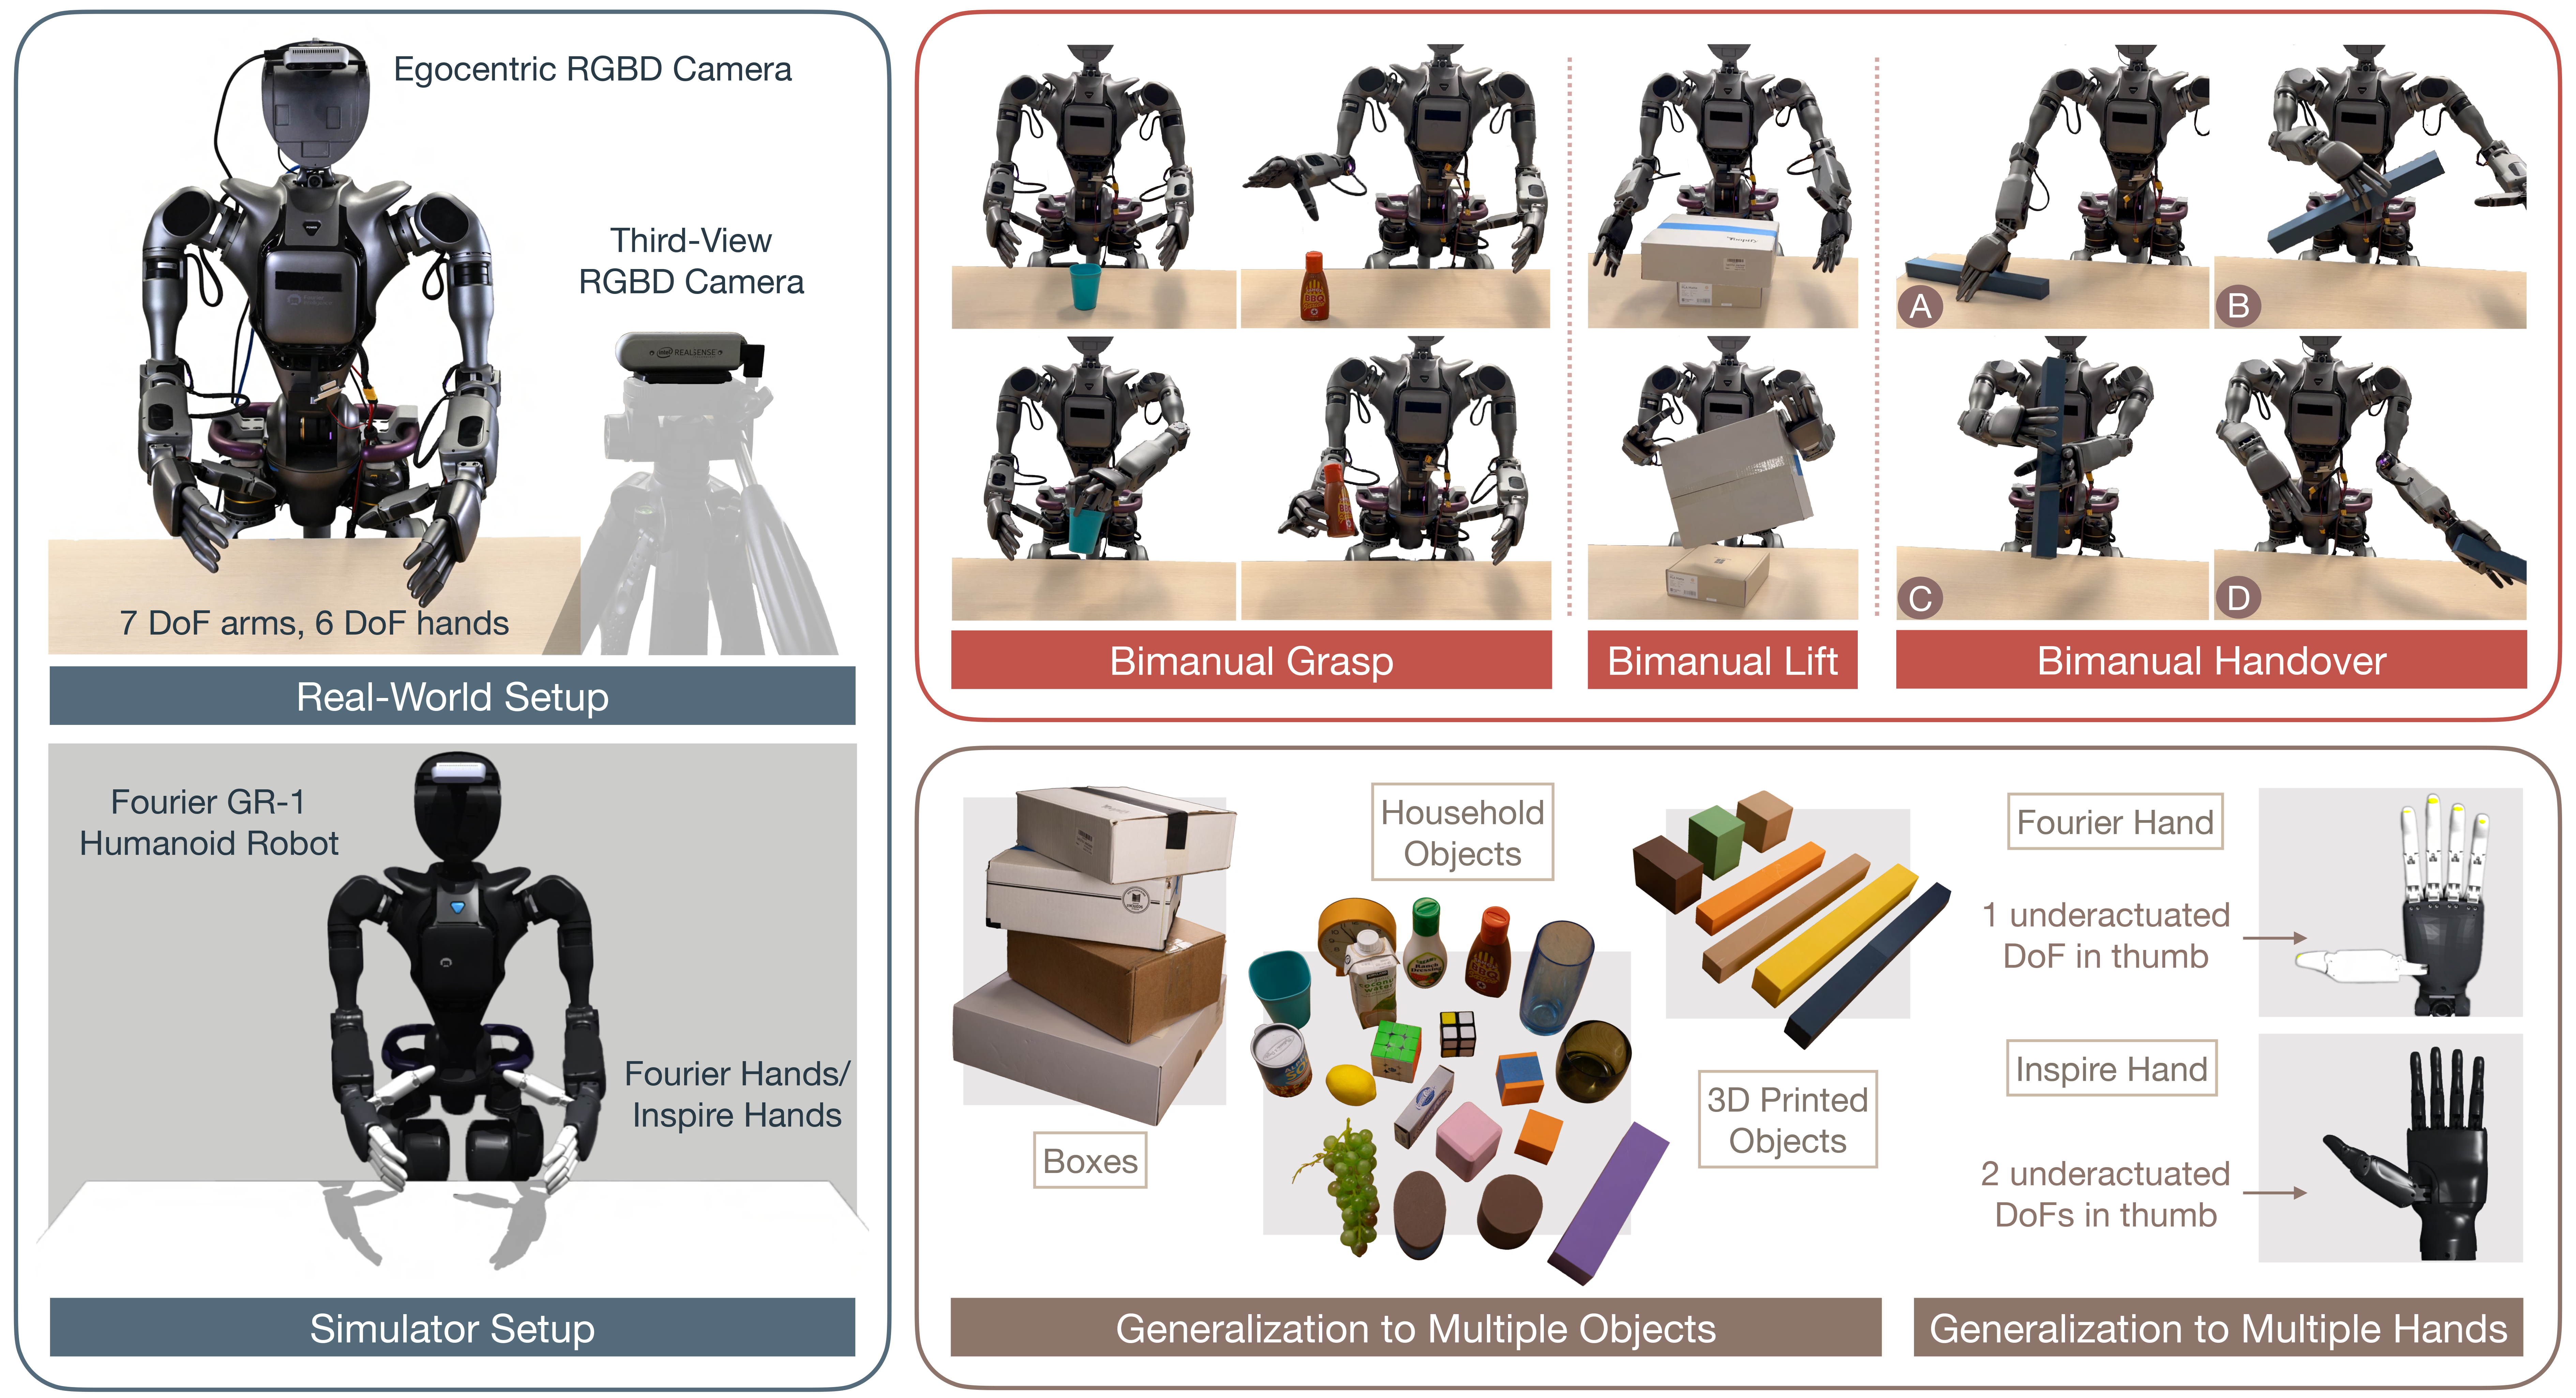
Complete pipeline from simulation to real robot — grasp, box lift, bimanual handover with automated real-to-sim tuning
Analysis of notable papers on autonomous navigation and manipulation — preparing for IROS 2026 Pittsburgh.
Techniques for transferring models from simulation to real robots — domain randomization, system identification, and best practices.
IROS 2026 Pittsburgh — preview workshops, competitions and leading research in navigation and manipulation.

Complete guide to MoveIt2 configuration for robot arms — from URDF, collision detection to trajectory planning in ROS 2.
Complete guide to performing risk assessment per ISO 10218 for industrial welding robot cells — from hazard identification to safety measures.
Comprehensive overview of embodied AI — from foundation models, sim-to-real to robot learning at scale with open-source tools.