All posts
Page 13 of 18
Step-by-step guide to building the Berkeley Humanoid Lite — an open-source 3D-printed humanoid with 24 DOF and RL-based sim-to-real locomotion from UC Berkeley.

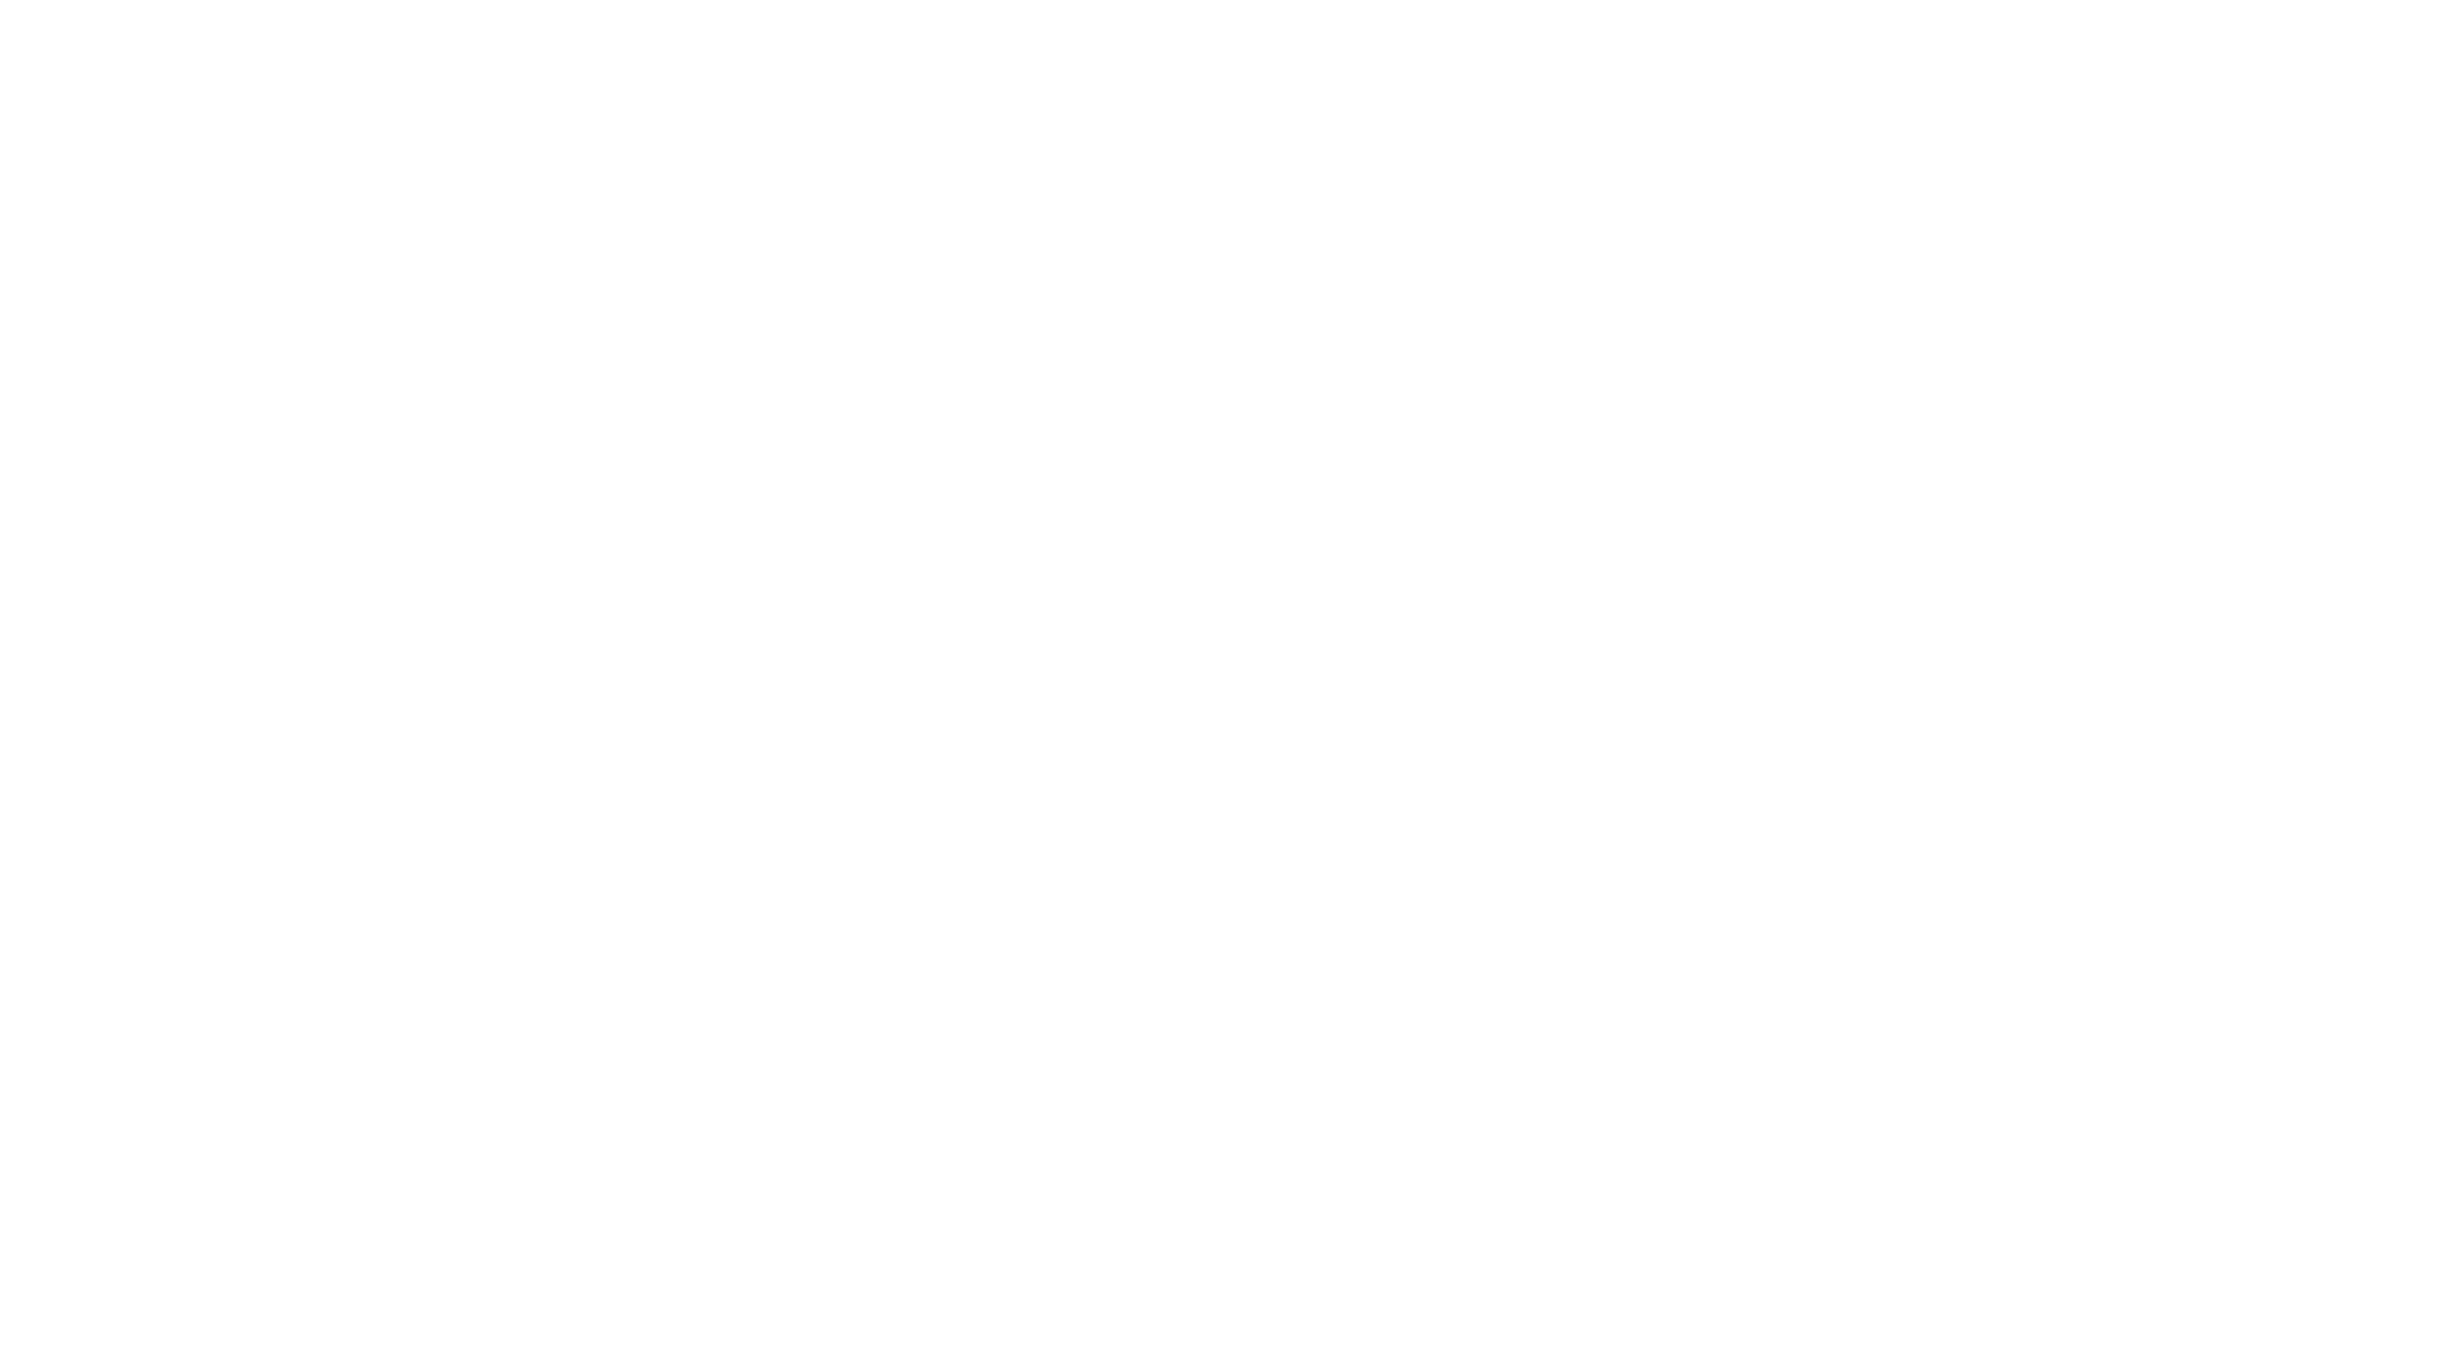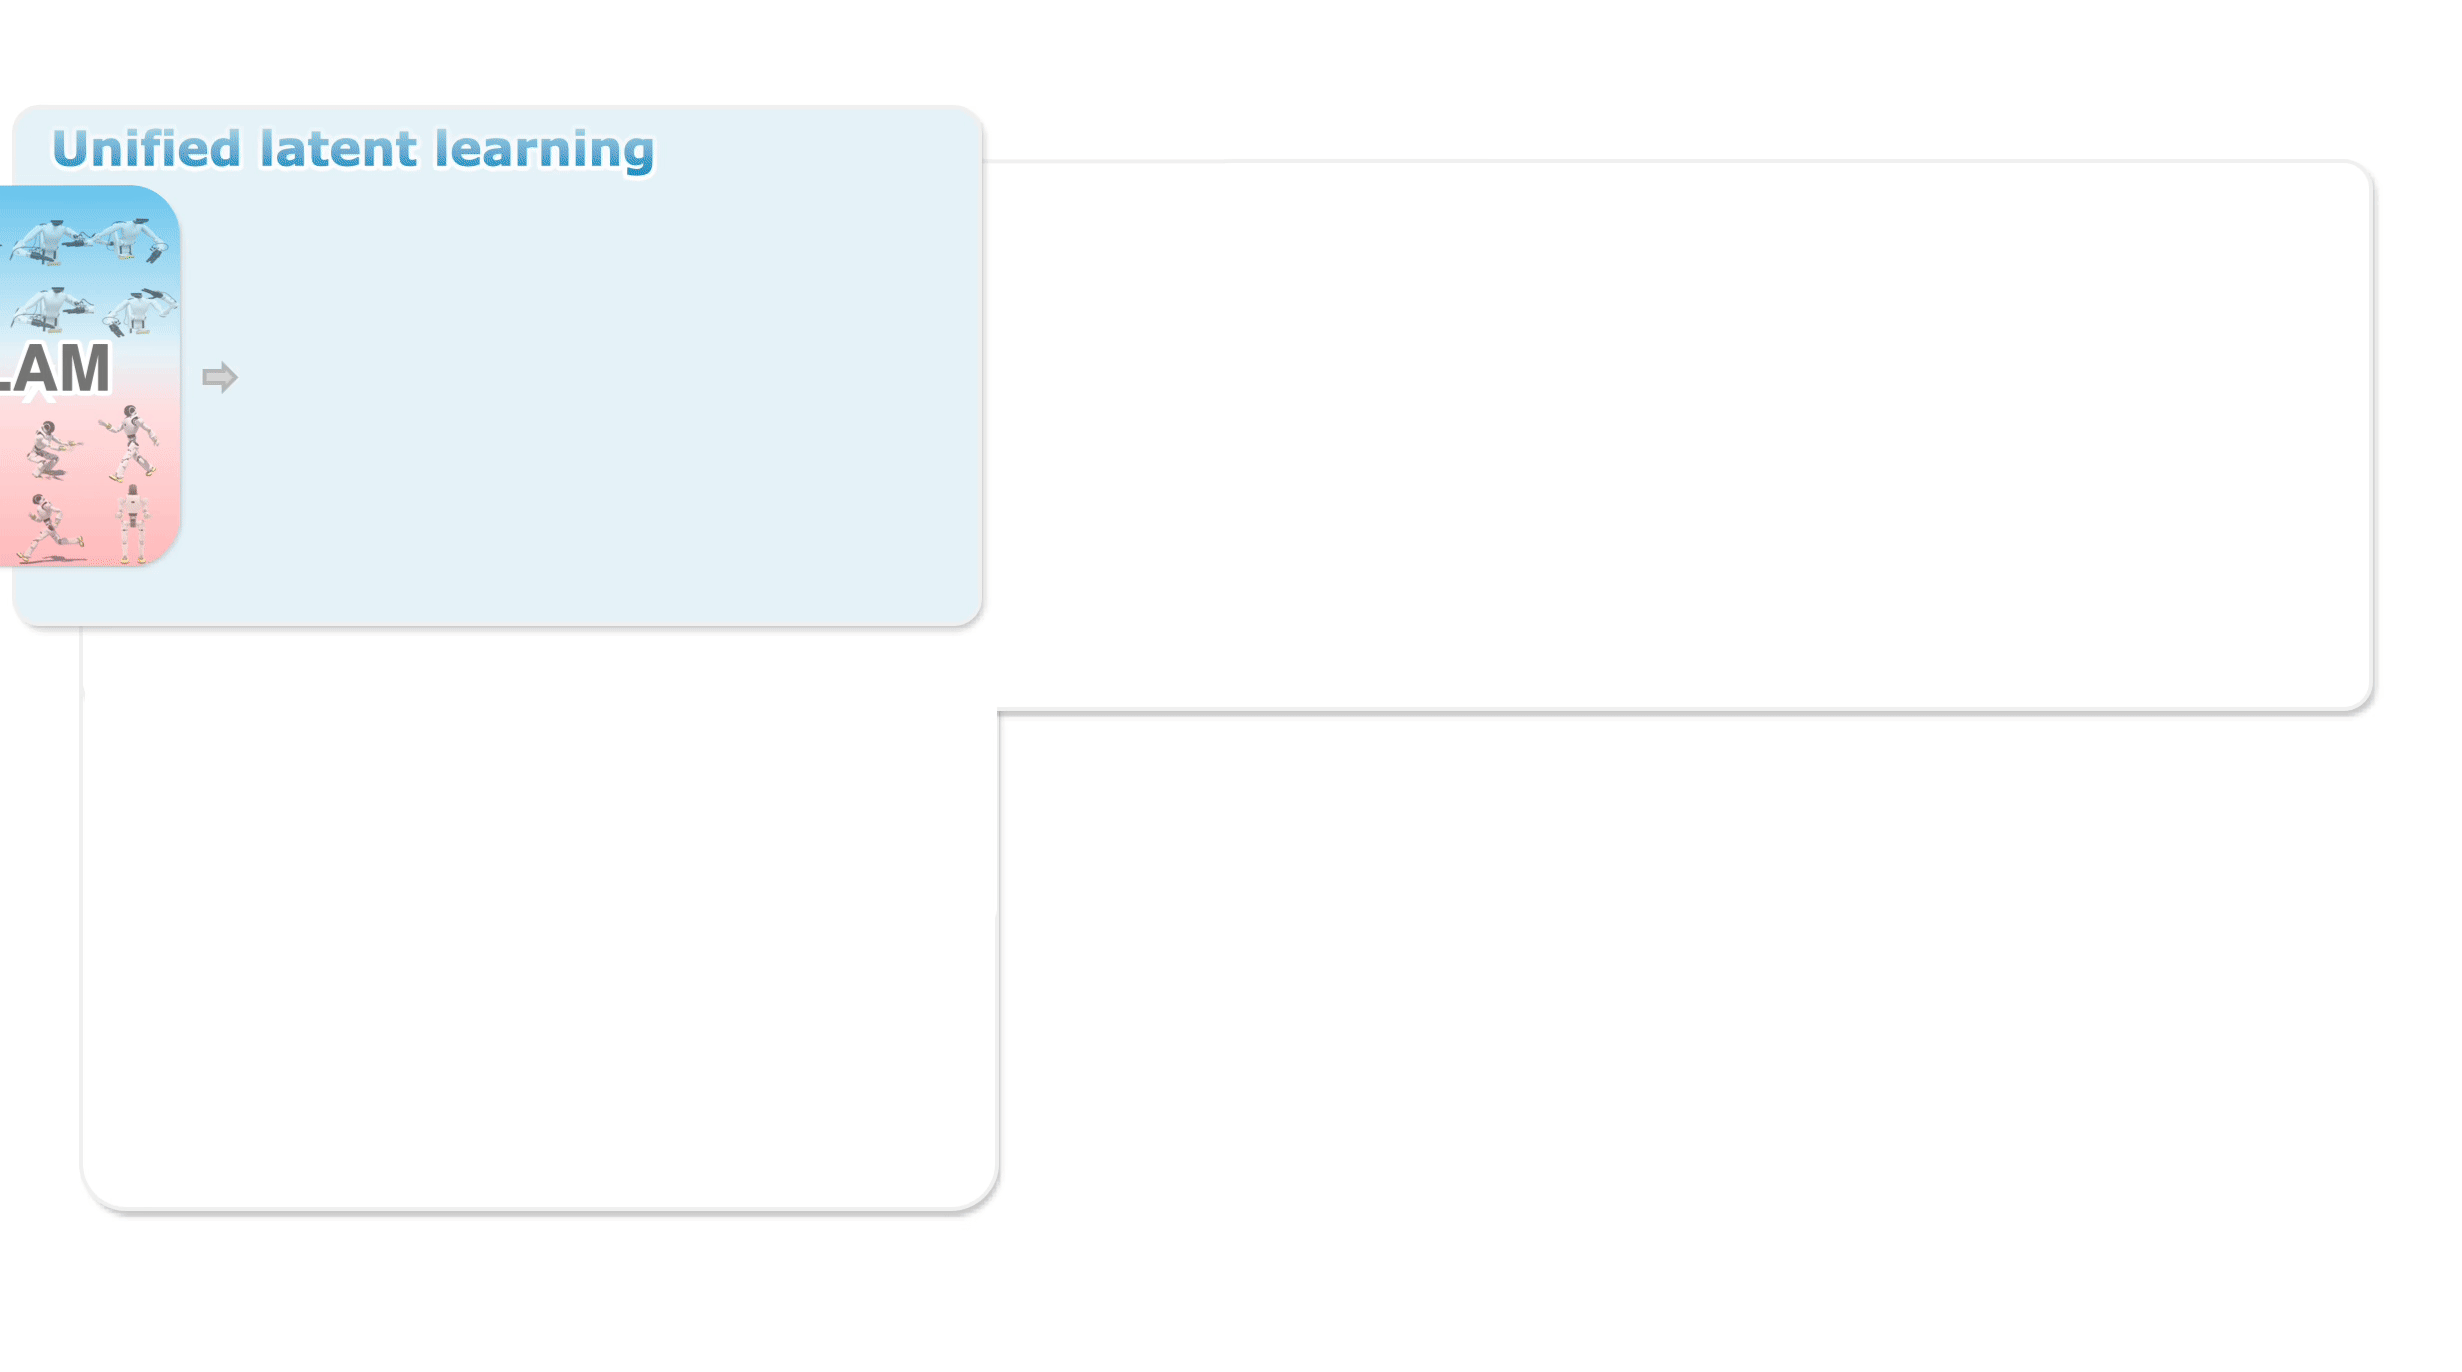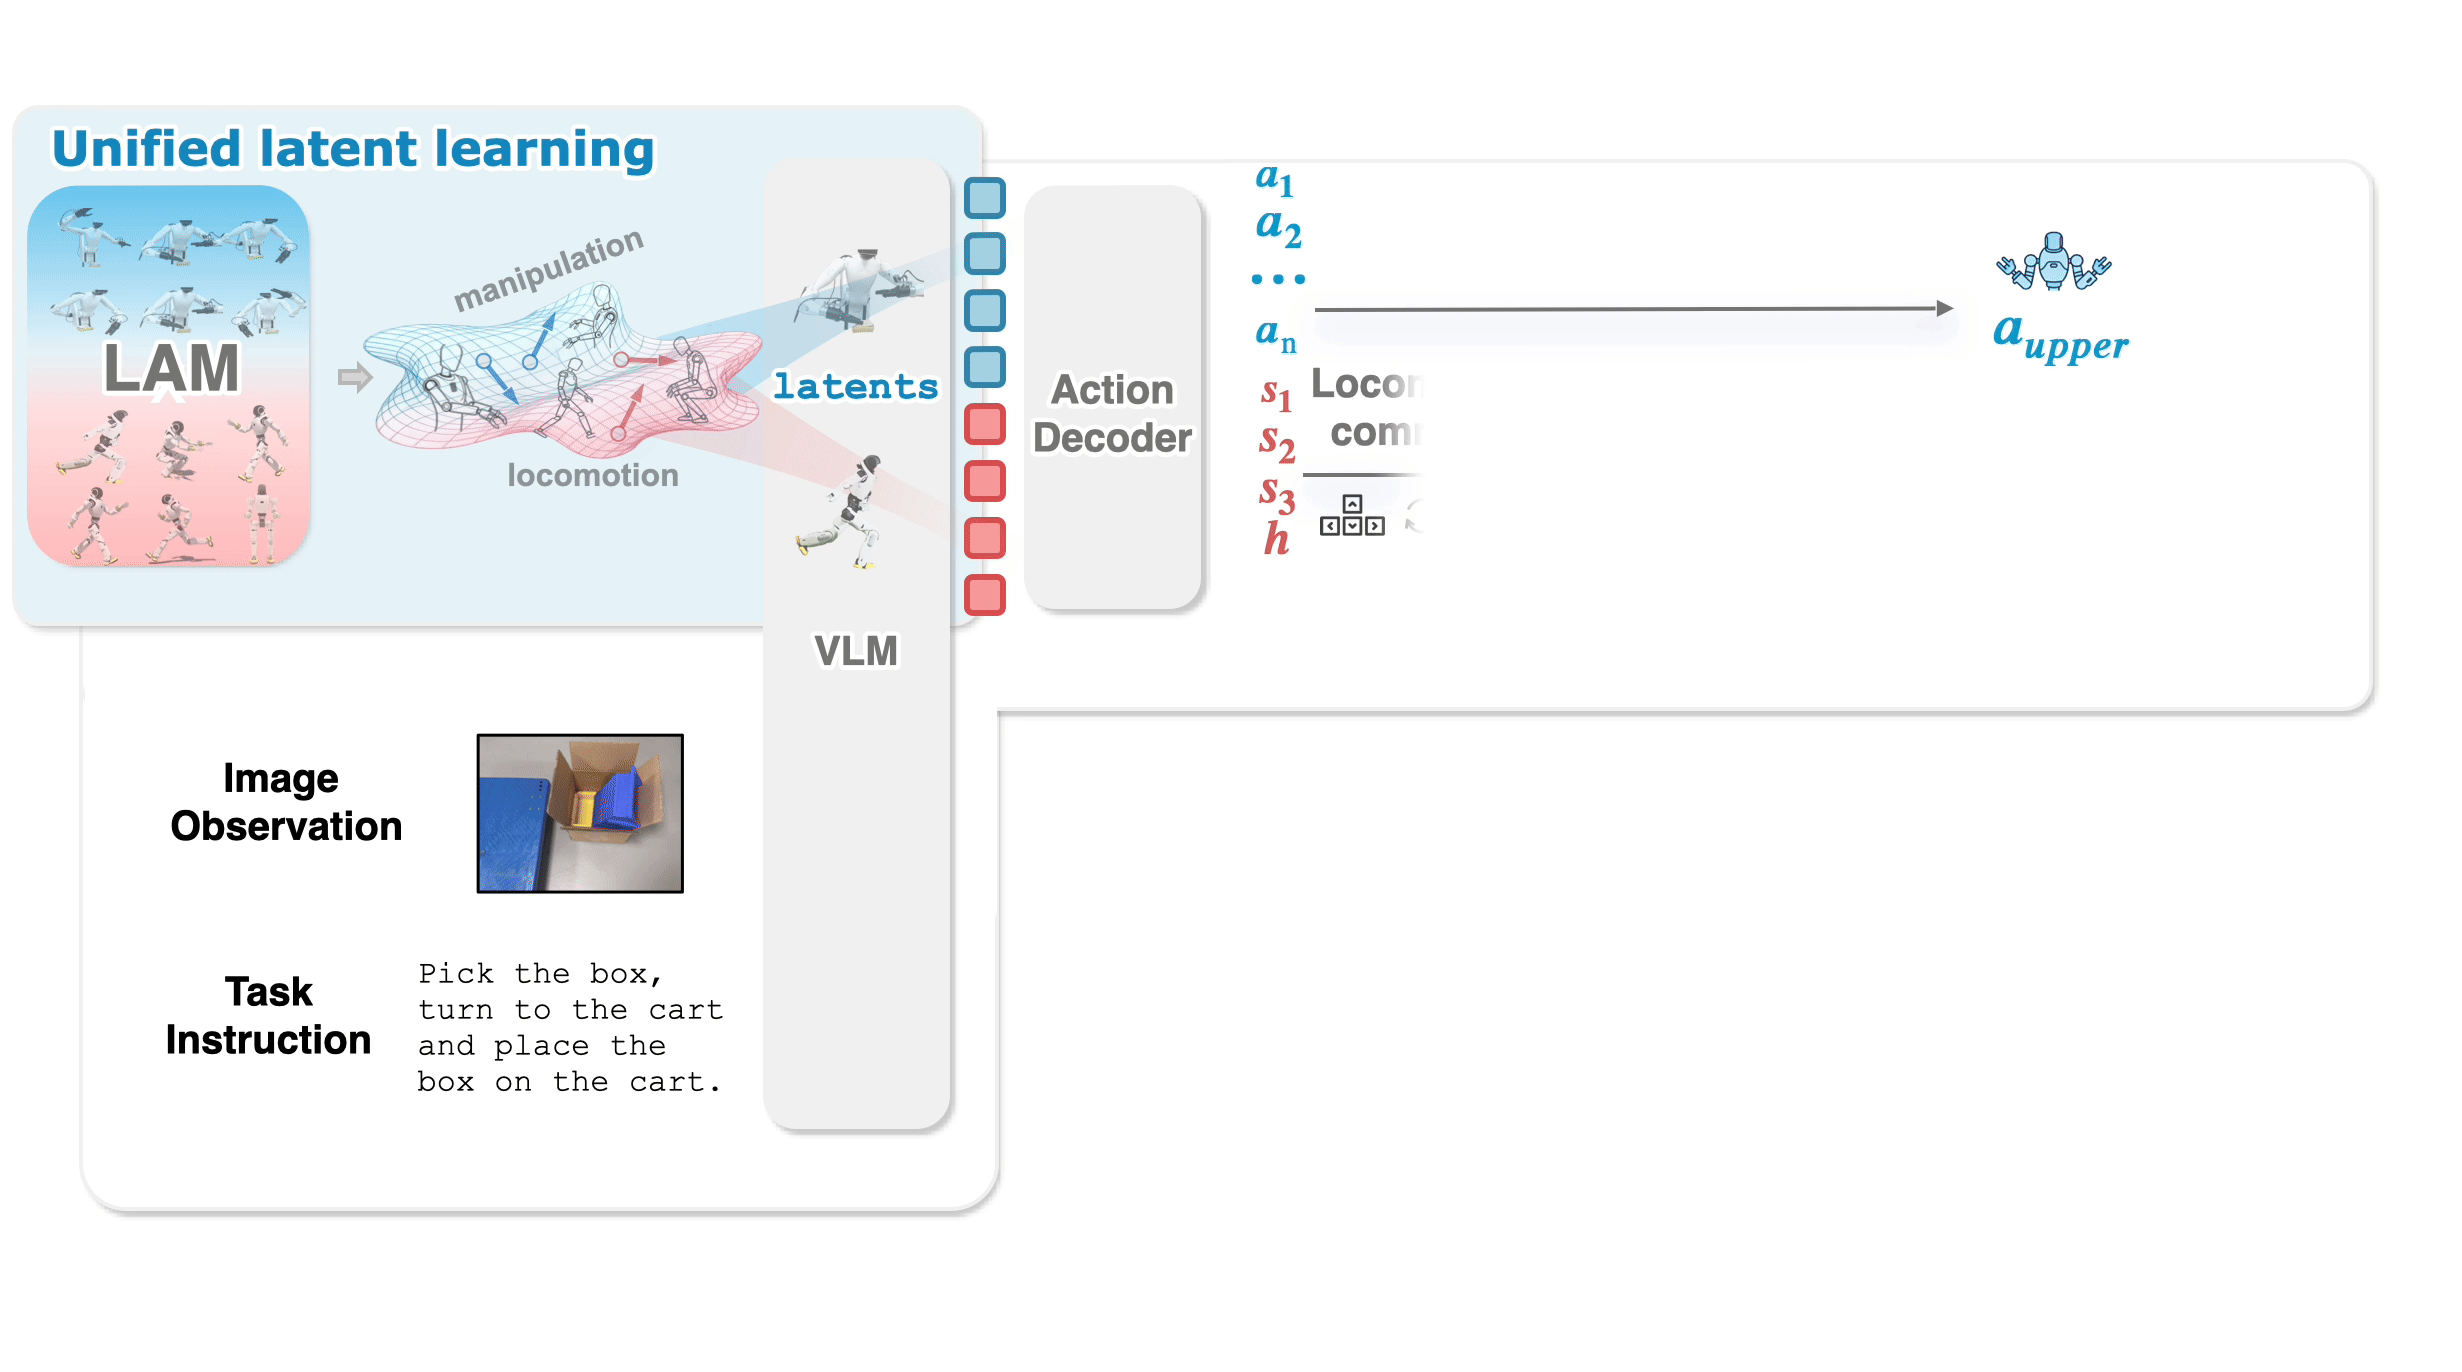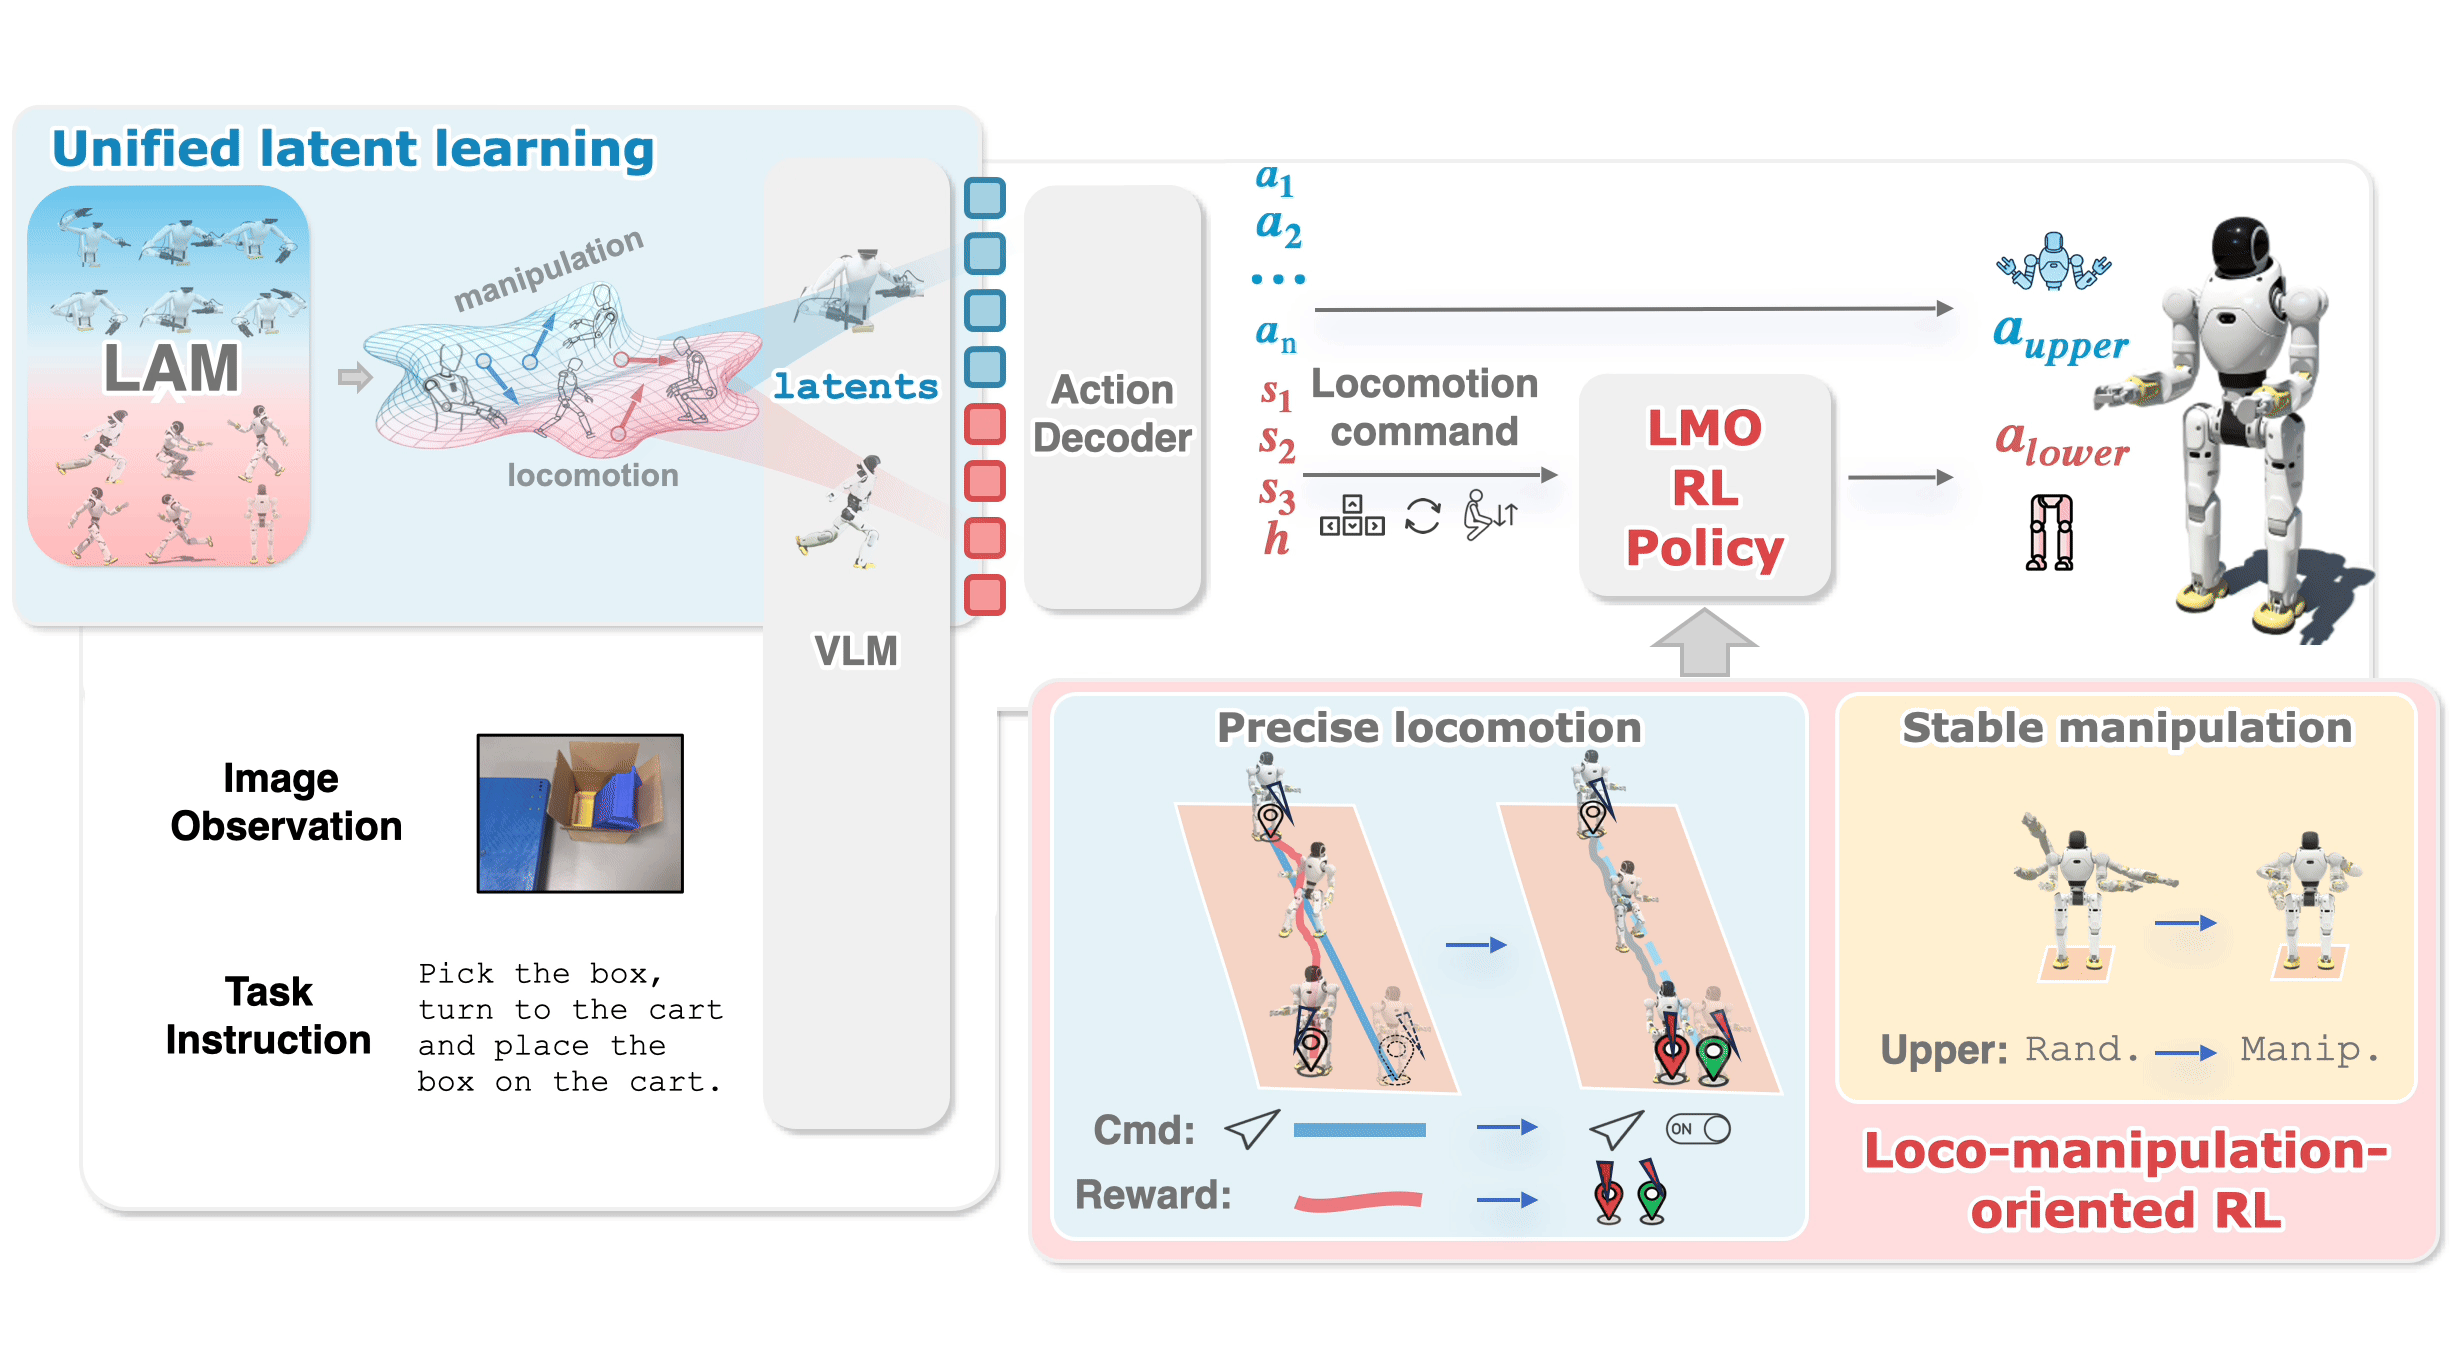
Deep-dive into the WholebodyVLA codebase — latent action architecture, LMO RL policy, and building a whole-body loco-manipulation pipeline for humanoids.

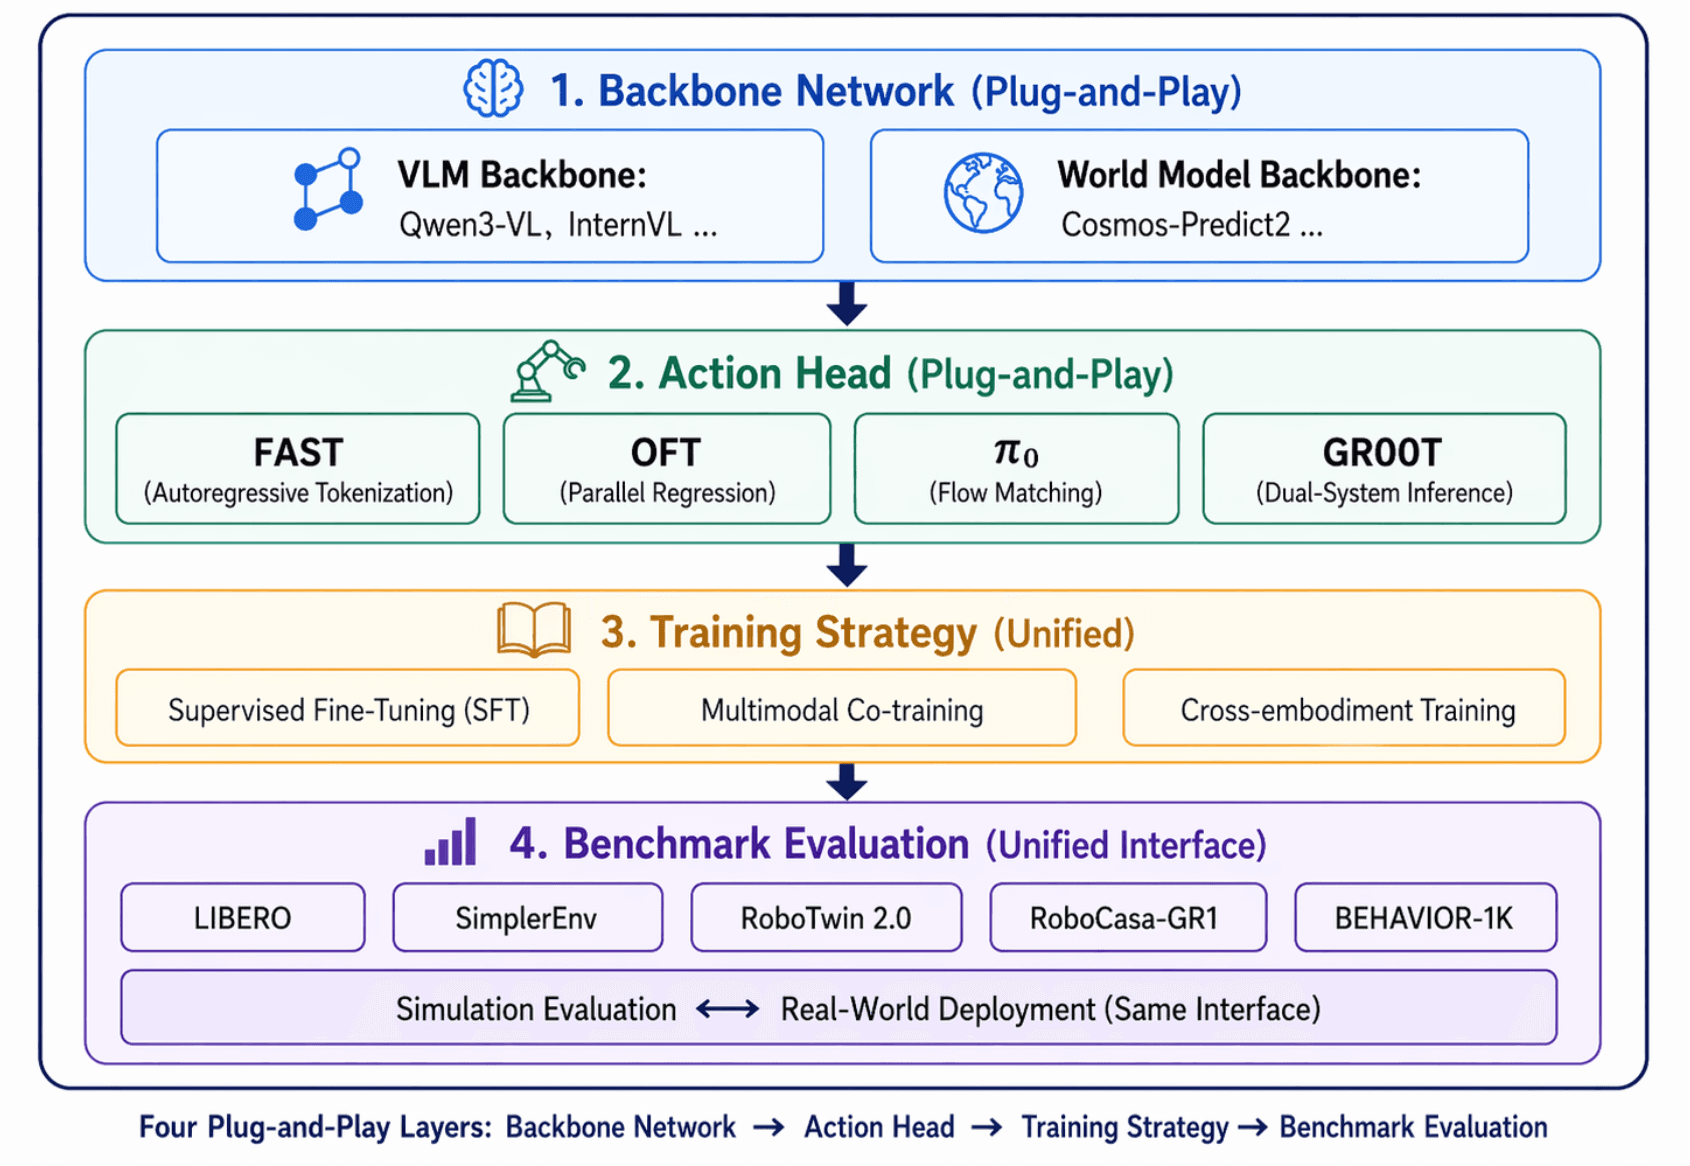
Step-by-step guide to building Vision-Language-Action models with StarVLA — a Lego-like modular framework from ICLR 2026 supporting 4 action head architectures.

Step-by-step guide to fine-tune the GR00T N1 VLA model for humanoid robots using Isaac Lab and AGIBOT World data — from setup to inference.
Analyzing Google's Gemma 4 architecture — from on-device AI to practical applications in robot control, perception and agentic workflows.
Deep dive into Google's Gemma 4 — open-source multimodal AI with agentic capabilities, running on Jetson and Raspberry Pi for robotics.

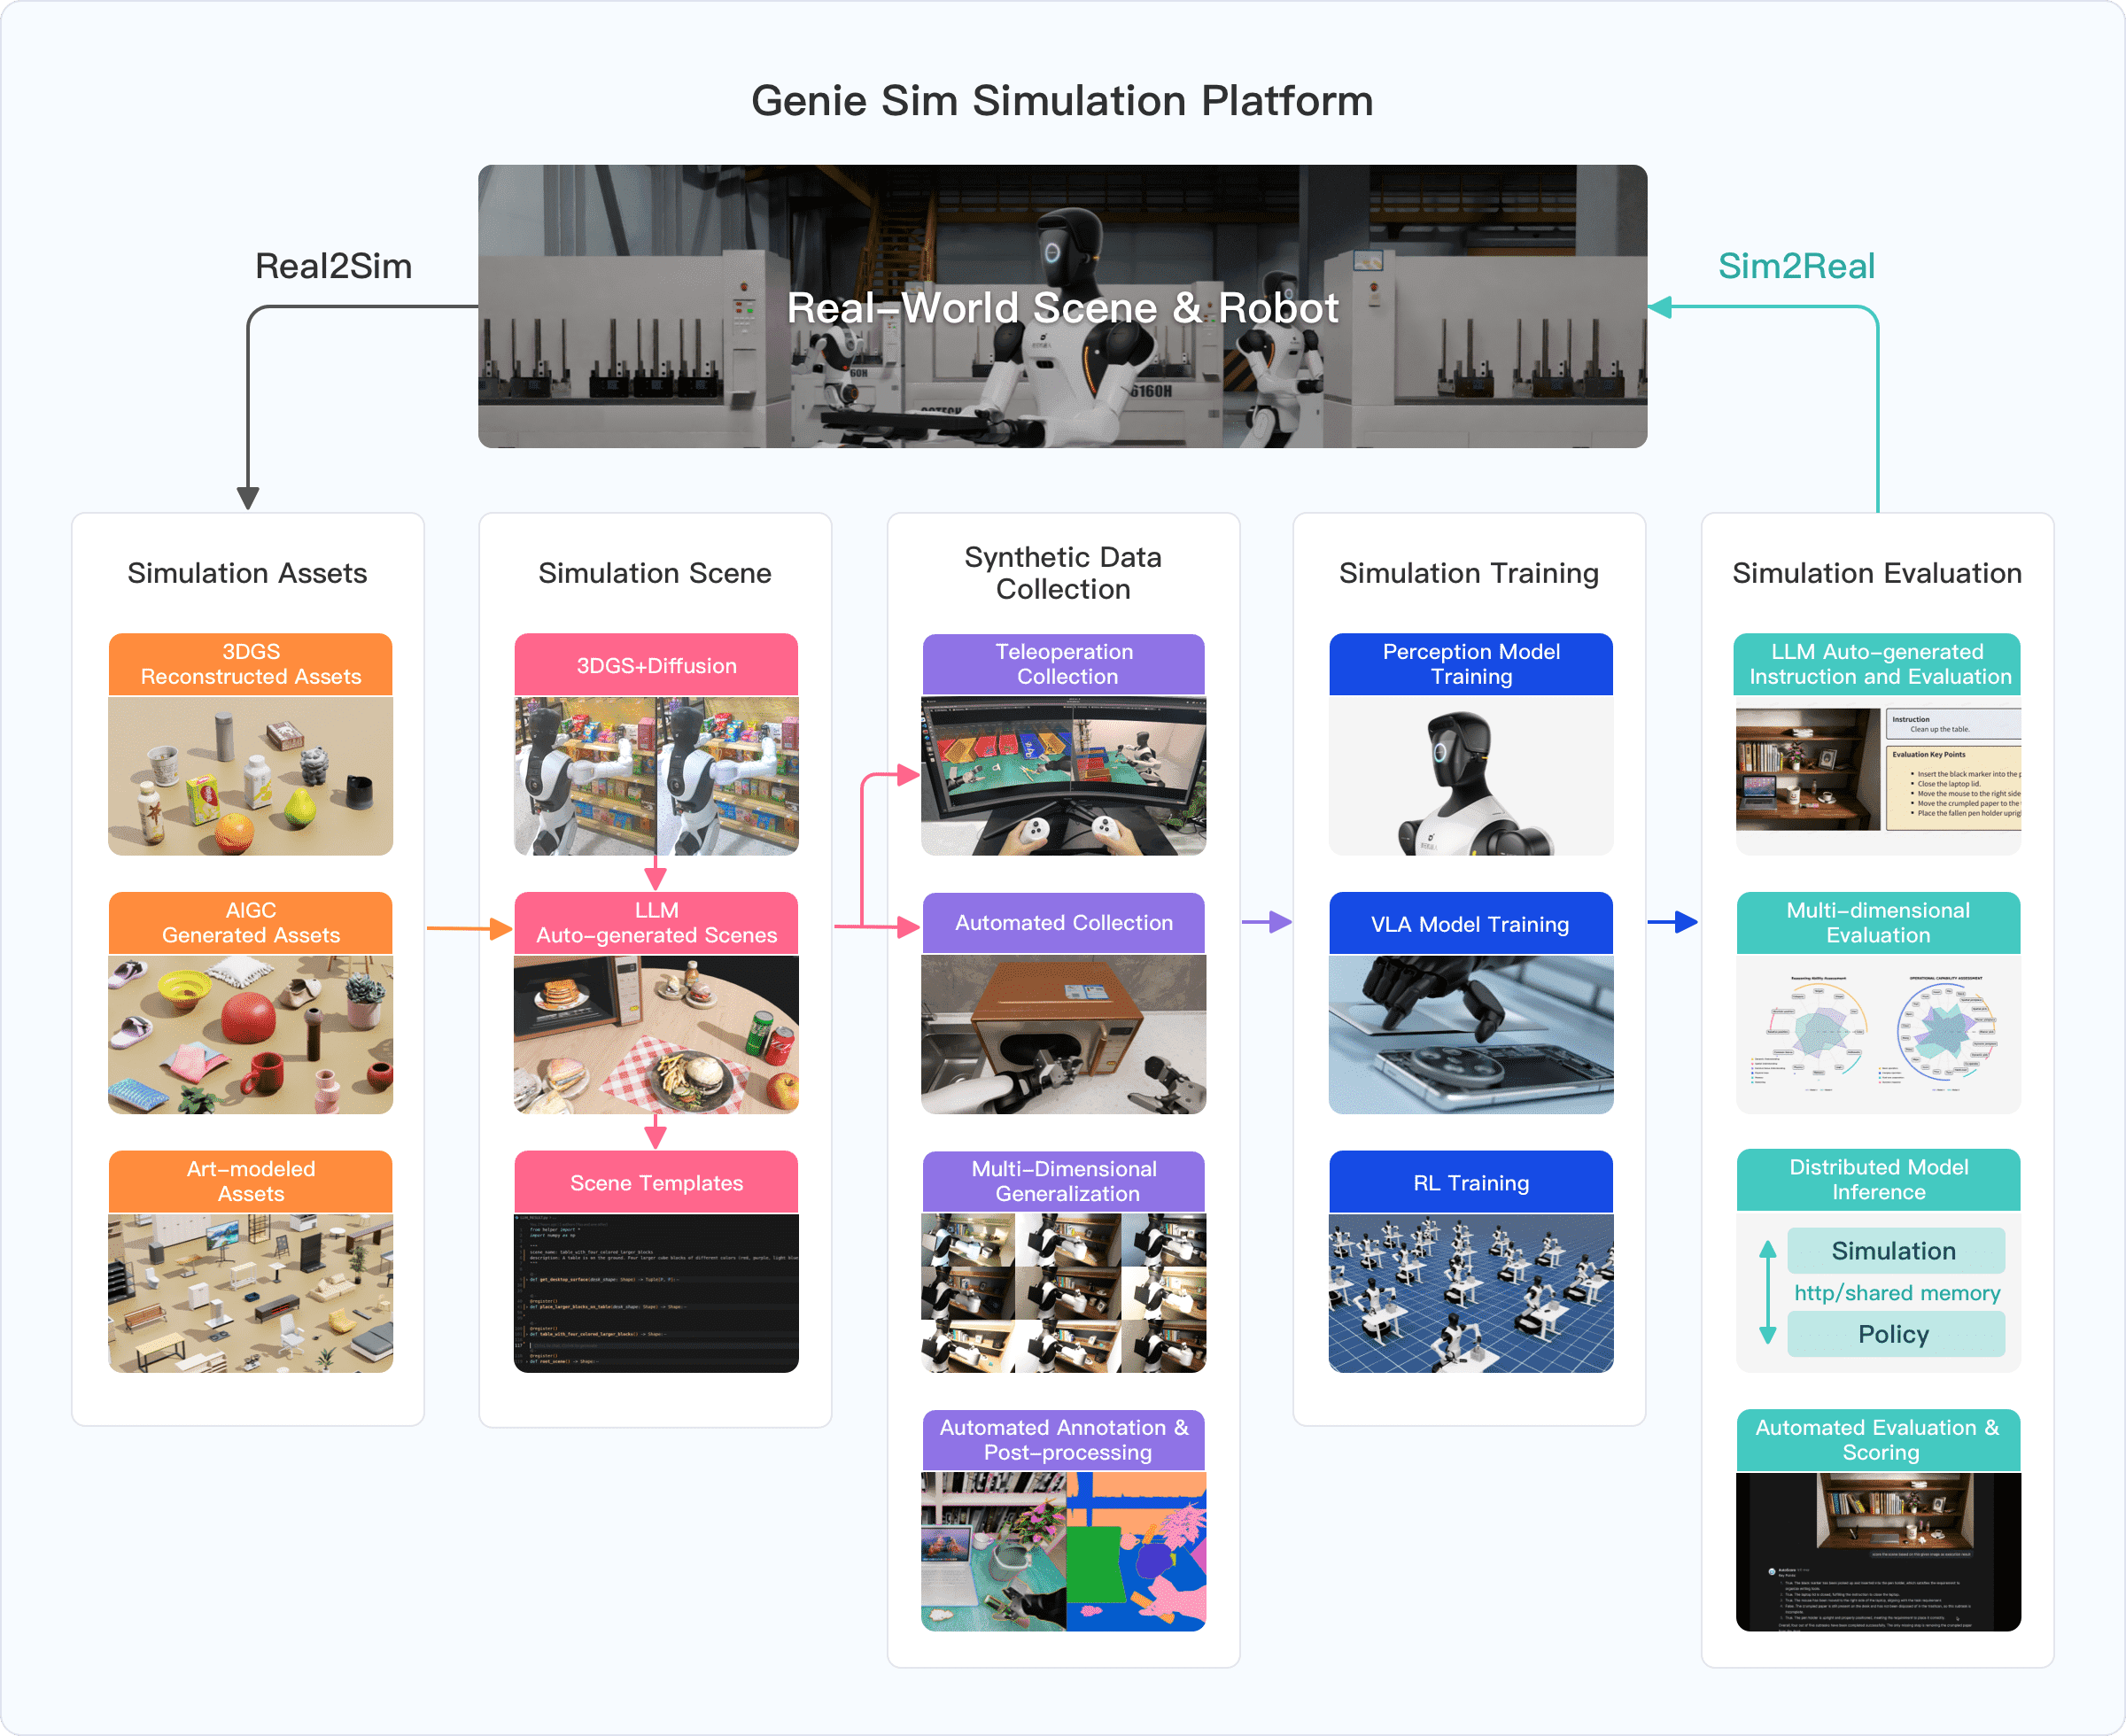
Step-by-step guide to setting up Genie Sim 3.0 — AGIBOT's open-source simulation platform on Isaac Sim for training humanoid robots.

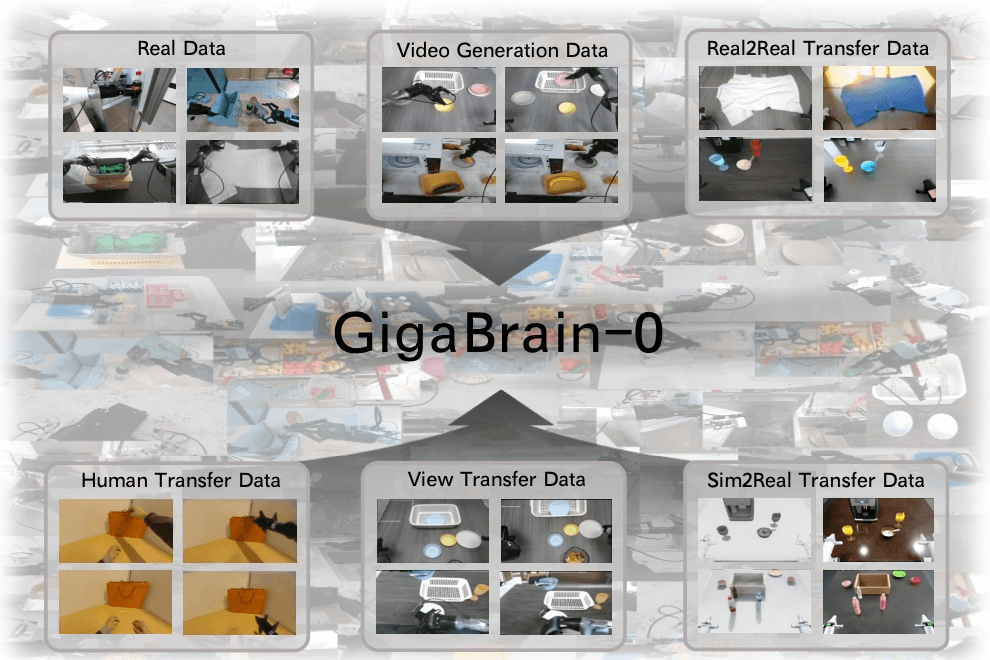
Hands-on guide to training VLA with World Models and Reinforcement Learning using the RAMP framework from GigaBrain — open-source, 3.5B params.

FlashSAC — a new off-policy RL algorithm that outperforms PPO in both speed and performance across 100+ robotics tasks.
Looking for InOrbit alternatives for your AMR warehouse fleet? Honest comparison of 5 platforms — pricing, VDA 5050, MiR/OTTO support.
Freedom Robotics works well, but maybe not for you. Honest comparison of 5 alternatives — pricing, ROS 2, free tier, live video. Includes VnRobo, Formant.

SimpleVLA-RL uses reinforcement learning with simple 0/1 rewards to boost VLA from 17 to 92 points — no complex reward engineering needed.