Series
G1 Mujoco Telemetry Control
The "G1 Mujoco Telemetry Control" series has 6 parts — read them in order from part 1.
Simulation
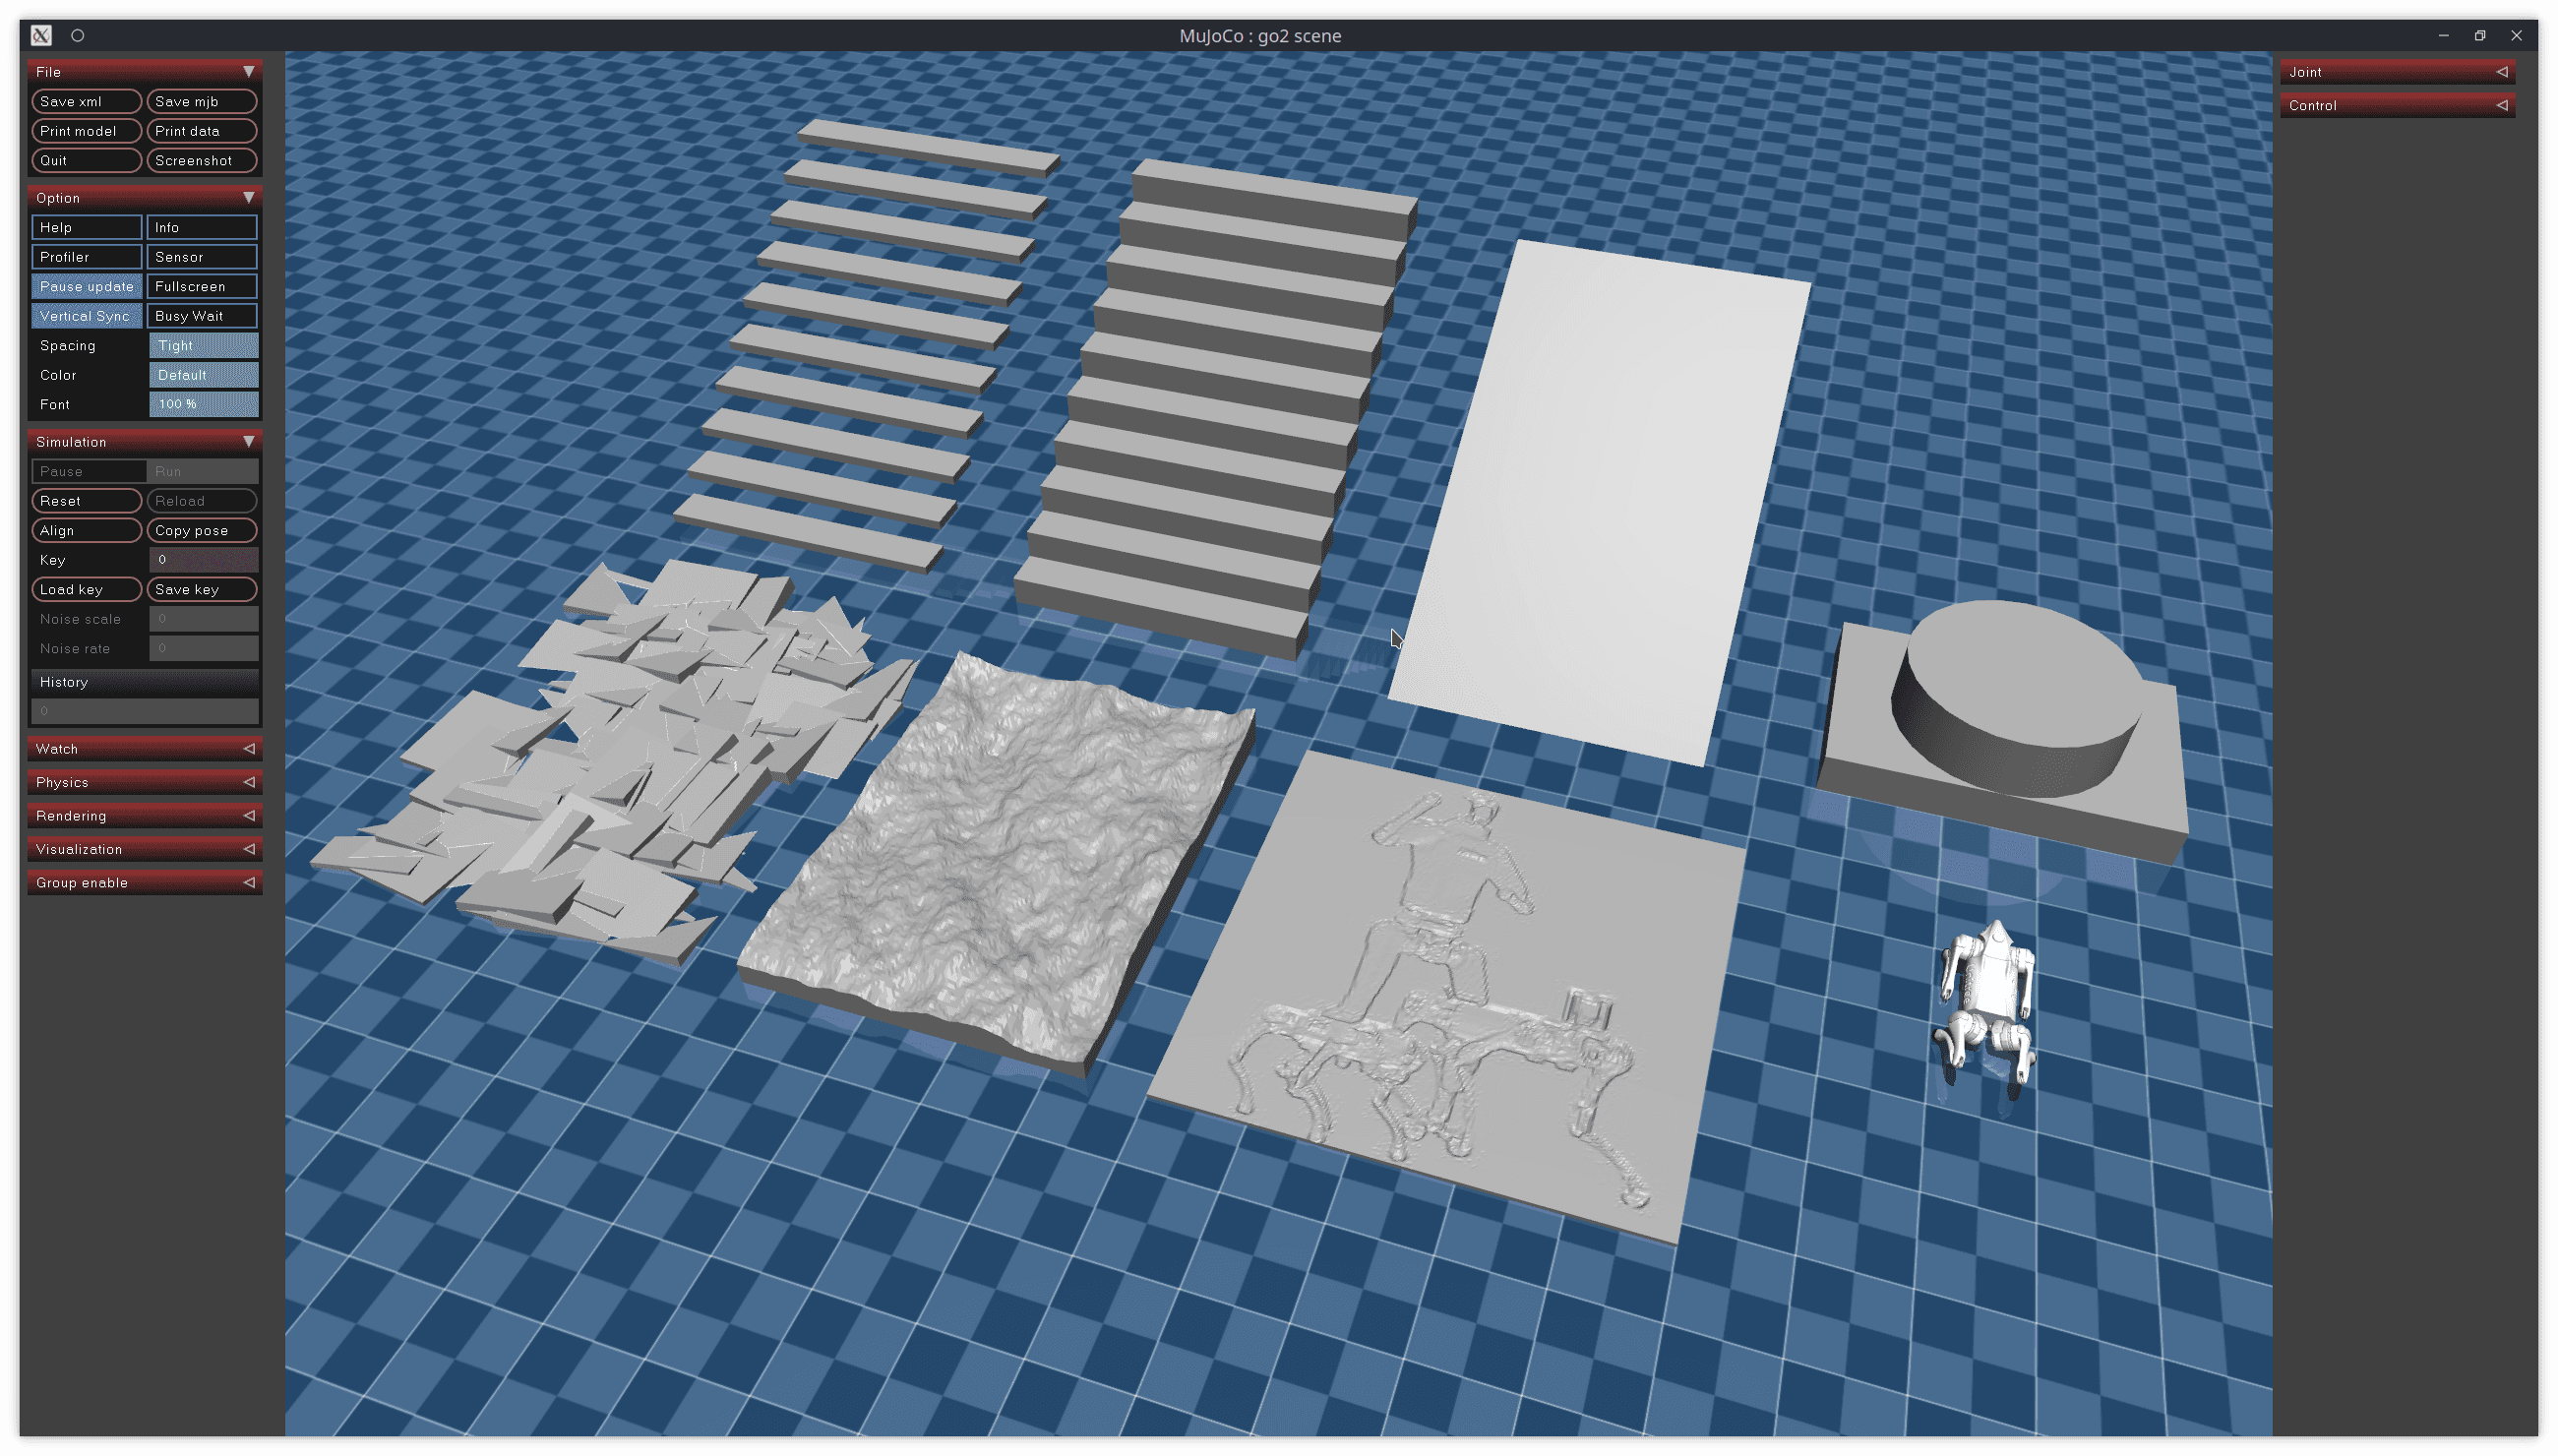
Bring Up G1 MuJoCo with Low-Level DDS
Bring up Unitree G1 in MuJoCo through SDK2 DDS: robot, scene, domain, interface, joystick, and real low-level topics.

Convert LAFAN1 G1 Motions to Foxglove MCAP
Dissect LAFAN1_MCAP_WORKING.py and convert G1 CSV poses into /tf MCAP for kinematic playback in Foxglove.

Debug G1 MPC/WBID with PlotJuggler
Use PlotJuggler to inspect SRBD, MPC, feet references, and wbid_solve_time in the G1 MuJoCo MPC/WBID stack.

From Posture PD to Contact-Aware WBID
Compare posture PD and contact-aware WBID for G1 MuJoCo: gains, q_init, qddot, contact forces, tasks, and constraints.

G1 Upper Body: IK, VR and MuJoCo
Follow the OpenWBT pipeline: VR wrist pose, G1_29_ArmIK, action_hl_idx clipping, and G1 upper body control in MuJoCo.

A Sim2Real Checklist for G1 Controllers
A practical G1 sim2real checklist covering DDS, ROS_DOMAIN_ID, OpenWBT, .pkl logs, PlotJuggler, damping and torque guards.