All posts
Page 4 of 18

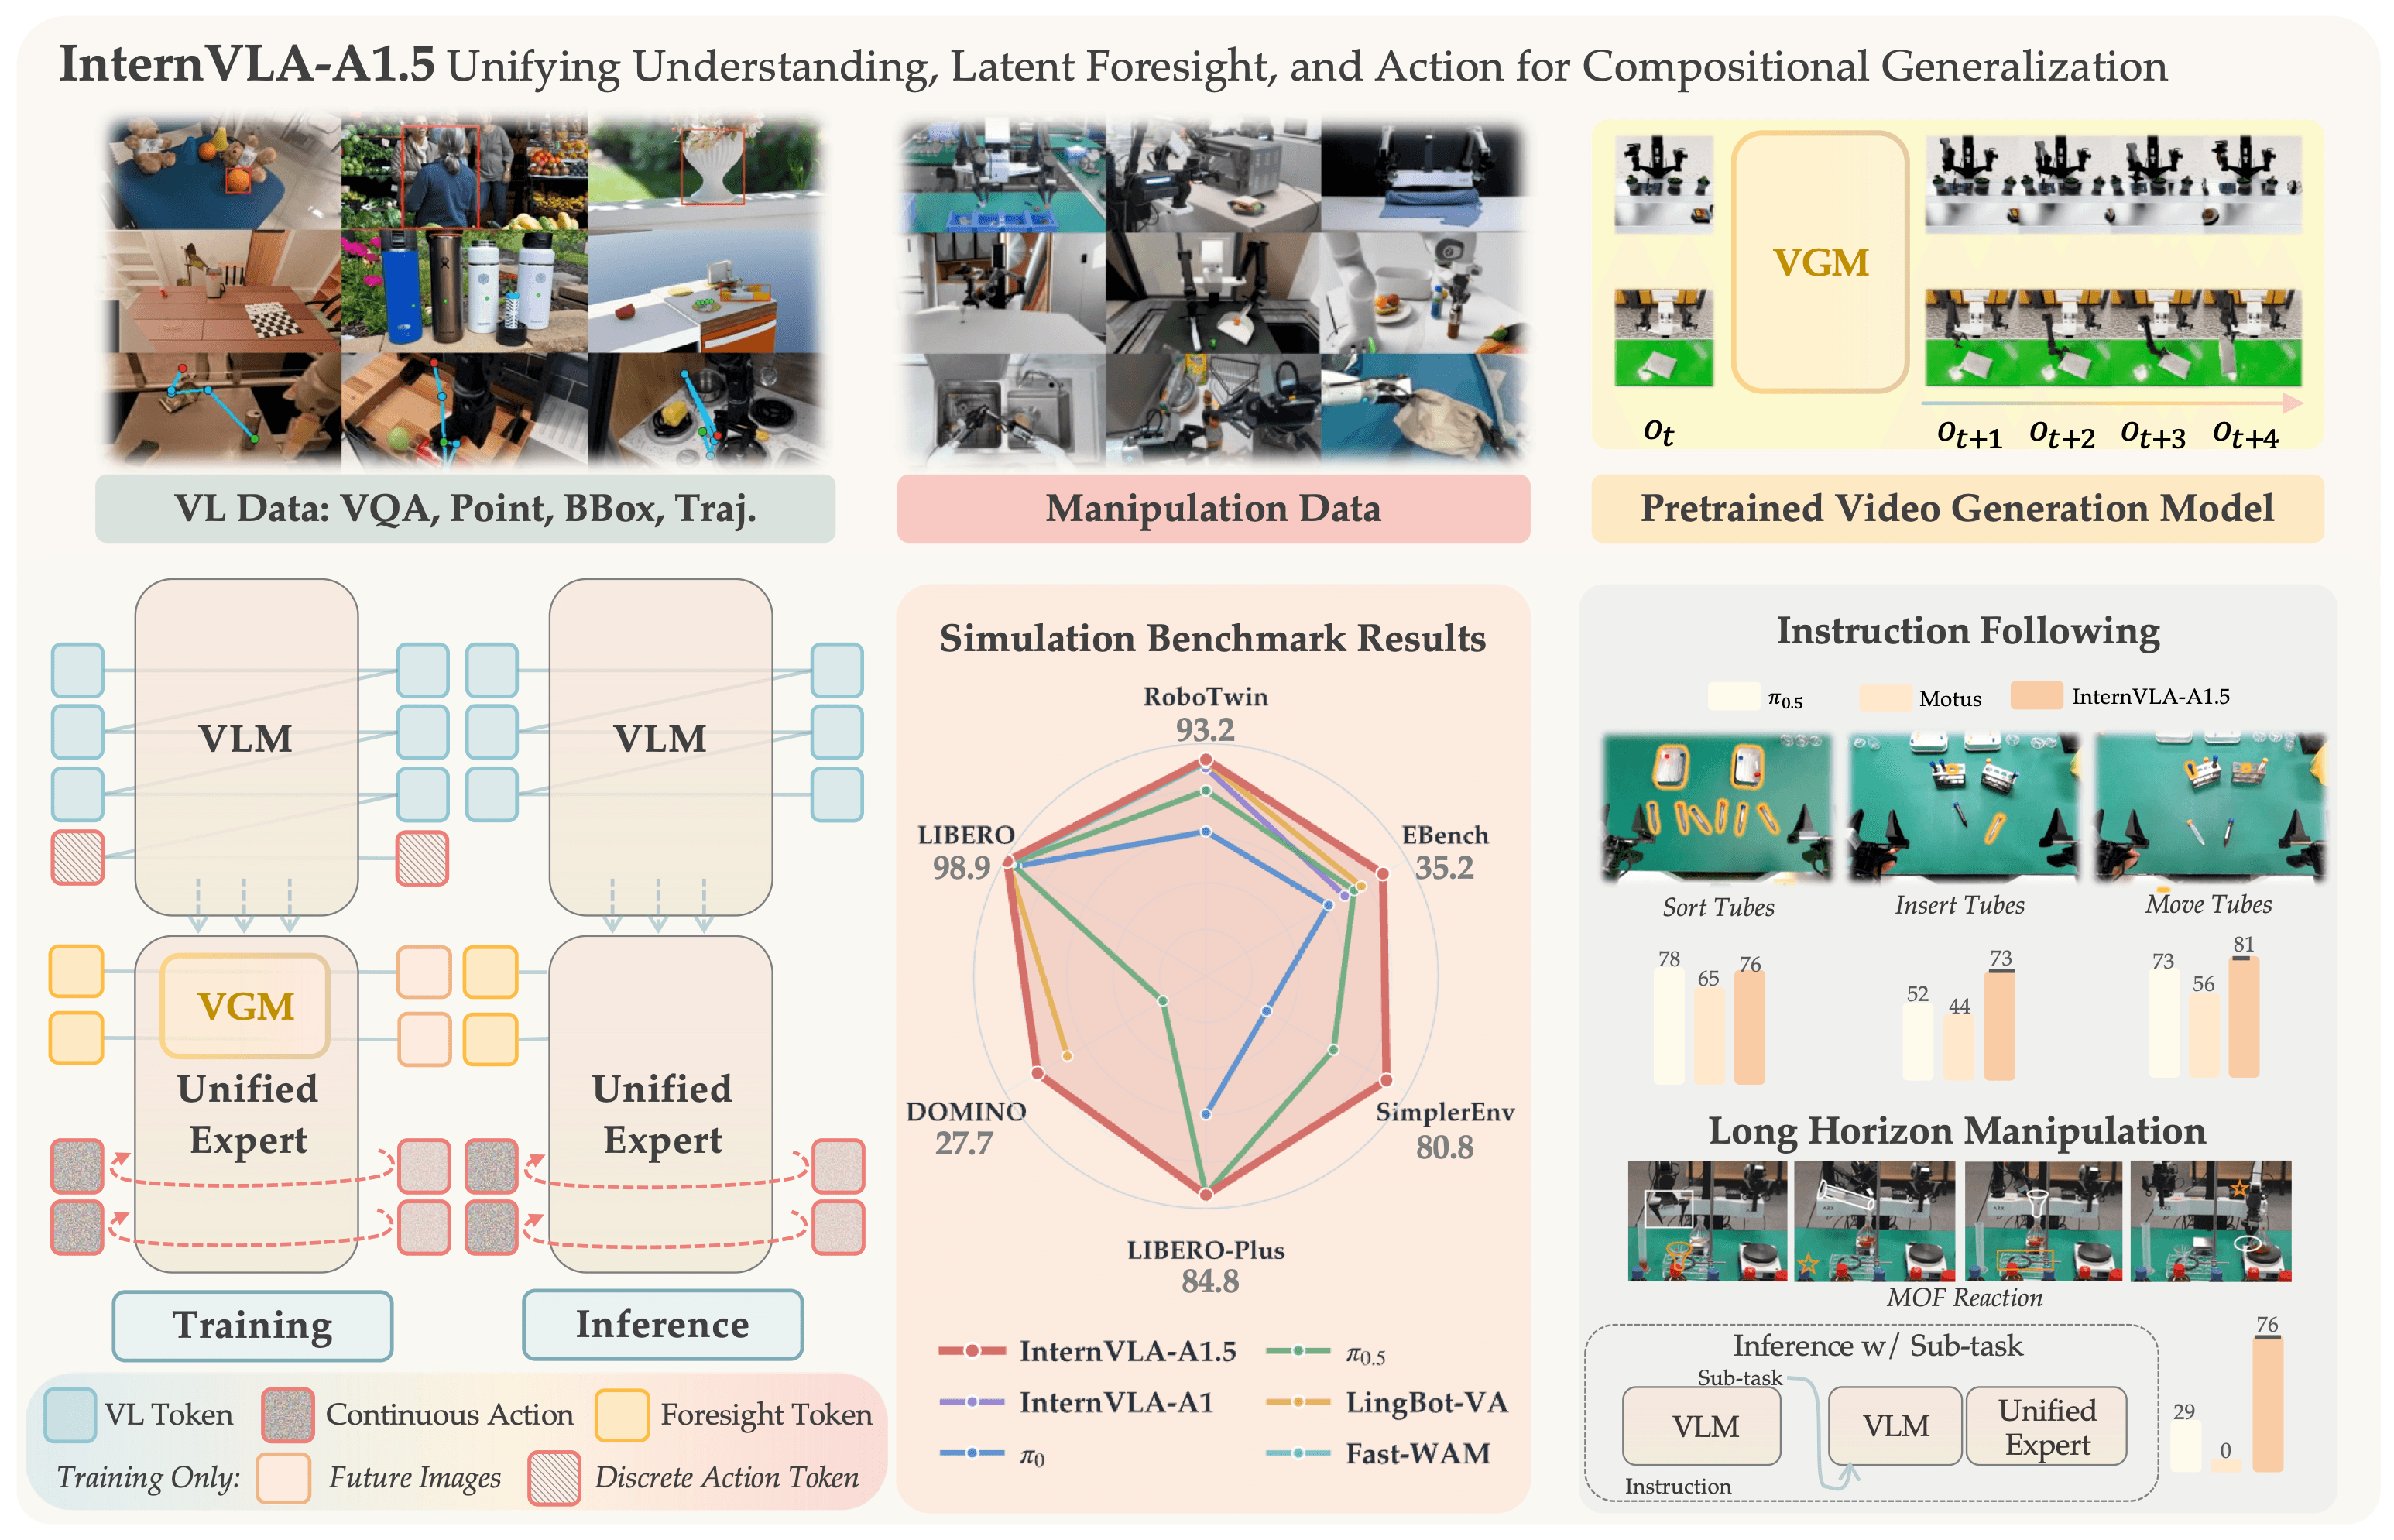
A practical guide to installing, fine-tuning, and deploying InternVLA-A1.5 on LeRobot datasets with latent foresight for manipulation VLA.

Fine-tuning and deploying GalaxeaVLA G0.5 — a unified autoregressive VLA on Qwen3.5 2B, 98.9% on LIBERO, 82.5% zero-shot DROID, open-source on HuggingFace.

A practical guide to using Cyclo Intelligence Behavior Trees to orchestrate GR00T N1.7 whole-body VLA on humanoids.

Open-source VLA from USC PSI Lab that beats GR00T N1.6 with only 80 demos. Full pipeline: install, teleoperation, 3-stage training, and deploy on Unitree G1.

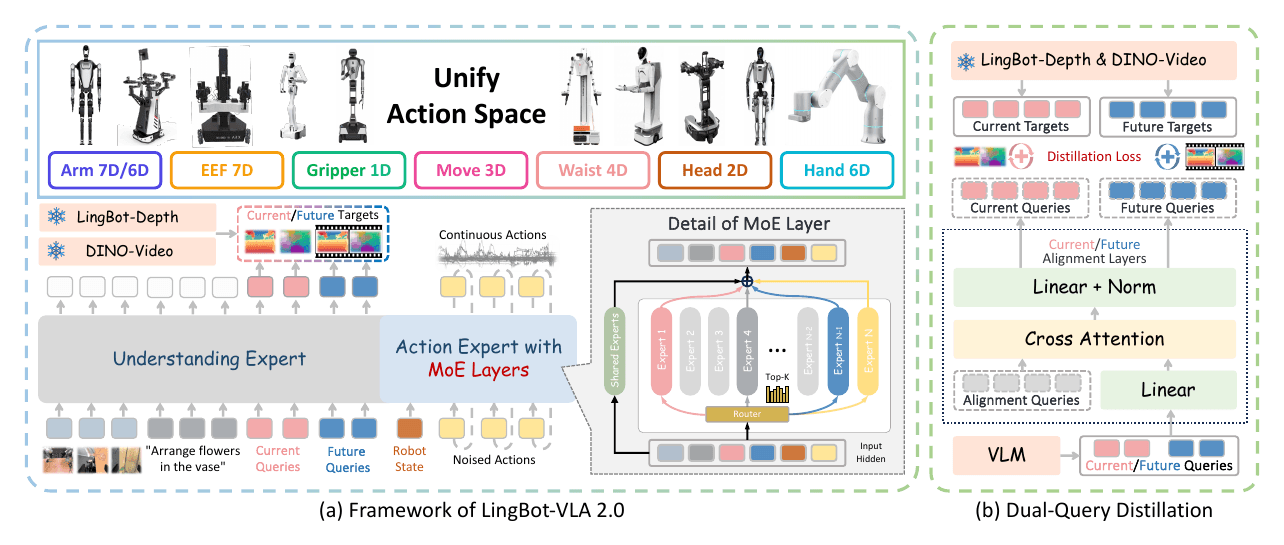
Install, post-train, and evaluate LingBot-VLA 2.0, a 55D cross-embodiment VLA for RoboTwin 2.0.

End-to-end pipeline: Isaac Teleop → LeRobot v0.6 → GR00T N1.7 — collect teleop data, fine-tune the VLA, deploy your manipulation policy on a real robot arm.

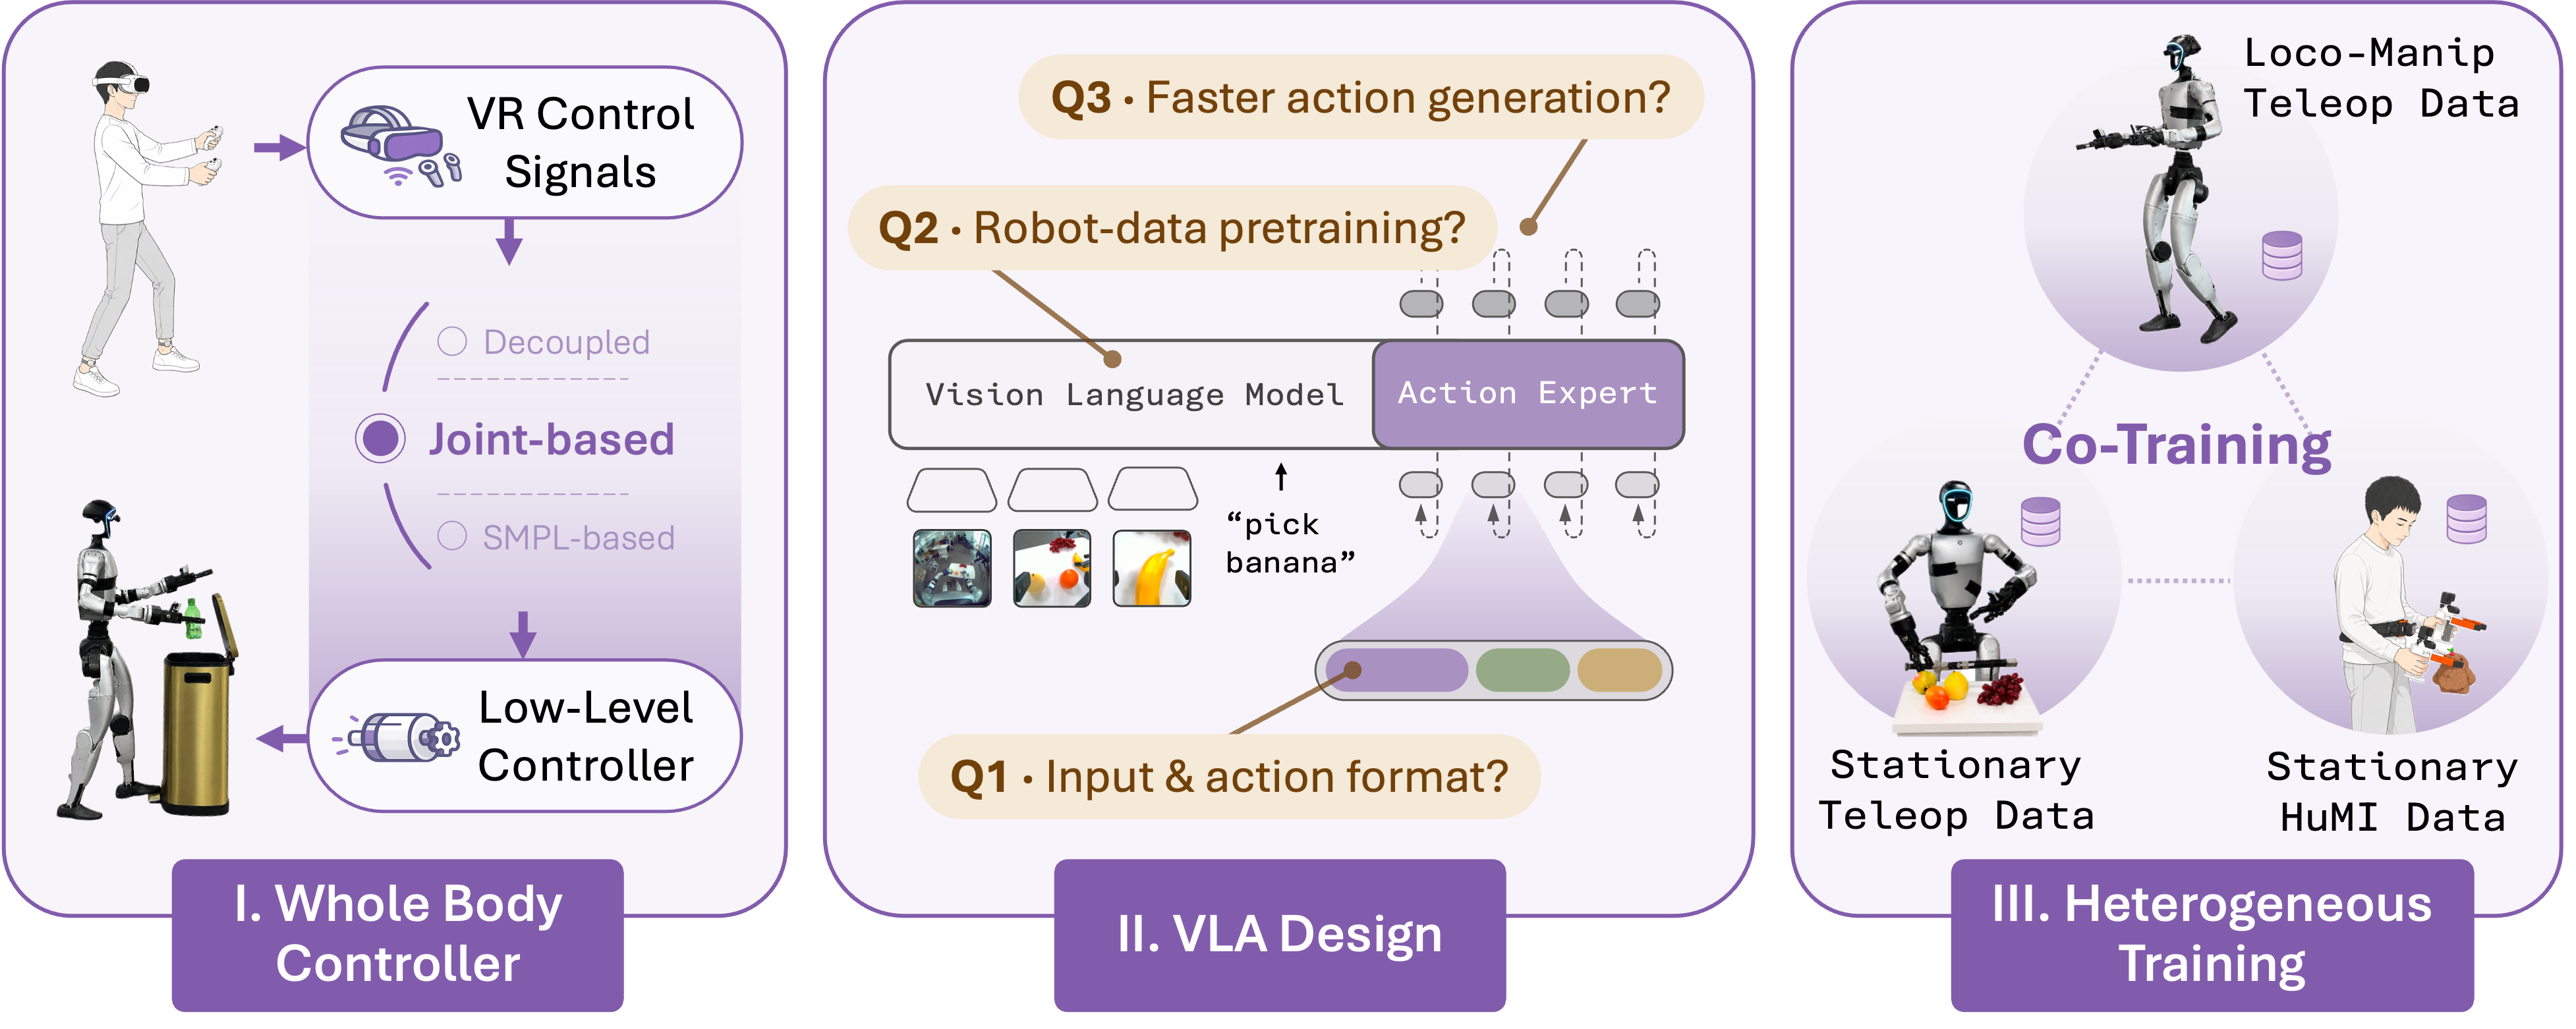
A hands-on guide to OpenHLM: native whole-body VLA for Unitree G1 with HuMI co-training, LeRobot data, training, and inference.

LingBot-VLA 2.0: a 6B-param open-source VLA with 60K hours of data, MoE Action Expert, Dual-Query Distillation, cross-embodiment manipulation beating π0.5.

A hands-on guide to DexVerse, the open-source benchmark for testing OpenVLA, π0.5, and diffusion policies on dexterous manipulation.

Setting up OpenWBC — an open-source VR teleop system using Apple Vision Pro + OpenHomie to control Unitree G1 and collect whole-body VLA data for GR00T N1.5.

OpenHLM (arXiv 2606.22174): 3-phase recipe — 32-DOF teleoperation, π0.5 VLA, HuMI co-training — beats GR00T N1.6 and Ψ₀ on G1 with under half the demo time.

LaST-R1 — a framework combining Latent Chain-of-Thought reasoning with LAPO (RL) to fine-tune VLA models to 99.8% success on LIBERO with just 1 demo/task.