All posts
Page 2 of 20

Learn PLaW-VLA architecture, installation, training and LIBERO inference, with a clear distinction between the current quickstart and paper results.

Set up RoboDojo and XPolicyLab, train and evaluate VLA policies across 42 simulation tasks, and interpret scores without misleading comparisons.

A beginner-friendly guide to fine-tuning Unitree UnifoLM-WLA-1.0, the open 6B model for tabletop and whole-body G1 manipulation.

A beginner guide to DreamMimic: RSSM latent dynamics, teacher–student distillation, installation, training, inference and simulation results.

Explore UFO's latent skills, TeCH, MJLab training, G1 tracking and teleoperation, with ONNX deployment and careful benchmark interpretation.

Transfer Agibot demonstrations to Unitree G1 through 6D trajectories, simulated retargeting, GR00T N1.5, and limited target-robot fine-tuning.

Install VLA-ACL, train a patch scorer on frozen OpenVLA-OFT, and evaluate LIBERO with action-consistent visual token pruning.

A practical guide to RACE-VLA: transition-aware action chunks that reduce stop-and-go execution on real robots.

A beginner guide to open-source UMR/WEPVLA: robot manipulation from 10 minutes of human demos using World Flow, Ego Trajectory, and point clouds.

SimpleMemVLA drops dedicated memory modules entirely, using Qwen3.5-4B's native video context as working memory — setting new SOTA on four memory-centric manipu

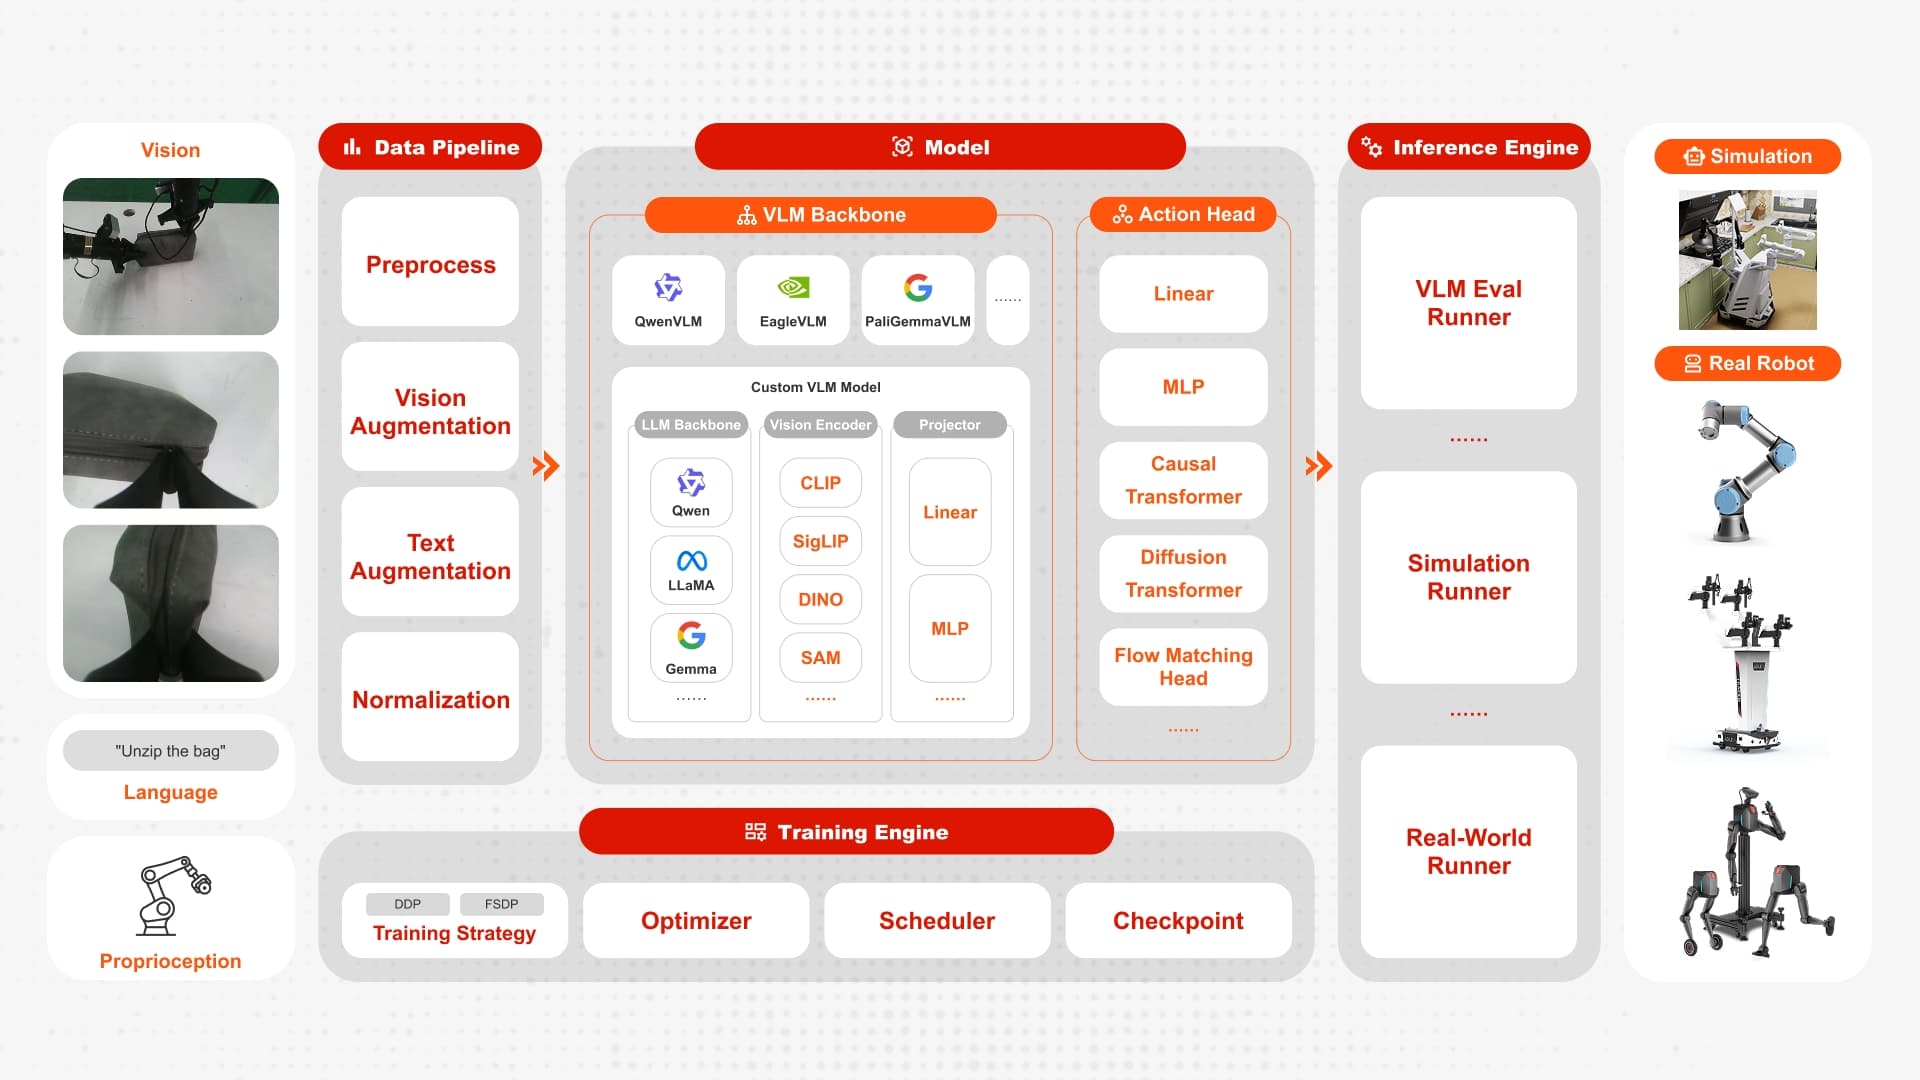
LimX Dynamics' open-source FluxVLA Engine covers the full pipeline from data to real-robot deployment, supporting Pi0, GR00T, and OpenVLA in one unified framewo

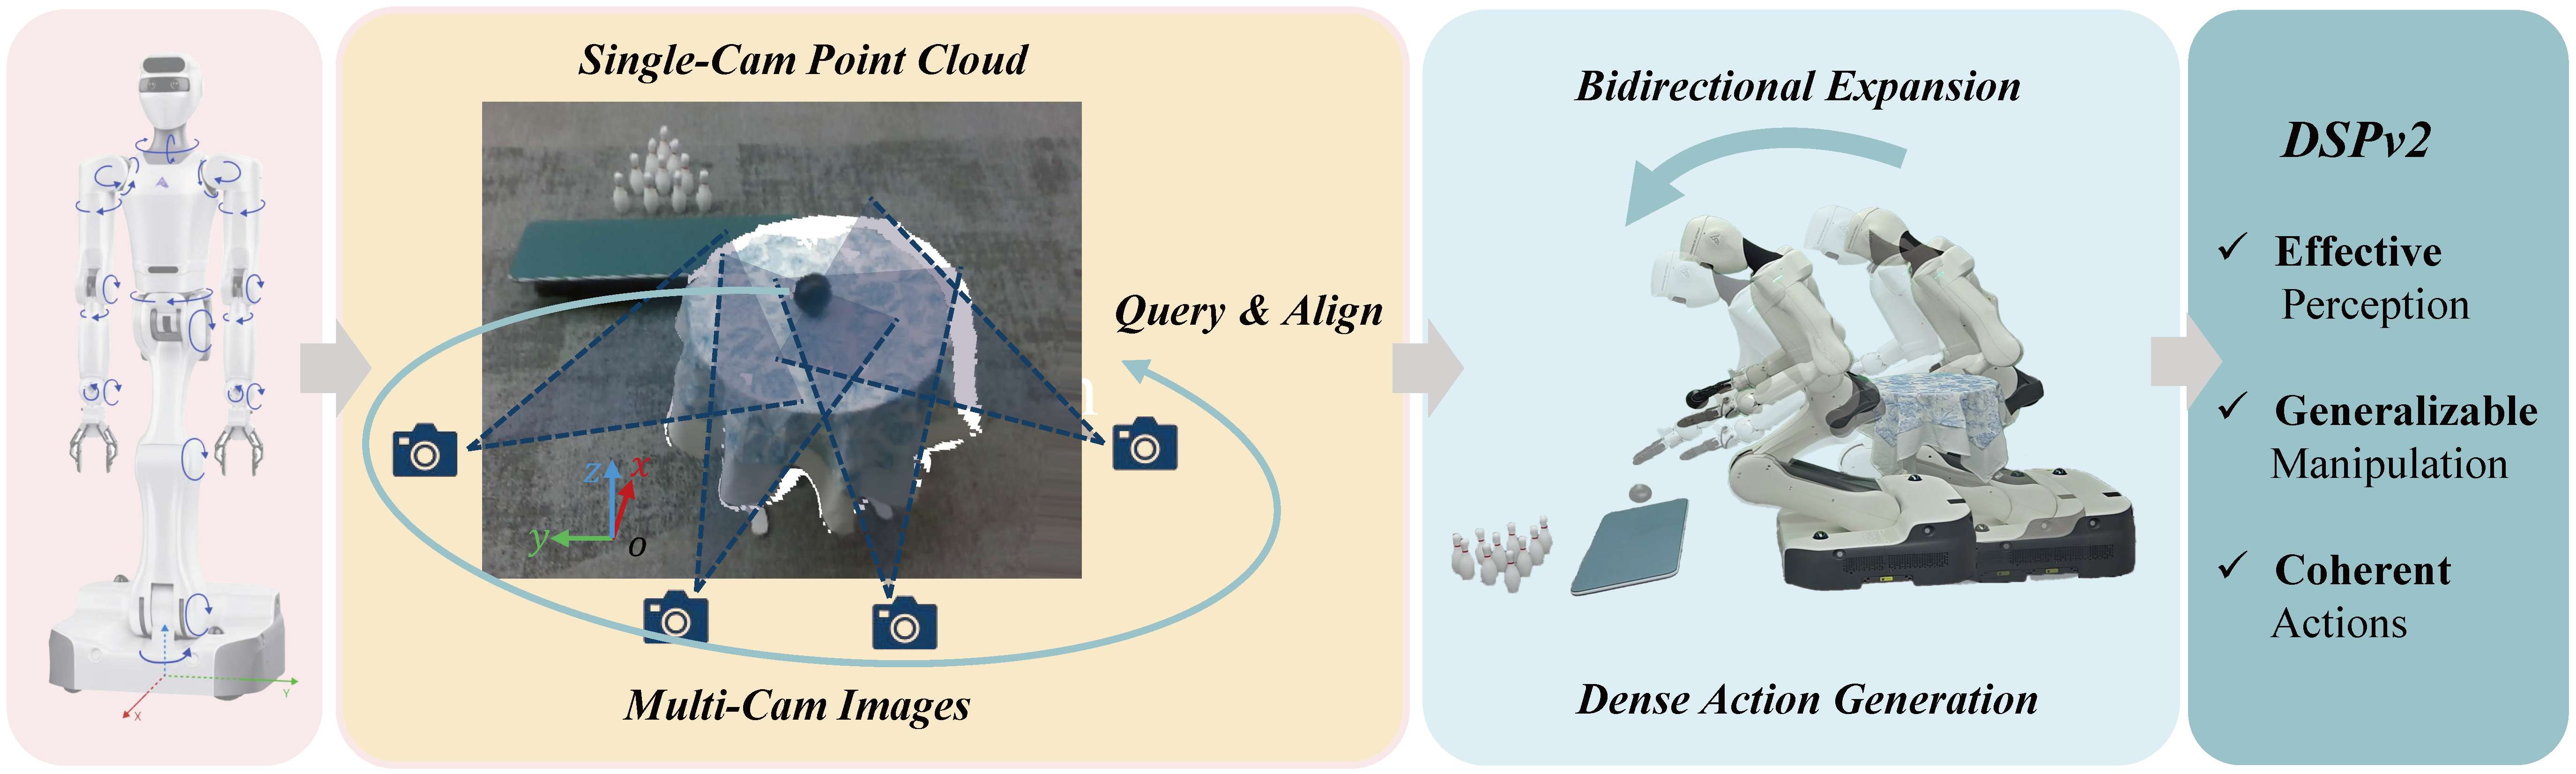
DSPv2 fuses 3D point clouds with multi-view DINOv2 semantics for generalizable whole-body mobile manipulation — complete guide to setup, training, and inference