Series
Groot N1 G1 Series
The "Groot N1 G1 Series" series has 5 parts — read them in order from part 1.
Humanoid
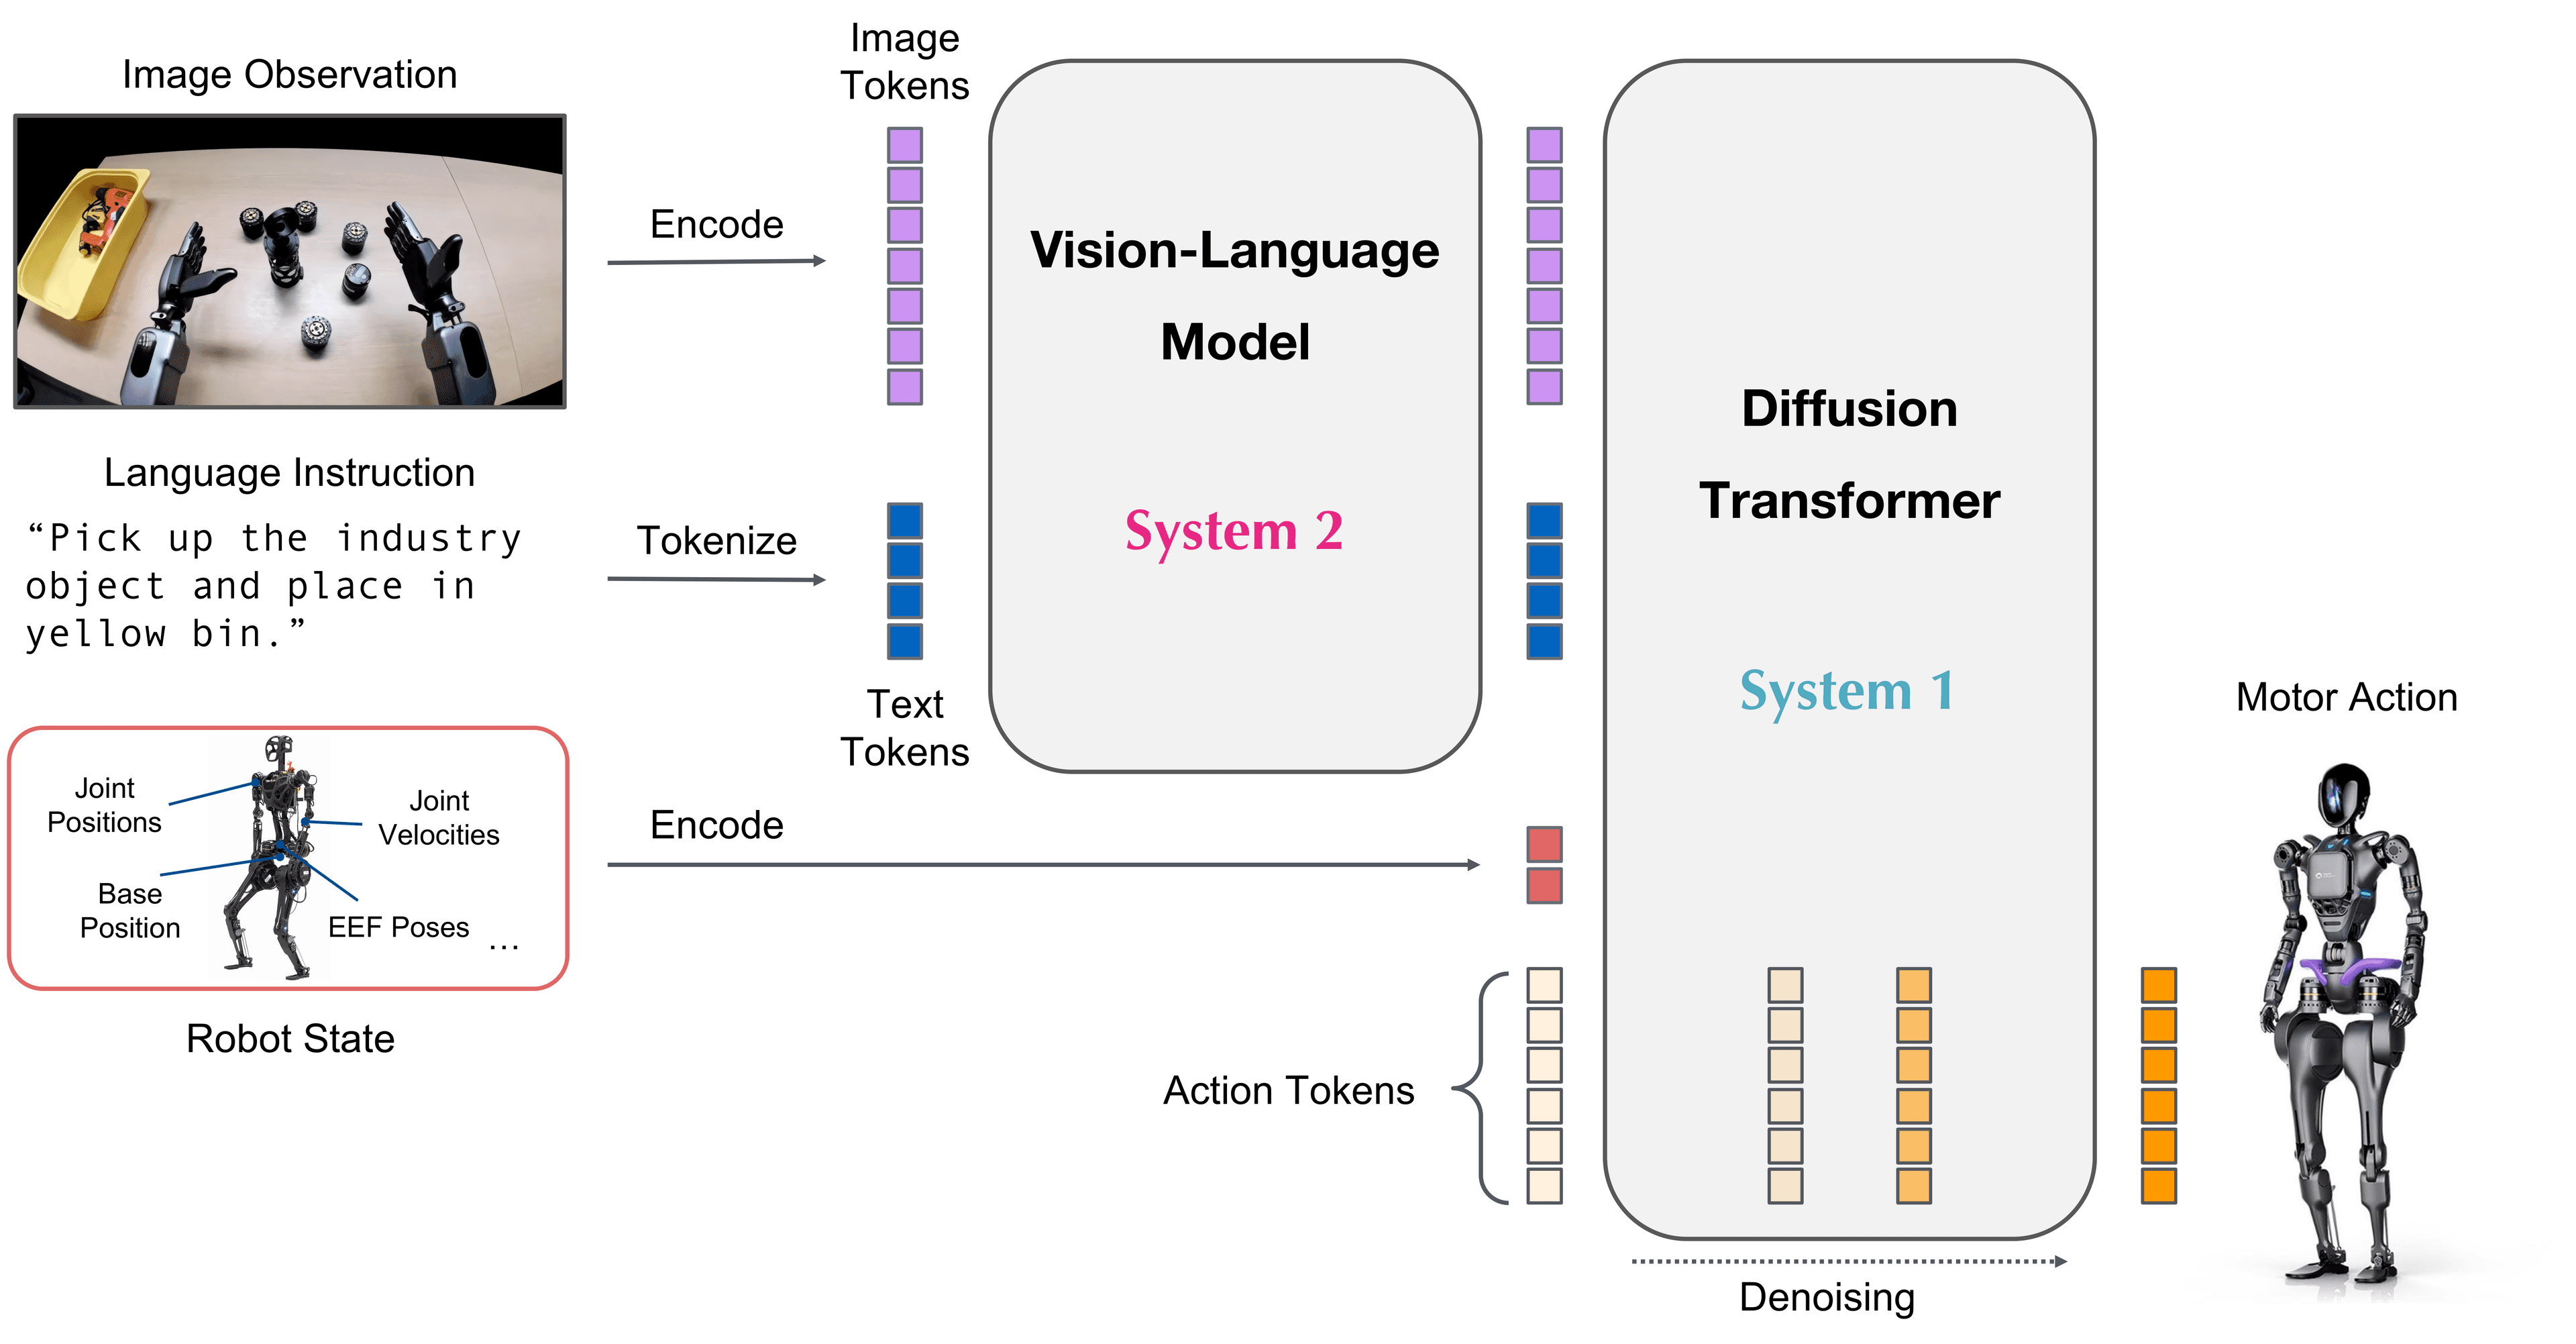
GR00T N1 + G1: decoupled WBC+VLA architecture, 6Hz-500Hz
How GR00T N1 (VLA at 6Hz) combines with GR00T-WBC (200Hz) to control Unitree G1 — decoupled architecture, why end-to-end fails, how to adapt for other robots.

GR00T N1 + G1 (Post 2): data collection with xr_teleoperate
Collecting data for GR00T N1 via two tracks: Isaac Lab simulation teleop (no robot needed) and real xr_teleoperate on G1 — both producing LeRobot format.

GR00T N1 + G1 (Post 3): fine-tuning — GPU, config, script
Fine-tune GR00T N1 (2B params) with a LeRobot dataset from G1 — GPU requirements, training config, avoiding overfitting, evaluating checkpoints before deploy.

GR00T N1 + G1 (Post 4): deploying GR00T-WBC — GEAR + SONIC
Deploy the GR00T-WBC stack (GEAR upper body 50Hz + SONIC locomotion 200Hz) on G1 with a fine-tuned GR00T N1 checkpoint — joint mapping, PD tuning, safety.

GR00T N1 + G1 (Post 5): sim2real transfer and eval
Closing the loop: domain randomization in Isaac Lab, actuator modeling for sim2real gap, deploy to real G1, benchmark with humanoid-bench, plus a debug guide.