All posts
Blog
Page 17 of 18
Navigation
amrautomationfleet
navigationAMR vs AGV: What's the Difference and Which to Choose
AMR navigates dynamically with SLAM; AGV follows fixed guides. Compare cost, flexibility, ROI and safety to pick the right fleet for your plant.
1/5/20268 min read
NT
Robot AI
researchroboticsai-perception
aiTop Robotics Research 2024-2025: Must-Read Papers from ICRA, CoRL and RSS
Summary and analysis of the most influential robotics papers — from foundation models for robots, dexterous manipulation to sim-to-real transfer.
12/15/202513 min read
NT
Humanoid
humanoidroboticsresearch
humanoidHumanoid Robots: From Research to Real-World Applications
Overview of humanoid robots — bipedal walking, whole-body control, and platforms like Tesla Optimus, Figure 02, and Unitree H1.
12/1/202510 min read
NT

amrai-perceptionlidar
navigationLiDAR and 3D Mapping: Building Environment Maps for Robots
Understanding LiDAR and 3D Mapping — using LiDAR sensors and PCL to create accurate 3D maps for autonomous robots.
11/15/20254 min read
NT
Navigation
devopskubernetesfleet
navigationKubernetes for Robot Fleet: Orchestration at Scale
Using Kubernetes and K3s to manage, update, and monitor hundreds of robots with GitOps principles.
11/1/20254 min read
NT
Research
safetystandardscobot
researchIndustrial Robot Safety Standards: ISO 10218 and ISO/TS 15066
Understand ISO 10218 and ISO/TS 15066 standards to design and deploy industrial robots safely, especially collaborative robots working with humans.
10/15/20254 min read
NT
Simulation
industry40digital-twinsimulation
simulationDigital Twin in Manufacturing: Smart Factory Simulation
Digital Twin in manufacturing allows smart factory simulation, process optimization and significantly reduced deployment costs.
10/1/20253 min read
NT
roboticsros2embedded
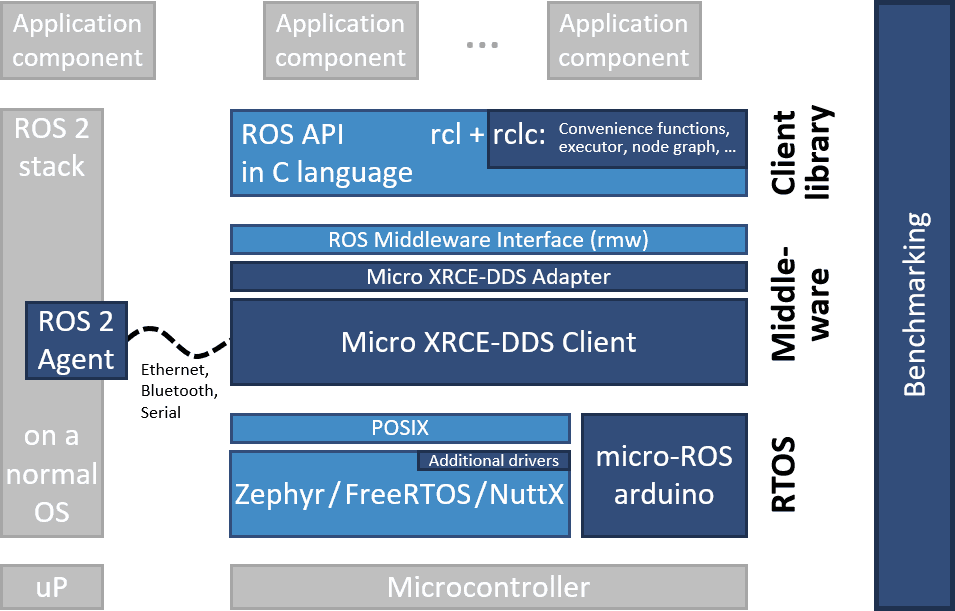
otherMicro-ROS: Connecting Microcontrollers to ROS 2 Ecosystem
Micro-ROS brings ROS 2 to microcontrollers like ESP32 and STM32, extending ROS 2 ecosystem down to embedded layer.
9/15/20254 min read
NT
ai-perceptionedge-computingnvidia
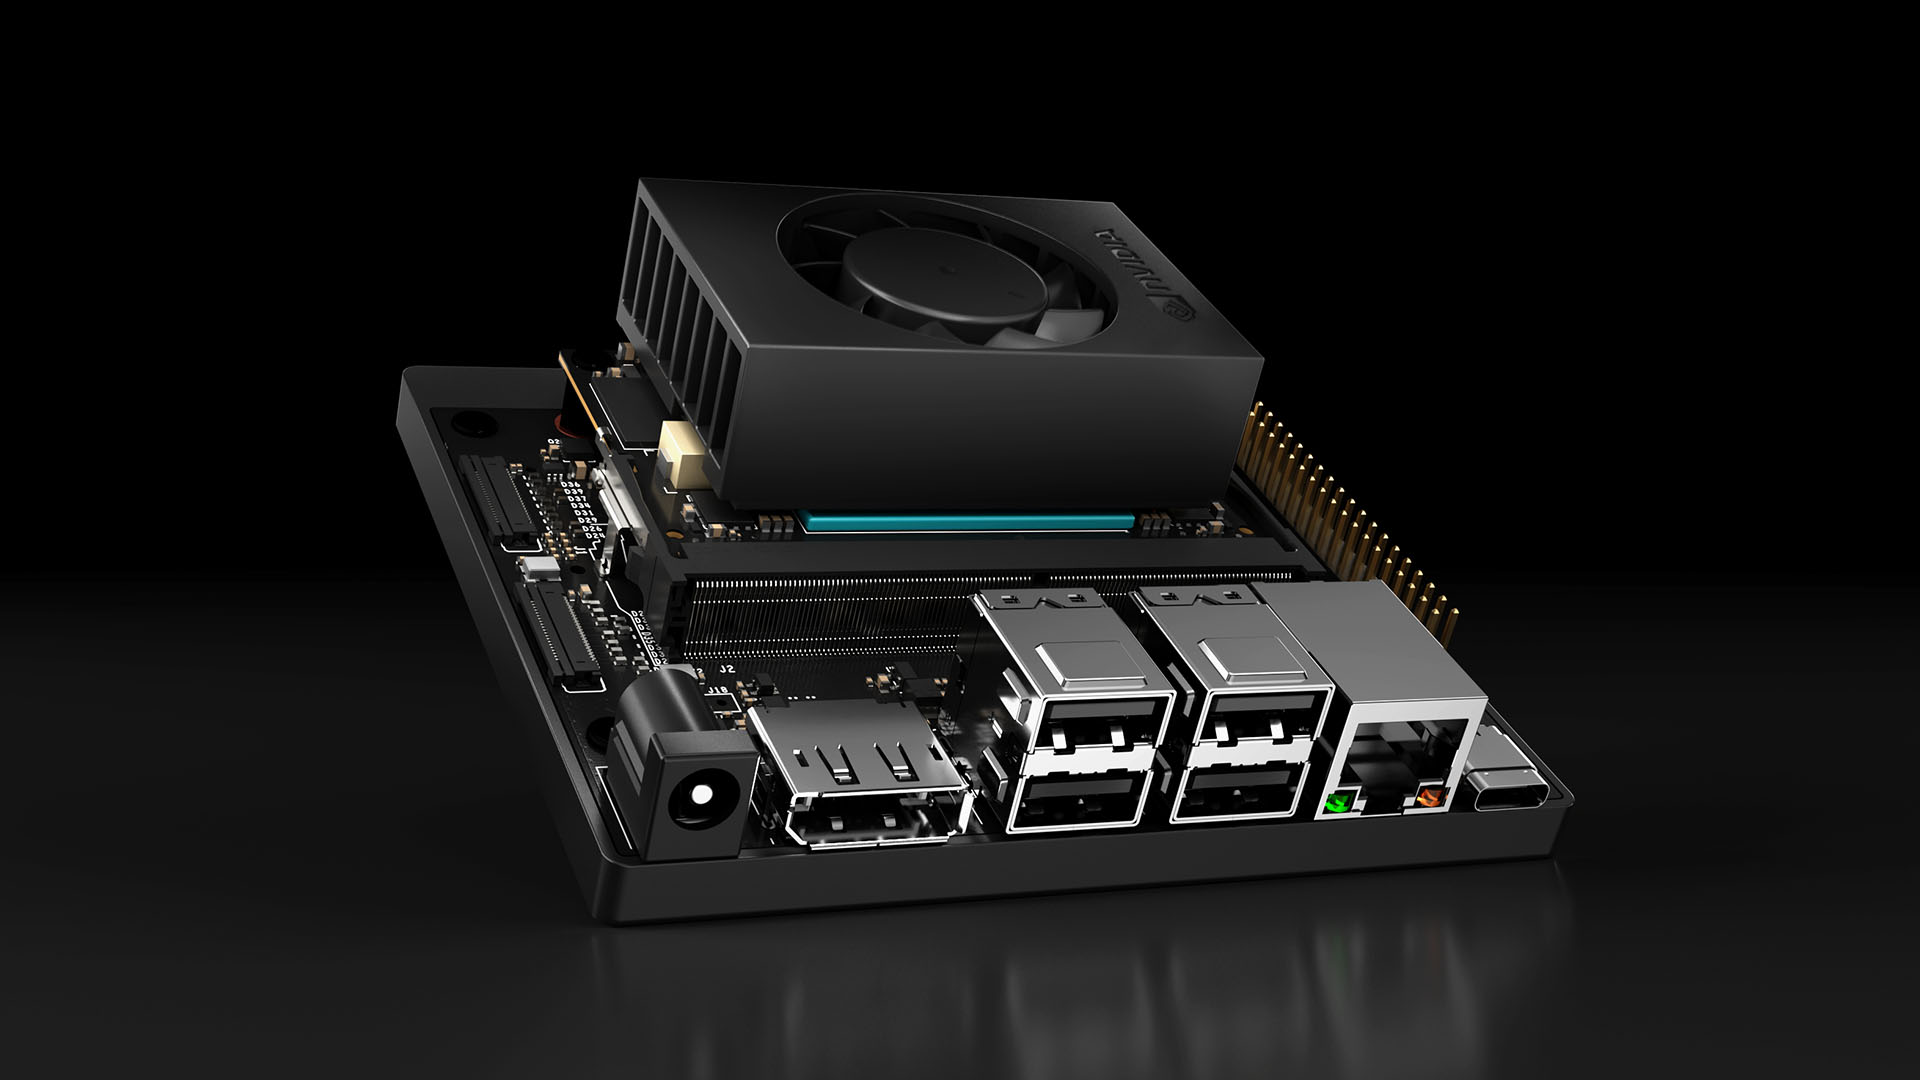
aiEdge AI with NVIDIA Jetson: Deploy AI on Embedded Devices
Guide to deploying Edge AI with NVIDIA Jetson and TensorRT — optimize real-time inference for robots and embedded applications.
8/15/20253 min read
NT
Manipulation
robot-armpythonprogramming
manipulationProgramming Robot Control with Python: From Basics to Advanced
Python is the most popular language in robotics thanks to rich library ecosystem. Learn how to control robots from GPIO to kinematics.
8/1/20254 min read
NT
Robotics
devopsdockeriot
otherDeploy IoT Applications with Docker and Docker Compose
Guide to deploying IoT applications with Docker and Docker Compose on edge devices — consistent packaging, management and easy maintenance.
7/15/20253 min read
NT
Robot AI
ai-perceptionroboticsresearch
aiAI Trends in Robotics 2025: From LLM to Embodied AI
Overview of AI trends in Robotics 2025 — foundation models, sim-to-real transfer, and Embodied AI transforming the industry.
7/10/20253 min read
NT